Karaniwang presyo bawat araw
Mga halaga sa USD


Learning Robotics with ROBOTIS DREAM Systems
The video tutorials can be accessed at this YouTube videos playlist.
Learning Robotics with ROBOTIS DREAM Systems Excerpts
This book has 6 chapters:
?
1) Chapter 1 presents an overview of the DREAM II system and its relationship with the SMART III system.
The Sense-Think-Act paradigm used in developing the contents of this book is also described in this chapter:
1.1 ROBOTIS DREAM II System Overview
1.1.1 DREAM II - Levels 1-5 Edition
1.1.2 DREAM II - School Set
1.1.3 From DREAM II to SMART III
1.2 Sense-Think-Act Paradigm
1.3 References
1.4 Review Questions for Chapter 1


2) Chapter 2 describes the hardware and software capabilities of the DREAM II system and shows how to get started on Windows PCs as well as Mobile Devices. This chapter also shows how to use the ROBOTIS MANAGER software tool using a basic “AVOIDER” robot design:
2.1 Using Basic Avoider on Windows PCs
2.2 Using Basic Avoider on Mobile Devices
2.3 Downloading Example Codes
2.4 References
2.5 Review Questions for Chapter 2


3) Chapter 3 is a substantial chapter providing a gradual but in-depth tutorial about applications of the R+TASK software tool using three robot designs - “AVOIDER/FOLLOWER”, “TRICYCLE” and "DOWEL SCANNER". Topics included autonomous-behavior and remote-control algorithms, CALLBACK function, communication and audio programming techniques. PC and Mobile uses of the TASK tool will be shown:
3.1 Learning Sequence Control
3.2 Learning Program Modularization with Functions
3.3 “Spinning Top” Maneuvers using IR Center Sensor
3.3.1 Solution using Parallel IF Structures
3.3.2 Solution using IF-ELSE-IF Structures
3.4 “Avoider” Maneuvers using Left and Right IR Sensors
3.5 “Follower” Maneuvers using Left and Right IR Sensors
3.6 Autonomous Behavior Programming Summary
3.7 Remote Control Programming Techniques
3.7.1 Structure of the “Remocon” packet
3.7.2 RC of “Avoider” using PC’s Virtual RC-100
3.7.3 RC of “Avoider” using Mobile Virtual Controllers
3.7.4 Combining Autonomous Behavior and Remote Control
3.8 Line Tracking & Obstacle Avoidance with NIR Sensors
3.9 Using Servo Motor & External NIR Sensor
3.9.1 Tricycle Steering Control with Servo Motor
3.9.2 Dowel Scanner
3.9.3 Using Function CALLBACK for Data Acquisition
3.10 References
3.11 Review Questions for Chapter 3


4) Chapter 4 is also another substantial chapter mirroring the instructional approach and topics developed in Chapter 3 but now using the R+SCRATCH/SCRATCH 2 tool chain and its multimedia and event programming features.
4.1 Basic Robot Programming with SCRATCH 2
4.2 Sequential Control of Robot Maneuvers
4.3 Remote Control of “FlashDancer” via PC’s keyboard
4.4 “Spinning Top” Maneuvers using Center IR Sensor
4.5 “Avoider” Maneuvers using Left and Right IR Sensors
4.6 “Follower” Maneuvers using Left and Right IR Sensors
4.7 Smart Avoider
4.8 Line Follower – Obstacle Avoider
4.9 Dowel Scanner
4.10 References
4.11 Review Questions for Chapter 4


5) Chapter 5 presents mechanical design concepts inherent in the mechanical components provided in the DREAM II system, with the goal of helping students understand the mechanical design concepts represented in the provided example robots of Level 1, and be creative in their own robot designs by showcasing additional mechanical concepts and robot designs.
5.1 Direct Motor Drive
5.2 Gear Applications
5.2.1 Using Sprockets (Windmill & Dragonfly)
5.2.2 Using Pulleys & O-rings (i.e. Tires)
5.3 Linkage Applications
5.3.1 Whale
5.3.2 Brachiosaurus & Cow
5.3.3 Rabbit
5.3.4 Ladybug
5.3.5 Chick
5.3.6 Kangaroo
5.3.7 Caterpillar
5.3.8 Tyrannosaurus
5.4 Review Questions for Chapter 5


6) Chapter 6 provides a closer look at select programmable robots provided in Levels 2 and 3 and seeks to explain their hardware/software features and to offer suggestions for expanding select robots beyond their original designs or solutions (https://youtu.be/8NxViBFM5no).
6.1 Elephant with NIR Sensor
6.2 Flower & Butterfly with NIR Sensor
6.3 Seal with Servo Head
6.4 Beetle with NIR Sensor
6.5 Racoon with PIR
6.6 Bull Fight using NIR and Color Sensors
6.7 Raging Bull - SCRATCH vs. TASK
6.8 MotoCycle
6.9 Four-Wheel Drive Dump Truck


ISBN-10: 099939181X
ISBN-13: 978-0999391815
Kasaysayan ng presyo
Isang punto ng datos bawat araw, na kinuwenta ang average ayon sa petsa ng obserbasyon.
Mga halaga sa USD
Kinakalkula ang mga average bawat araw ng UTC mula sa lahat ng naitalang presyo ng alok.
Robotis
£22.08
Robotis
£18.75
Robotis
£20.06
Robotis
£21.92
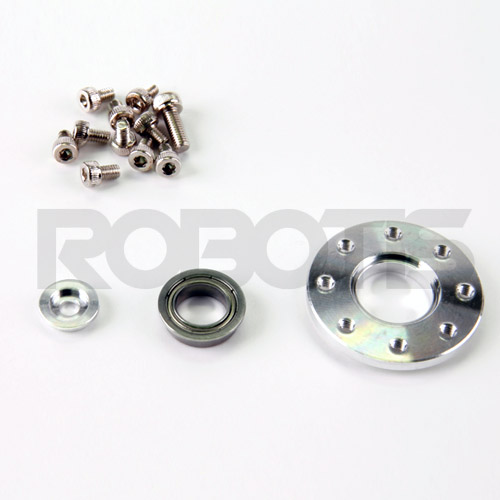
Robotis
£14.75
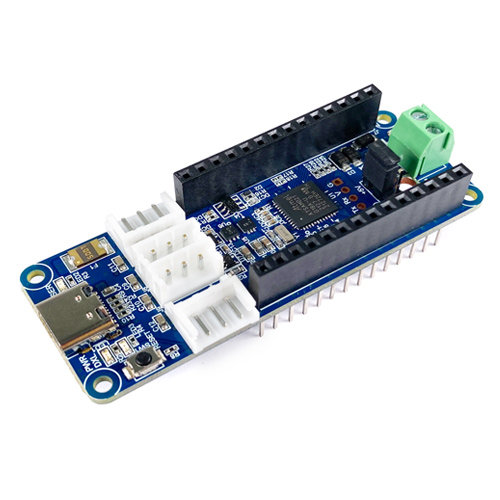
Robotis
£24.25
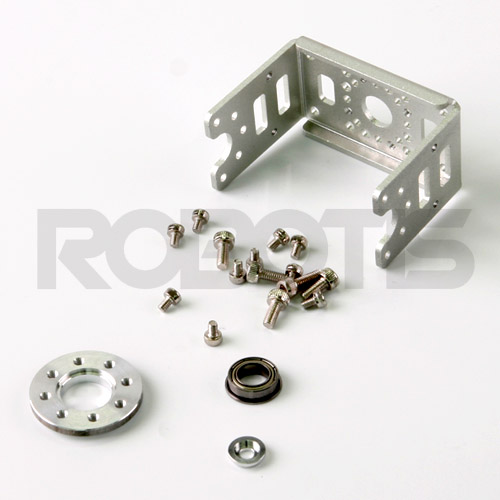
Robotis
£26.75
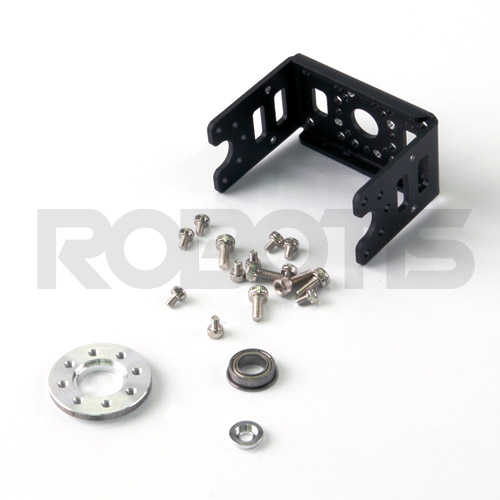
Robotis
£26.75
Robotis
£23.83
Robotis
£16.33
Robotis
£28.17
Robotis
£30.08
🍪 Mga kagustuhan sa cookie
Gumagamit kami ng cookies upang masukat ang pagganap. Patakaran sa pagkapribado