Priemerná denná cena
Sumy v mene USD
Popis
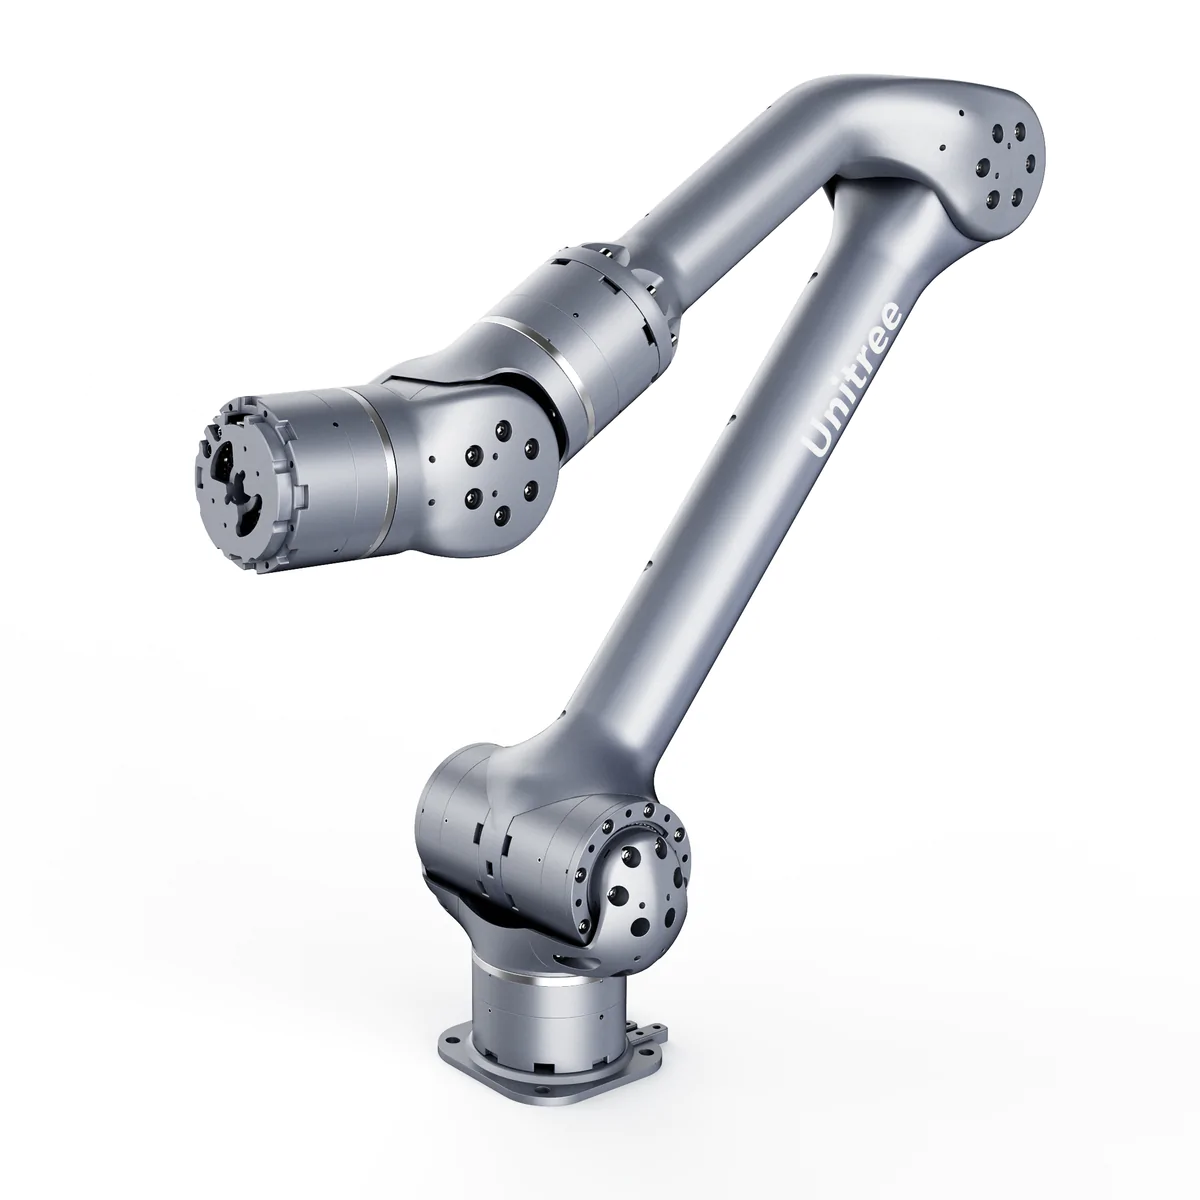
.containerimgtext { position: relative; text-align: center; color: white; } .bottom-leftimgtext { position: absolute; bottom: 8px; left: 16px; } .top-leftimgtext { position: absolute; top: 8px; left: 16px; } .top-rightimgtext { position: absolute; top: 8px; right: 16px; } .bottom-rightimgtext { position: absolute; bottom: 8px; right: 16px; } .centeredimgtext { position: absolute; top: 50%; left: 25%; transform: translate(-50%, -50%); } Compact & Lightweight Dexterous & Flexible Sufficient Payload Sufficient Accuracy Support Joint Force Control With Collision Protection Open Programming Interface and Extended Interface The manipulator control program and control interface are successively opened, and different actuators can be quickly replaced at the end of the manipulator. Application Various mobile robots, mobile robot onboard manipulator, e-commerce logistics, new consumption, daily life, etc. Synergy It can cooperate with Aliengo or B1 quadruped and other mobile robots to complete complex tasks and explore various application scenarios. Model Z1 AIR Z1 PRO DOF 6 6 Weight 4.1kg 4.3 Payload 2kg 3-5kg Reach 700mm Repeatability * ~0.1 mm Power Supply Voltage 24V Current > 20A Interface Ethernet User Operating System Ubuntu Force Feedback and Collision Detection Provide Power MAX 500w Control Interface Position + Force Control Joint Range Max Speed J1 +- 150º 180º/s J2 +- 90º 180º/s J3 +- 90º 180º/s J4 +- 160º 180º/s J5 +- 90º 180º/s J6 +- 162º 180º/s * It depends on the actual test according to the use requirements (the test standards of manipulator vary greatly, and the accuracy varies greatly under different test conditions) ** Since the reduction ratio used by each joint is relatively low, the position control stiffness of the whole machine is low. If the control mode is not optimized, there will be large position control error and shaking when the manipulator moves. FUNCTION PARAMETER Backlash ~6 arcmin Maximum Torque 33 N.m Weight 405g Size 65*50mm Reducer Harmonic Reducer Reduction Ratio 60+ Voltage 24V (Recommended) Communication Method RS 485 Encoder Resolution 15bit Bearing Industrial Grade cross roller Motor Sensing Feedback Torque, Angle, angular velocity Motor Control Command Torque, angle, angular velocity, stiffness, damping Force Control Accuracy ~0.2 N.m Control Frequency 1KHz Unitree - Z1 Robot Arm
.containerimgtext { position: relative; text-align: center; color: white; } .bottom-leftimgtext { position: absolute; bottom: 8px; left: 16px; } .top-leftimgtext { position: absolute; top: 8px; left: 16px; } .top-rightimgtext { position: absolute; top: 8px; right: 16px; } .bottom-rightimgtext { position: absolute; bottom: 8px; right: 16px; } .centeredimgtext { position: absolute; top: 50%; left: 25%; transform: translate(-50%, -50%); } Compact & Lightweight Dexterous & Flexible Sufficient Payload Sufficient Accuracy Support Joint Force Control With Collision Protection Open Programming Interface and Extended Interface The manipulator control program and control interface are successively opened, and different actuators can be quickly replaced at the end of the manipulator. Application Various mobile robots, mobile robot onboard manipulator, e-commerce logistics, new consumption, daily life, etc. Synergy It can cooperate with Aliengo or B1 quadruped and other mobile robots to complete complex tasks and explore various application scenarios. Model Z1 AIR Z1 PRO DOF 6 6 Weight 4.1kg 4.3 Payload 2kg 3-5kg Reach 700mm Repeatability * ~0.1 mm Power Supply Voltage 24V Current > 20A Interface Ethernet User Operating System Ubuntu Force Feedback and Collision Detection Provide Power MAX 500w Control Interface Position + Force Control Joint Range Max Speed J1 +- 150º 180º/s J2 +- 90º 180º/s J3 +- 90º 180º/s J4 +- 160º 180º/s J5 +- 90º 180º/s J6 +- 162º 180º/s * It depends on the actual test according to the use requirements (the test standards of manipulator vary greatly, and the accuracy varies greatly under different test conditions) ** Since the reduction ratio used by each joint is relatively low, the position control stiffness of the whole machine is low. If the control mode is not optimized, there will be large position control error and shaking when the manipulator moves. FUNCTION PARAMETER Backlash ~6 arcmin Maximum Torque 33 N.m Weight 405g Size 65*50mm Reducer Harmonic Reducer Reduction Ratio 60+ Voltage 24V (Recommended) Communication Method RS 485 Encoder Resolution 15bit Bearing Industrial Grade cross roller Motor Sensing Feedback Torque, Angle, angular velocity Motor Control Command Torque, angle, angular velocity, stiffness, damping Force Control Accuracy ~0.2 N.m Control Frequency 1KHz
História cien
Jeden údaj za deň, spriemerovaný podľa dátumu pozorovania.
Sumy v mene USD
Priemery sa počítajú za každý deň UTC zo všetkých zaznamenaných cien ponúk.

Unitree
7 563 €

Unitree
9 280 €
 Predaj
Unitree
$13 900$11 815Ušetrite 15 %

Unitree
$11 900
 Predaj
Unitree
$16 050$13 858Ušetrite 14 %

Unitree
od $11 900

Unitree
$11 900

Unitree
$13 900

Unitree
od $11 800

Unitree
15 349 €
Unitree
$16 050
Unitree
8 112 €
🍪 Predvoľby súborov cookie
Súbory cookie používame na meranie výkonu. Zásady ochrany súkromia