Priemerná denná cena
Sumy v mene USD
Popis
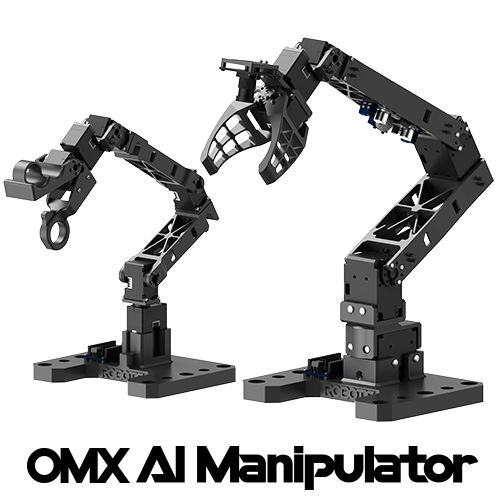
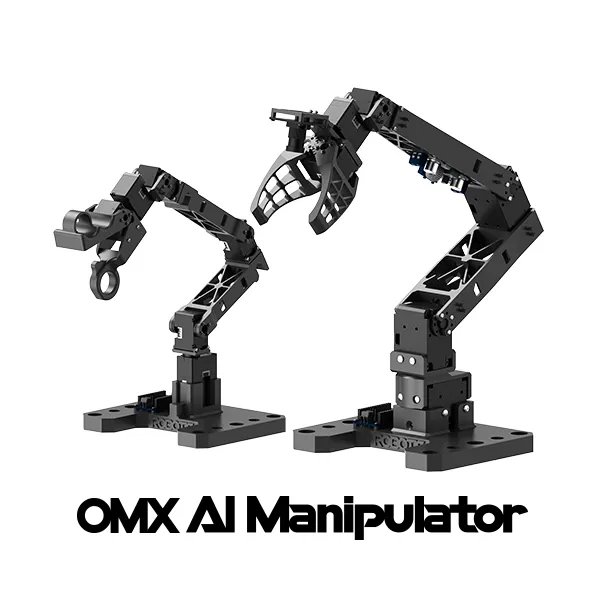
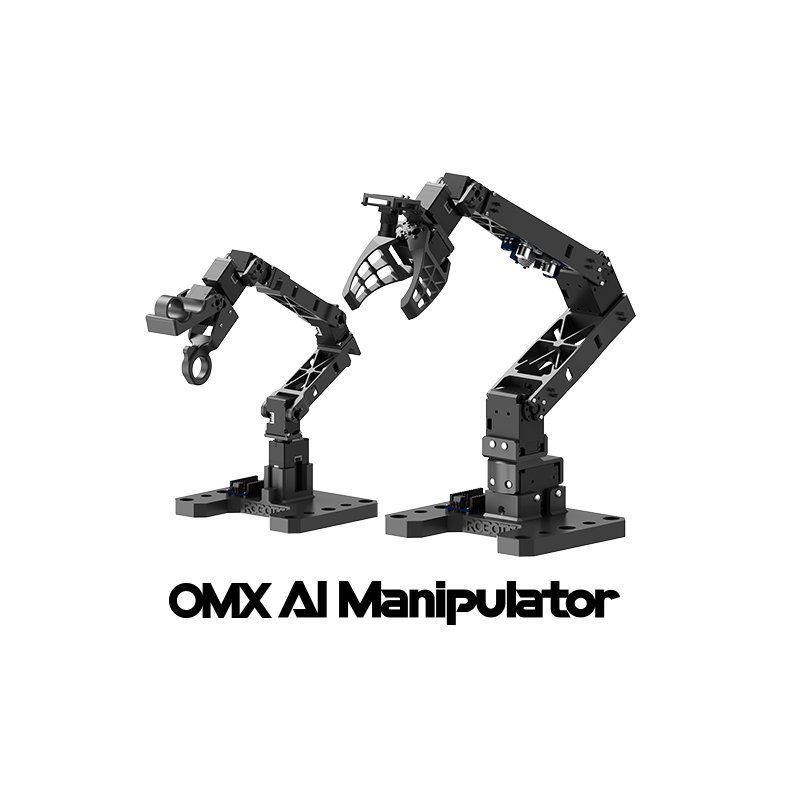
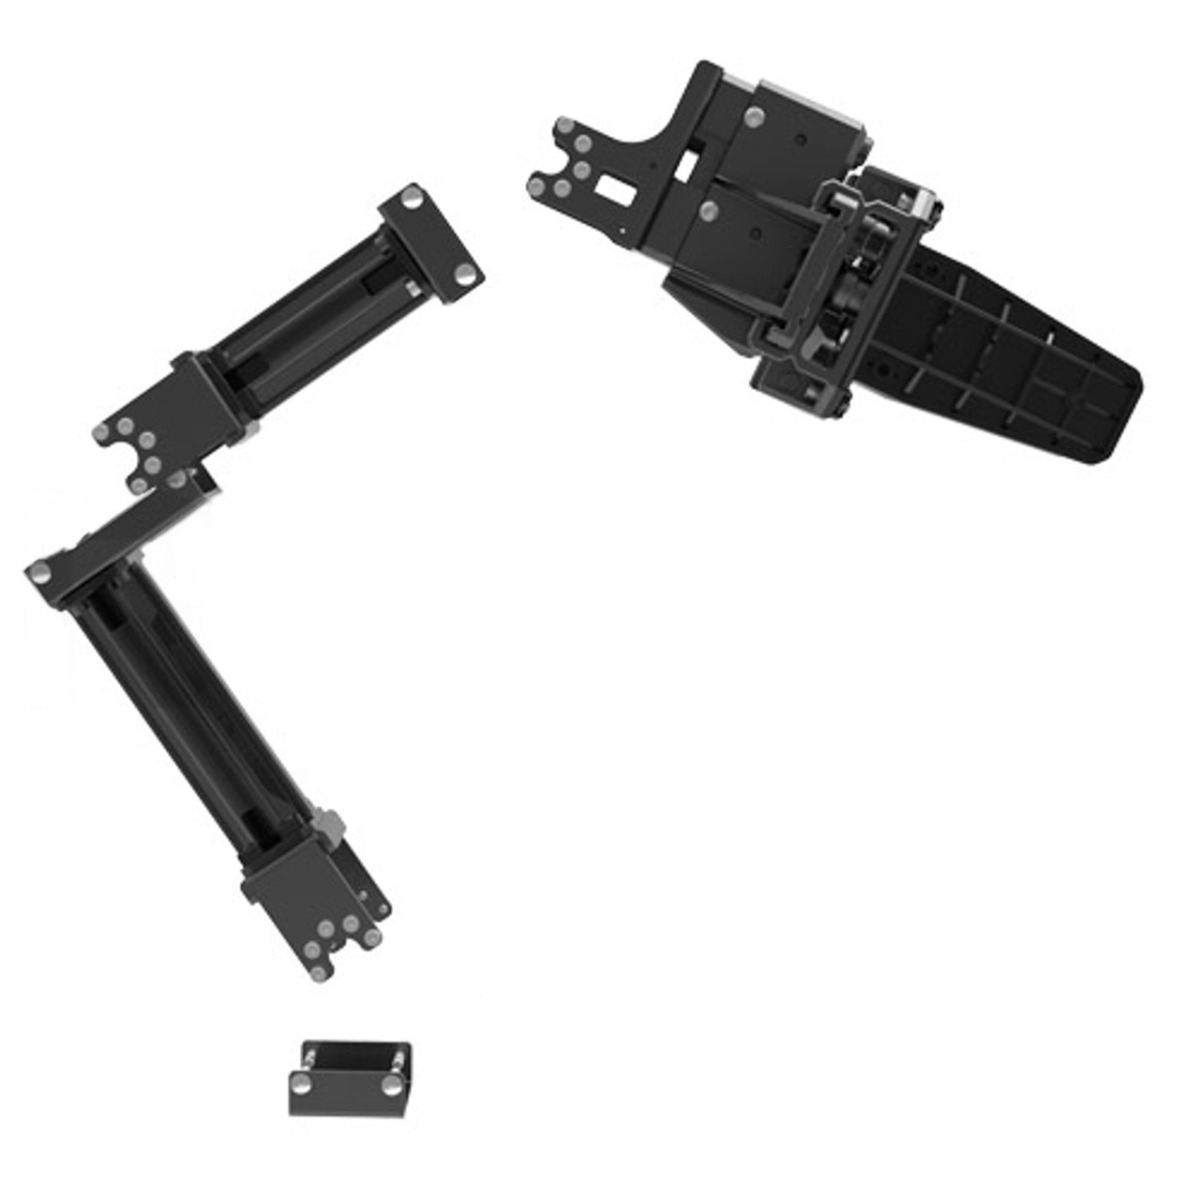
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Realizing handy integration with a wide range of robot platforms and sensors. Research Friendly Solution Affordable entry point for beginning Physical Al research. Flexible expandability based on the diverse DYNAMIXEL lineup. Reliable research platform with outstanding durability and maintenance service. Specification Items OMX-AI (Leader) OMX-AI (Follower) DOF 5 + 1 Gripper 5 + 1 Gripper Reach 335 [mm] 400 [mm] Weight 360 [g] 560 [g] Operating Voltage 5 [VDC] 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: -270° ~ +360° Joint 2,3: -120° ~ +90° Joint 4: -100° ~ +100° Joint 5: ±270° Joint 6: 0° ~ + 100° Joint 1: -270° ~ +360° Joint 2,3: -120° ~ +90° Joint 4: -100° ~ +100° Joint 5: ±270° Joint 6: 0° ~ + 100° DYNAMIXEL-Y Specification ID 1~5: XL330-M288-T ID 6: XL330-M077-T ID 11~13: XL430-W250-T ID 14~16: XL330-M288-T Host Interface USB C-Type USB C-Type Internal Communications TTL TTL Communication Baudrate 1 [Mbps] 1 [Mbps] SW ROS 2 ROS 2 Parts List Links e-Manual Assembly Guide Drawing (PDF, STEP) Drawing (STL) URDF on Github Camera Information
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Realizing handy integration with a wide range of robot platforms and sensors. Research Friendly Solution Affordable entry point for beginning Physical Al research. Flexible expandability based on the diverse DYNAMIXEL lineup. Reliable research platform with outstanding durability and maintenance service. Specification Items OMX-AI (Leader) OMX-AI (Follower) DOF 5 + 1 Gripper 5 + 1 Gripper Reach 335 [mm] 400 [mm] Weight 360 [g] 560 [g] Operating Voltage 5 [VDC] 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: -270° ~ +360° Joint 2,3: -120° ~ +90° Joint 4: -100° ~ +100° Joint 5: ±270° Joint 6: 0° ~ + 100° Joint 1: -270° ~ +360° Joint 2,3: -120° ~ +90° Joint 4: -100° ~ +100° Joint 5: ±270° Joint 6: 0° ~ + 100° DYNAMIXEL-Y Specification ID 1~5: XL330-M288-T ID 6: XL330-M077-T ID 11~13: XL430-W250-T ID 14~16: XL330-M288-T Host Interface USB C-Type USB C-Type Internal Communications TTL TTL Communication Baudrate 1 [Mbps] 1 [Mbps] SW ROS 2 ROS 2 Parts List Links e-Manual Assembly Guide Drawing (PDF, STEP) Drawing (STL) URDF on Github Camera Information
História cien
Jeden údaj za deň, spriemerovaný podľa dátumu pozorovania.
Sumy v mene USD
Priemery sa počítajú za každý deň UTC zo všetkých zaznamenaných cien ponúk.

Robotis
$343,85
Robotis
444 €
Robotis
416,95 €

Robotis
$275,89
Robotis
304,95 €
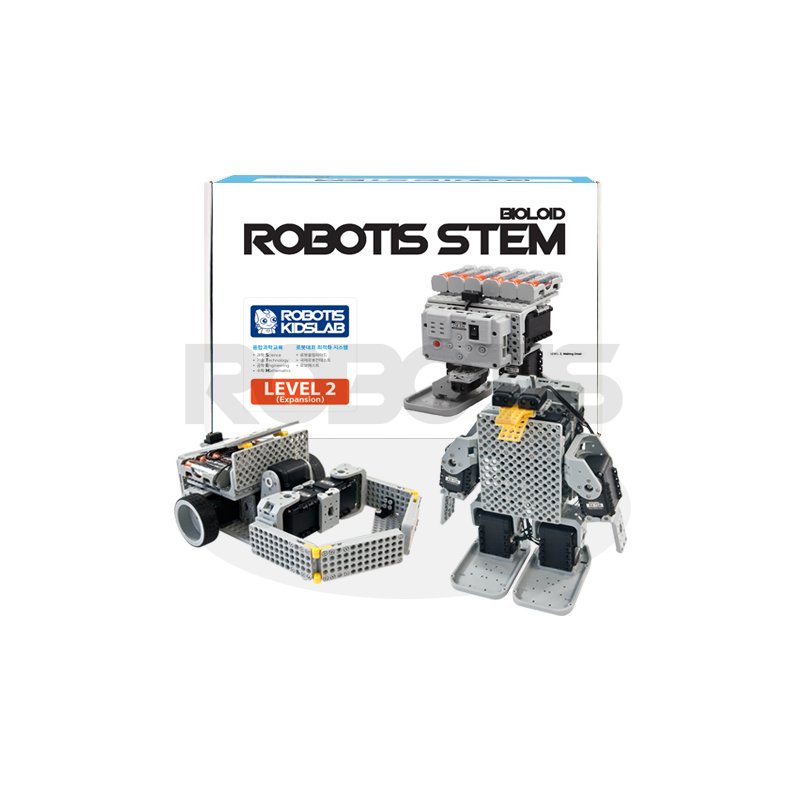
Robotis
327,95 €

Robotis
£219,17
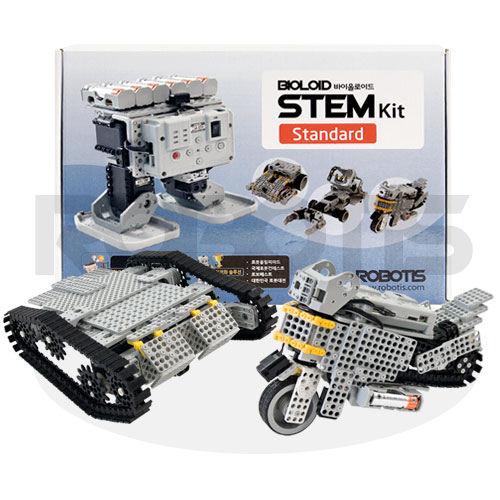
Robotis
£308,50
Robotis
£194,83
Robotis
£216,08

Robotis
$310,39

Robotis
$206,66
🍪 Predvoľby súborov cookie
Súbory cookie používame na meranie výkonu. Zásady ochrany súkromia