Prețul mediu zilnic
Sume în USD
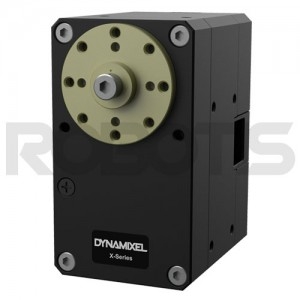
Descriere
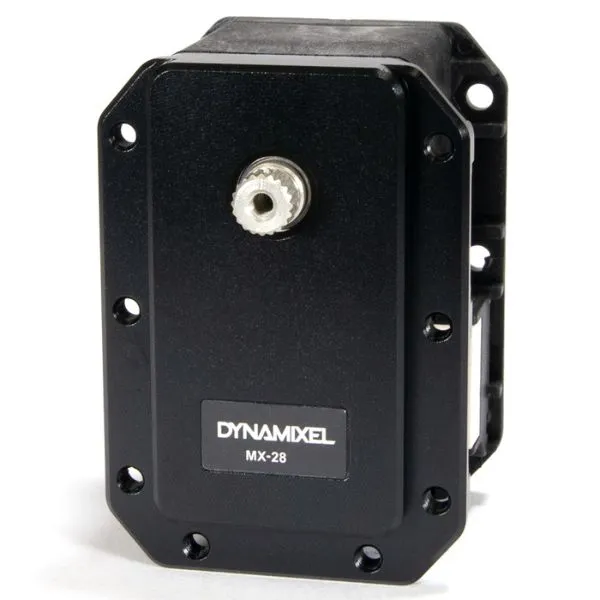
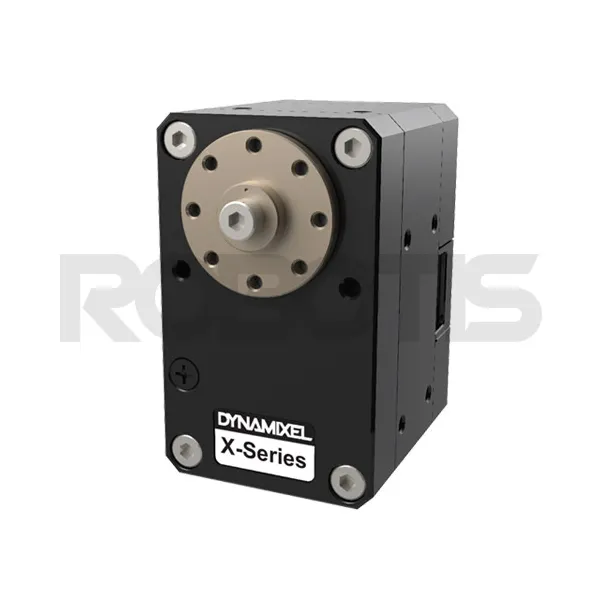
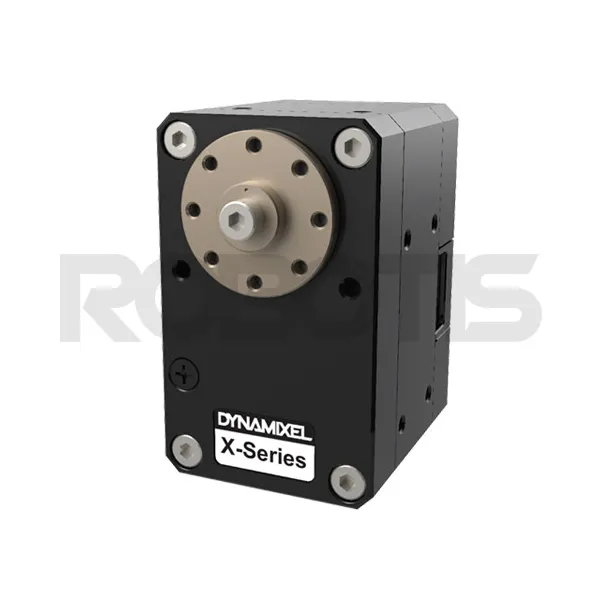
■ Basic Features • Improved Torque, Compact Design • Enhanced Durability and Expandability • Hollow Back Case Minimizes Cable Stress (3-Way Wiring) • Frames Directly Screwed onto the Case (No Nuts Needed) • Improved Aluminum Case Heat Sink • 6 Operating Modes • Current-Based Torque Control (4096 steps, 2.69mA/step) • Profile Control for Smooth Motion Planning • Trajectory Data and Moving Status (In-Position, Following Error, etc.) • Energy Efficient (Standby Current Reduced from 100mA to 40mA) • 28.4% reduced volume compared to the MX-106 ■ Package Contents Description Quantity DYNAMIXEL XM540-W270-R 1 HORN HN13-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 3P Sync Cable 160MM 1 BOLT/NUT Wrench Bolt (WB M2.5*5) 16 Wrench Bolt (WB M2.5*4) 10 Wrench Bolt (WB M3*8) 1 ETC Spacer Ring 8 ■ H/W Specifications Model Name XM540-W270-R Weight (g) 165 Dimensions (mm) 33.5 x 58.5 x 44 Gear Ratio 272.5 : 1 Operation Voltage (V) 11.1 12.0 14.8 Stall Torque (N.m) 10.0 10.6 12.9 Stall Current (A) 4.2 4.4 5.5 No Load Speed (RPM) 28 30 37 MCU ST CORTEX-M3 (STM32F103C8 @ 72MHZ,32BIT) Position Sensor Contactless absolute encoder (12BIT,360°) by AMS Motor Coreless Resolution 0.088° x 4,096 steps Operating Range Current Control Mode : Endless turnVelocity Control Mode : Endless turnPosition Control Mode : 360[deg]Extended Control Mode : ±256[rev] Current-based Position Control Mode : ±256[rev] PWM Control Mode : Endless turn Input Voltage (V) 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Communication Signal Digital Packet Protocol RS485 Asynchronous Serial Communication (8bit,1stop, No Parity Link (physical) RS485 Multi Drop Bus ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal Body(Front, Middle) Engineering Plastic Body(Back) Gear : Full Metal Standby current (mA) 40 ■ Default Settings ID : 1 Baud Rate : 57600bps *Please make necessary modifications to ID, baud rate, etc. after purchase. ■ Hyperlinks Frame, Horn, Bearing Compatible Chart : Click Here Controller Compatibility Chart : Click Here Download Drawing : Click Here Dynamixel SDK : Click Here OpenCM IDE : Click Here Software RoboPlus (R+) : Click Here Link to e-Manual : Click Here ■ Caution The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication. For more information, please see the [DYNAMIXEL Connector Standard] page on the e-Manual. To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X3P (by length) U2D2 OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable -X4P 180mm (Convertible) JST-4P RS-485 USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X4P (by length) U2D2 The DYNAMIXEL X-Series is a new line-up of high performance networked actuators. Improved Torque, Compact Design, Enhanced Durability and Expandability.
■ Basic Features • Improved Torque, Compact Design • Enhanced Durability and Expandability • Hollow Back Case Minimizes Cable Stress (3-Way Wiring) • Frames Directly Screwed onto the Case (No Nuts Needed) • Improved Aluminum Case Heat Sink • 6 Operating Modes • Current-Based Torque Control (4096 steps, 2.69mA/step) • Profile Control for Smooth Motion Planning • Trajectory Data and Moving Status (In-Position, Following Error, etc.) • Energy Efficient (Standby Current Reduced from 100mA to 40mA) • 28.4% reduced volume compared to the MX-106 ■ Package Contents Description Quantity DYNAMIXEL XM540-W270-R 1 HORN HN13-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 3P Sync Cable 160MM 1 BOLT/NUT Wrench Bolt (WB M2.5*5) 16 Wrench Bolt (WB M2.5*4) 10 Wrench Bolt (WB M3*8) 1 ETC Spacer Ring 8 ■ H/W Specifications Model Name XM540-W270-R Weight (g) 165 Dimensions (mm) 33.5 x 58.5 x 44 Gear Ratio 272.5 : 1 Operation Voltage (V) 11.1 12.0 14.8 Stall Torque (N.m) 10.0 10.6 12.9 Stall Current (A) 4.2 4.4 5.5 No Load Speed (RPM) 28 30 37 MCU ST CORTEX-M3 (STM32F103C8 @ 72MHZ,32BIT) Position Sensor Contactless absolute encoder (12BIT,360°) by AMS Motor Coreless Resolution 0.088° x 4,096 steps Operating Range Current Control Mode : Endless turnVelocity Control Mode : Endless turnPosition Control Mode : 360[deg]Extended Control Mode : ±256[rev] Current-based Position Control Mode : ±256[rev] PWM Control Mode : Endless turn Input Voltage (V) 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Communication Signal Digital Packet Protocol RS485 Asynchronous Serial Communication (8bit,1stop, No Parity Link (physical) RS485 Multi Drop Bus ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal Body(Front, Middle) Engineering Plastic Body(Back) Gear : Full Metal Standby current (mA) 40 ■ Default Settings ID : 1 Baud Rate : 57600bps *Please make necessary modifications to ID, baud rate, etc. after purchase. ■ Hyperlinks Frame, Horn, Bearing Compatible Chart : Click Here Controller Compatibility Chart : Click Here Download Drawing : Click Here Dynamixel SDK : Click Here OpenCM IDE : Click Here Software RoboPlus (R+) : Click Here Link to e-Manual : Click Here ■ Caution The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication. For more information, please see the [DYNAMIXEL Connector Standard] page on the e-Manual. To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X3P (by length) U2D2 OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable -X4P 180mm (Convertible) JST-4P RS-485 USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X4P (by length) U2D2
Istoricul prețurilor
Un punct de date pentru fiecare zi, calculat ca medie după data observației.
Sume în USD
Mediile sunt calculate pentru fiecare zi UTC, pe baza tuturor prețurilor ofertelor înregistrate.
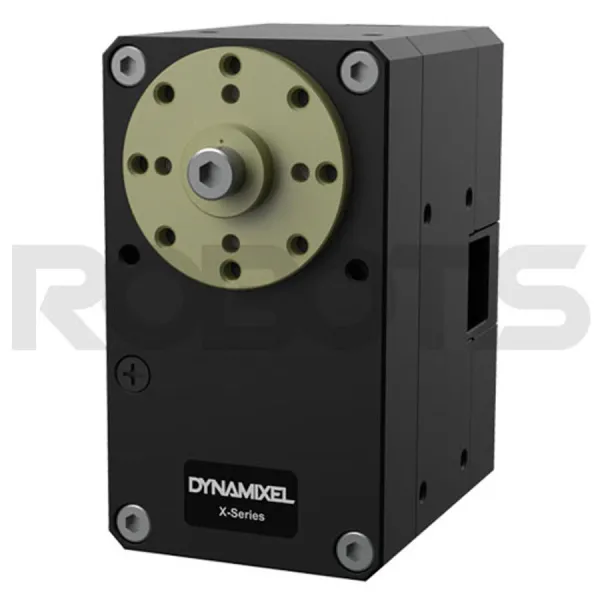
Robotis
489,96 €

Robotis
$494,39
Robotis
319,15 €
Robotis
300,26 €
Robotis
331,43 €
Robotis
329,40 €
Robotis
340,74 €
Robotis
325,56 €
Robotis
327,54 €
Robotis
317,40 €
Robotis
317,40 €
Robotis
304,20 €
🍪 Preferințe pentru cookie-uri
Folosim cookie-uri pentru a măsura performanța. Politica de confidențialitate