

-20%

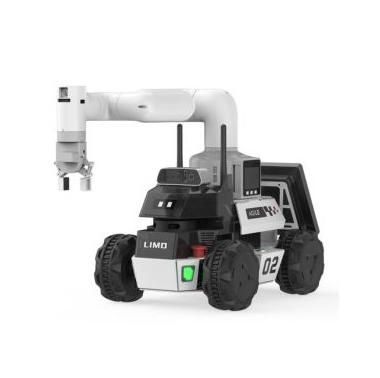
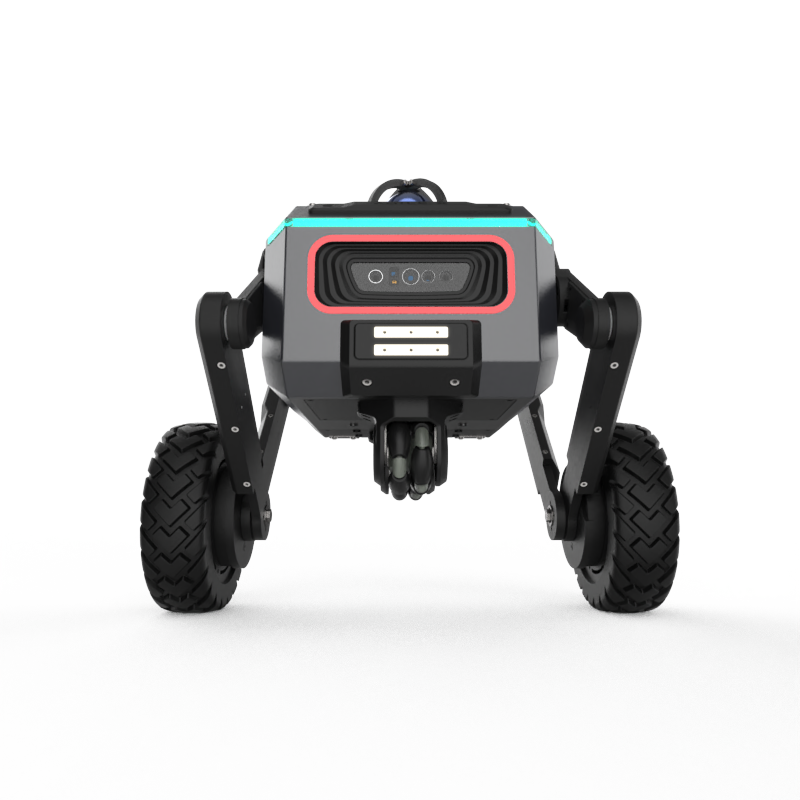
Der LIMO Pro von AgileX Robotics ist eine kompakte mobile Robotikplattform für Forschung, Lehre und die Entwicklung von Anwendungen in den Bereichen autonome Navigation, SLAM, Computer Vision und eingebettete KI.
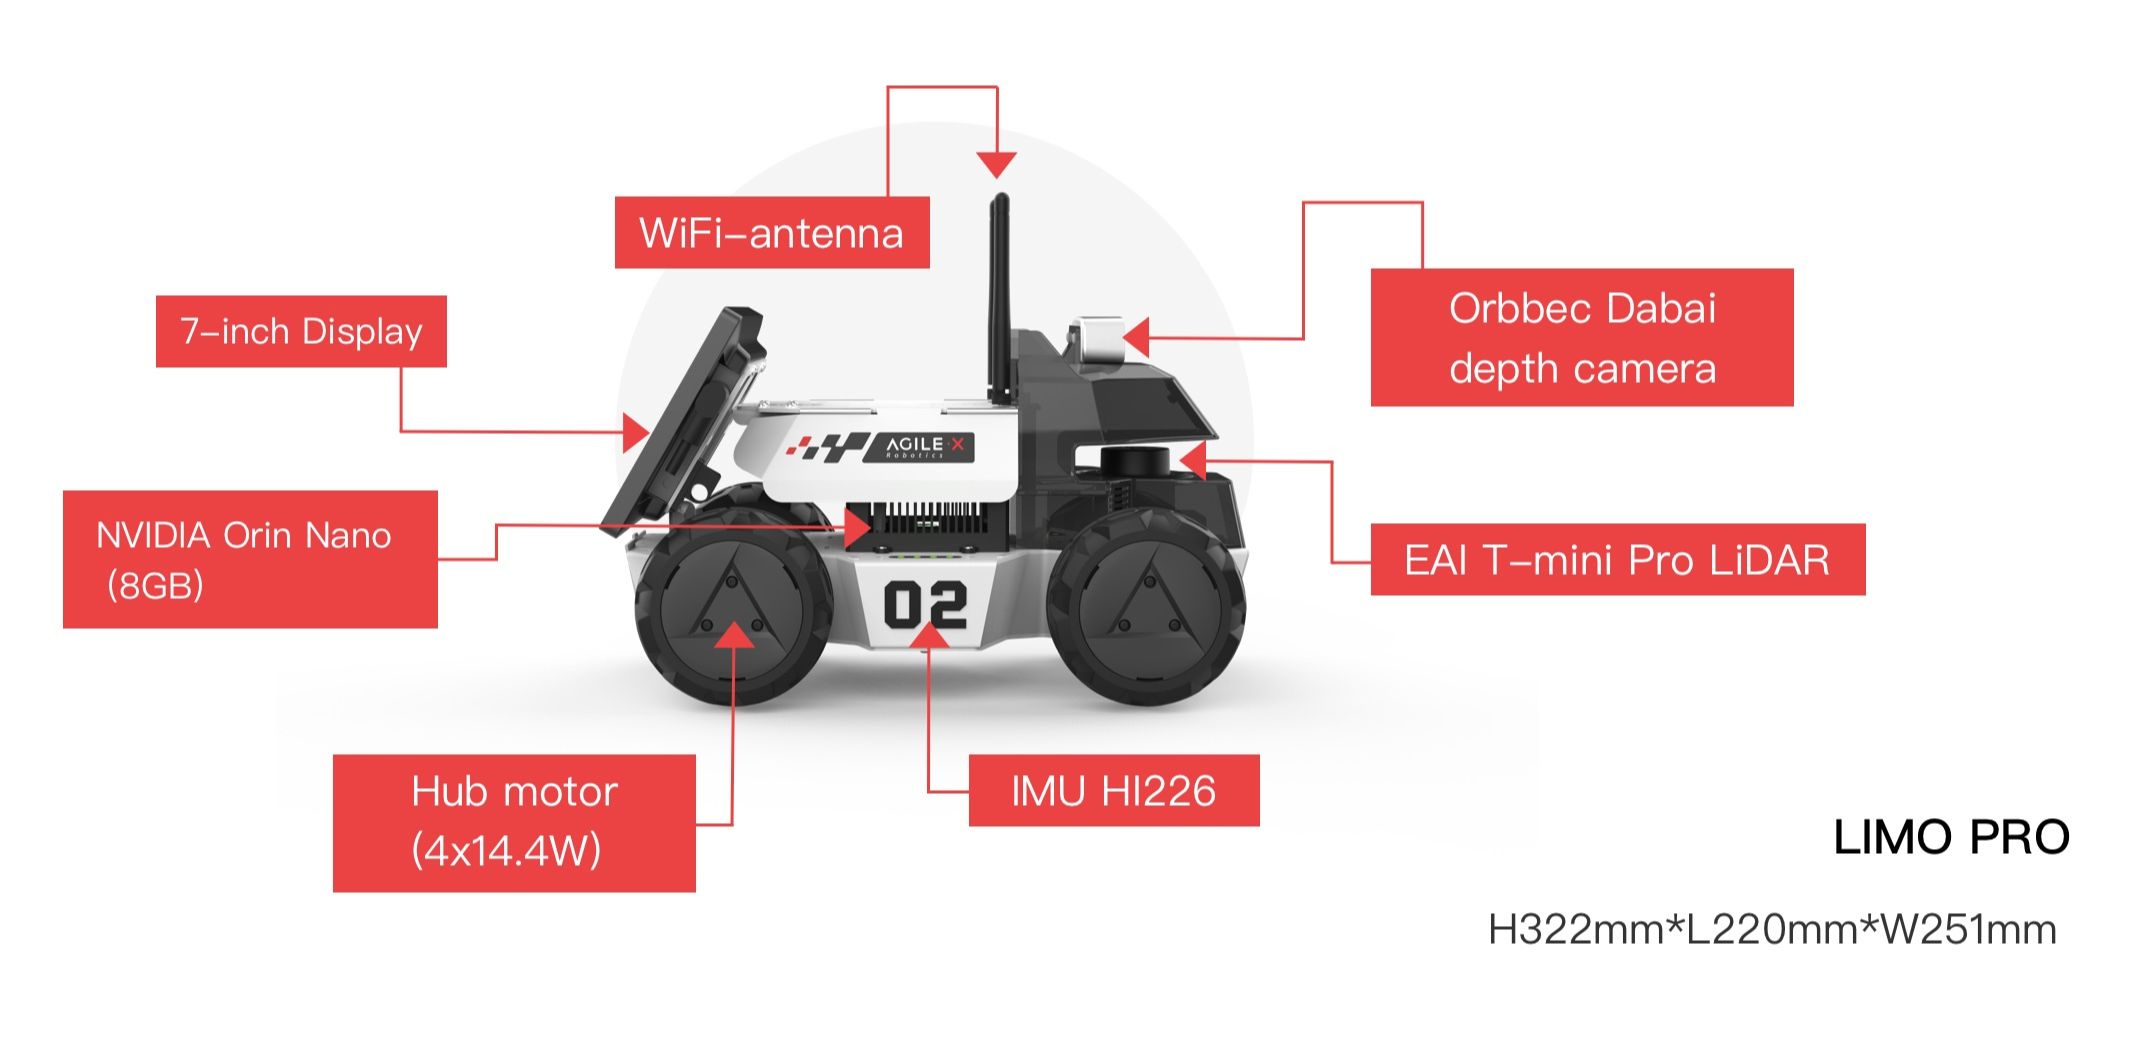

| Dimensions | 322 × 220 × 251 mm |
| Weight | 4.8 kg |
| Payload | 4 kg |
| Runtime | 2.5 h |
| Standby time | 4 h |
| Wheelbase | 200 mm |
| Track width | 175 mm |
| Minimum ground clearance | 24 mm |
| Drive system | 4 wheel motors × 14.4 W |
| Maximum speed | 1 m/s |
| Minimum turning radius in Ackermann mode | 0.4 m |
| Locomotion modes | 4-wheel differential drive, Ackermann, tracks, Mecanum |
| Operating temperature | -10 °C to +40 °C |
| Onboard computer | NVIDIA Jetson Orin Nano |
| CPU | 6-core Arm Cortex-A78AE |
| GPU | 1024 CUDA cores |
| LiDAR | EAI T-mini Pro |
| Depth camera | Orbbec DaBai |
| IMU | HI226 |
| Battery | 10 Ah / 12 V |
| Connectivity | Wi-Fi, Bluetooth |
| Interfaces | USB Type-C, USB 2.0, HDMI |
| Rear display | 7-inch IPS touchscreen, 1024 × 600 |
| Front display | 1.54-inch OLED, 128 × 64 |
| ROS | ROS 2 Humble compatible |
| ROS 2 environment | Ubuntu 22.04 + ROS 2 Humble via AgileX limo_ros2 packages |
| Programming languages | Python, C++ |
| Simulation | Gazebo |
Istoricul prețurilor
Un punct de date pentru fiecare zi, calculat ca medie după data observației.
Sume în USD
Mediile sunt calculate pentru fiecare zi UTC, pe baza tuturor prețurilor ofertelor înregistrate.

AgileX
£1.907,08
AgileX
2.040 €
AgileX
2.400 €
AgileX
£3.552,75
AgileX
£1.868,13

AgileX
£1.480
AgileX
£3.947,50

AgileX
$3.990

AgileX
$3.990
AgileX
£4.927,36
AgileX
£4.089,75

AgileX
$4.995
🍪 Preferințe pentru cookie-uri
Folosim cookie-uri pentru a măsura performanța. Politica de confidențialitate