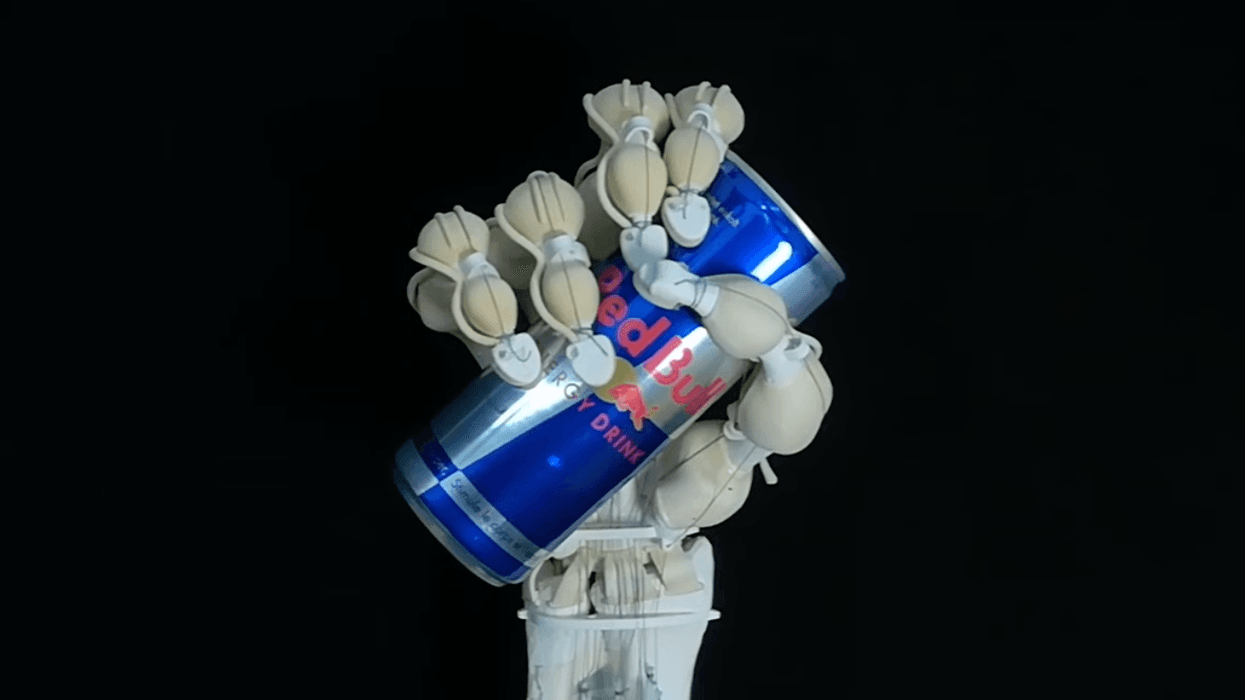
Researchers at ETH Zurich's Soft Robotics Lab have 3D-printed a biomimetic hand in a single-pass process, combining a rigid skeleton, soft joint capsules, artificial tendons, and embedded touch sensors. Dexterous manipulation remains the single biggest deployment bottleneck for humanoid robots — and this approach directly addresses it by replicating the mechanical architecture that makes human hands so capable.
Table of Contents
- Why dexterous manipulation is humanoid robotics' hardest problem
- How the ETH Zurich biomimetic hand actually works
- What else is moving in robotics research this week
- What this means for humanoid robot buyers
- Frequently Asked Questions
Why Dexterous Manipulation Is Humanoid Robotics' Hardest Problem
Ask any humanoid robot engineer where the deployment gap is, and the answer is almost always the same: hands. Locomotion is largely solved — Boston Dynamics proved that more than a decade ago with platforms like LittleDog. But the moment a humanoid needs to pick up an irregular object, handle delicate components, or apply calibrated grip force, performance collapses.
The core issue is mechanical. Most commercial robot hands use rigid actuators — servo motors or pneumatic cylinders — that trade biological subtlety for engineering simplicity. Human hands achieve their extraordinary range through a layered system: rigid bone structure for force transmission, compliant tendons for smooth motion, joint capsules that passively absorb shock, and distributed tactile sensing that closes the control loop in real time. Replicating even two of those four properties in a single manufactured system has historically required expensive, multi-stage assembly processes.
That gap matters commercially. Analysts tracking the humanoid sector consistently identify manipulation capability — specifically, the ability to handle human-scale objects in unstructured environments — as the gating factor for warehouse, logistics, and light manufacturing deployment. Until hands improve, humanoids remain expensive mobile cameras.
How the ETH Zurich Biomimetic Hand Actually Works
The Soft Robotics Lab (SRL) at ETH Zurich has published research describing a robot hand fabricated in a single continuous 3D-print run that integrates four functionally distinct material systems: a rigid skeletal structure, compliant joint capsules (analogous to the fibrous tissue surrounding human joints), routed artificial tendons for actuation, and printed tactile sensors embedded directly into the fingertip surfaces.
According to IEEE Spectrum, the full design is detailed in a peer-reviewed paper on IEEE Xplore, with the SRL framing the work as advancing understanding of "natural kinematic structures" through functional replication.
The single-print approach is the genuinely significant technical contribution here. Multi-material 3D printing (depositing different polymer types within one print job) has existed for years, but combining soft and rigid domains with embedded sensor channels in a single uninterrupted process, at the geometric complexity of a human hand, is a meaningful step forward. It eliminates the assembly tolerances that typically degrade performance in hybrid soft-rigid systems — every joint capsule, every tendon routing path, and every sensor interface is geometrically exact relative to the skeleton because they were all printed together.
The Tendon-Actuated Architecture
Tendon-driven actuation — where motors or artificial muscles pull cables routed through the hand rather than mounting actuators directly at each joint — allows the finger joints themselves to remain slim and lightweight. The tradeoff is control complexity: tendon routing introduces nonlinear force transmission, and the compliance of the artificial tendons means the mapping between actuator input and fingertip force isn't trivial to model.
The analogy to a marionette is useful here. Pull a string, and the puppet's hand closes — but the exact position depends on the string tension, the routing geometry, and how stiff the "joints" are. The analogy breaks down because a marionette has no feedback; the ETH hand's embedded touch sensors close that loop, giving the controller real-time data on contact force and fingertip deformation.
| Feature | Traditional Robot Hand | ETH Biomimetic Hand |
|---|---|---|
| Actuation | Direct-drive servos at joint | Tendon-routed artificial muscles |
| Joint compliance | Rigid / fixed | Soft capsules (passive compliance) |
| Tactile sensing | External or none | Printed sensors, embedded in-situ |
| Manufacturing | Multi-stage assembly | Single continuous 3D-print run |
| Biological fidelity | Low | High (skeleton + tendon + capsule + sensor) |
What Else Is Moving in Robotics Research This Week
Beyond the ETH hand, the broader robotics research community produced several noteworthy developments this week.
NIST on humanoid performance standards: Kamel Saidi, robotics program manager at the National Institute of Standards and Technology, spoke at the Humanoids Summit on how formalised performance benchmarks could accelerate humanoid adoption. This is an underappreciated bottleneck — buyers can't commit capital to humanoid fleets without standardised metrics for reliability, manipulation accuracy, and safety. NIST's involvement signals the ecosystem is maturing past the demo phase.
Agility Robotics released a retrospective video signalling upcoming announcements — notable given the company's position as one of the few humanoid vendors with documented commercial deployments (Amazon warehouses).
DRAGON Lab at the University of Tokyo demonstrated two research directions simultaneously: a trajectory planning method for floating-base articulated robots navigating cluttered environments, and a biomimetic robotic fish — the lab's first underwater platform. The fish is adjacent to the humanoid narrative, but the trajectory planning work is directly relevant to mobile manipulation in unstructured spaces.
OmniPlanner from NTNU showed a unified path planning system for aerial, ground, and underwater robots, validated in environments including underground mines, ballast water tanks, and submarine bunkers. Multi-domain autonomy at that reliability level matters for inspection robotics well beyond the lab.
The ARISE project — a collaboration between FZI, ETH Zurich, University of Zurich, University of Bern, and University of Basel — demonstrated cooperative autonomous multi-robot teams under outdoor conditions, targeting lunar mission applications. The sensor fusion and coordination algorithms developed for lunar surface operations have direct transfer value to terrestrial multi-robot warehouse deployments.
Historical footnote: A newly identified 1897 Georges Méliès film, Gugusse and the Automaton, has been confirmed as the earliest known cinematic depiction of a humanoid robot. The Library of Congress preserved the clip; Gizmodo surfaced it. It's a useful reminder that the humanoid dream predates the semiconductor by half a century.
What This Means for Humanoid Robot Buyers
For anyone evaluating humanoid platforms today, the ETH Zurich research represents a research-to-product pipeline to watch over the next two to four years rather than a purchasing decision for this quarter. Current commercial humanoids — including platforms from Agility, Unitree, and Fourier Intelligence — ship with hands that are functional but limited, typically offering 4-6 degrees of freedom versus the human hand's 21-25 degrees of freedom.
The single-print biomimetic approach, if it transitions from lab prototype to manufacturable component, could change the cost calculus significantly. Multi-stage hand assembly is expensive; reducing it to a print-and-deploy process could bring dexterous end-effector costs down by an order of magnitude over current custom fabrication routes.
Practical guidance for buyers right now:
- If your use case involves repetitive structured grasping (pick-and-place with defined objects), current commercial hands are adequate — evaluate platforms on payload, cycle time, and software stack
- If your use case requires dexterous manipulation of irregular objects, you're currently looking at custom end-effector integration or waiting 18-36 months for the next hardware generation
- Cobot platforms with interchangeable end-effectors remain the most flexible near-term option for manipulation-heavy workflows
You can explore current options for used cobots for sale or browse humanoid robots on Robot Overflow to compare what's commercially available today against the research trajectory.