Päivän keskihinta
Summat valuutassa USD


Upper-Body Dual-Arm Humanoid Robot with Inspire DFQ Five-Finger Dexterous Hands & Dual Intel Core i5/i7 Compute. 31 DOF, 6-DOF hands with 12 joints, ±0.20 mm repeatability, 600 mm reach, binocular vision & full-stack open SDK.

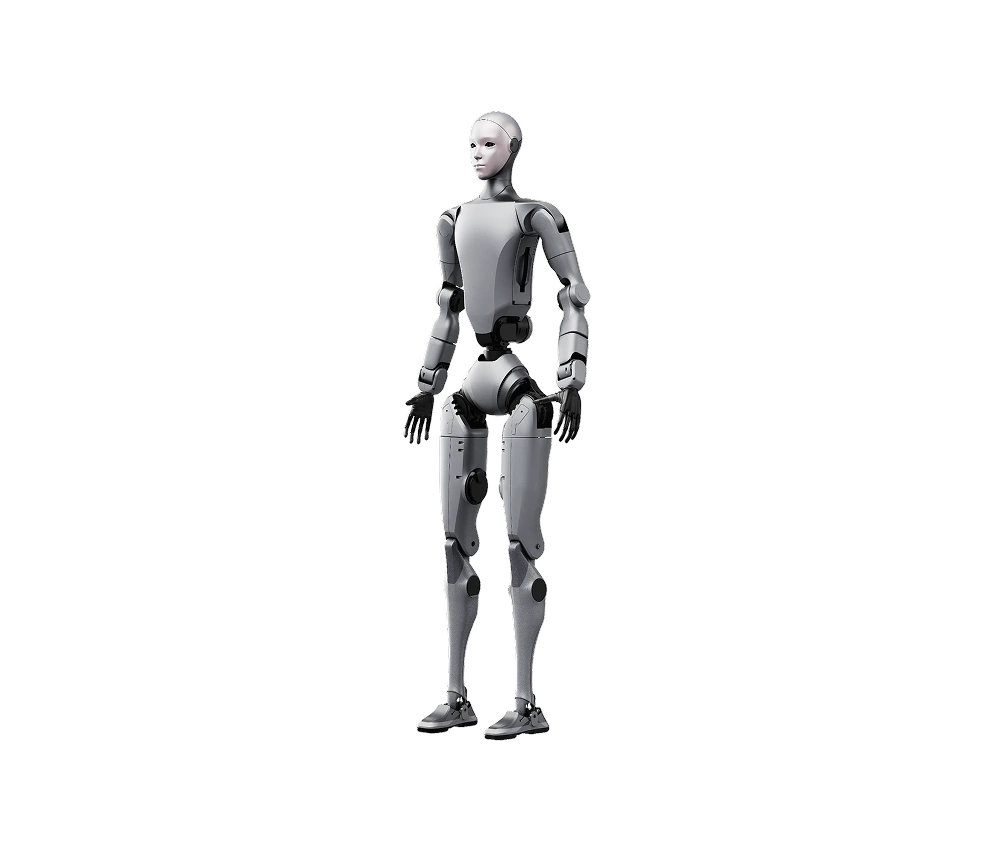
H2-A Standard H — upper-body humanoid with Inspire DFQ five-finger dexterous hands, 6 DOF + 12 joints per hand
The H2-A Standard H introduces the Inspire DFQ five-finger dexterous hand — a precision-engineered end effector with 6 DOF per hand and 12 joints for fluid, biomimetic finger movement. The DFQ achieves ±0.20 mm repeatability with a thumb lateral rotation range >65° and impressive actuation speeds: thumb lateral swing 235°/s, thumb bending 150°/s, four-finger bending 570°/s. Grip force is finely tuned with 6 N max on the thumb and 4 N max on the four fingers, resolved to 0.50 N for delicate force-controlled manipulation. The integrated wrist RGB camera provides close-up visual feedback for grasp verification. At 31 total DOF, Standard H delivers high-speed, precision five-finger manipulation for research labs and automation prototyping.
The H2-A Standard H is engineered around two 7-DOF high-performance arms, each driven by low-inertia inner-rotor PMSM motors with crossed-roller and double-row ball bearings. With 600 mm reach and a ~7 kg rated payload per arm (up to ~15 kg peak), it handles precise assembly, heavy pick-and-place, and industrial manipulation research with human-like fluidity. The extra two degrees of freedom per arm provide kinematic redundancy — the arm can maintain end-effector pose while reconfiguring its elbow to avoid obstacles, reach around corners, or optimize for natural motion. Dual encoders on every joint deliver closed-loop precision down to ±0.1 mm.

Multimodal Perception & Natural Interaction: Integrating binocular vision with natural language interaction, H2-A enables intuitive and natural human–robot collaboration.
The Inspire DFQ is a 6-DOF five-finger dexterous hand engineered for high-speed, precision manipulation research. With 12 joints per hand, it delivers fluid biomimetic finger movement with exceptional dynamic performance. The thumb features a lateral rotation range >65° with swing speed of 235°/s and bending speed of 150°/s, while the four fingers achieve 570°/s bending speed — enabling rapid grasp transitions and dynamic in-hand manipulation. Force-controlled precision is delivered through 6 N max grip force on the thumb and 4 N on the four fingers, with 0.50 N resolution and ±0.20 mm repeatability for delicate, repeatable tasks. The integrated wrist RGB camera provides close-up visual feedback for grasp verification and object inspection.
The 3-DOF waist joint provides full torso articulation — yaw, pitch, and roll — dramatically expanding the robot's reachable workspace without moving the base. In a seated or standing deployment, the waist allows the robot to turn and manipulate objects on either side, hand objects from one hand to the other across the body, bend forward for floor-level picking, and orient toward humans or workstations. Combined with 7-DOF arms and Inspire DFQ five-finger dexterous hands, the H2-A achieves human-like reach envelopes that cover a full sphere of workspace — ideal for bimanual manipulation, in-hand reorientation, and human-robot interaction research.
The H2-A Standard H ships with a built-in dual-compute architecture: PC1 runs an Intel Core i5 for real-time platform functionality and motion control, while PC2 provides an Intel Core i7 dedicated to user development. This separation ensures deterministic robot behavior while giving researchers full freedom to experiment. Optional expansion slots (PC3 for NVIDIA Jetson Thor, PC4 for Intel i7 or Jetson Orin NX) future-proof the platform as your AI ambitions grow.
A wide-angle humanoid-style binocular camera head delivers a broad field of view for spatial awareness. Paired with an 8-core high-performance CPU + 10 TOPS NPU in the head module, plus the dual Intel compute in the body, it runs visual perception, object detection, and gesture recognition locally — no cloud required. The Inspire DFQ wrist cameras add close-up visual feedback for precision grasping and finger tracking.
Array beamforming microphones and high-power speakers enable clear voice capture and synthesis in noisy labs or industrial floors. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control.
At just 780 × 444 × 200 mm and approximately 34.4 kg (with battery), the H2-A Standard H fits on a reinforced lab bench or industrial workstation. The compact footprint leaves room for objects, tools, and sensors around the robot. Power via the included upper-body Li-ion battery for ~8 hours of untethered operation, or connect the external power supply for 24/7 continuous use.

Comprehensive SDKs and APIs, together with a mature manipulation and perception software stack, enable developers to focus on application innovation while reducing development cycles from months to weeks.
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the H2-A Standard H a clean slate for reinforcement learning, teleoperation research, and embodied AI. The dual Intel compute handles model training and inference without external hardware.
Standard H delivers high-speed precision manipulation. Upgrade as your research evolves:
| Model | Unitree H2-A Standard H (Upper Body) |
| Dimensions | 780 × 444 × 200 mm (H × W × D) |
| Weight (with Battery) | ~34.4 kg |
| Total DOF (without hands) | 19 (Arm 7×2, Waist 3, Head 2) |
| Total DOF (with hands) | 31 (Arm 7×2, Waist 3, Head 2, Hand 6×2) |
| Arm Reach | 600 mm (forearm + upper arm) |
| Joint Bearings | Crossed-roller + double-row ball bearings |
| Joint Motors | Low-inertia, high-speed, inner-rotor permanent magnet synchronous motors |
| Max Arm Payload | Peak: ~15 kg; Rated: ~7 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | BrainCo Inspire DFQ Five-Finger Dexterous Hands (both arms, pre-installed) with wrist RGB camera |
| Hand Active DOF | 6 per hand (12 joints total) |
| Hand Transmission | 12 micro force-controlled compound joints + 4 micro force-controlled gear joints |
| Thumb Lateral Rotation | >65° |
| Repeatability | ±0.20 mm |
| Max Grip Force (Thumb) | 6 N |
| Max Grip Force (4 Fingers) | 4 N |
| Grip Force Resolution | 0.50 N |
| Thumb Lateral Swing Speed | 235°/s |
| Thumb Bending Speed | 150°/s |
| Four-Finger Bending Speed | 570°/s |
| Perception Feedback | Joint mode, position, velocity, torque, temperature, voltage/current, IMU data |
| Wrist Cameras | Included — RGB 1920×1080, FOV D:130°/H:120°/V:81° |
| Tactile Sensing | Not included — proprioception via joint encoders (upgrade to RH56E2-T1 Tactile / Standard I available) |
| Waist Joint | 3-DOF (Yaw, Pitch, Roll) |
| Head Joint | 2-DOF, Yaw: ±115°, Pitch: ±36° |
| Vision | Binocular camera — wide-angle humanoid-style dual-camera system |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute (PC1) | Intel Core i5 (platform functionality) |
| Body Compute (PC2) | Intel Core i7 (user development) |
| Optional Compute (PC3) | NVIDIA Jetson Thor (empty slot, add-on) |
| Optional Compute (PC4) | Intel Core i7 or NVIDIA Jetson Orin NX (empty slot, add-on) |
| Audio | Array microphone + high-power speaker |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | Upper-body Li-ion battery (~8 h) + external DC PSU (24/7) |
| Cabling | Hollow + internal wiring |
| Joint Encoders | Dual + single encoders per joint |
| Cooling | Localized air cooling |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/audio/vision/lighting |
| Controllers | Handheld remote control included |
| Warranty | 12 months on the entire unit |
Standard A is the entry point. Every configuration shares the same H2-A upper-body base — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | DOF (Total) | Features |
|---|---|---|---|
| Standard A | Dex1-1 Advanced (RGB) | 21 | Entry-level parallel grippers with wrist camera, 7-DOF arms, stereo vision |
| Standard B | Dex3-1 (RGB) | 33 | 3-finger dexterous hand with wrist RGB camera |
| Standard C | Dex3-1 Tactile (RGB) | 33 | 3-finger hand with 33 tactile sensors + wrist RGB camera |
| Standard D | Dex5-1 (RGB) | 51 | 5-finger 16-DOF hand with wrist RGB camera |
| Standard E | Dex5-1P Tactile (RGB) | 51 | 5-finger hand with 94 pressure sensors + wrist RGB camera |
| Standard F | Revo 2 Basic (RGB) | 31 | 5-finger 6-DOF BrainCo hand with wrist RGB camera |
| Standard G | Revo 2 Tactile (RGB) | 31 | 5-finger hand with pressure/friction/direction/proximity sensing + wrist RGB camera |
| Standard H | RH56DFQ (RGB) | 31 | Inspire Robots 5-finger 6-DOF hand with wrist RGB camera |
| Standard I | RH56E2-T1 Tactile (RGB) | 31 | Inspire Robots 5-finger hand with 17 tactile sensors + wrist RGB camera |
| Standard J | Revo 3 U21 (RGB) | 61 | BrainCo 21-DOF hand with wrist RGB camera |
| Standard K | Revo 3 U21T Tactile (RGB) | 61 | BrainCo 21-DOF hand with full-palm tactile + wrist RGB camera |
| Standard L | Revo 3 U21VT Visuo-Tactile (RGB) | 61 | BrainCo 21-DOF hand with visuo-tactile sensing + wrist RGB camera |
| Standard M | WUJI Hand 2 Tactile (RGB) | 59 | WUJI 20-DOF hand with tactile + wrist RGB camera, 1000 Hz control |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional compute modules and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.
Upper-Body Dual-Arm Humanoid Robot with Inspire DFQ Five-Finger Dexterous Hands & Dual Intel Core i5/i7 Compute. 31 DOF, 6-DOF hands with 12 joints, ±0.20 mm repeatability, 600 mm reach, binocular vision & full-stack open SDK.
H2-A Standard H — upper-body humanoid with Inspire DFQ five-finger dexterous hands, 6 DOF + 12 joints per hand
The H2-A Standard H introduces the Inspire DFQ five-finger dexterous hand — a precision-engineered end effector with 6 DOF per hand and 12 joints for fluid, biomimetic finger movement. The DFQ achieves ±0.20 mm repeatability with a thumb lateral rotation range >65° and impressive actuation speeds: thumb lateral swing 235°/s, thumb bending 150°/s, four-finger bending 570°/s. Grip force is finely tuned with 6 N max on the thumb and 4 N max on the four fingers, resolved to 0.50 N for delicate force-controlled manipulation. The integrated wrist RGB camera provides close-up visual feedback for grasp verification. At 31 total DOF, Standard H delivers high-speed, precision five-finger manipulation for research labs and automation prototyping.
The H2-A Standard H is engineered around two 7-DOF high-performance arms, each driven by low-inertia inner-rotor PMSM motors with crossed-roller and double-row ball bearings. With 600 mm reach and a ~7 kg rated payload per arm (up to ~15 kg peak), it handles precise assembly, heavy pick-and-place, and industrial manipulation research with human-like fluidity. The extra two degrees of freedom per arm provide kinematic redundancy — the arm can maintain end-effector pose while reconfiguring its elbow to avoid obstacles, reach around corners, or optimize for natural motion. Dual encoders on every joint deliver closed-loop precision down to ±0.1 mm.
Multimodal Perception & Natural Interaction: Integrating binocular vision with natural language interaction, H2-A enables intuitive and natural human–robot collaboration.
The Inspire DFQ is a 6-DOF five-finger dexterous hand engineered for high-speed, precision manipulation research. With 12 joints per hand, it delivers fluid biomimetic finger movement with exceptional dynamic performance. The thumb features a lateral rotation range >65° with swing speed of 235°/s and bending speed of 150°/s, while the four fingers achieve 570°/s bending speed — enabling rapid grasp transitions and dynamic in-hand manipulation. Force-controlled precision is delivered through 6 N max grip force on the thumb and 4 N on the four fingers, with 0.50 N resolution and ±0.20 mm repeatability for delicate, repeatable tasks. The integrated wrist RGB camera provides close-up visual feedback for grasp verification and object inspection.
The 3-DOF waist joint provides full torso articulation — yaw, pitch, and roll — dramatically expanding the robot's reachable workspace without moving the base. In a seated or standing deployment, the waist allows the robot to turn and manipulate objects on either side, hand objects from one hand to the other across the body, bend forward for floor-level picking, and orient toward humans or workstations. Combined with 7-DOF arms and Inspire DFQ five-finger dexterous hands, the H2-A achieves human-like reach envelopes that cover a full sphere of workspace — ideal for bimanual manipulation, in-hand reorientation, and human-robot interaction research.
The H2-A Standard H ships with a built-in dual-compute architecture: PC1 runs an Intel Core i5 for real-time platform functionality and motion control, while PC2 provides an Intel Core i7 dedicated to user development. This separation ensures deterministic robot behavior while giving researchers full freedom to experiment. Optional expansion slots (PC3 for NVIDIA Jetson Thor, PC4 for Intel i7 or Jetson Orin NX) future-proof the platform as your AI ambitions grow.
A wide-angle humanoid-style binocular camera head delivers a broad field of view for spatial awareness. Paired with an 8-core high-performance CPU + 10 TOPS NPU in the head module, plus the dual Intel compute in the body, it runs visual perception, object detection, and gesture recognition locally — no cloud required. The Inspire DFQ wrist cameras add close-up visual feedback for precision grasping and finger tracking.
Array beamforming microphones and high-power speakers enable clear voice capture and synthesis in noisy labs or industrial floors. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control.
At just 780 × 444 × 200 mm and approximately 34.4 kg (with battery), the H2-A Standard H fits on a reinforced lab bench or industrial workstation. The compact footprint leaves room for objects, tools, and sensors around the robot. Power via the included upper-body Li-ion battery for ~8 hours of untethered operation, or connect the external power supply for 24/7 continuous use.
Comprehensive SDKs and APIs, together with a mature manipulation and perception software stack, enable developers to focus on application innovation while reducing development cycles from months to weeks.
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the H2-A Standard H a clean slate for reinforcement learning, teleoperation research, and embodied AI. The dual Intel compute handles model training and inference without external hardware.
Standard H delivers high-speed precision manipulation. Upgrade as your research evolves:
| Model | Unitree H2-A Standard H (Upper Body) |
| Dimensions | 780 × 444 × 200 mm (H × W × D) |
| Weight (with Battery) | ~34.4 kg |
| Total DOF (without hands) | 19 (Arm 7×2, Waist 3, Head 2) |
| Total DOF (with hands) | 31 (Arm 7×2, Waist 3, Head 2, Hand 6×2) |
| Arm Reach | 600 mm (forearm + upper arm) |
| Joint Bearings | Crossed-roller + double-row ball bearings |
| Joint Motors | Low-inertia, high-speed, inner-rotor permanent magnet synchronous motors |
| Max Arm Payload | Peak: ~15 kg; Rated: ~7 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | BrainCo Inspire DFQ Five-Finger Dexterous Hands (both arms, pre-installed) with wrist RGB camera |
| Hand Active DOF | 6 per hand (12 joints total) |
| Hand Transmission | 12 micro force-controlled compound joints + 4 micro force-controlled gear joints |
| Thumb Lateral Rotation | >65° |
| Repeatability | ±0.20 mm |
| Max Grip Force (Thumb) | 6 N |
| Max Grip Force (4 Fingers) | 4 N |
| Grip Force Resolution | 0.50 N |
| Thumb Lateral Swing Speed | 235°/s |
| Thumb Bending Speed | 150°/s |
| Four-Finger Bending Speed | 570°/s |
| Perception Feedback | Joint mode, position, velocity, torque, temperature, voltage/current, IMU data |
| Wrist Cameras | Included — RGB 1920×1080, FOV D:130°/H:120°/V:81° |
| Tactile Sensing | Not included — proprioception via joint encoders (upgrade to RH56E2-T1 Tactile / Standard I available) |
| Waist Joint | 3-DOF (Yaw, Pitch, Roll) |
| Head Joint | 2-DOF, Yaw: ±115°, Pitch: ±36° |
| Vision | Binocular camera — wide-angle humanoid-style dual-camera system |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute (PC1) | Intel Core i5 (platform functionality) |
| Body Compute (PC2) | Intel Core i7 (user development) |
| Optional Compute (PC3) | NVIDIA Jetson Thor (empty slot, add-on) |
| Optional Compute (PC4) | Intel Core i7 or NVIDIA Jetson Orin NX (empty slot, add-on) |
| Audio | Array microphone + high-power speaker |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | Upper-body Li-ion battery (~8 h) + external DC PSU (24/7) |
| Cabling | Hollow + internal wiring |
| Joint Encoders | Dual + single encoders per joint |
| Cooling | Localized air cooling |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/audio/vision/lighting |
| Controllers | Handheld remote control included |
| Warranty | 12 months on the entire unit |
Standard A is the entry point. Every configuration shares the same H2-A upper-body base — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | DOF (Total) | Features |
|---|---|---|---|
| Standard A | Dex1-1 Advanced (RGB) | 21 | Entry-level parallel grippers with wrist camera, 7-DOF arms, stereo vision |
| Standard B | Dex3-1 (RGB) | 33 | 3-finger dexterous hand with wrist RGB camera |
| Standard C | Dex3-1 Tactile (RGB) | 33 | 3-finger hand with 33 tactile sensors + wrist RGB camera |
| Standard D | Dex5-1 (RGB) | 51 | 5-finger 16-DOF hand with wrist RGB camera |
| Standard E | Dex5-1P Tactile (RGB) | 51 | 5-finger hand with 94 pressure sensors + wrist RGB camera |
| Standard F | Revo 2 Basic (RGB) | 31 | 5-finger 6-DOF BrainCo hand with wrist RGB camera |
| Standard G | Revo 2 Tactile (RGB) | 31 | 5-finger hand with pressure/friction/direction/proximity sensing + wrist RGB camera |
| Standard H | RH56DFQ (RGB) | 31 | Inspire Robots 5-finger 6-DOF hand with wrist RGB camera |
| Standard I | RH56E2-T1 Tactile (RGB) | 31 | Inspire Robots 5-finger hand with 17 tactile sensors + wrist RGB camera |
| Standard J | Revo 3 U21 (RGB) | 61 | BrainCo 21-DOF hand with wrist RGB camera |
| Standard K | Revo 3 U21T Tactile (RGB) | 61 | BrainCo 21-DOF hand with full-palm tactile + wrist RGB camera |
| Standard L | Revo 3 U21VT Visuo-Tactile (RGB) | 61 | BrainCo 21-DOF hand with visuo-tactile sensing + wrist RGB camera |
| Standard M | WUJI Hand 2 Tactile (RGB) | 59 | WUJI 20-DOF hand with tactile + wrist RGB camera, 1000 Hz control |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional compute modules and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.

Hintahistoria
Yksi tietopiste päivää kohti, keskiarvo laskettuna havaintopäivän mukaan.
Summat valuutassa USD
Keskiarvot lasketaan UTC-päivittäin kaikista tallennetuista tarjoushinnoista.

Unitree
$39 900

Unitree
$39 900

Unitree
$42 800
Unitree
$44 800
Unitree
$40 180
Unitree
$44 180
Unitree
$47 800

Unitree
$42 800
Unitree
42 499 €

Unitree
$40 900

Unitree
$39 900

Unitree
alkaen 42 000 €
🍪 Evästeasetukset
Käytämme evästeitä suorituskyvyn mittaamiseen. Tietosuojakäytäntö