Päivän keskihinta
Summat valuutassa USD
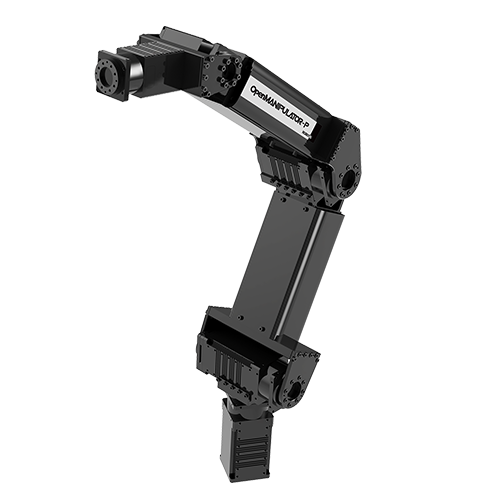
Kuvaus
OpenMANIPULATOR-P Features Product Name : OpenMANIPULATOR-P Model Name : RM-P60-RNH User Programmable Open-Source Manipulator System Modular Platform for Easy Maintenance and Customization No External Control Box & High Weight-to-Payload Ratio Package Components OpenMANIPULATOR-PRO 1 (Fully-assembled) Hard Case 1 U2D2 1 Spare Cables (4P, 2P) 1 Screw Sets (WB M3x8 etc) 1 4P Expansion Hub 1 H/W Specification DOF 6 Payload (kg) 3 Repeatability (mm) ±0.05 Speed (Each joint, deg/sec) 180 Weight (kg) 5.5 Reach (mm) 645 Rated Voltage (VDC) 24 Communication RS-485 (Multi Drop Bus) Motor Output / Joint 200W / 2ea 100W / 2ea 20W / 2ea Software ROS (Ubuntu Linux) Controller PC (Not Included) S/W Specification ROBOTIS Manipulator controller package based on integrated software OpenMANIPULATOR-PRO Library (Kinematics,Trajectory and Dynamixel Controller). GUI program package for setting and monitoring control parameters. MoveIt! package for OpenMANIPULATOR-PRO Simulation package based on Gazebo Simulator Teleoperation examples of keyboard and Joystick Purpose Research and Education Kinematics and Dynamics Experiment Research and Design a Dual Arm Robot Build a Mobile Robot System Industrial Operation Inspection Equipment Small-Scale Delivery System Caution Power supply and PC are not included Please purchase separately according to your usage environment. Factory Default Settings ID 1 Baud Rate 57600 bps (User can change various settings including ID and baud rate according to environment) If you purchase RH-P12 (Robot Hand) and RM-P60-RNH(OpenMANIPULATOR PRO) together, they will be shipped out together in the OpenMANIPULATOR PRO`s case. Features of DYNAMIXEL PRO All-in-one Modular Design DC Motor + Controller + Driver + Sensor + Cycloid Reduction Gear Compact and Lightweight Minimized module size with compact and lightweight cycloid reduction gear. High weight-to-output ratio(0.05Nm/g) High impact resistance ( over 400%) High Precision and Low Backlash Contactless (Magnetic) Absolute Encoder(by AMS) & Incremental Encoder for Precise Positioning Low backlash (3~4arcmin) Performance data provided tested by Korea Laboratory Accreditation Scheme(KOLAS) Current-Based Torque Control High speed current sensing algorithm and current feedback control Triple-loop control for current, speed and position feedback. User Friendly development environment Provide C language based library Various solution examples (C++, LabVIEW, C#, eclipse, JAVA, etc..) Links e-Manual Drawing DYNAMIXEL SDK Meet the RM-P60-RNH
OpenMANIPULATOR-P Features Product Name : OpenMANIPULATOR-P Model Name : RM-P60-RNH User Programmable Open-Source Manipulator System Modular Platform for Easy Maintenance and Customization No External Control Box & High Weight-to-Payload Ratio Package Components OpenMANIPULATOR-PRO 1 (Fully-assembled) Hard Case 1 U2D2 1 Spare Cables (4P, 2P) 1 Screw Sets (WB M3x8 etc) 1 4P Expansion Hub 1 H/W Specification DOF 6 Payload (kg) 3 Repeatability (mm) ±0.05 Speed (Each joint, deg/sec) 180 Weight (kg) 5.5 Reach (mm) 645 Rated Voltage (VDC) 24 Communication RS-485 (Multi Drop Bus) Motor Output / Joint 200W / 2ea 100W / 2ea 20W / 2ea Software ROS (Ubuntu Linux) Controller PC (Not Included) S/W Specification ROBOTIS Manipulator controller package based on integrated software OpenMANIPULATOR-PRO Library (Kinematics,Trajectory and Dynamixel Controller). GUI program package for setting and monitoring control parameters. MoveIt! package for OpenMANIPULATOR-PRO Simulation package based on Gazebo Simulator Teleoperation examples of keyboard and Joystick Purpose Research and Education Kinematics and Dynamics Experiment Research and Design a Dual Arm Robot Build a Mobile Robot System Industrial Operation Inspection Equipment Small-Scale Delivery System Caution Power supply and PC are not included Please purchase separately according to your usage environment. Factory Default Settings ID 1 Baud Rate 57600 bps (User can change various settings including ID and baud rate according to environment) If you purchase RH-P12 (Robot Hand) and RM-P60-RNH(OpenMANIPULATOR PRO) together, they will be shipped out together in the OpenMANIPULATOR PRO`s case. Features of DYNAMIXEL PRO All-in-one Modular Design DC Motor + Controller + Driver + Sensor + Cycloid Reduction Gear Compact and Lightweight Minimized module size with compact and lightweight cycloid reduction gear. High weight-to-output ratio(0.05Nm/g) High impact resistance ( over 400%) High Precision and Low Backlash Contactless (Magnetic) Absolute Encoder(by AMS) & Incremental Encoder for Precise Positioning Low backlash (3~4arcmin) Performance data provided tested by Korea Laboratory Accreditation Scheme(KOLAS) Current-Based Torque Control High speed current sensing algorithm and current feedback control Triple-loop control for current, speed and position feedback. User Friendly development environment Provide C language based library Various solution examples (C++, LabVIEW, C#, eclipse, JAVA, etc..) Links e-Manual Drawing DYNAMIXEL SDK
Hintahistoria
Yksi tietopiste päivää kohti, keskiarvo laskettuna havaintopäivän mukaan.
Summat valuutassa USD
Keskiarvot lasketaan UTC-päivittäin kaikista tallennetuista tarjoushinnoista.
RoboSavvy
£165,58
RoboSavvy
£57,75
RoboSavvy
£29,77
 Myynti
Unitree
$13 900$11 815Säästä 15%

Unitree
$11 900
PUDU
10 920 €
PUDU
11 760 €
Segway
11 299,95 €
Trossen Robotics
12 259,95 €
UFactory
11 781 €
AgileX
£10 294,58
Direct Drive Tech
£10 650
🍪 Evästeasetukset
Käytämme evästeitä suorituskyvyn mittaamiseen. Tietosuojakäytäntö