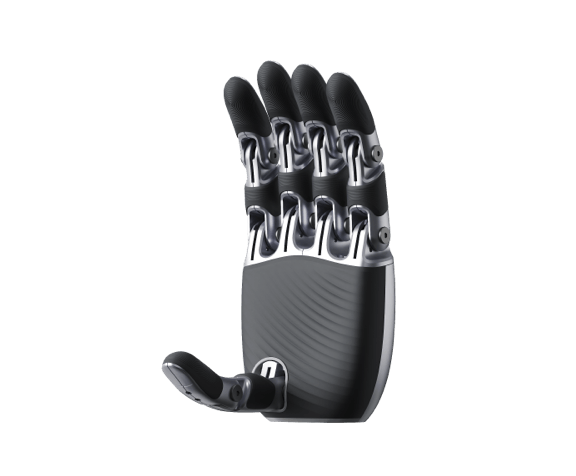
Linkerbot Linker Hand O6 Dexterous Hand | 6 DoF Five-finger Hand (Compatible with Unitree R1)
Go to slide 1 Go to slide 2 Go to slide 3 Go to slide 4 Go to slide 5
Linkerbot Linker Hand O6 Dexterous Hand | 6 DoF Five-finger Hand (Compatible with Unitree R1)

Linkerbot Linker Hand O6 Dexterous Hand | 6 DoF Five-finger Hand (Compatible with Unitree R1)

Sale price$1,450.00

Hand:Left
Left
Right
Tactile Sensing:Without Tactile Sensing
Without Tactile Sensing
With Tactile Sensing

The Linker Hand O6 is a lightweight dexterous robotic hand designed for humanoid robots, robotic arms, embodied AI, and automation. It features 6 active + 5 passive DoF, weighs only 360 g, and delivers up to 70 N grip force with <±0.20 mm repeatability.
Key features include high-torque servo modules, linkage transmission, optional tactile sensing, and support for CAN, CAN FD, RS485, and EtherCAT communication. Its compact, human-hand-sized design makes it ideal for robot manipulation, research, industrial automation, and AI robotics development.

Description

Linker Hand O6 Specifications

Model Linker Hand O6
Degrees of Freedom 6 Active DoF + 5 Passive DoF
Transmission Linkage Transmission
Control Interface CAN / CAN FD / RS485 / EtherCAT
Weight 360 g
Maximum Load 50 kg
Operating Voltage 24–48 V
Repeatability < ±0.20 mm
Tactile Sensor Optional
Maximum Thumb Fingertip Force 20 N
Maximum Four-Finger Fingertip Force 25 N
Maximum Five-Finger Grip Force 70 N
Four-Finger Flexion Angle 1.61 rad (92.59°)
Thumb Lateral Swing Speed 1.36 rad/s (78.10°/s)
Four-Finger Flexion Speed 1.30 rad/s (74.75°/s)
Thumb Flexion Speed 0.66 rad/s (38°/s)


Hintahistoria

Keskihintojen historia

Yksi tietopiste päivää kohti, keskiarvo laskettuna havaintopäivän mukaan.

Päivän keskihinta

Summat valuutassa USD

$1 450
Keskihintojen historiakaavio, valuutta USDViivakaavio: 7 havaintoa ajalta 2.10.2026–7.10.2026.$1 450,03$1 450,02$1 450,01$1 450$1 449,992.10.3.10.4.10.5.10.7.10.2.10.2026: keskihinta $1 4503.10.2026: keskihinta $1 4504.10.2026: keskihinta $1 4505.10.2026: keskihinta $1 4506.10.2026: keskihinta $1 4507.10.2026: keskihinta $1 450

Keskiarvot lasketaan UTC-päivittäin kaikista tallennetuista tarjoushinnoista.