Päivän keskihinta
Summat valuutassa USD


Control interface: RS485 / CAN / Modbus TCP
Operating voltage: 24 V ±10%
Quiescent current: 0.25 A
Peak current: 4 A
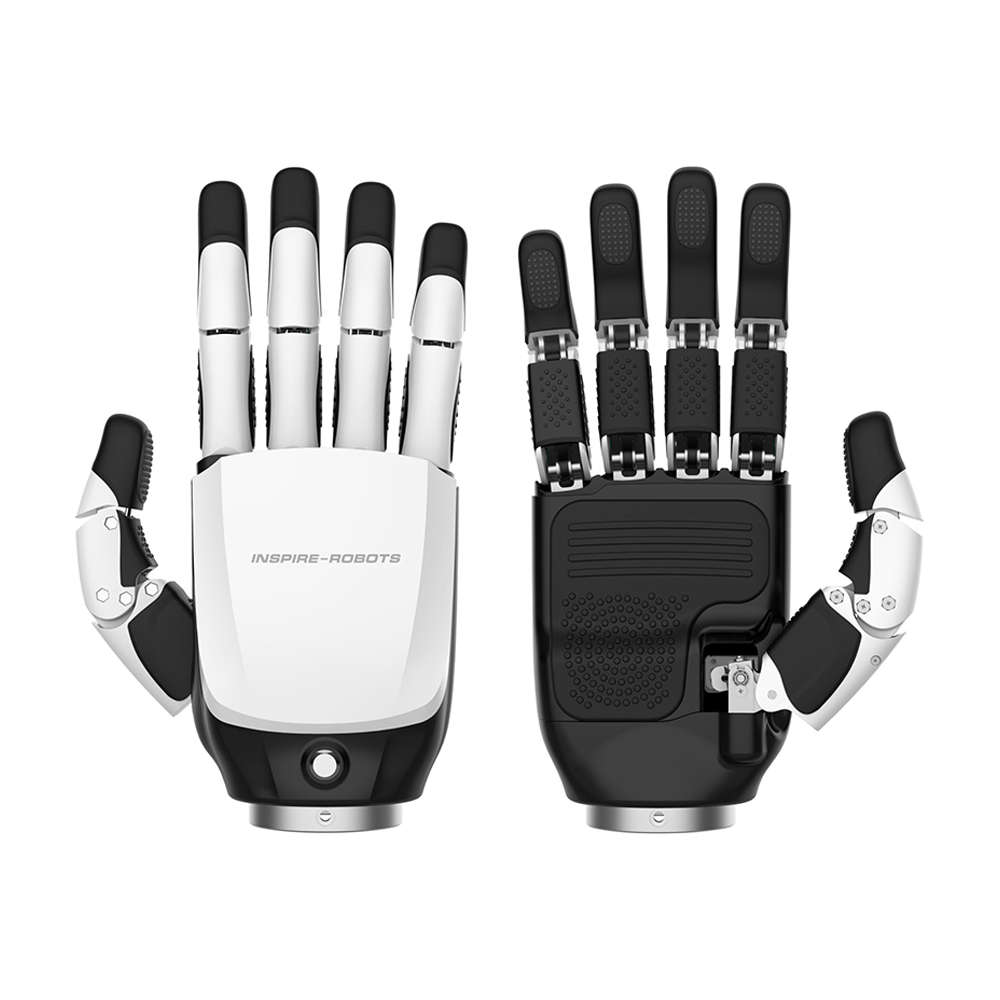
Finger configuration: 5-finger anthropomorphic hand
Degrees of freedom (DOF): 6
Number of joints: 12
Weight: 790 ± 10 g
Available versions: Left or right hand
Repeatability: ±0.20 mm
Thumb fingertip strength: 30 N
Finger fingertip strength: 28 N
Force resolution: ±0.05 N
Thumb lateral rotation range: 75° – 170°
Thumb lateral rotation speed: >130°/s
Thumb flexion speed: >130°/s
Four-finger flexion speed: >200°/s
Force sensors: 6
Tactile sensors: 5/ 17 depending on configuration
Tactile sensing range: 0–30 N
Tactile sensor accuracy: ≤5% FS
Maximum fingertip pressure: 8 kg
Hand closing time: ~0.8 s
Integrated multi-point tactile sensing (up to 17 sensors) for grasp feedback
High-precision force control and manipulation
Designed for humanoid robots, AI research, manipulation experiments, and robotic arms
Hintahistoria
Yksi tietopiste päivää kohti, keskiarvo laskettuna havaintopäivän mukaan.
Summat valuutassa USD
Keskiarvot lasketaan UTC-päivittäin kaikista tallennetuista tarjoushinnoista.

Inspire Robots
$7 500

Inspire Robots
5 900 €

Inspire Robots
alkaen $8 680

Inspire Robots
8 500 €

Inspire Robots
$6 294

Inspire Robots
$6 294

Inspire Robots
alkaen $6 500

Inspire Robots
$10 900
Inspire Robots
£5 181,72

Inspire Robots
$4 500

Inspire Robots
$4 500

Inspire Robots
alkaen $5 600
🍪 Evästeasetukset
Käytämme evästeitä suorituskyvyn mittaamiseen. Tietosuojakäytäntö