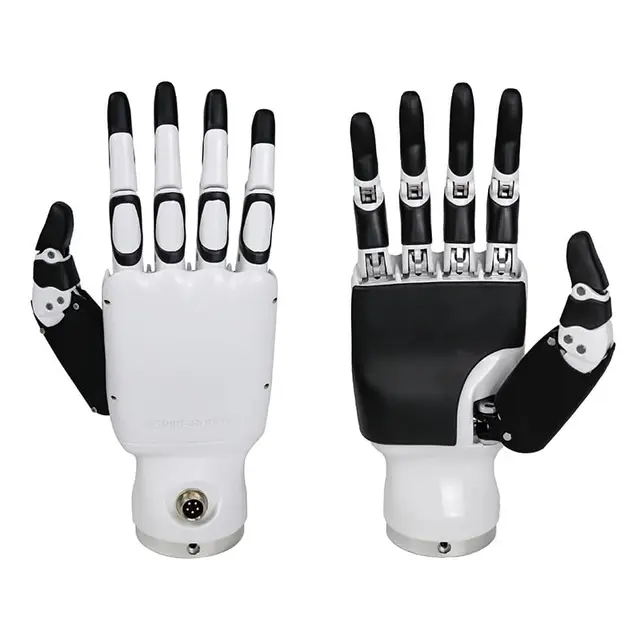
The Inspire RH56E2 is the heavy-load dexterous robotic hand from Inspire Robots' RH56 series: five fingers and six actuators built to grip with the force of a human hand. Inspire describes it as the first industrial-grade dexterous hand with human-hand grasping force, with 30 N at the thumb tip, 28 N at each fingertip and an overall load capacity equivalent to 15 kg.
That strength is the reason to choose it over lighter hands: power tools, door handles, kettlebells, boxes and workpieces in industrial automation, service robots and teaching labs. A power-off self-lock holds the fingers in place when power is cut.
Six micro linear servo actuators move 12 joints, each with a force sensor that reads finger force at 0.05 N resolution, and fingertips repeat to ±0.20 mm. The thumb rotates laterally through 75–170° at more than 130°/s and flexes at more than 130°/s, the four fingers flex at more than 200°/s, and the hand closes in 0.8 s. It measures 211.5 mm long, 93.0 mm across the palm and 47.5 mm thick, and runs on 24 V ±10 % with a 4 A peak.
The RH56E2 comes as a left or a right hand, each with Modbus TCP over Ethernet plus either CAN 2.0 (the -0 models) or RS-485 (the -2 models). Without tactile sensors it weighs 770 ± 10 g. The T1 tactile build adds 17 piezoresistive sensors across the fingertips, finger pads and palm with a 0–30 N range; the T2 build carries five capacitive sensors with a 0–20 N range; both are accurate to 5 % of full scale and weigh 790 ± 10 g. Hand side, bus and tactile option are confirmed with the quotation.
For lighter work, the Inspire RH56DFX weighs 540 g with 15 N at the thumb tip, and the Inspire RH56F1 brings EtherCAT at 620 g. Compare them with the rest of our dexterous robotic hands.
Key Capabilities
-
30 N thumb, 28 N fingertips: The thumb tip pushes with 30 N and each fingertip with 28 N, and Inspire rates the overall load capacity at the equivalent of 15 kg.
-
Holds its grip with power off: A power-off self-lock keeps every finger in place when the supply is cut.
-
Force sensing at 0.05 N: Six force sensors, one per actuator, read finger force at 0.05 N resolution for threshold-based or closed-loop gripping.
-
Tactile builds with 17 or 5 sensors: The T1 build carries 17 piezoresistive sensors over fingertips, finger pads and palm (0–30 N); the T2 build carries five capacitive sensors (0–20 N).
-
Modbus TCP plus CAN or RS-485: Every RH56E2 connects over Modbus TCP on Ethernet, plus CAN 2.0 or RS-485 depending on the model.
-
Quick, repeatable fingers: The four fingers flex at over 200°/s, the hand closes in 0.8 s, and fingertips repeat to ±0.20 mm.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.