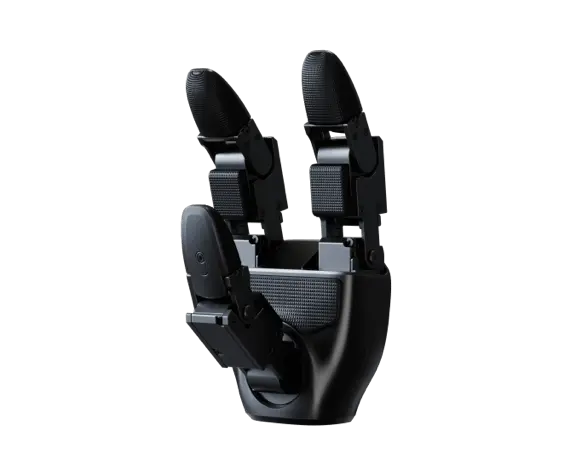
The BrainCo Revo 2 Touch (XTL) is the left-hand version of BrainCo's Revo 2 bionic dexterous hand with tactile fingertips, the only one of the three Revo 2 versions that can feel what it holds. It weighs 383 g, measures 160 mm from palm base to middle fingertip and 78.5 mm across the palm, and gives a humanoid robot or robot arm 11 degrees of freedom, six of them driven by their own motors.
Choose the Touch when the task depends on contact. A capacitive module in each of the five fingertips reads pressure, friction, force direction and proximity, measuring normal and tangential force up to 25 N at 70 Hz, so a controller can notice an object before touching it, detect first contact and set the grip before a paper cup folds or a smooth part slips. The tactile adaptive control mode works this way, and BrainCo's Python adaptive-grasping example recognises object stiffness from the fingertip data. That makes it a strong fit for grasp-learning research, teleoperation and humanoids that handle fragile or mixed objects.
Strength is the same across the Revo 2 range: at least 50 N five-finger grip, 15 N pinch, a 20 kg maximum payload, 0.1° repeat control precision and a full flex or extension in 0.65 s or less, at 50 dB or less. The Revo 2 Basic left hand (XRL) connects over RS-485 or CAN FD on 12–28 V, the Revo 2 Pro left hand (XEL) adds EtherCAT and a 12–64 V input, and the Touch keeps everything the Pro has and adds the fingertip sensors.
This is the left hand, with default device ID 126; the matching Revo 2 Touch right hand (XTR) uses 127, so a pair is addressed separately from the first power-on. Both run BrainCo's Python and C/C++ SDKs on Linux, Windows and ROS, update over the air and connect at up to 500 Hz over RS-485 or CAN FD, or 1 kHz over EtherCAT. For a Unitree H2, see the Revo 2 tactile hand configured for the H2; for other makes and models, compare our full range of dexterous robotic hands.
Key Capabilities
-
Touch in every fingertip: Capacitive sensors in all five fingertips read pressure, friction, force direction and proximity, with normal and tangential force measured up to 25 N.
-
383 g at human-hand size: The hand is 160 mm from palm base to middle fingertip and 78.5 mm across the palm, which keeps the load on a humanoid's arm low.
-
11 degrees of freedom from six motors: Six motors drive two thumb joints and one joint in each finger, five more joints are passive, and control repeats to 0.1°.
-
50 N grip, 20 kg payload: The five-finger grip reaches at least 50 N, the pinch at least 15 N, and the hand carries at least 20 kg.
-
Tactile adaptive control: On top of position, velocity and current control, the Touch adjusts finger current from what the fingertips feel, so soft and rigid objects get the grip they need.
-
EtherCAT at up to 1 kHz: RS-485 and CAN FD run at up to 500 Hz and EtherCAT (CoE and PDO) at up to 1 kHz, from a 12–64 V supply.
-
Python, C/C++ and ROS: BrainCo's SDKs run on Linux, Windows and ROS, and the firmware updates over the air.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.