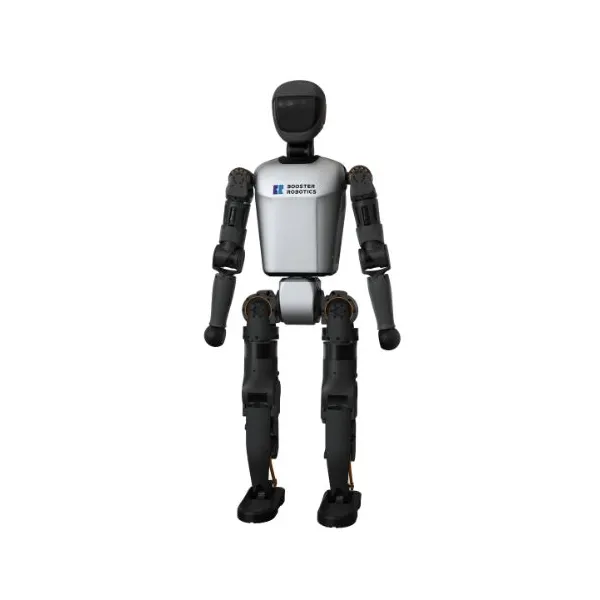
- Compact humanoid form Approximately 118 cm tall and around 30 kg, easy to transport, reset after falls, and operate in labs and classrooms.
- 23 degrees of freedom Six DOF per leg, four per arm, plus a waist joint and a two-DOF head for bipedal locomotion and upper-body motion.
- Developer-first, open platform Complete API access and ROS 2 compatibility for programming, testing, and extending behaviour.
- Dynamic-capable actuation High-torque joints (up to 130 N.m knee torque) with dual encoders for genuine dynamic motion.
- Simulation and AI workflows Integrates with mainstream simulation and AI development pipelines for research and teaching.
- Competition-proven platform The T1 platform is used by leading robotics teams in competition settings such as RoboCup.

Päeva keskmine hind
Summad valuutas USD