متوسط السعر اليومي
المبالغ بعملة USD
الوصف
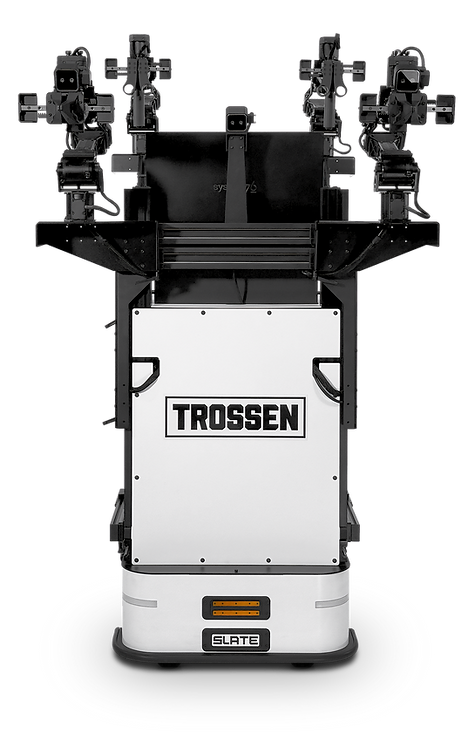
The Mobile AI is a high-performance, mobile all-in-one robotic machine learning workstation built to meet the demand for affordable, capable data collection and model development. With a four-arm configuration, an intuitive touchscreen interface, and a high-performance laptop, it delivers cutting-edge performance right out of the box—accelerating research in automation, human-robot interaction, and advanced manipulation without the need for extensive setup or modification. SPECIFICATIONS 2X Leader-Follower WidowX AI Arm Pairs 1X 10" Touchscreen 3X Intel RealSense D405 Cameras Frame & Accessories CONFIGURATIONS Without Laptop Computing capabilities depend on factors such as OS, RAM, storage, and CPU/GPU performance. With High-Performance Laptop Data Collection, Teloperation, On Device Model Training*, Cloud Model Training, Model Evaluation* SOFTWARE SUPPORT Hugging Face LeRobot Google CoLab Gazebo MuJoCo NVIDIA Issac ROS2 RESOURCES <a href="https://youtube.com/playlist?list=PL8X3t2QTE54tC1eCGDOGs_-56qOYco-gV&si=ZuR14Nyy2S37FNB5" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M41.944 62.145V37.762L62 49.953z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> TUTORIALS <a href="https://docs.trossenrobotics.com/" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M64 39.688H36a1.626 1.626 0 0 1 0-3.25h28a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 47.646H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M56.223 55.604H36a1.626 1.626 0 0 1 0-3.25h20.223a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 63.562H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOCUMENTATION <a href="https://github.com/interbotix" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m36.482 50.751 7.274 2.447v4.083L32 52.493v-3.537l11.756-4.788v4.069z" fill="#ffffff" data-color="2"></path> <path d="M48.065 60.513h-3.178l6.61-21.025h3.192l-6.623 21.025Z" fill="#ffffff" data-color="2"></path> <path d="m63.545 50.711-7.235-2.46v-4.069L68 48.97v3.537l-11.69 4.788v-4.069l7.235-2.513Z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> GITHUB <a href="https://drive.google.com/drive/folders/1bVi37QH0NhnrXrNQ6zcDeJ-FLGykucKv?usp=sharing" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m50 55.851-7.893-7.823 2.319-2.347 3.975 4.192V37.72H51.6v12.153l3.965-4.192 2.328 2.347z" fill="#ffffff" data-color="2"></path> <path d="M40.332 54.208v4.57h19.336v-4.57H62v7.072H38v-7.072z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOWNLOADS
The Mobile AI is a high-performance, mobile all-in-one robotic machine learning workstation built to meet the demand for affordable, capable data collection and model development. With a four-arm configuration, an intuitive touchscreen interface, and a high-performance laptop, it delivers cutting-edge performance right out of the box—accelerating research in automation, human-robot interaction, and advanced manipulation without the need for extensive setup or modification. SPECIFICATIONS 2X Leader-Follower WidowX AI Arm Pairs 1X 10" Touchscreen 3X Intel RealSense D405 Cameras Frame & Accessories CONFIGURATIONS Without Laptop Computing capabilities depend on factors such as OS, RAM, storage, and CPU/GPU performance. With High-Performance Laptop Data Collection, Teloperation, On Device Model Training*, Cloud Model Training, Model Evaluation* SOFTWARE SUPPORT Hugging Face LeRobot Google CoLab Gazebo MuJoCo NVIDIA Issac ROS2 RESOURCES <a href="https://youtube.com/playlist?list=PL8X3t2QTE54tC1eCGDOGs_-56qOYco-gV&si=ZuR14Nyy2S37FNB5" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M41.944 62.145V37.762L62 49.953z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> TUTORIALS <a href="https://docs.trossenrobotics.com/" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="M64 39.688H36a1.626 1.626 0 0 1 0-3.25h28a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 47.646H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M56.223 55.604H36a1.626 1.626 0 0 1 0-3.25h20.223a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> <path d="M48.444 63.562H36a1.626 1.626 0 0 1 0-3.25h12.444a1.626 1.626 0 0 1 0 3.25" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOCUMENTATION <a href="https://github.com/interbotix" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m36.482 50.751 7.274 2.447v4.083L32 52.493v-3.537l11.756-4.788v4.069z" fill="#ffffff" data-color="2"></path> <path d="M48.065 60.513h-3.178l6.61-21.025h3.192l-6.623 21.025Z" fill="#ffffff" data-color="2"></path> <path d="m63.545 50.711-7.235-2.46v-4.069L68 48.97v3.537l-11.69 4.788v-4.069l7.235-2.513Z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> GITHUB <a href="https://drive.google.com/drive/folders/1bVi37QH0NhnrXrNQ6zcDeJ-FLGykucKv?usp=sharing" target="_blank"> <svg preserveAspectRatio="xMidYMid meet" data-bbox="20 20 60 60" viewBox="20 20 60 60" height="100" width="100" xmlns="http://www.w3.org/2000/svg" data-type="color" role="presentation" aria-hidden="true" aria-label=""> <g> <path fill="#000000" d="M80 25.011v49.978A5.01 5.01 0 0 1 74.989 80H25.011A5.01 5.01 0 0 1 20 74.989V25.011A5.01 5.01 0 0 1 25.011 20h49.978A5.01 5.01 0 0 1 80 25.011" data-color="1"></path> <path d="m50 55.851-7.893-7.823 2.319-2.347 3.975 4.192V37.72H51.6v12.153l3.965-4.192 2.328 2.347z" fill="#ffffff" data-color="2"></path> <path d="M40.332 54.208v4.57h19.336v-4.57H62v7.072H38v-7.072z" fill="#ffffff" data-color="2"></path> </g> </svg> </a> DOWNLOADS
سجل الأسعار
نقطة بيانات واحدة لكل يوم، محسوبة بمتوسط الأسعار المرصودة في ذلك اليوم.
المبالغ بعملة USD
تُحسب المتوسطات لكل يوم وفق التوقيت العالمي المنسق، استنادًا إلى أسعار جميع العروض المسجلة.
Trossen Robotics
12,259.95 €
Trossen Robotics
£3,840
ABB
28,680 €
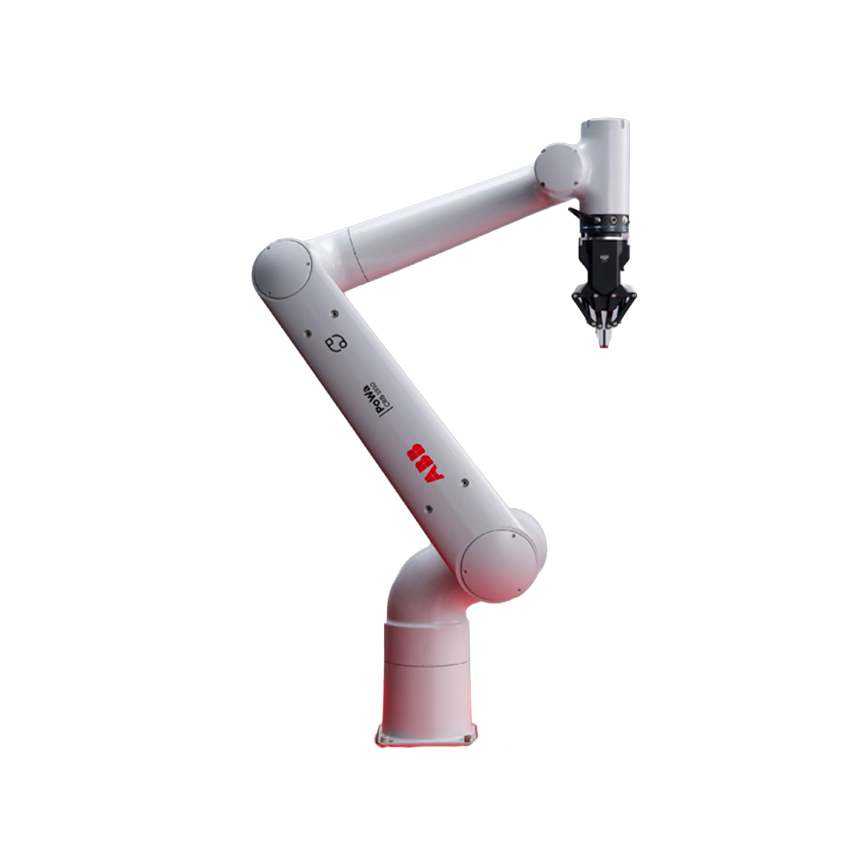
ABB
28,560 €
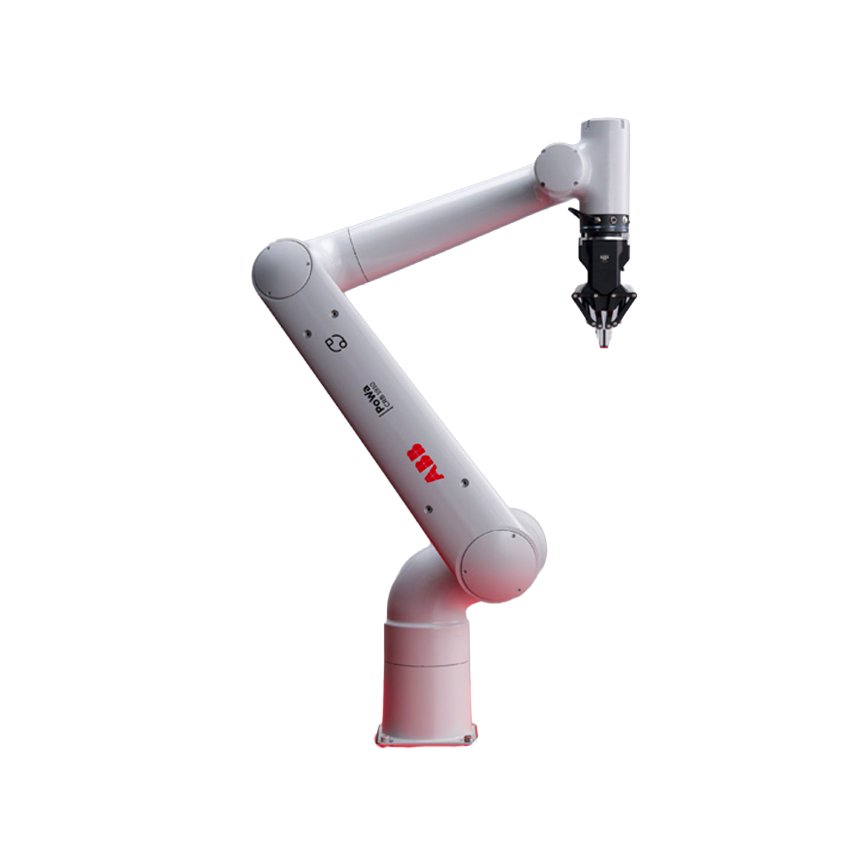
ABB
29,280 €
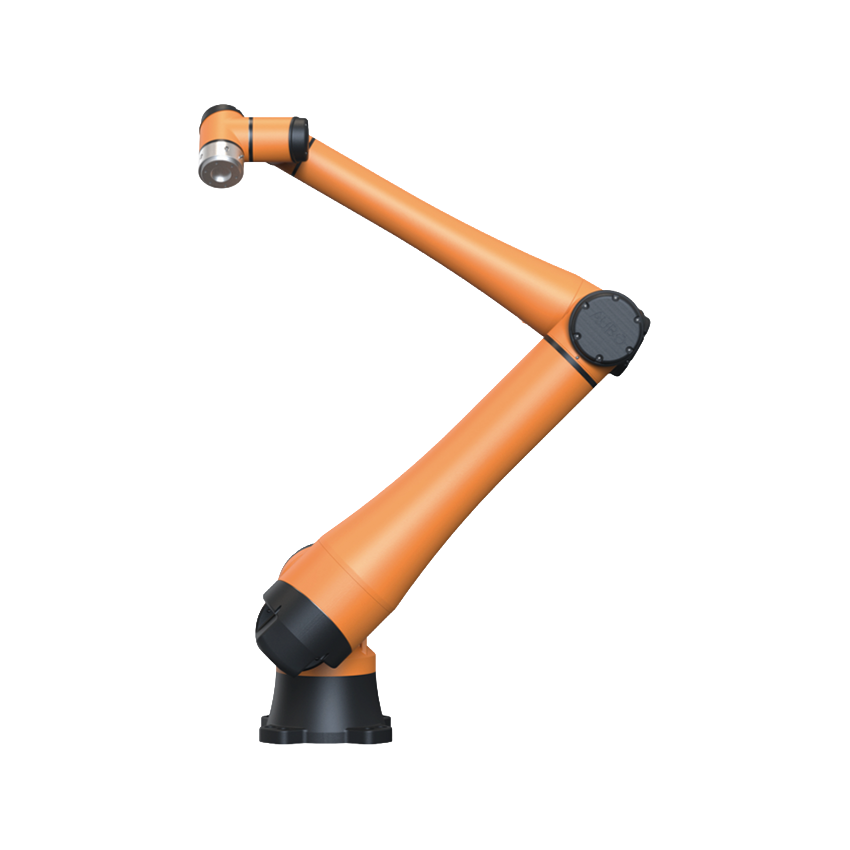
AUBO Robotics
28,000 €
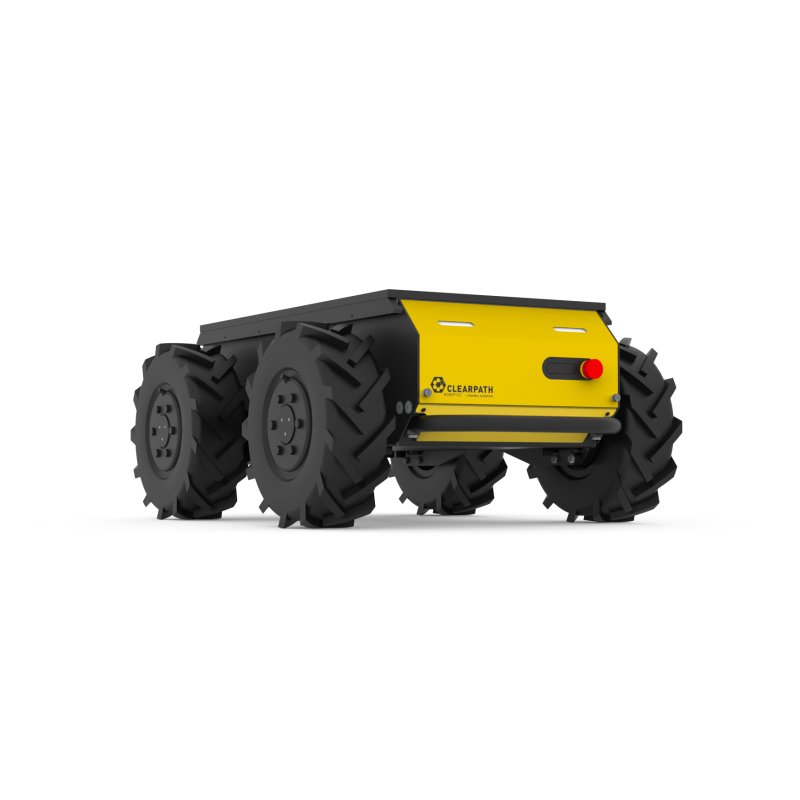
Clearpath
28,114.95 €
Universal Robots
29,155 €

Guo Xing
$27,895

Unitree
$29,000

Dobot
25,630 €

Dobot
26,580 €
🍪 تفضيلات ملفات تعريف الارتباط
نستخدم ملفات تعريف الارتباط لقياس الأداء. سياسة الخصوصية