متوسط السعر اليومي
المبالغ بعملة USD
الوصف
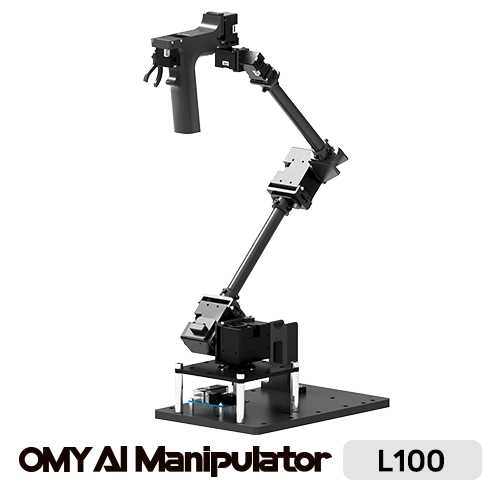
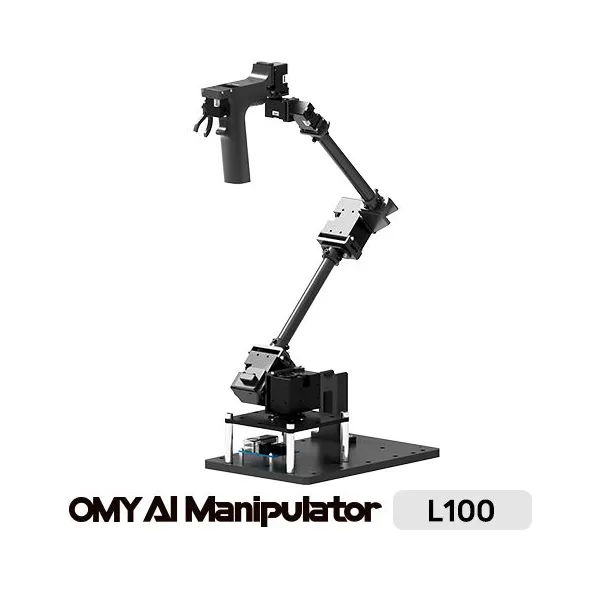
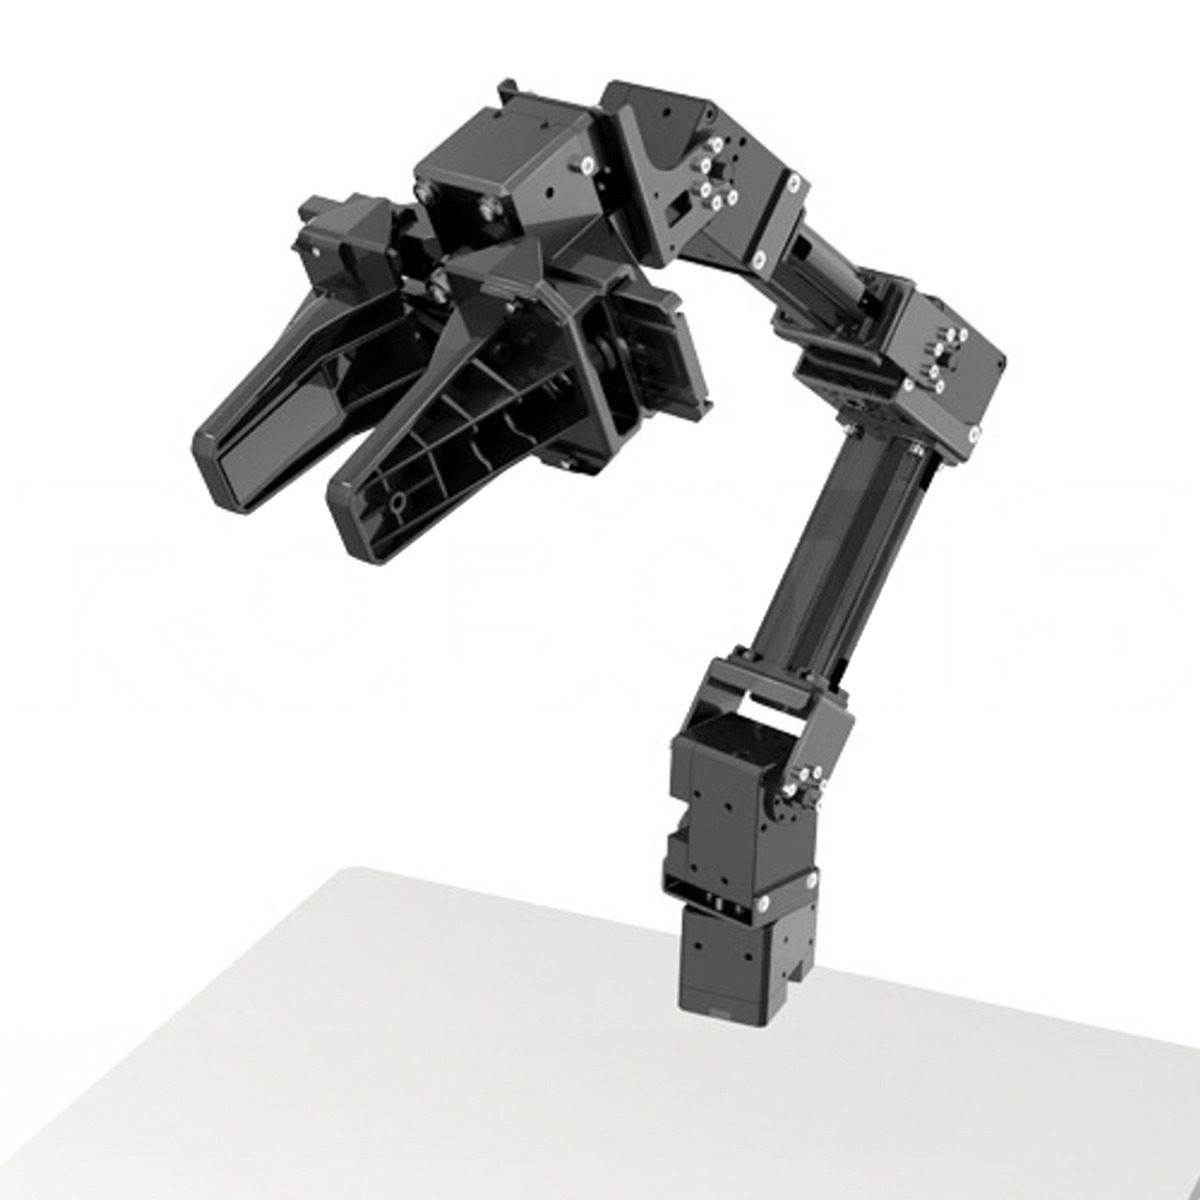
Features Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Offering operational and customization flexibility via a lightweight (under 1.5kg) and modular structure. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo, MuJoCo). Enabling compatibility between heterogeneous/multiple robots based on the ROS2 environment. Specification Items OMY-L100 (Leader) DOF 7 Payload - Reach 560 [mm] Weight 1.46 [kg] Operating Voltage 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Repeatability - Brake Force - TCP Speed - Host Interface U2D2 (USB 2.0) Internal Communications TTL Multidrop Bus Communication Baudrate 4 [Mbps] Robot Hand - Camera - Links e-Manual
Features Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Offering operational and customization flexibility via a lightweight (under 1.5kg) and modular structure. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo, MuJoCo). Enabling compatibility between heterogeneous/multiple robots based on the ROS2 environment. Specification Items OMY-L100 (Leader) DOF 7 Payload - Reach 560 [mm] Weight 1.46 [kg] Operating Voltage 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Repeatability - Brake Force - TCP Speed - Host Interface U2D2 (USB 2.0) Internal Communications TTL Multidrop Bus Communication Baudrate 4 [Mbps] Robot Hand - Camera - Links e-Manual
سجل الأسعار
نقطة بيانات واحدة لكل يوم، محسوبة بمتوسط الأسعار المرصودة في ذلك اليوم.
المبالغ بعملة USD
تُحسب المتوسطات لكل يوم وفق التوقيت العالمي المنسق، استنادًا إلى أسعار جميع العروض المسجلة.
Robotis
£2,215.05
Robotis
£2,215.05
Robotis
1,838.95 €
Robotis
£1,999.50
Robotis
£1,999.50

Robotis
$1,629.09

Robotis
$1,933.61

Robotis
$1,908.31
Robotis
3,291.60 €
Robotis
1,540.95 €
Robotis
£1,118.42
Robotis
£1,250.61
🍪 تفضيلات ملفات تعريف الارتباط
نستخدم ملفات تعريف الارتباط لقياس الأداء. سياسة الخصوصية