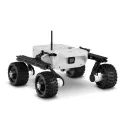
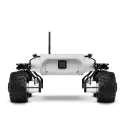
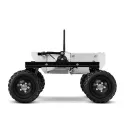
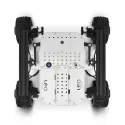
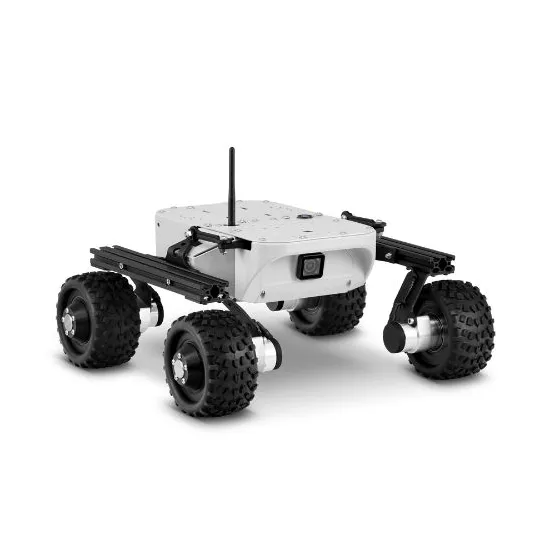
The assembled Leo Rover 1.9 by Fictionlab is an open-source 4x4 mobile robot designed for research, education, and robotics prototyping. Delivered fully assembled and tested, it provides a modular ROS 2 platform ready for developing and testing robotic applications both indoors and outdoors.


| Configuration | Fully assembled and tested robot |
| Dimensions | 424 × 445 × 303 mm |
| Weight | Approximately 7 kg |
| Payload | Approximately 5 kg with standard tires |
| Maximum linear speed | Approximately 0.4 m/s |
| Maximum angular speed | Approximately 1 rad/s |
| Estimated obstacle clearance | Approximately 70 mm |
| Ground clearance | 108 mm |
| Drive system | 4-wheel drive |
| Suspension | Differential / rocker system |
| Protection rating | IP55 |
| Operating temperature | -10 °C to +40 °C |
| Runtime | Up to 4 hours with the standard battery |
| Communication range | Up to 100 m |
| Onboard computer | Raspberry Pi 5 |
| Processor | Broadcom BCM2712, 64-bit quad-core Arm Cortex-A76 at 2.4 GHz |
| Memory | 4 GB LPDDR4X |
| Camera | 12.3 MP Arducam with wide-angle lens |
| Integrated sensors | Front camera, IMU, and wheel encoders |
| Connectivity | Dual-band Wi-Fi, Bluetooth 5.0, Gigabit Ethernet |
| USB | 2 × USB 3.0 + 2 × USB 2.0 |
| Operating system | Ubuntu 24.04 |
| Robotics framework | ROS 2 Jazzy |
| Software license | MIT |
| Battery | Li-Ion 3S2P, 10.8 V, 6.8 Ah, approximately 73.2 Wh |
| Charging time | Approximately 4 hours |
سجل الأسعار
نقطة بيانات واحدة لكل يوم، محسوبة بمتوسط الأسعار المرصودة في ذلك اليوم.
المبالغ بعملة USD
تُحسب المتوسطات لكل يوم وفق التوقيت العالمي المنسق، استنادًا إلى أسعار جميع العروض المسجلة.
Fictionlab
5,770.31 €
Unitree
6,427.20 €
UFactory
6,360 €
Dobot
7,254 €
AgileX
5,950.95 €
Dobot
6,490 €
AgileX
£5,995.96
YDLIDAR
£7,044.75

Elephant Robotics
$6,999

AgileX
$6,750

Dobot
6,611 €

Dobot
6,999 €
🍪 تفضيلات ملفات تعريف الارتباط
نستخدم ملفات تعريف الارتباط لقياس الأداء. سياسة الخصوصية