Giá trung bình hằng ngày
Số tiền bằng USD
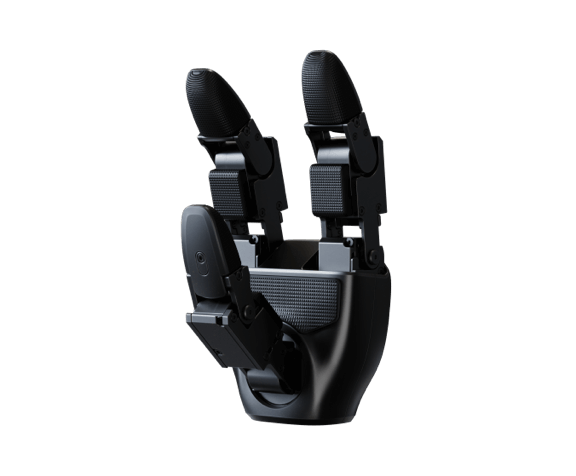
Unitree · Dex3-1
£5.705,08
Mô tả
Unitree Dex3-1 Power Control Dexterous Hand, Operate Everything Combined with force and position hybrid control, it is sensitive and reliable, and can simulate the precise operation of the object Collect data, Sensitive and Accurate Dex3-1 Dex3-1 three-finger dexterous hand, with 7 degrees of freedom 7 motion off machine: 6 micro brushless force control joint direct drive, 1 micro brushless force control joint gear drive, one hand with 33 tactile sensors. It can be used with G1 humanoid robot to perform various complex actions. Product Parameters Weight 710g Size 175mm x 88mm x 77mm Degrees of Freedom Thumb x 3Index Finger x 2Middle Finger x 2 Transmission Mechanism 6 Motors Drive Directly1 Motor Drive with Gears Angle of Joint Thumb Joint 0: -60°~60°Thumb Joint 1: -35°~60°The Thumb Joint 2: 0 to 100°Index Finger Joint 0: 0 °~90°Index Finger Joint 1: 0 °~100°Middle Finger Joint 0: 0 °~90°Middle Finger Joint 1: 0 °~100° Fingertip Repeat Positioning Accuracy ±2mm Working Voltage 12~58V Static Current 58V @ 0.2A Maximum Current 10A Communication Interface USB2.0 Working Temperature Range -20℃ ~ 60℃ Load Conditions ( Palm Facing Down At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 500g | The Maximum Power Is: 400W@3s Load Condition (Palm Facing Left At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 500g | The Maximum Power Is: 400W@3s Number of Pressure Sensors 9 (Total of 33 Pressure Sensors) Array resolution 2 x 2 (Palm) x 32 x 2 (Single Finger Pad) x 33 x 1 (Single Fingertip) x 3 Range of Perception 10g-2500g Maximum Acceptance (Unamaged) 20kg Communication rate 1000Hz The number of bytes in a full packet Sender:1234 bytesReceiver:1270 bytes Perceptual feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, Sensor Pressure Value, Sensor Temperature Value, imu Data Control feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient Model F-1515-108 Miniature Brushless Force Control Joint F-1515-214 Miniature Brushless Force Control joint Weight 45g Size 34.8mm x 23.1mm x 23.3mm Reduction Ratio 1:108 1:214 Maximum Torque (Ideal) 0.76Nm 1.498Nm Maximum Torque (Actual) The Torque Is In The Same Direction As The Speed:0.49NmThe Toque Is In The Opposite Direction of The Rotational Speed:1.37Nm The Torque Is In The Same Direction As The Speed:0.86NmThe Toque Is In The Opposite Direction of The Rotational Speed:3.1 Nm Maximum Rotational Speed 23rad/s 11rad/s Maximum Line Current 4.76A Communication Control Frequency 1000Hz Method of Communication High Speed Unibus Encoder Rotor Absolute Value Encoder Working Temperature Range -20℃ ~ 60℃ IP Rating / Working Voltage 12-24V Motor Preceived Feedback Torque, Angle, Angular Velocity, Temperature Motor Control Instruction Torque, Angle, Angular Velocity, Stiffness, Damping
Unitree Dex3-1 Power Control Dexterous Hand, Operate Everything Combined with force and position hybrid control, it is sensitive and reliable, and can simulate the precise operation of the object Collect data, Sensitive and Accurate Dex3-1 Dex3-1 three-finger dexterous hand, with 7 degrees of freedom 7 motion off machine: 6 micro brushless force control joint direct drive, 1 micro brushless force control joint gear drive, one hand with 33 tactile sensors. It can be used with G1 humanoid robot to perform various complex actions. Product Parameters Weight 710g Size 175mm x 88mm x 77mm Degrees of Freedom Thumb x 3Index Finger x 2Middle Finger x 2 Transmission Mechanism 6 Motors Drive Directly1 Motor Drive with Gears Angle of Joint Thumb Joint 0: -60°~60°Thumb Joint 1: -35°~60°The Thumb Joint 2: 0 to 100°Index Finger Joint 0: 0 °~90°Index Finger Joint 1: 0 °~100°Middle Finger Joint 0: 0 °~90°Middle Finger Joint 1: 0 °~100° Fingertip Repeat Positioning Accuracy ±2mm Working Voltage 12~58V Static Current 58V @ 0.2A Maximum Current 10A Communication Interface USB2.0 Working Temperature Range -20℃ ~ 60℃ Load Conditions ( Palm Facing Down At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 500g | The Maximum Power Is: 400W@3s Load Condition (Palm Facing Left At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 500g | The Maximum Power Is: 400W@3s Number of Pressure Sensors 9 (Total of 33 Pressure Sensors) Array resolution 2 x 2 (Palm) x 32 x 2 (Single Finger Pad) x 33 x 1 (Single Fingertip) x 3 Range of Perception 10g-2500g Maximum Acceptance (Unamaged) 20kg Communication rate 1000Hz The number of bytes in a full packet Sender:1234 bytesReceiver:1270 bytes Perceptual feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, Sensor Pressure Value, Sensor Temperature Value, imu Data Control feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient Model F-1515-108 Miniature Brushless Force Control Joint F-1515-214 Miniature Brushless Force Control joint Weight 45g Size 34.8mm x 23.1mm x 23.3mm Reduction Ratio 1:108 1:214 Maximum Torque (Ideal) 0.76Nm 1.498Nm Maximum Torque (Actual) The Torque Is In The Same Direction As The Speed:0.49NmThe Toque Is In The Opposite Direction of The Rotational Speed:1.37Nm The Torque Is In The Same Direction As The Speed:0.86NmThe Toque Is In The Opposite Direction of The Rotational Speed:3.1 Nm Maximum Rotational Speed 23rad/s 11rad/s Maximum Line Current 4.76A Communication Control Frequency 1000Hz Method of Communication High Speed Unibus Encoder Rotor Absolute Value Encoder Working Temperature Range -20℃ ~ 60℃ IP Rating / Working Voltage 12-24V Motor Preceived Feedback Torque, Angle, Angular Velocity, Temperature Motor Control Instruction Torque, Angle, Angular Velocity, Stiffness, Damping
Lịch sử giá
Mỗi ngày có một điểm dữ liệu, tính trung bình theo ngày ghi nhận.
Số tiền bằng USD
Giá trung bình được tính theo ngày UTC từ tất cả giá chào bán đã ghi nhận.

Unitree
5.798 €

Unitree
từ $6.000

Unitree
$6.500

Unitree
từ $6.500

Unitree
$6.500
Unitree
6.400 €

Unitree
$7.680

Unitree
$7.680

Unitree
$7.800

Unitree
$8.680
Unitree
$8.680

Unitree
$8.680
🍪 Tùy chọn cookie
Chúng tôi sử dụng cookie để đo lường hiệu suất. Chính sách quyền riêng tư