Giá trung bình hằng ngày
Số tiền bằng USD


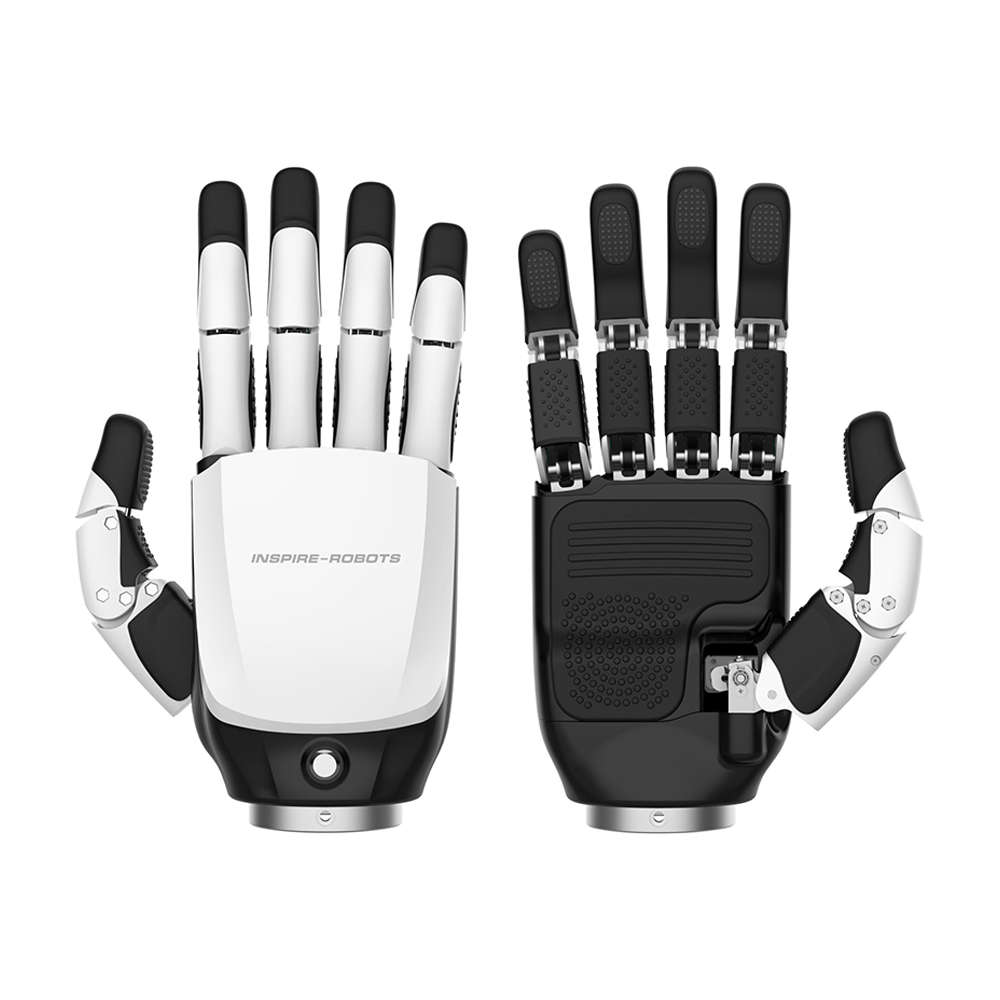
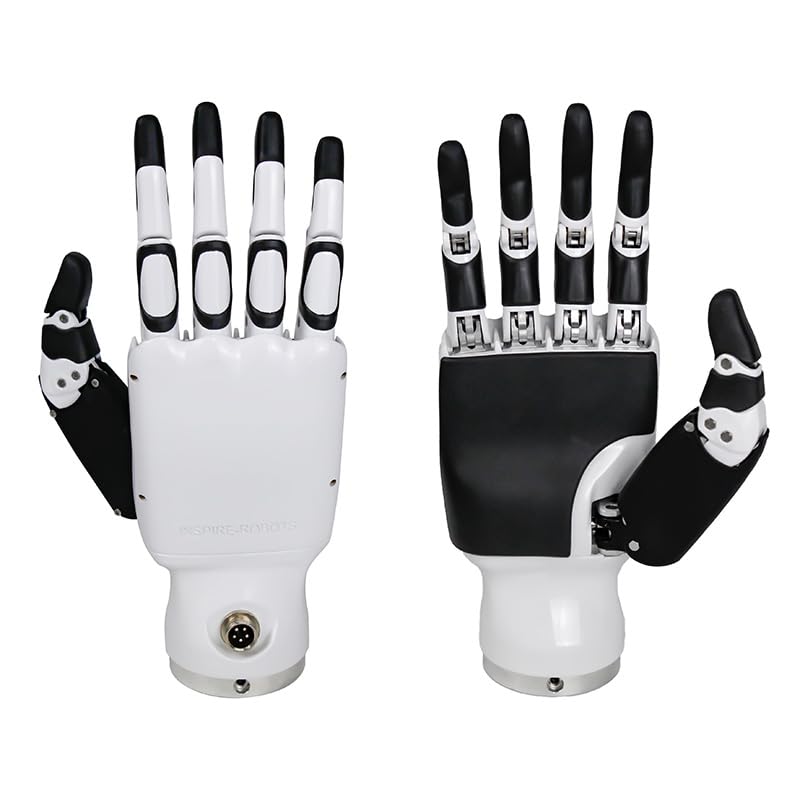
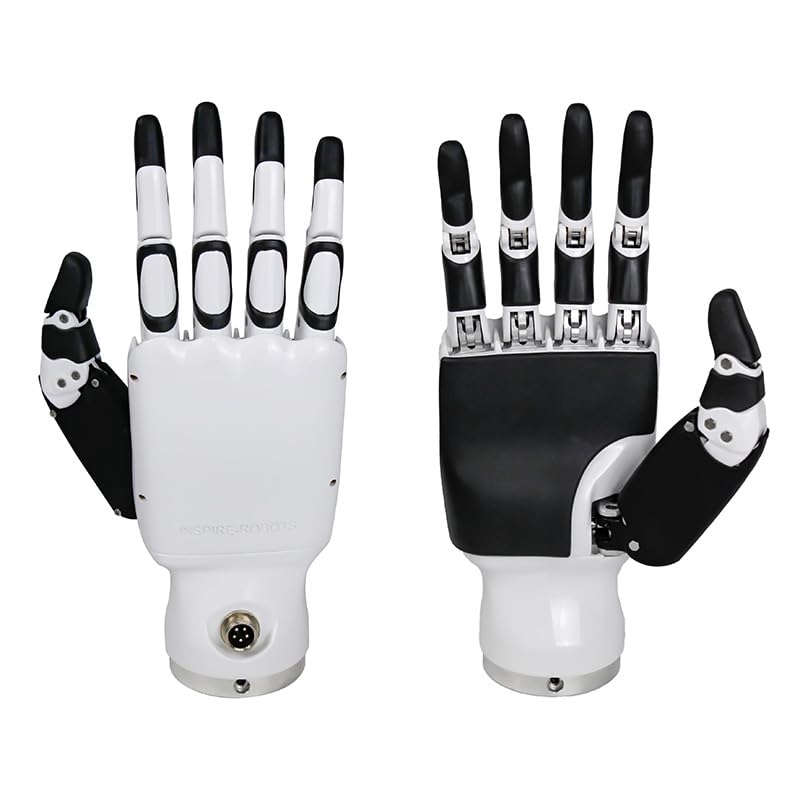
F1 Series Humanoid Dexterous Hand
The F1 series features a full-metal body with an integrated skeletal design, greatly enhancing structural rigidity. Its software algorithms are deeply integrated with multi-dimensional sensors, supporting multiple control strategies. With 1 kHz high-speed real-time communication, 30 kg static passive load capacity, 15 N fingertip gripping force, and 20 rigorous standardized tests, this hand truly understands robotics.
Construction Excellence: Integrated design, full-metal body, and innovative hidden wiring.
Advanced Sensing: 4 categories, 24 groups of sensors including tactile, force, position, and temperature.
Stable Control: Handles 30 kg static load, verified through 20 strict standard tests.
Specifications
Control Interface: EtherCAT + RS485 or EtherCAT+CAN FD
Degrees of Freedom: 6
Number of Joints: 12
Weight: 620 ± 10 g
Operating Voltage: 24V – 48V
Static Current:
RS485: 194 ± 10 mA @ 24V
EtherCAT: 210 ± 10 mA @ 24V
Maximum Current: 5A @ 24V
Fingertip Repeat Positioning Accuracy: ±0.2 mm
Maximum Thumb Fingertip Grip Force: ≥15 N
Maximum Four-Finger Fingertip Grip Force: ≥10 N
Grip Force Resolution: 0.1 N
Thumb Lateral Rotation Range: 56° – 180°
Thumb Lateral Rotation Speed: >155°/s
Thumb Bending Speed: >37°/s
Four-Finger Bending Speed: >107°/s
Tactile Sensor Measurement Range: 30 N
Tactile Sensor Accuracy: 5% FS
Number of Tactile Sensors: 6
Hand Closing Time: ≤0.8 s
Lịch sử giá
Mỗi ngày có một điểm dữ liệu, tính trung bình theo ngày ghi nhận.
Số tiền bằng USD
Giá trung bình được tính theo ngày UTC từ tất cả giá chào bán đã ghi nhận.

Inspire Robots
$6.294

Inspire Robots
$6.294

Inspire Robots
$4.500

Inspire Robots
$4.500

Inspire Robots
từ 3.300 €

Inspire Robots
5.900 €
Inspire Robots
£5.181,72

Inspire Robots
$7.500

Inspire Robots
từ $5.600

Inspire Robots
từ $5.750
Inspire Robots
£4.115,88
Inspire Robots
£4.115,88
🍪 Tùy chọn cookie
Chúng tôi sử dụng cookie để đo lường hiệu suất. Chính sách quyền riêng tư