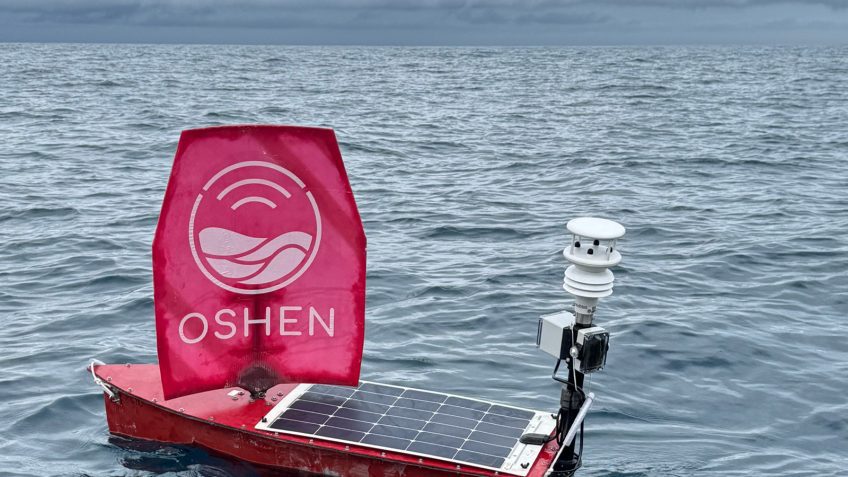
Oshen's C-Star autonomous ocean robot has become the first uncrewed surface vehicle to collect scientific data inside a Category 5 hurricane — a milestone that validates both the hardware's survivability and the broader case for deploying autonomous robots in environments that are simply too dangerous for humans. The startup has since signed contracts with multiple government agencies to deploy the platform for ongoing ocean data collection.
Table of Contents
- What is the Oshen C-Star robot?
- What engineering challenges does surviving a Category 5 hurricane present?
- How does the C-Star collect and transmit data autonomously?
- Why does ocean robot data matter for hurricane forecasting?
- What This Means for Robotics and Autonomous Systems
- Frequently Asked Questions
What is the Oshen C-Star Robot?
The C-Star is an autonomous uncrewed surface vehicle (USV) — a self-navigating ocean robot designed to operate continuously in open-water environments without human intervention onboard. Oshen built it specifically to survive and function in extreme maritime conditions that would destroy conventional sensor buoys and make crewed research vessels impossible to deploy safely.
The platform sits at a compelling intersection of physical AI and environmental robotics. Rather than processing video or manipulating objects in a warehouse, the C-Star's autonomy is focused on persistent navigation: holding position against extreme currents, avoiding debris, managing power across multi-day deployments, and making real-time decisions about when and how to collect sensor readings. It is embodied AI in one of the harshest operating environments on the planet.
Oshen's government contracts — the agencies involved have not been publicly disclosed — signal that the platform has cleared the credibility threshold required for operational science missions, not just demonstration flights.
What Engineering Challenges Does Surviving a Category 5 Hurricane Present?
A Category 5 hurricane generates sustained wind speeds exceeding 157 mph (252 km/h) and wave heights that routinely exceed 40 feet (12 metres). For any autonomous surface vehicle, this environment creates a layered set of engineering problems that go far beyond waterproofing.
Structural loading is the most immediate challenge. Wave impacts at those heights generate enormous impulsive forces — the kind that snap conventional hulls or flood sensor housings. The C-Star's design must distribute these loads without catastrophic failure, which typically requires a combination of materials engineering (composites, flexible mounts) and hull geometry that sheds water rather than catching it.
Power management presents a second constraint. In storm conditions, solar generation collapses and wave energy harvesting becomes unpredictable. The robot must have enough stored energy to maintain critical systems — navigation, communications, core sensors — through the worst conditions while intelligently shedding non-essential loads.
Navigation and station-keeping in Category 5 conditions is arguably the hardest autonomy problem. Surface currents during major hurricanes can exceed 5-7 knots, and the sea surface itself is chaotic. The robot's control algorithms must distinguish between intentional position changes and being thrown off course by a breaking wave. This requires tight integration between IMU (inertial measurement unit) data, GPS, and the propulsion system — executing corrections fast enough to matter without burning through battery reserves.
The fact that the C-Star emerged from a Category 5 event with intact systems and usable data is a meaningful proof point. Most hardened electronics enclosures are rated to survive the conditions. Actually collecting clean, timestamped scientific data during them is a harder bar.
How Does the C-Star Collect and Transmit Data Autonomously?
The C-Star is designed as a mobile sensor platform — think of it as a research vessel stripped of its crew and compressed into an autonomous hull that never needs to return to port for safety reasons. Its sensor suite is oriented toward oceanographic and atmospheric boundary layer measurements: sea surface temperature, salinity, wave height, barometric pressure, wind speed, and humidity are the core parameters relevant to hurricane intensification research.
What makes the autonomous data collection scientifically valuable is spatial continuity. Traditional fixed buoys give you a single point measurement. A crewed ship gives you transect data, but only where it's safe to operate. The C-Star can follow a storm system, collecting measurements along a track defined by the science — not by where it's safe for a crew to be. That's a fundamentally different data product.
Data transmission in the middle of a hurricane relies on satellite communication links (likely Iridium for low-data-rate telemetry, potentially Starlink for higher-bandwidth transmission windows). The robot's autonomy stack must decide which data packets are highest priority when bandwidth is constrained, and buffer the rest for transmission once conditions allow. This is a real-time resource allocation problem running continuously on embedded compute.
Why Does Ocean Robot Data Matter for Hurricane Forecasting?
The single biggest uncertainty in hurricane intensity forecasting is what happens at the ocean-atmosphere interface — the thin layer where heat and moisture transfer from warm seawater into the storm. Current forecast models are data-starved in exactly this zone because no conventional platform can safely operate there.
Dropsondes (sensor packages dropped from aircraft) give vertical atmospheric profiles but miss the sea surface layer entirely. Fixed buoys give surface data but only at pre-positioned locations that may not align with a storm track. Research aircraft can fly above and around storms but not through the boundary layer at sea level. The C-Star fills a gap that has existed in observational oceanography for decades.
The practical stakes are high. Rapid intensification events — where a hurricane strengthens by 35+ mph in 24 hours — are notoriously difficult to forecast and are responsible for a disproportionate share of loss of life and property damage, largely because they leave coastal populations with insufficient warning time. Better ocean heat content and air-sea flux data from platforms like C-Star could meaningfully improve 24-48 hour intensity forecasts.
Government agencies — likely including NOAA and potentially the U.S. Navy — have clear institutional incentives to fund platforms that reduce this uncertainty. Oshen's contract announcements suggest at least some of those agencies have decided the C-Star has reached operational readiness.
What This Means for Robotics and Autonomous Systems
Oshen's Category 5 milestone is more than an oceanography story. It is a case study in what happens when you design an autonomous robot around an environment rather than retrofitting a general-purpose platform for a specific task.
The C-Star's significance for the broader robotics industry lies in several areas:
| Dimension | Implication for Robotics |
|---|---|
| Extreme environment survivability | Validates design-for-environment approach over ruggedisation of standard platforms |
| Autonomous data prioritisation | Demonstrates edge AI decision-making under constrained communication bandwidth |
| Long-duration deployment | Advances engineering for persistent autonomy beyond hours-long missions |
| Government procurement | Signals growing appetite for uncrewed platforms in high-risk scientific missions |
| Physical AI validation | Proves embodied AI adds value in environments where human presence is impossible |
For engineers and developers working on used industrial robots and autonomous platforms in adjacent sectors, the key lesson is deployment-environment specificity. The hardest autonomy problems are rarely the algorithms in isolation — they are the integration of sensing, power, communication, and structural resilience into a system that performs when conditions are worst.
The precedent matters beyond ocean robotics. Similar design principles apply to autonomous systems being developed for wildfire perimeters, nuclear facilities, deep mining operations, and infrastructure inspection in active disaster zones. Every domain where human presence is dangerous or impossible is a potential market for robots engineered to Oshen's standard.