Günlük ortalama fiyat
USD cinsinden tutarlar
Açıklama
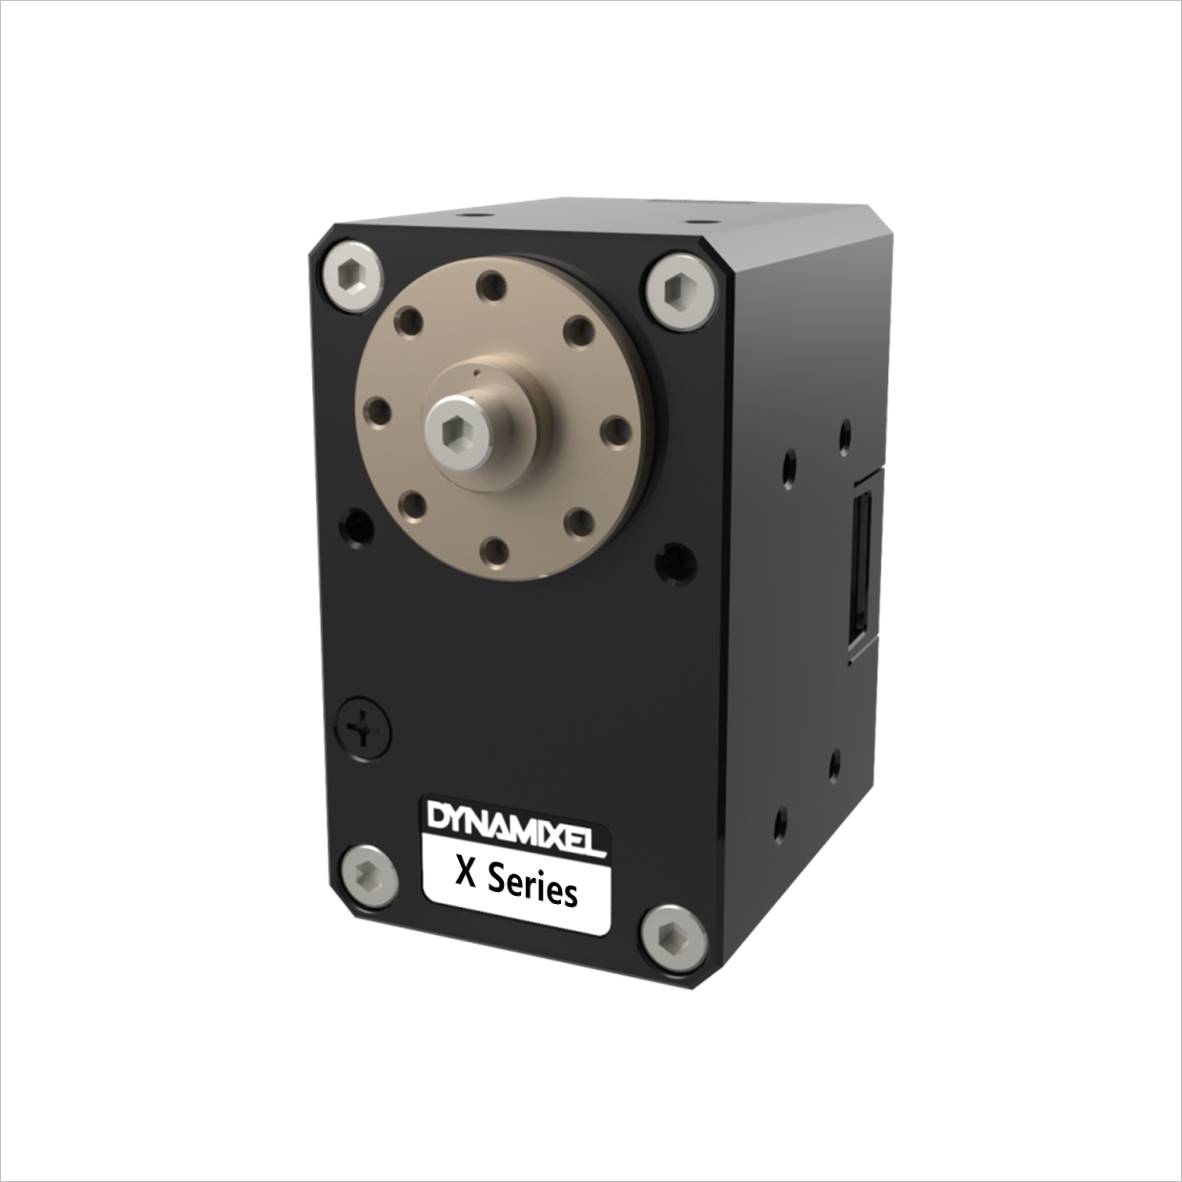
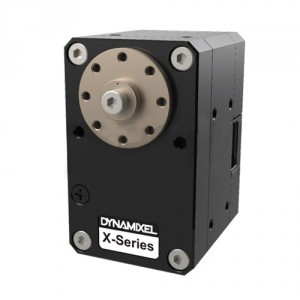
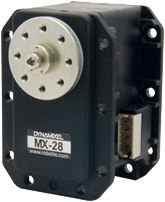
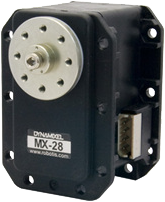
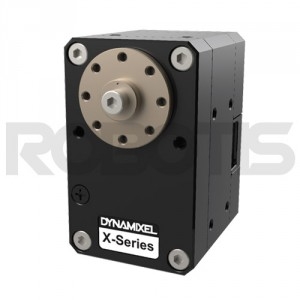
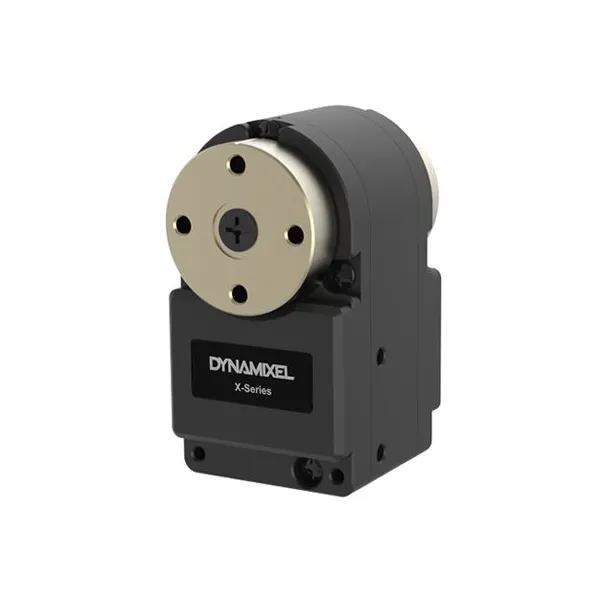
Features Improved Torque, Compact Size Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-way-routing) Direct Screw Assembly to the Case(without Nut Insert) Improved Heat Sink Featuring an Aluminum Case 6 Operating Modes Current-Based Torque Control (4096 steps, 2.69mA/step) Profile Control for Smooth Motion Planning Trajectory Data and Moving Status (In-Position, Following Error, etc.) Energy Saving (Reduced Current from 100mA to 40mA) Package Contents Description Quantity DYNAMIXEL XM430-W350-R 1 HORN HN12-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 BOLT/NUT Wrench Bolt (WB M2.5*4) 16 Wrench Bolt (WB M2.5*8) 1 Wrench Bolt (WB M2*3) 10 ETC Spacer Ring 8 Hardware Specification Model Number XM430-W350-R Weight 82g Dimension 28.5mm x 46.5mm x 34mm Gear Ratio 353.5 : 1 Operation Voltage (V) 11.1 12 14.8 Stall Torque (N.m) 3.8 4.1 4.8 Stall Current (A) 2.1 2.3 2.6 No Load Speed (RPM) 43 46 57 MCU ST CORTEX-M3 ( STM32F103C8 @ 72MHZ, 32BIT) Position Sensor Contactless absolute encoder (12bit, 360degree) by AMS Motor Coreless Motor Resolution Approx. 0.088° x 4,096 Operation Range Position Control Mode : 360° Extended Position Control Mode : 512 turns Velocity Control Mode : Endless turn Operation Voltage 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Command Signal Digital Packet Protocol Type RS485 Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (physical) RS485 Multi Drop Bus (daisy chain type connector) ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal (Front, Middle) Engineering Plastic (Back) Gear : Full Metal Standby current 40 mA Default Settings ID : 1 Baud Rate : 57,600bps (Please make necessary modifications after purchase. Such as the ID, baud rate, etc) Compatible Devices Embedded Board : OpenCM9.04 + 485 Expansion Board PC Interface : USB2Dynamixel (Molex-JST Convertible Cable is required) Development Environment GUI Software : RoboPlus 2.0 (Task / Motion / Manager) : download OpenCM IDE : download SDK : download Drawings : download E-manual : link PLEASE NOTE DYNAMIXEL X-Series adopted new JST connector with gold plating for secure and reliable communication. For more information, please visit e-Manual [DYNAMIXEL Connector Standard] To control DYNAMIXEL X-Series via OpenCM or USB2Dynamixel, please use JST-Molex Convertible Cable enclosed in the package. DYNAMIXEL X-Series is a new line-up of high performance networked actuator module, which has been widely used for building multi-joint robots with reliability and expandability.
Features Improved Torque, Compact Size Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-way-routing) Direct Screw Assembly to the Case(without Nut Insert) Improved Heat Sink Featuring an Aluminum Case 6 Operating Modes Current-Based Torque Control (4096 steps, 2.69mA/step) Profile Control for Smooth Motion Planning Trajectory Data and Moving Status (In-Position, Following Error, etc.) Energy Saving (Reduced Current from 100mA to 40mA) Package Contents Description Quantity DYNAMIXEL XM430-W350-R 1 HORN HN12-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 BOLT/NUT Wrench Bolt (WB M2.5*4) 16 Wrench Bolt (WB M2.5*8) 1 Wrench Bolt (WB M2*3) 10 ETC Spacer Ring 8 Hardware Specification Model Number XM430-W350-R Weight 82g Dimension 28.5mm x 46.5mm x 34mm Gear Ratio 353.5 : 1 Operation Voltage (V) 11.1 12 14.8 Stall Torque (N.m) 3.8 4.1 4.8 Stall Current (A) 2.1 2.3 2.6 No Load Speed (RPM) 43 46 57 MCU ST CORTEX-M3 ( STM32F103C8 @ 72MHZ, 32BIT) Position Sensor Contactless absolute encoder (12bit, 360degree) by AMS Motor Coreless Motor Resolution Approx. 0.088° x 4,096 Operation Range Position Control Mode : 360° Extended Position Control Mode : 512 turns Velocity Control Mode : Endless turn Operation Voltage 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Command Signal Digital Packet Protocol Type RS485 Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (physical) RS485 Multi Drop Bus (daisy chain type connector) ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal (Front, Middle) Engineering Plastic (Back) Gear : Full Metal Standby current 40 mA Default Settings ID : 1 Baud Rate : 57,600bps (Please make necessary modifications after purchase. Such as the ID, baud rate, etc) Compatible Devices Embedded Board : OpenCM9.04 + 485 Expansion Board PC Interface : USB2Dynamixel (Molex-JST Convertible Cable is required) Development Environment GUI Software : RoboPlus 2.0 (Task / Motion / Manager) : download OpenCM IDE : download SDK : download Drawings : download E-manual : link PLEASE NOTE DYNAMIXEL X-Series adopted new JST connector with gold plating for secure and reliable communication. For more information, please visit e-Manual [DYNAMIXEL Connector Standard] To control DYNAMIXEL X-Series via OpenCM or USB2Dynamixel, please use JST-Molex Convertible Cable enclosed in the package.
Fiyat geçmişi
Gözlem tarihine göre ortalaması alınmış, günde bir veri noktası.
USD cinsinden tutarlar
Ortalamalar, kaydedilen tüm teklif fiyatları kullanılarak UTC günlerine göre hesaplanır.
Robotis
325,56 €

Robotis
$333,39
Robotis
223,40 €
Robotis
223,08 €
Robotis
£224,24
Robotis
£208,54
Robotis
£231,81
Robotis
£224,02
Robotis
£208,53
Robotis
£224,02
Robotis
£208,79
Robotis
174 €
🍪 Çerez tercihleri
Performansı ölçmek için çerezleri kullanıyoruz. Gizlilik Politikası