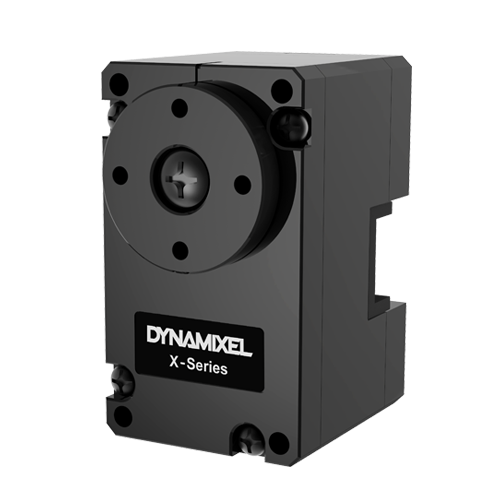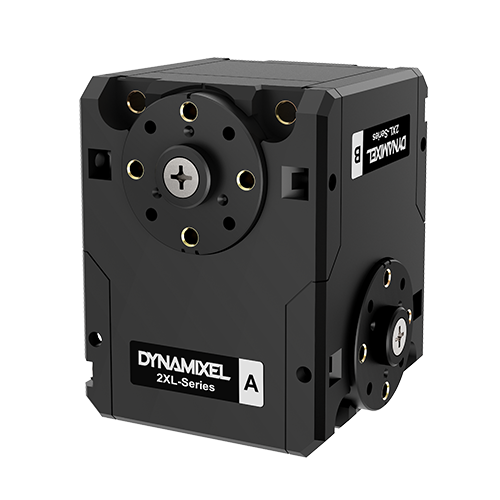
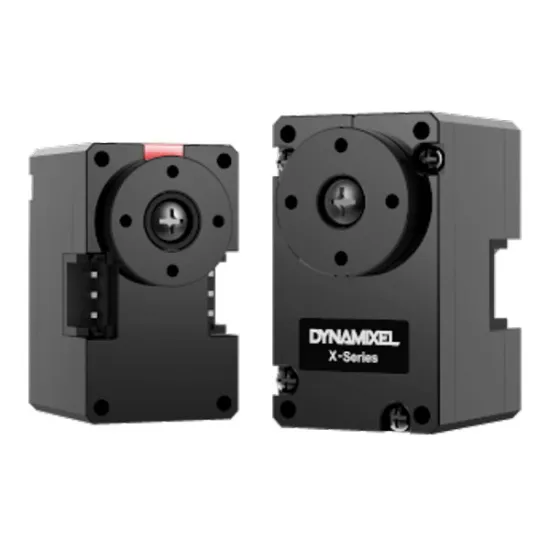
Dynamixel XC330-T181-T Servo

Dynamixel XC330-T181-T Servo

Dynamixel XC330-T181-T Servo
Robotis | A-000000-04951
€110.40 VAT incl. €92.00 VAT excl.

Robotis has rounded out its XC330 range with some servo motors that are equally fast and fun to control. The Dynamixel XC330-T181-T servo will reach 113 rpm!


Manufacturer reference: 902-0170-000

Quantity
41 Available

Get it in 24/48h! (see T&C)

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

Dynamixel XC330-T181-T: a nimble middleman

Looking for a particularly speedy mid-range Dynamixel actuator? The Dynamixel XC330-T181-T servo is one of the fastest in its class, with 104 rpm at an input voltage of 11.1 V. In contrast, its stall torque is relatively low. We therefore recommend it for designing small racing machines.

Although not as powerful as the XM range, the XC330-T181-T, with TTL connection, nonetheless offers all the features that make the Robotis servos so successful. These include extensive programming capabilities, multiple control modes and comprehensive feedback. Speed, PWM, position, extended position... no parameter will escape you!

Take note: the input voltage range for this actuator is between 6.5 and 12 V (with a recommended 11.1 V). Like the other servos in its class, you can mount it on your platform in a variety of configurations using the appropriate assembly kits.

Technical specifications of the XC330-T181-T servo

  • ARM CORTEX-M0+ 64 MHz, 32-bit processor
  • Position sensor: contactless absolute encoder (12 bits, 360°)
  • Coreless DC motor
  • Baud rate: 9,600 bps to 4 Mbps
  • Control algorithm: PID
  • Resolution: 4,096 pulses/revolution
  • Operating modes: current control, velocity control, position control (0 to 360°), extended position control (multi-turn), current-based position control, PWM control (voltage control)
  • Gear ratio: 180.62:1
  • Stall torque:
    • 0.65 N.m @ 9 V, 0.61 A
    • 0.76 N.m @ 11.1 V, 0.80 A
    • 0.80 N.m @ 12 V, 0.88 A
  • No-load speed:
    • 83 rev/min @ 9 V
    • 104 rev/min @ 11.1 V
    • 113 rev/min @ 12 V
  • Input voltage: 6.5–12 V (recommended: 11.1 V)
  • Standby current: 17 mA
  • Digital packet command signal
  • Physical connection:
  • TTL multidrop bus (3.3 V logic, 5 V compatible)
  • TTL half duplex asynchronous serial communication (8 bits, 1 stop, no parity)
  • ID: 253 (0~252)
  • Feedback: position, velocity, current, real-time tick, trajectory, temperature, input voltage, etc.
  • Case material: engineering plastic
  • Gear material: full metal gear (2 bearings)
  • Operating temperature: -5 to +60 °C
  • Weight: 23 g
  • Dimensions: 20 x 34 x 26 mm

Resources for the XC330-T181-T servo motor

Find the right information for your Dynamixel XC330-T181-T servo among this list of links, compiled especially for you:

    My Dynamixel servomotor is not detected, what can I do about it ?

    Check that your Dynamixel servomotor is correctly configured. Do not hesitate to re-flash it with the ROBOTIS Software Roboplus. After re-flash remember to re-configure it. If the issue is not solved, contact us for an advanced support.


    My motor works but it seems like there is an offset. Why ?

    The motor is probably not well mounted. Check that you correctly mounted the horns by respecting the mark.


    My Dynamixel servomotor seems blocked. I can't turn it even when it is not alimented.

    There is probably a mechanical issue with the Dynamixel servomotor. You can directly contact us to get more advance support.


    My Dynamixel servomotor is not working properly.

    Check your power supply and the system cabling (try with a different servomotor). You can also reset the servo. If nothing works, the best solution is to go through the Dynamixel servomotor checklist!


    What is the difference between Protocol 1.0 and Protocol 2.0?

    The 1.0 protocol is dedicated to the Dynamixel AX and MX series. Protocol 2.0 is for the X and Dynamixel Pro series. Protocol 2.0 control tables include PID controls which allow for more precise adjustment of the servo motor movements. Protocol 2.0 can be updated on MX series servo motors. You can refer to the protocol 1.0 and protocol 2.0 pages for more informations.


Fiyat geçmişi

Ortalama fiyat geçmişi

Gözlem tarihine göre ortalaması alınmış, günde bir veri noktası.

Günlük ortalama fiyat

USD cinsinden tutarlar

$123,63
USD cinsinden ortalama fiyat geçmişi grafiği2 Eki 2026 ile 7 Eki 2026 arasında 6 gözlem içeren çizgi grafik.$123,66$123,65$123,64$123,63$123,622 Eki3 Eki4 Eki5 Eki7 Eki2 Eki 2026: ortalama $123,633 Eki 2026: ortalama $123,634 Eki 2026: ortalama $123,635 Eki 2026: ortalama $123,636 Eki 2026: ortalama $123,637 Eki 2026: ortalama $123,63

Ortalamalar, kaydedilen tüm teklif fiyatları kullanılarak UTC günlerine göre hesaplanır.