Karaniwang presyo bawat araw
Mga halaga sa USD
Paglalarawan
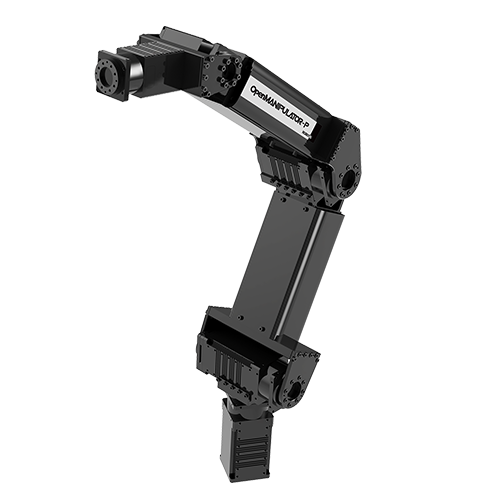
OpenMANIPULATOR-P Features Product Name : OpenMANIPULATOR-P Model Name : RM-P60-RNH User Programmable Open-Source Manipulator System Modular Platform for Easy Maintenance and Customization No External Control Box & High Weight-to-Payload Ratio Package Components OpenMANIPULATOR-PRO 1 (Fully-assembled) Hard Case 1 U2D2 1 Spare Cables (4P, 2P) 1 Screw Sets (WB M3x8 etc) 1 4P Expansion Hub 1 H/W Specification DOF 6 Payload (kg) 3 Repeatability (mm) ±0.05 Speed (Each joint, deg/sec) 180 Weight (kg) 5.5 Reach (mm) 645 Rated Voltage (VDC) 24 Communication RS-485 (Multi Drop Bus) Motor Output / Joint 200W / 2ea 100W / 2ea 20W / 2ea Software ROS (Ubuntu Linux) Controller PC (Not Included) S/W Specification ROBOTIS Manipulator controller package based on integrated software OpenMANIPULATOR-PRO Library (Kinematics,Trajectory and Dynamixel Controller). GUI program package for setting and monitoring control parameters. MoveIt! package for OpenMANIPULATOR-PRO Simulation package based on Gazebo Simulator Teleoperation examples of keyboard and Joystick Purpose Research and Education Kinematics and Dynamics Experiment Research and Design a Dual Arm Robot Build a Mobile Robot System Industrial Operation Inspection Equipment Small-Scale Delivery System Caution Power supply and PC are not included Please purchase separately according to your usage environment. Factory Default Settings ID 1 Baud Rate 57600 bps (User can change various settings including ID and baud rate according to environment) If you purchase RH-P12 (Robot Hand) and RM-P60-RNH(OpenMANIPULATOR PRO) together, they will be shipped out together in the OpenMANIPULATOR PRO`s case. Features of DYNAMIXEL PRO All-in-one Modular Design DC Motor + Controller + Driver + Sensor + Cycloid Reduction Gear Compact and Lightweight Minimized module size with compact and lightweight cycloid reduction gear. High weight-to-output ratio(0.05Nm/g) High impact resistance ( over 400%) High Precision and Low Backlash Contactless (Magnetic) Absolute Encoder(by AMS) & Incremental Encoder for Precise Positioning Low backlash (3~4arcmin) Performance data provided tested by Korea Laboratory Accreditation Scheme(KOLAS) Current-Based Torque Control High speed current sensing algorithm and current feedback control Triple-loop control for current, speed and position feedback. User Friendly development environment Provide C language based library Various solution examples (C++, LabVIEW, C#, eclipse, JAVA, etc..) Links e-Manual Drawing DYNAMIXEL SDK Meet the RM-P60-RNH
OpenMANIPULATOR-P Features Product Name : OpenMANIPULATOR-P Model Name : RM-P60-RNH User Programmable Open-Source Manipulator System Modular Platform for Easy Maintenance and Customization No External Control Box & High Weight-to-Payload Ratio Package Components OpenMANIPULATOR-PRO 1 (Fully-assembled) Hard Case 1 U2D2 1 Spare Cables (4P, 2P) 1 Screw Sets (WB M3x8 etc) 1 4P Expansion Hub 1 H/W Specification DOF 6 Payload (kg) 3 Repeatability (mm) ±0.05 Speed (Each joint, deg/sec) 180 Weight (kg) 5.5 Reach (mm) 645 Rated Voltage (VDC) 24 Communication RS-485 (Multi Drop Bus) Motor Output / Joint 200W / 2ea 100W / 2ea 20W / 2ea Software ROS (Ubuntu Linux) Controller PC (Not Included) S/W Specification ROBOTIS Manipulator controller package based on integrated software OpenMANIPULATOR-PRO Library (Kinematics,Trajectory and Dynamixel Controller). GUI program package for setting and monitoring control parameters. MoveIt! package for OpenMANIPULATOR-PRO Simulation package based on Gazebo Simulator Teleoperation examples of keyboard and Joystick Purpose Research and Education Kinematics and Dynamics Experiment Research and Design a Dual Arm Robot Build a Mobile Robot System Industrial Operation Inspection Equipment Small-Scale Delivery System Caution Power supply and PC are not included Please purchase separately according to your usage environment. Factory Default Settings ID 1 Baud Rate 57600 bps (User can change various settings including ID and baud rate according to environment) If you purchase RH-P12 (Robot Hand) and RM-P60-RNH(OpenMANIPULATOR PRO) together, they will be shipped out together in the OpenMANIPULATOR PRO`s case. Features of DYNAMIXEL PRO All-in-one Modular Design DC Motor + Controller + Driver + Sensor + Cycloid Reduction Gear Compact and Lightweight Minimized module size with compact and lightweight cycloid reduction gear. High weight-to-output ratio(0.05Nm/g) High impact resistance ( over 400%) High Precision and Low Backlash Contactless (Magnetic) Absolute Encoder(by AMS) & Incremental Encoder for Precise Positioning Low backlash (3~4arcmin) Performance data provided tested by Korea Laboratory Accreditation Scheme(KOLAS) Current-Based Torque Control High speed current sensing algorithm and current feedback control Triple-loop control for current, speed and position feedback. User Friendly development environment Provide C language based library Various solution examples (C++, LabVIEW, C#, eclipse, JAVA, etc..) Links e-Manual Drawing DYNAMIXEL SDK
Kasaysayan ng presyo
Isang punto ng datos bawat araw, na kinuwenta ang average ayon sa petsa ng obserbasyon.
Mga halaga sa USD
Kinakalkula ang mga average bawat araw ng UTC mula sa lahat ng naitalang presyo ng alok.
RoboSavvy
£165.58
RoboSavvy
£57.75
RoboSavvy
£29.77
 Benta
Unitree
$13,900$11,815Tipid ng 15%

Unitree
$11,900
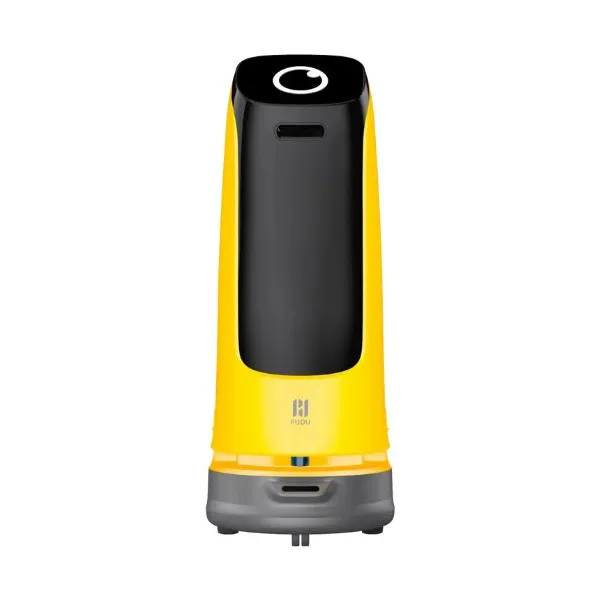
PUDU
10,920 €
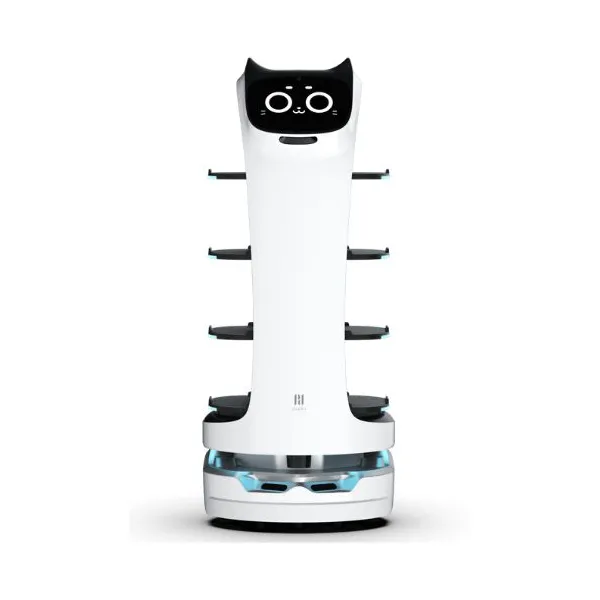
PUDU
11,760 €
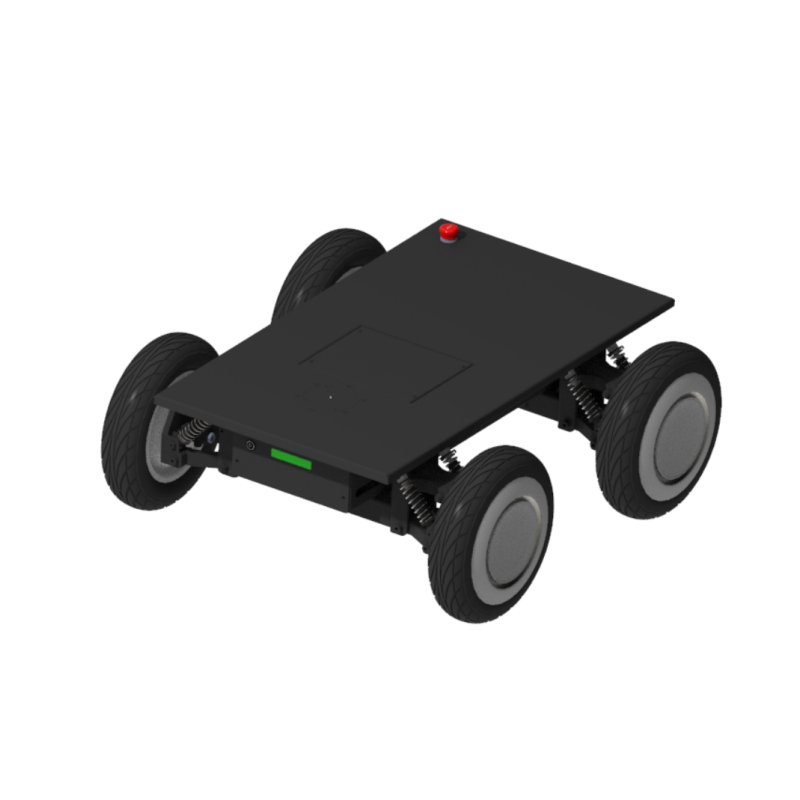
Segway
11,299.95 €
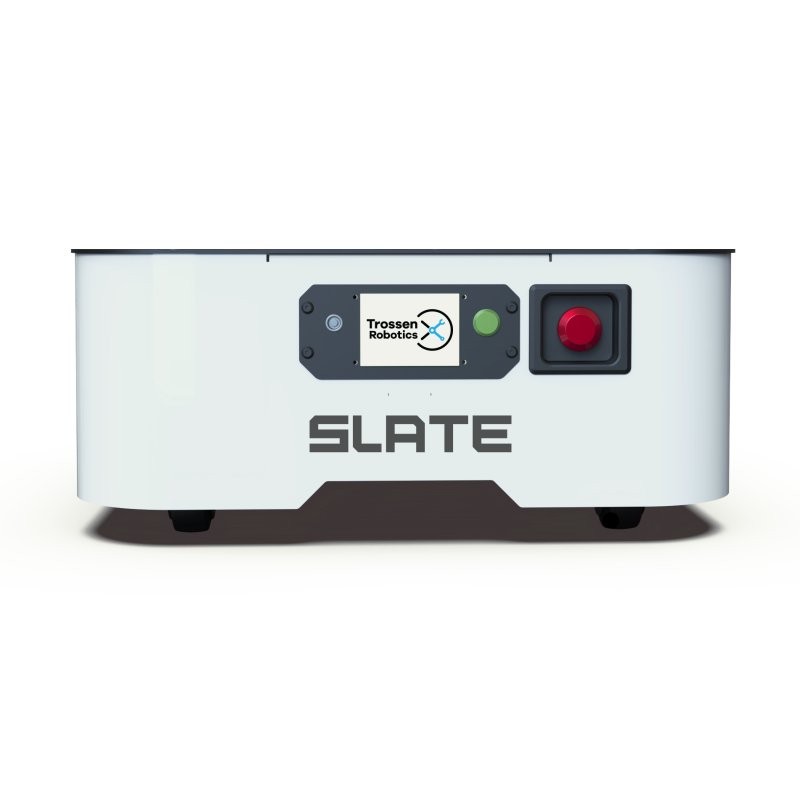
Trossen Robotics
12,259.95 €
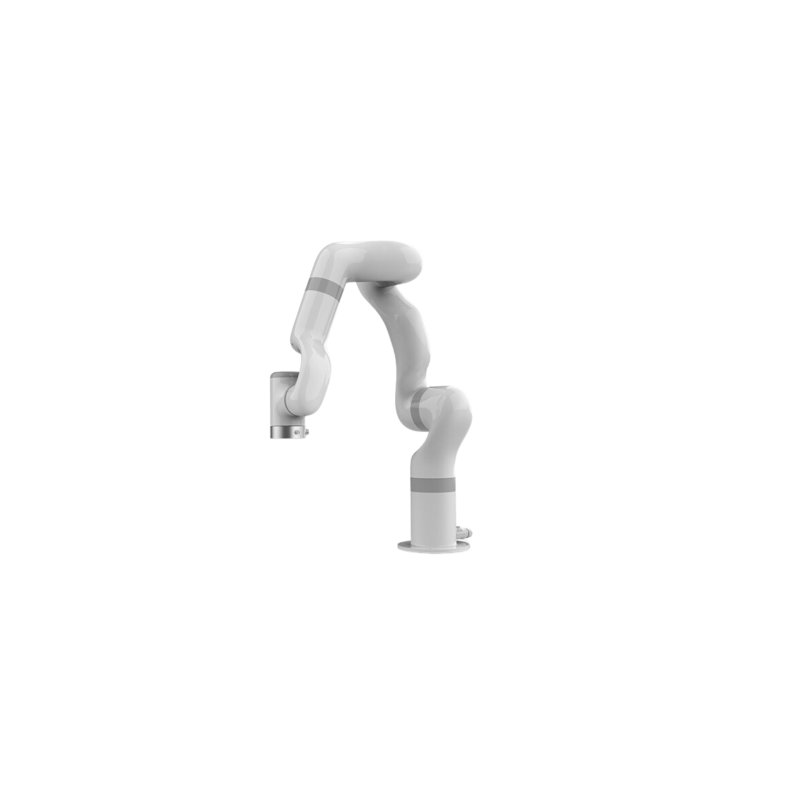
UFactory
11,781 €
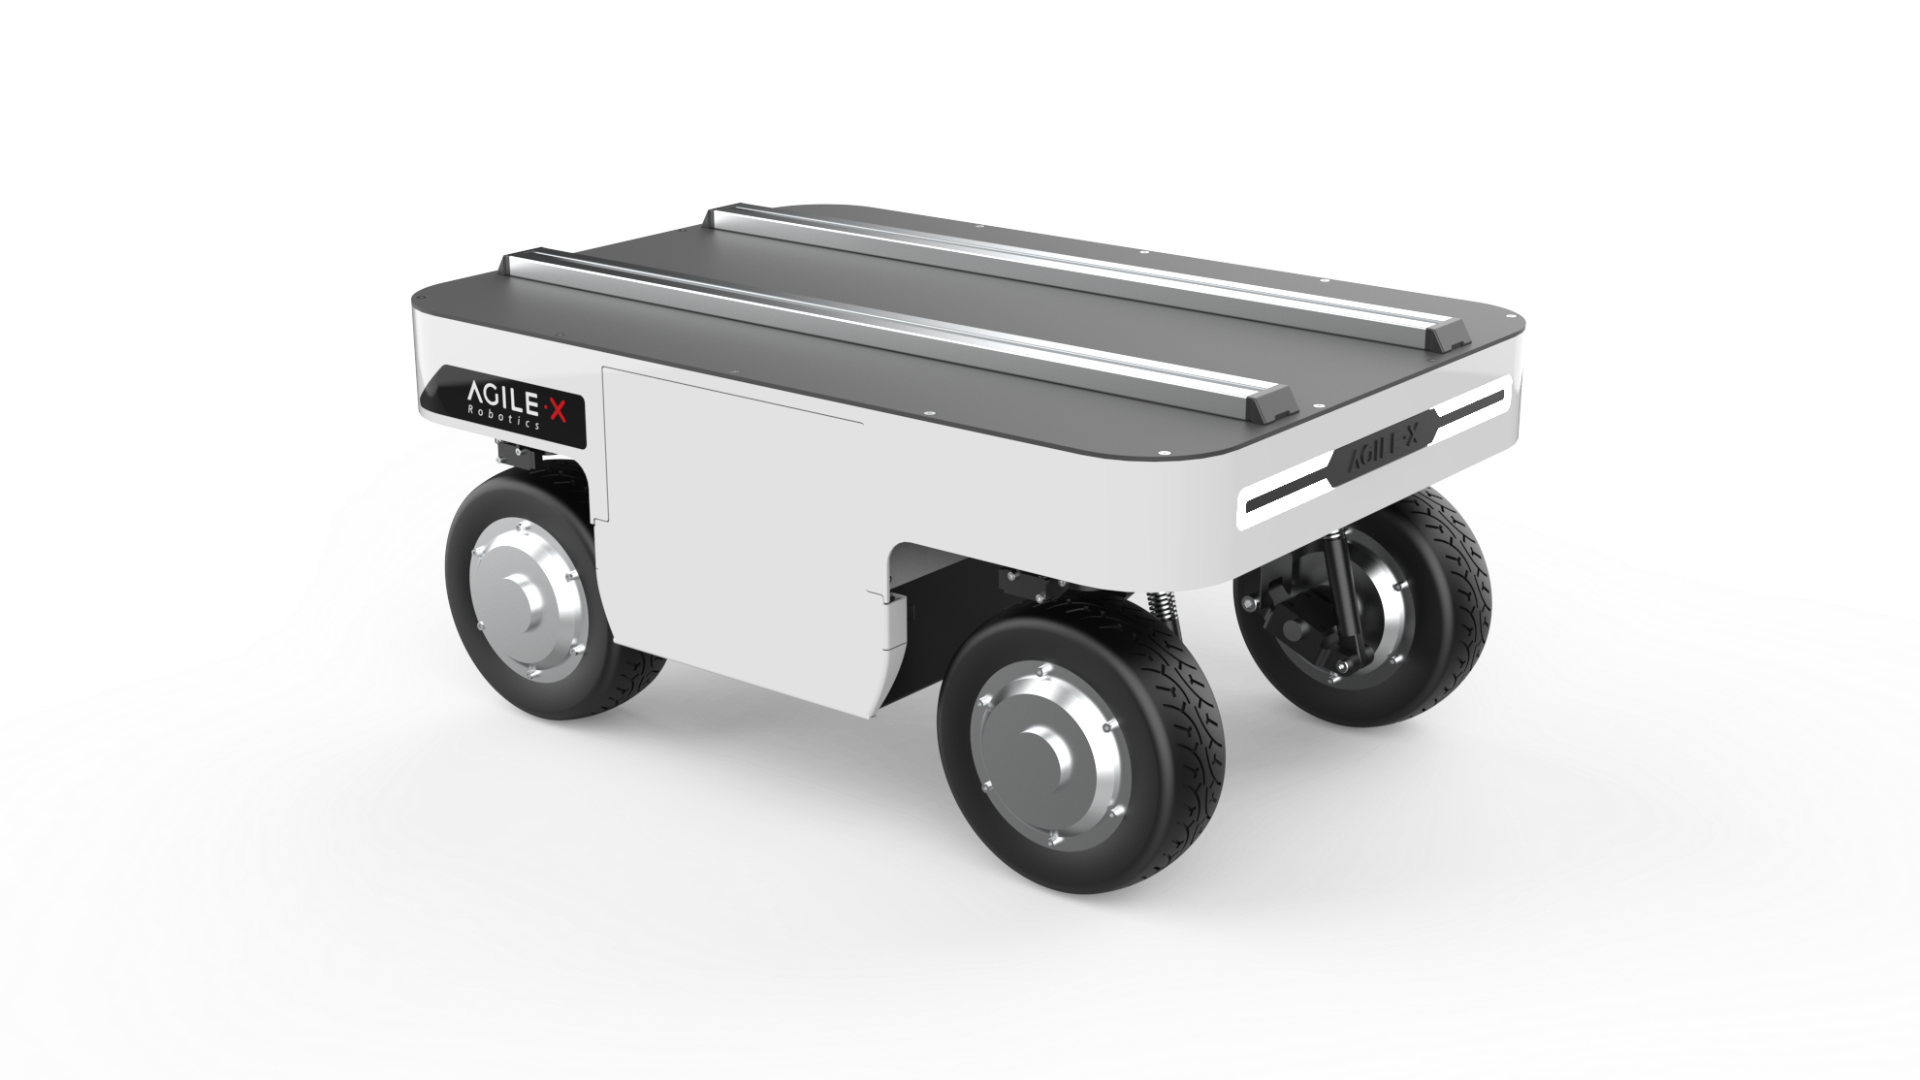
AgileX
£10,294.58
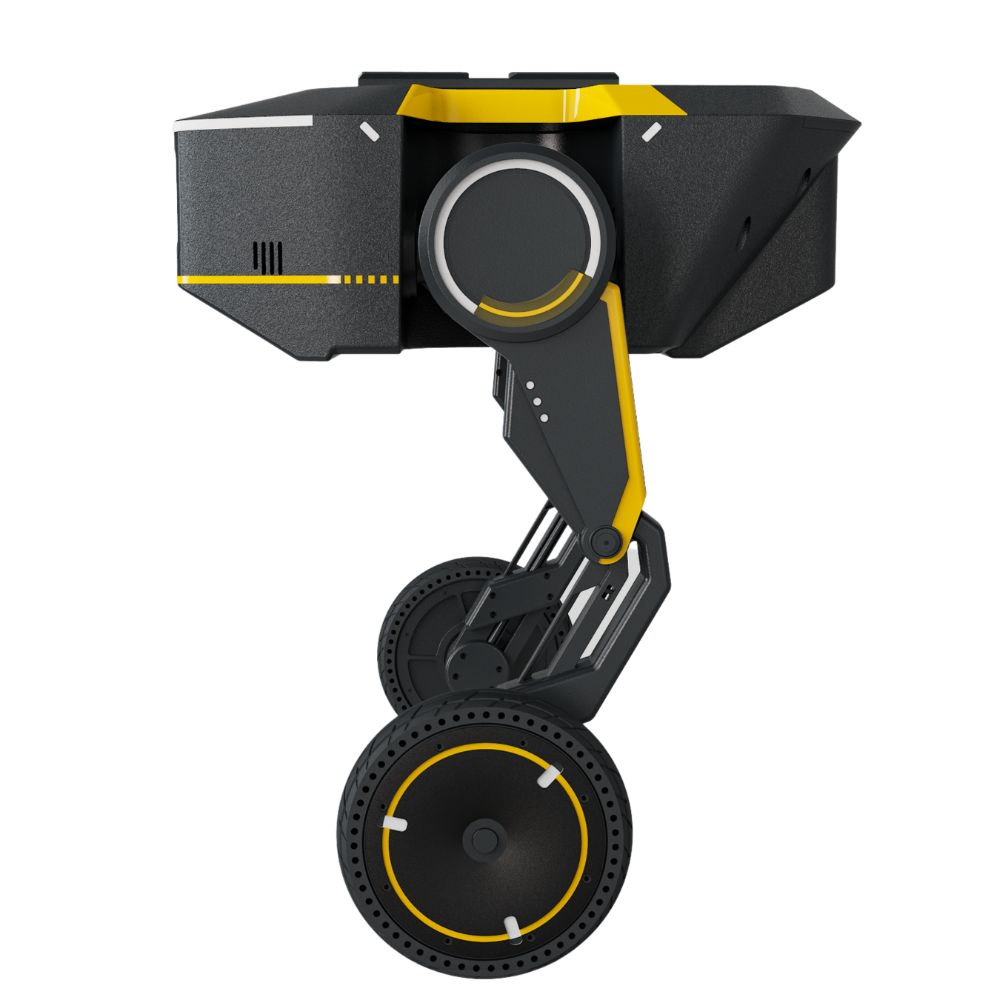
Direct Drive Tech
£10,650
🍪 Mga kagustuhan sa cookie
Gumagamit kami ng cookies upang masukat ang pagganap. Patakaran sa pagkapribado