Dnevno povprečje cen
Zneski v USD


A development-focused humanoid platform with 40 total degrees of freedom, two Dex3-1 force-controlled three-finger hands with tactile sensing, 100 TOPS computing power, stereo and wrist-mounted vision, and open secondary-development capabilities.
Unitree R1 EDU U4 (Pro B) expands the R1 EDU platform with two Dex3-1 force-controlled three-finger hands equipped with tactile sensing. Each hand provides 7 degrees of freedom, bringing the complete humanoid system to 40 total joint motors.
Unitree describes the R1 EDU platform as supporting fully open control interfaces for joints and sensors, mainstream simulation platforms, and high-power computing options, creating a flexible foundation for robotics research and secondary development.

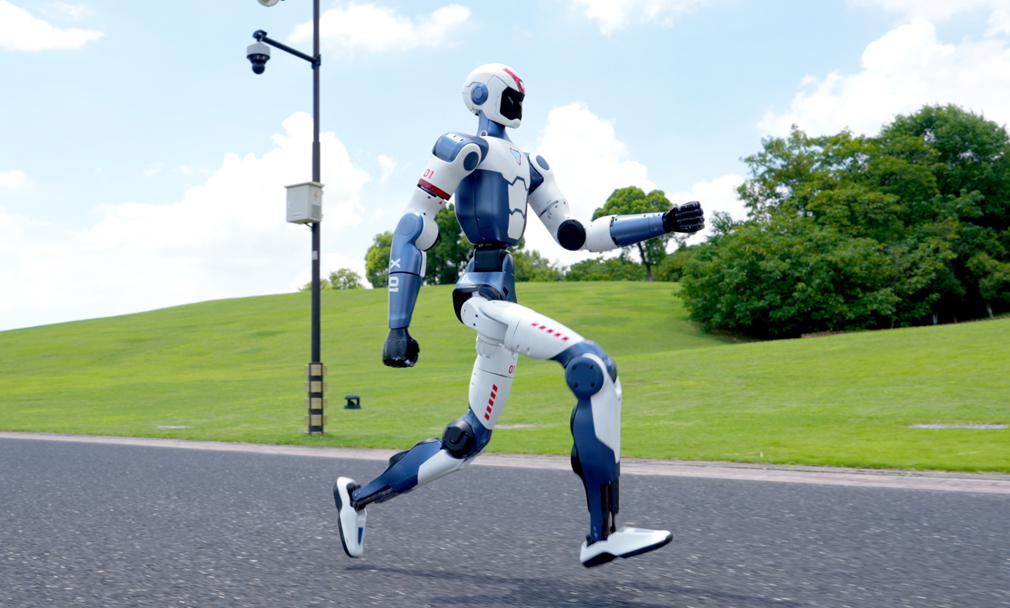
R1 EDU U4 combines advanced humanoid mobility with high-performance computing, stereo perception, dexterous manipulation, and tactile feedback.
The 26-DOF R1 EDU base is paired with two 7-DOF Dex3-1 hands, resulting in 40 total joint motors across the complete robot.
Each Dex3-1 hand provides 7 degrees of freedom and combines force and position hybrid control. Unitree specifies 33 tactile sensors per hand for pressure-based perceptual feedback.
The U4 configuration uses a 100 TOPS computing docking station for AI workloads and secondary development, together with AI algorithm technical support.
Perception hardware includes a stereo camera and wrist-mounted camera, with the R1 LiDAR kit available as an optional upgrade.

The Dex3-1 three-finger hand uses force and position hybrid control and provides 7 active degrees of freedom. Unitree specifies 33 tactile sensors on each hand, enabling pressure sensing across the palm, finger pads, and fingertips.
R1 EDU U4 combines an 8-core high-performance CPU, 100 TOPS computing dock, stereo and wrist-mounted cameras, wireless connectivity, and high-level and low-level development support.
A development-focused humanoid configuration with Dex3-1 force-controlled hands, 100 TOPS computing, multimodal perception, and a complete standard accessory set.
Specification |
R1 EDU U4 (Pro B) |
|---|---|
Dimensions (H × W × D), Standing |
47.6 × 14.1 × 7.5 in |
Weight With Battery |
Approx. 63.9 lbs |
Total Degrees of Freedom |
40 (26 + 7 + 7) |
DOF Per Leg / Waist / Arm / Head |
6 / 2 / 5 / 2 |
Dexterous Hands |
2 × Dex3-1 force-controlled three-finger hands; 7 DOF each (thumb: 3, index: 2, middle: 2); with tactile feedback |
Tactile Sensors |
33 tactile sensors per Dex3-1 hand |
Maximum Arm Payload |
4.4 lbs |
Calf + Thigh Length |
23.6 in |
Arm Reach |
Approx. 16.5 in |
Waist Joint Motion |
Y ±150° R ±30° |
Knee Joint Range |
-10° to +139° |
Hip Joint Range |
Y: ±157° P: -168° to +146° R: -60° to +100° |
Hollow Internal Wiring |
Yes, throughout all joints |
Joint Encoders |
Dual + single encoders |
Cooling System |
Localized air cooling |
Power Supply |
Lithium-ion battery |
Base Computing |
8-core high-performance CPU |
Built-in Docking Station |
100 TOPS computing; open for secondary development; includes AI algorithm technical support |
Perception Sensors |
Stereo camera + wrist-mounted camera; optional LiDAR kit |
Audio |
Standard speakers + microphone array |
Wireless |
Wi-Fi 6, Bluetooth 5.2 |
Battery Life |
Approx. 1 hour |
OTA Updates |
Smart OTA supported |
Customization |
High-level & low-level |
Simulation & SDK |
Robot models, Isaac Sim, simulation interfaces |
Included Accessories |
1 charger, 1 smart battery (quick-release), 1 remote control |
Warranty |
12-month whole-unit warranty |
Robot Accessories |
Remote control, charger, transport case |
Protective Mount |
Not included by default |
A development-focused humanoid platform with 40 total degrees of freedom, two Dex3-1 force-controlled three-finger hands with tactile sensing, 100 TOPS computing power, stereo and wrist-mounted vision, and open secondary-development capabilities.
Unitree R1 EDU U4 (Pro B) expands the R1 EDU platform with two Dex3-1 force-controlled three-finger hands equipped with tactile sensing. Each hand provides 7 degrees of freedom, bringing the complete humanoid system to 40 total joint motors.
Unitree describes the R1 EDU platform as supporting fully open control interfaces for joints and sensors, mainstream simulation platforms, and high-power computing options, creating a flexible foundation for robotics research and secondary development.
R1 EDU U4 combines advanced humanoid mobility with high-performance computing, stereo perception, dexterous manipulation, and tactile feedback.
The 26-DOF R1 EDU base is paired with two 7-DOF Dex3-1 hands, resulting in 40 total joint motors across the complete robot.
Each Dex3-1 hand provides 7 degrees of freedom and combines force and position hybrid control. Unitree specifies 33 tactile sensors per hand for pressure-based perceptual feedback.
The U4 configuration uses a 100 TOPS computing docking station for AI workloads and secondary development, together with AI algorithm technical support.
Perception hardware includes a stereo camera and wrist-mounted camera, with the R1 LiDAR kit available as an optional upgrade.
The Dex3-1 three-finger hand uses force and position hybrid control and provides 7 active degrees of freedom. Unitree specifies 33 tactile sensors on each hand, enabling pressure sensing across the palm, finger pads, and fingertips.
R1 EDU U4 combines an 8-core high-performance CPU, 100 TOPS computing dock, stereo and wrist-mounted cameras, wireless connectivity, and high-level and low-level development support.
A development-focused humanoid configuration with Dex3-1 force-controlled hands, 100 TOPS computing, multimodal perception, and a complete standard accessory set.
Specification |
R1 EDU U4 (Pro B) |
|---|---|
Dimensions (H × W × D), Standing |
47.6 × 14.1 × 7.5 in |
Weight With Battery |
Approx. 63.9 lbs |
Total Degrees of Freedom |
40 (26 + 7 + 7) |
DOF Per Leg / Waist / Arm / Head |
6 / 2 / 5 / 2 |
Dexterous Hands |
2 × Dex3-1 force-controlled three-finger hands; 7 DOF each (thumb: 3, index: 2, middle: 2); with tactile feedback |
Tactile Sensors |
33 tactile sensors per Dex3-1 hand |
Maximum Arm Payload |
4.4 lbs |
Calf + Thigh Length |
23.6 in |
Arm Reach |
Approx. 16.5 in |
Waist Joint Motion |
Y ±150° R ±30° |
Knee Joint Range |
-10° to +139° |
Hip Joint Range |
Y: ±157° P: -168° to +146° R: -60° to +100° |
Hollow Internal Wiring |
Yes, throughout all joints |
Joint Encoders |
Dual + single encoders |
Cooling System |
Localized air cooling |
Power Supply |
Lithium-ion battery |
Base Computing |
8-core high-performance CPU |
Built-in Docking Station |
100 TOPS computing; open for secondary development; includes AI algorithm technical support |
Perception Sensors |
Stereo camera + wrist-mounted camera; optional LiDAR kit |
Audio |
Standard speakers + microphone array |
Wireless |
Wi-Fi 6, Bluetooth 5.2 |
Battery Life |
Approx. 1 hour |
OTA Updates |
Smart OTA supported |
Customization |
High-level & low-level |
Simulation & SDK |
Robot models, Isaac Sim, simulation interfaces |
Included Accessories |
1 charger, 1 smart battery (quick-release), 1 remote control |
Warranty |
12-month whole-unit warranty |
Robot Accessories |
Remote control, charger, transport case |
Protective Mount |
Not included by default |


Zgodovina cen
Ena podatkovna točka na dan, izračunana kot povprečje glede na datum meritve.
Zneski v USD
Povprečja se izračunajo za vsak dan po UTC na podlagi vseh zabeleženih cen ponudb.

Unitree
$32.900
Unitree
$30.900

Unitree
$30.900

Unitree
$31.260

Unitree
$31.260

Unitree
od 41.900 zł
Unitree
$28.900
Unitree
$23.200

Unitree
$23.890
Unitree
$23.190
Unitree
$24.490
Unitree
$23.790
🍪 Nastavitve piškotkov
Piškotke uporabljamo za merjenje učinkovitosti. Pravilnik o zasebnosti