Dnevno povprečje cen
Zneski v USD


Control interface: RS485 / CAN / Modbus TCP
Operating voltage: 24 V ±10%
Quiescent current: 0.25 A
Peak current: 4 A
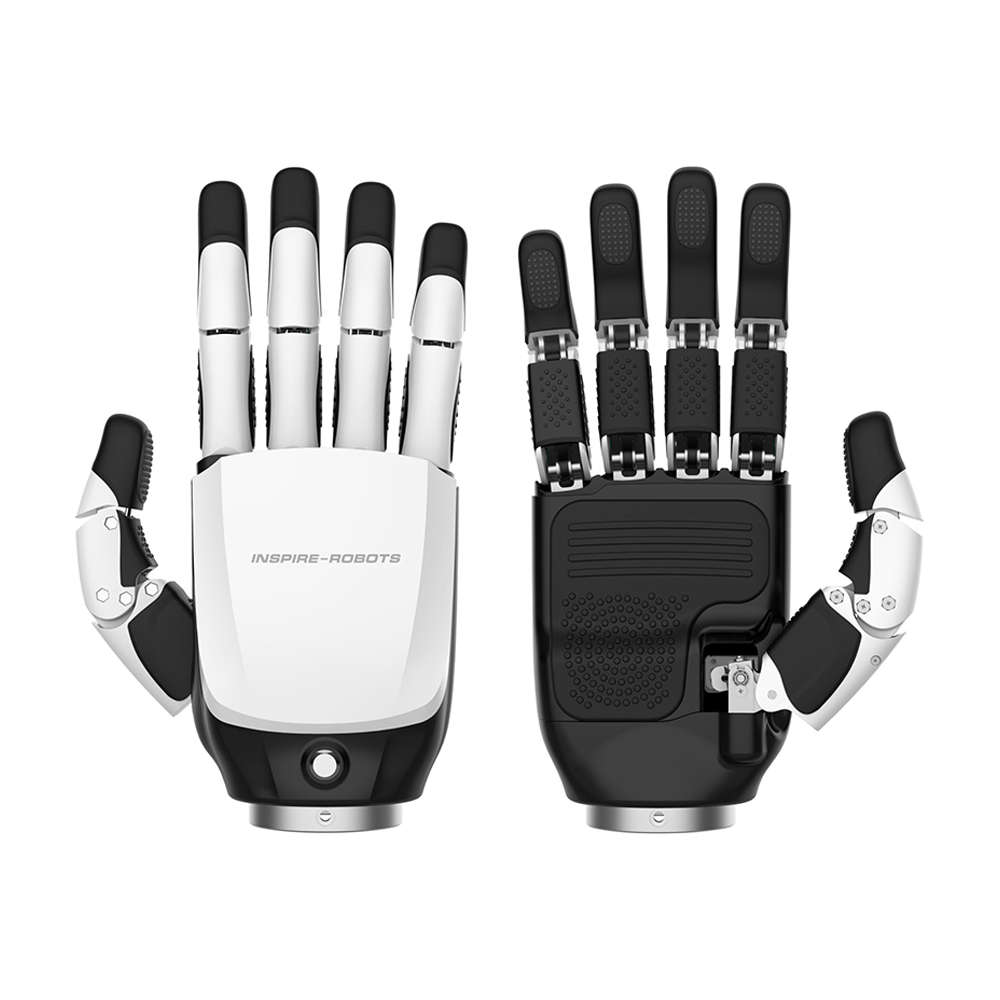
Finger configuration: 5-finger anthropomorphic hand
Degrees of freedom (DOF): 6
Number of joints: 12
Weight: 790 ± 10 g
Available versions: Left or right hand
Repeatability: ±0.20 mm
Thumb fingertip strength: 30 N
Finger fingertip strength: 28 N
Force resolution: ±0.05 N
Thumb lateral rotation range: 75° – 170°
Thumb lateral rotation speed: >130°/s
Thumb flexion speed: >130°/s
Four-finger flexion speed: >200°/s
Force sensors: 6
Tactile sensors: 5/ 17 depending on configuration
Tactile sensing range: 0–30 N
Tactile sensor accuracy: ≤5% FS
Maximum fingertip pressure: 8 kg
Hand closing time: ~0.8 s
Integrated multi-point tactile sensing (up to 17 sensors) for grasp feedback
High-precision force control and manipulation
Designed for humanoid robots, AI research, manipulation experiments, and robotic arms
Zgodovina cen
Ena podatkovna točka na dan, izračunana kot povprečje glede na datum meritve.
Zneski v USD
Povprečja se izračunajo za vsak dan po UTC na podlagi vseh zabeleženih cen ponudb.

Inspire Robots
$7500

Inspire Robots
5900 €

Inspire Robots
od $8680

Inspire Robots
8500 €

Inspire Robots
$6294

Inspire Robots
$6294

Inspire Robots
od $6500

Inspire Robots
$10.900
Inspire Robots
£5181,72

Inspire Robots
$4500

Inspire Robots
$4500

Inspire Robots
od $5600
🍪 Nastavitve piškotkov
Piškotke uporabljamo za merjenje učinkovitosti. Pravilnik o zasebnosti