Prezz medju ta’ kuljum
Ammonti f{currency}
Deskrizzjoni
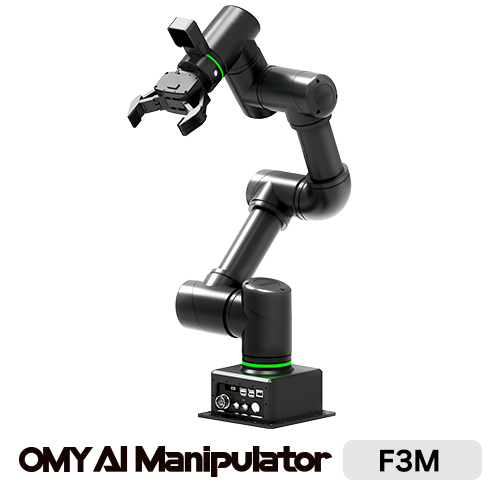
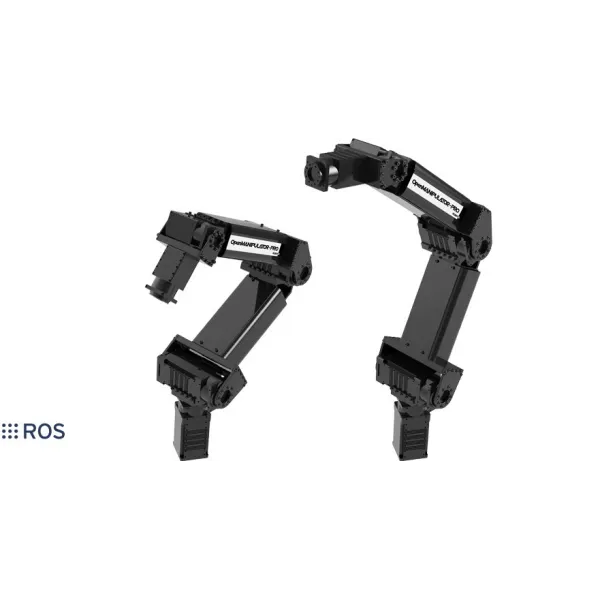
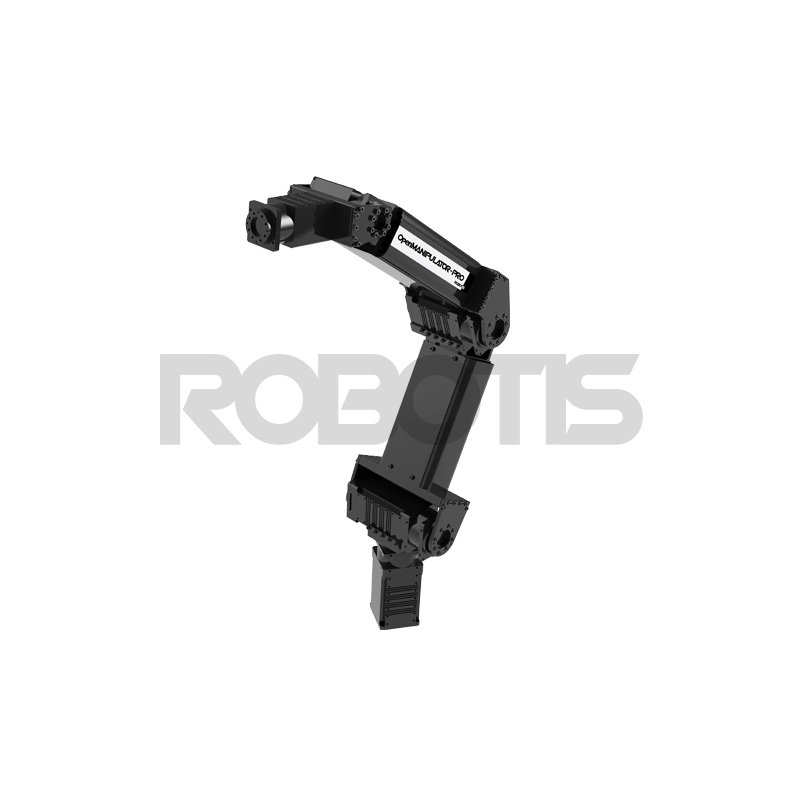
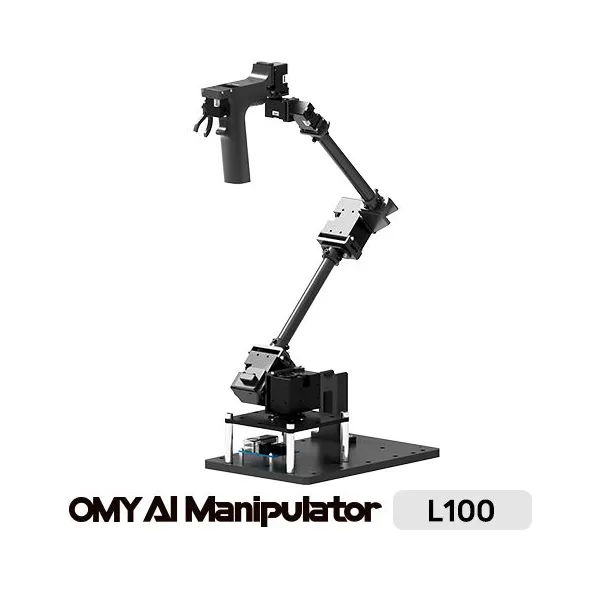
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. Plug-and-Play Minimizing research preparation time by providing hardware with integrated vision and grippers. Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-F3M (Follower) DOF 6 Payload 3 [kg] Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. Plug-and-Play Minimizing research preparation time by providing hardware with integrated vision and grippers. Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-F3M (Follower) DOF 6 Payload 3 [kg] Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Storja tal-prezzijiet
Punt tad-dejta wieħed għal kull jum, ikkalkulat bħala medja skont id-data tal-osservazzjoni.
Ammonti f{currency}
Il-medji jiġu kkalkulati għal kull jum UTC mill-prezzijiet kollha tal-offerti rreġistrati.

Robotis
$14,373.85
Robotis
£7,420.21
Robotis
£11,145.87

Robotis
$11,498.85
Robotis
13,923.95 €

Robotis
$4,834.51
Robotis
17,272.96 €
Robotis
15,549.95 €

Robotis
$16,176.02

Robotis
$17,248.85
Robotis
894.92 €
Robotis
3,291.60 €
🍪 Preferenzi tal-cookies
Aħna nużaw cookies biex inkejlu l-prestazzjoni. Politika tal-privatezza