Prezz medju ta’ kuljum
Ammonti f{currency}

Deskrizzjoni
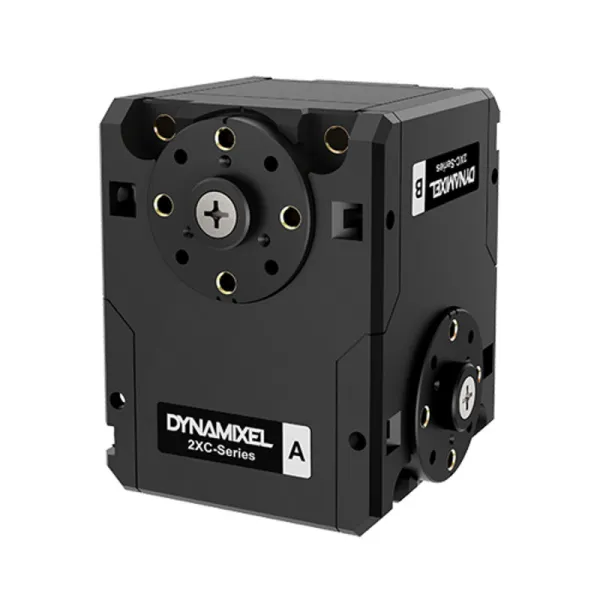
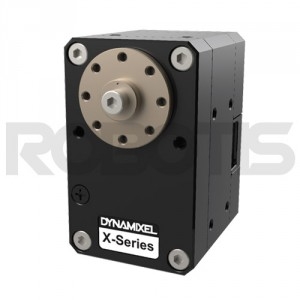
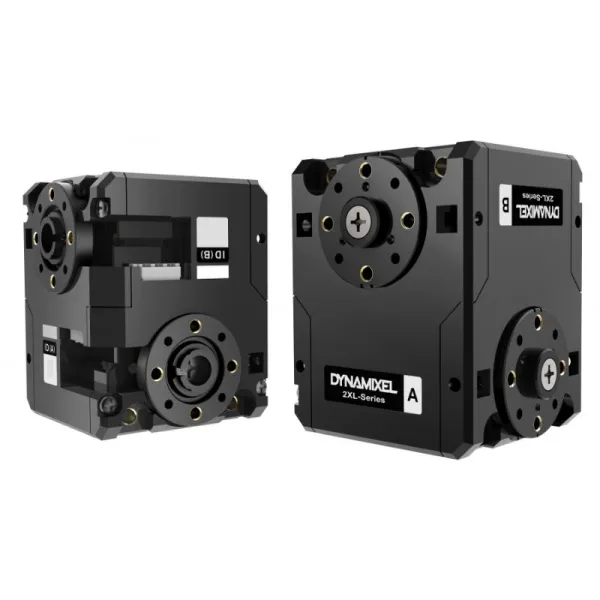
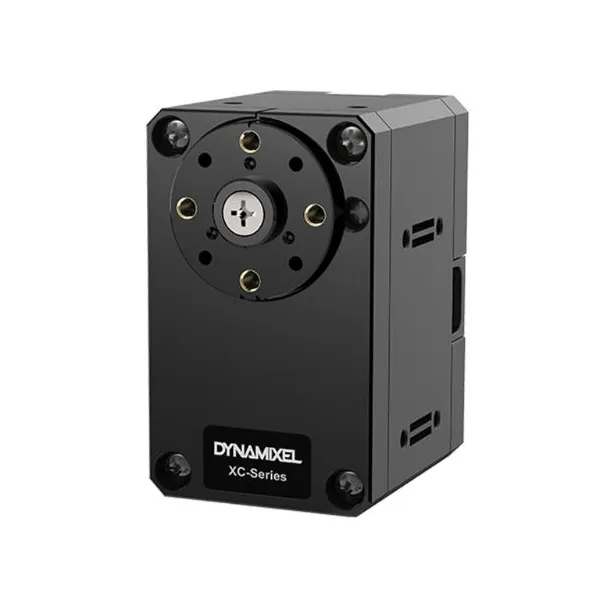
Features DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. The DYNAMIXEL 2XC series can control two axis with a single module, so it can be effectively applied to robot`s neck, shoulder, hip, wrist, and ankle. The 2XC series adopts new features that allow 360 degrees control mode with its contactless magnetic encoder and hollow back case assembly structure. Metal gear(Cutting Process) and Coreless motor are used for high durability. High compatibility with XL430, XM430, XH430. Package Components 2XC430-W250-T1Robot Cable-X3P 180mm1Bolt M2.5x510Bolt M2x510 * Idler Set(HN11-I101 Set) for assembling hinge frames are not included. Compatible Products Controller : OpenCM9.04 + 485 Expansion Board, OpenCR1.0, CM-550 Interface : USB2Dynamixel, U2D2 Factory Default Settings ID(A) : 1 ID(B) : 2 Baud Rate : 57600bps (User can change various settings including ID and baud rate according to environment) Various Cabling Methods Performance Comparison Caution DYNAMIXEL-X Series cable assembly through hollow case Organize the entangled cable before assembling the back case. Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error. The DYNAMIXEL-X Series adopted a new gold-plated JST connector for secure and reliable communication. The connector used for previous Dynamixel is Molex. Molex-JST conversion cable is not included with the purchase of 2XC430 Dynamixel, so you must purchase Molex-JST conversion cable separately to connect to the existing controller (OpenCM 485 expansion board, USB2Dynamixel). Specification Model Name 2XC430-W250-T MCU Cortex-M3 (72 [Mhz], 32 [bit]) Input Voltage Min. [V] 6.5 Recommended [V] 12.0 Max. [V] 14.8Performance Characteristics Voltage [V] 12.0 Stall Torque [N·m] 1.80 Stall Current [A] 1.4 No Load Speed [rpm] 64.0 No Load Current [A] 0.05Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] -Resolution Resolution [deg/pulse] 0.0879 Step [pulse] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg]) Maker : ams(www.ams.com), Part No : AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 72 Motor Coreless Baud Rate Min. [bps] 9,600 Max. [bps] 4,500,000 Control Algorithm PID Gear Type Spur Gear Material Metal Case Material Engineering Plastic Dimensions (WⅹHⅹD) [mm] 36 X 46.5 X 36 Dimensions (WⅹHⅹD) [inch] 1.4 X 1.83 X 1.41 Weight [g] 102.00 Weight [oz] 3.60 Gear Ratio 257.4 : 1 Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) TTL Level Multi Drop Bus ID 0 ~ 253 Feedback Position, Velocity, Load, Realtime tick, Trajectory, Temperature, Input Voltage, etc Protocol version 1.0 2.0(Default) Operating Mode / Angle Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 49 Link e-Manual Drawing Software Compatibility Guide Selection Guide DYNAMIXEL SDK
Features DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. The DYNAMIXEL 2XC series can control two axis with a single module, so it can be effectively applied to robot`s neck, shoulder, hip, wrist, and ankle. The 2XC series adopts new features that allow 360 degrees control mode with its contactless magnetic encoder and hollow back case assembly structure. Metal gear(Cutting Process) and Coreless motor are used for high durability. High compatibility with XL430, XM430, XH430. Package Components 2XC430-W250-T1Robot Cable-X3P 180mm1Bolt M2.5x510Bolt M2x510 * Idler Set(HN11-I101 Set) for assembling hinge frames are not included. Compatible Products Controller : OpenCM9.04 + 485 Expansion Board, OpenCR1.0, CM-550 Interface : USB2Dynamixel, U2D2 Factory Default Settings ID(A) : 1 ID(B) : 2 Baud Rate : 57600bps (User can change various settings including ID and baud rate according to environment) Various Cabling Methods Performance Comparison Caution DYNAMIXEL-X Series cable assembly through hollow case Organize the entangled cable before assembling the back case. Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error. The DYNAMIXEL-X Series adopted a new gold-plated JST connector for secure and reliable communication. The connector used for previous Dynamixel is Molex. Molex-JST conversion cable is not included with the purchase of 2XC430 Dynamixel, so you must purchase Molex-JST conversion cable separately to connect to the existing controller (OpenCM 485 expansion board, USB2Dynamixel). Specification Model Name 2XC430-W250-T MCU Cortex-M3 (72 [Mhz], 32 [bit]) Input Voltage Min. [V] 6.5 Recommended [V] 12.0 Max. [V] 14.8Performance Characteristics Voltage [V] 12.0 Stall Torque [N·m] 1.80 Stall Current [A] 1.4 No Load Speed [rpm] 64.0 No Load Current [A] 0.05Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] -Resolution Resolution [deg/pulse] 0.0879 Step [pulse] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg]) Maker : ams(www.ams.com), Part No : AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 72 Motor Coreless Baud Rate Min. [bps] 9,600 Max. [bps] 4,500,000 Control Algorithm PID Gear Type Spur Gear Material Metal Case Material Engineering Plastic Dimensions (WⅹHⅹD) [mm] 36 X 46.5 X 36 Dimensions (WⅹHⅹD) [inch] 1.4 X 1.83 X 1.41 Weight [g] 102.00 Weight [oz] 3.60 Gear Ratio 257.4 : 1 Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) TTL Level Multi Drop Bus ID 0 ~ 253 Feedback Position, Velocity, Load, Realtime tick, Trajectory, Temperature, Input Voltage, etc Protocol version 1.0 2.0(Default) Operating Mode / Angle Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 49 Link e-Manual Drawing Software Compatibility Guide Selection Guide DYNAMIXEL SDK
Storja tal-prezzijiet
Punt tad-dejta wieħed għal kull jum, ikkalkulat bħala medja skont id-data tal-osservazzjoni.
Ammonti f{currency}
Il-medji jiġu kkalkulati għal kull jum UTC mill-prezzijiet kollha tal-offerti rreġistrati.

Robotis
$298.89
Robotis
304.20 €
Robotis
£208.54
Robotis
£208.53
Robotis
£199.90
Robotis
£208.79

Robotis
$192.43
Robotis
152.16 €
Robotis
143.52 €
Robotis
143.52 €
Robotis
223.40 €
Robotis
223.08 €
🍪 Preferenzi tal-cookies
Aħna nużaw cookies biex inkejlu l-prestazzjoni. Politika tal-privatezza