Prezz medju ta’ kuljum
Ammonti f{currency}
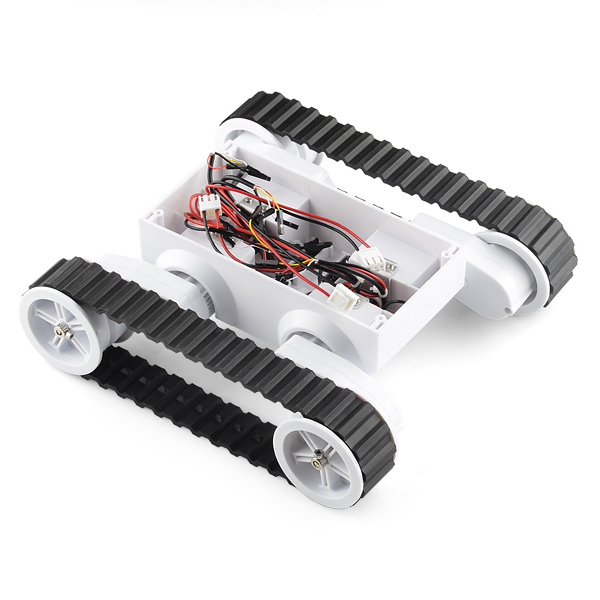
Deskrizzjoni
If you're looking for a chassis base for your next robot, look no further than the Rover 5. The Rover 5 uses 4 independent motors, each with a hall-effect quadrature encoder and gearbox. The entire gearbox assembly can be rotated at 5 degree increments for different clearance configurations. You can even replace the tank treads with traditional wheels. This isn't a wimpy or flimsy robot base. Weighing in at over 2.5 pounds without batteries, this base is heavy duty and can drive over quite a bit. Check the manual below for dimensional drawings. Features: Adjustable gear box angles 4 independent DC motors 4 independent hall-effect encoders Thick rubber tank treads 10Kg/cm stall torque per motor Documents: Manual Datasheet (Motors) Quadrature Encoder Example Remote Control Tutorial
If you're looking for a chassis base for your next robot, look no further than the Rover 5. The Rover 5 uses 4 independent motors, each with a hall-effect quadrature encoder and gearbox. The entire gearbox assembly can be rotated at 5 degree increments for different clearance configurations. You can even replace the tank treads with traditional wheels. This isn't a wimpy or flimsy robot base. Weighing in at over 2.5 pounds without batteries, this base is heavy duty and can drive over quite a bit. Check the manual below for dimensional drawings. Features: Adjustable gear box angles 4 independent DC motors 4 independent hall-effect encoders Thick rubber tank treads 10Kg/cm stall torque per motor Documents: Manual Datasheet (Motors) Quadrature Encoder Example Remote Control Tutorial
Storja tal-prezzijiet
Punt tad-dejta wieħed għal kull jum, ikkalkulat bħala medja skont id-data tal-osservazzjoni.
Ammonti f{currency}
Il-medji jiġu kkalkulati għal kull jum UTC mill-prezzijiet kollha tal-offerti rreġistrati.
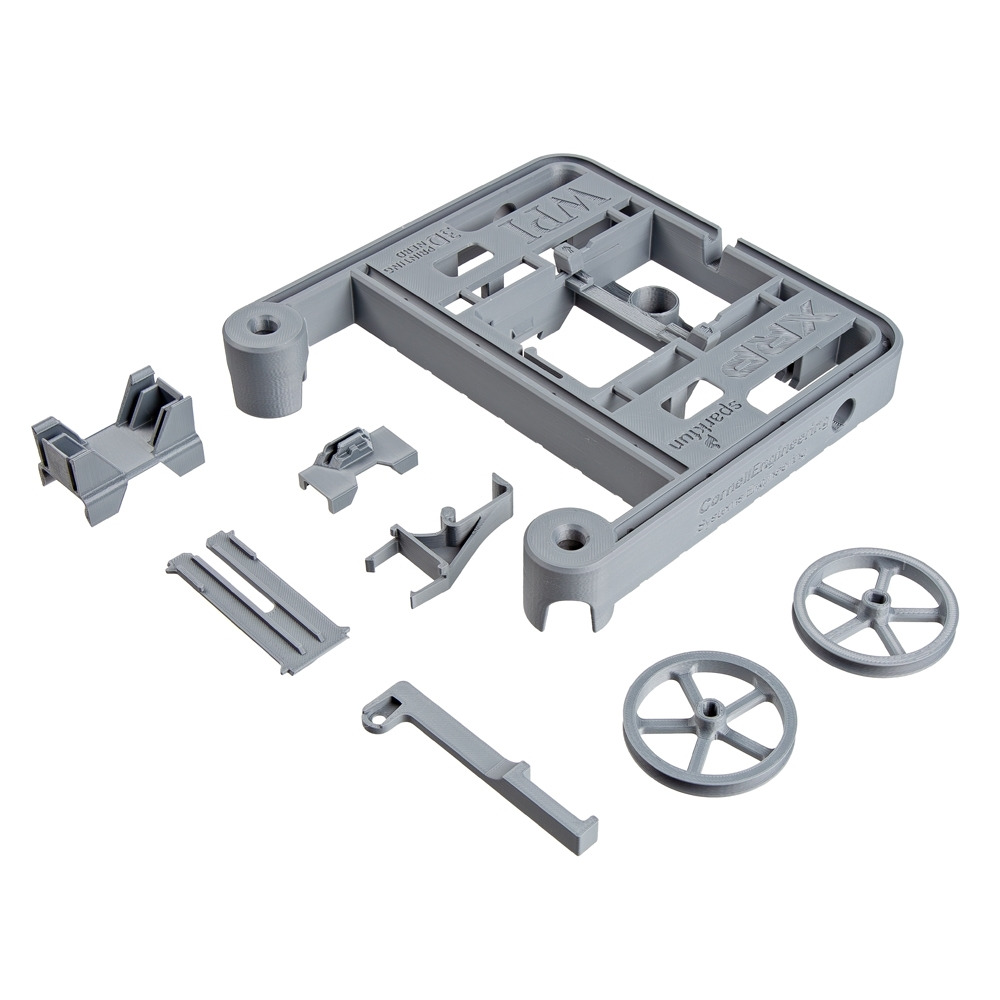
RoboSavvy
£29.77
RoboSavvy
£165.58
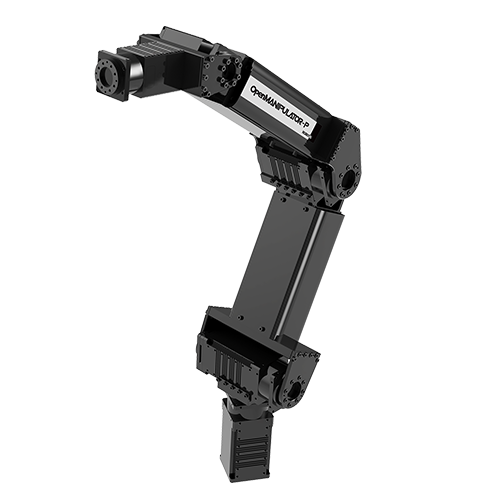
RoboSavvy
£11,291.33
Robotis
£60.33
Robotis
£61.17
Robotis
£56.58
Robotis
£52.67
Robotis
£56.42
Robotis
£61.25
Robotis
£53.04

Robotis
$56.24

Robotis
$63.14
🍪 Preferenzi tal-cookies
Aħna nużaw cookies biex inkejlu l-prestazzjoni. Politika tal-privatezza