Prezz medju ta’ kuljum
Ammonti f{currency}


Control interface: RS485 / CAN / Modbus TCP
Operating voltage: 24 V ±10%
Quiescent current: 0.25 A
Peak current: 4 A
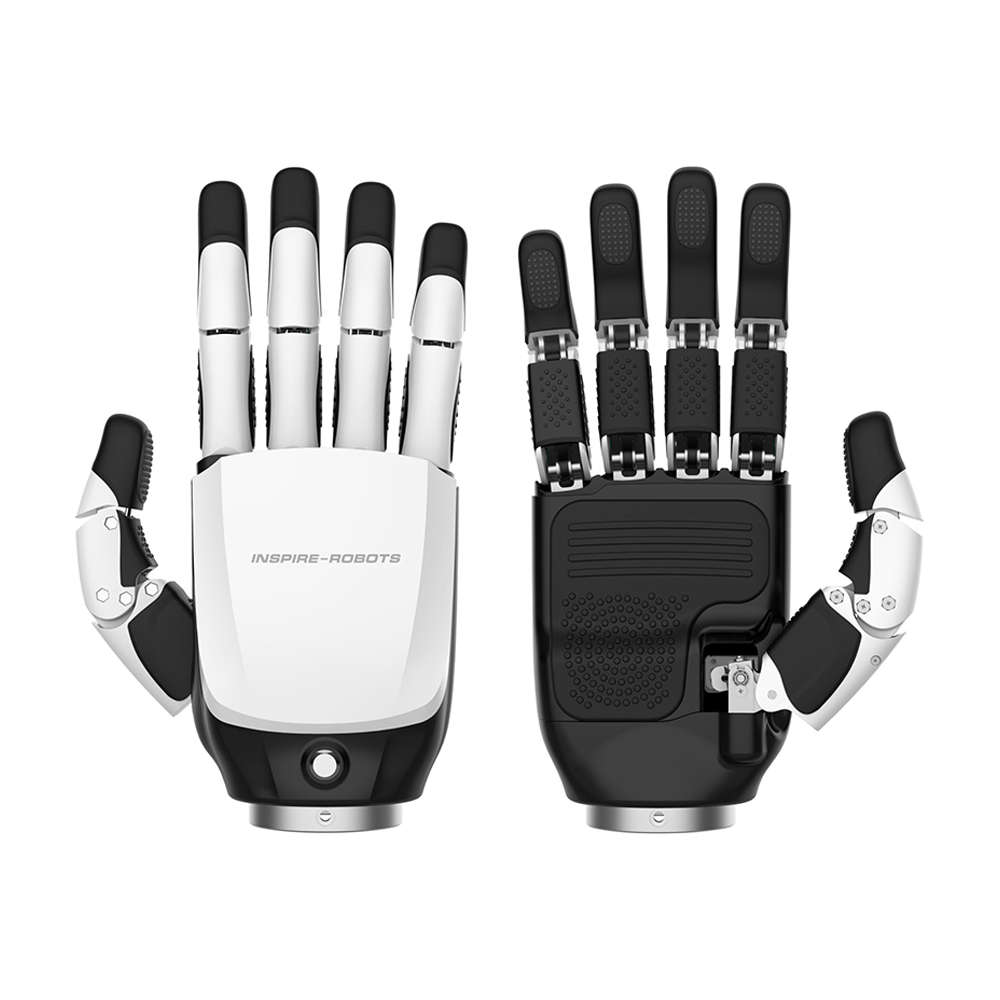
Finger configuration: 5-finger anthropomorphic hand
Degrees of freedom (DOF): 6
Number of joints: 12
Weight: 790 ± 10 g
Available versions: Left or right hand
Repeatability: ±0.20 mm
Thumb fingertip strength: 30 N
Finger fingertip strength: 28 N
Force resolution: ±0.05 N
Thumb lateral rotation range: 75° – 170°
Thumb lateral rotation speed: >130°/s
Thumb flexion speed: >130°/s
Four-finger flexion speed: >200°/s
Force sensors: 6
Tactile sensors: 5/ 17 depending on configuration
Tactile sensing range: 0–30 N
Tactile sensor accuracy: ≤5% FS
Maximum fingertip pressure: 8 kg
Hand closing time: ~0.8 s
Integrated multi-point tactile sensing (up to 17 sensors) for grasp feedback
High-precision force control and manipulation
Designed for humanoid robots, AI research, manipulation experiments, and robotic arms
Storja tal-prezzijiet
Punt tad-dejta wieħed għal kull jum, ikkalkulat bħala medja skont id-data tal-osservazzjoni.
Ammonti f{currency}
Il-medji jiġu kkalkulati għal kull jum UTC mill-prezzijiet kollha tal-offerti rreġistrati.

Inspire Robots
$7,500

Inspire Robots
5,900 €

Inspire Robots
minn $8,680

Inspire Robots
8,500 €

Inspire Robots
$6,294

Inspire Robots
$6,294

Inspire Robots
minn $6,500

Inspire Robots
$10,900
Inspire Robots
£5,181.72

Inspire Robots
$4,500

Inspire Robots
$4,500

Inspire Robots
minn $5,600
🍪 Preferenzi tal-cookies
Aħna nużaw cookies biex inkejlu l-prestazzjoni. Politika tal-privatezza