Prezz medju ta’ kuljum
Ammonti f{currency}


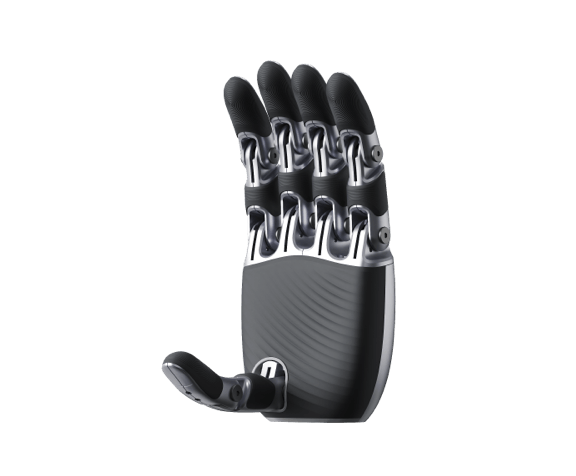
The myGripper H100 is a three-finger dexterous robotic hand developed by Elephant Robotics specifically designed for applications in robotics research, education, and other related scenarios. It can be used for myCobot Pro 630 and Mercury Series. Equipped with 6 high performance digital servo motors, the H100 enables multi-parameter control, including output torque, motion speed, and absolute position. It supports high-frequency 100Hz communication, allowing real-time status monitoring during grasping operations, fully meeting the data collection needs of research environments.

Enables actions such as giving a thumbs-up, waving, and gesture control in collaboration with robots.

Capable of handling various objects, including fruits, food, tools, and equipment.

Performs precision tasks and demonstrations in laboratory settings.

Ideal for hands-on learning in robotics courses.

| What's Included? | Three-Finger Dexterous Hand *1 |
|---|---|
| Dual-Head 8-Pin Aviation Connector Cable *1 | |
| Extension Cable *1 | |
| USB to 485 Module *1 | |
| 8-Pin Aviation Connector with 2m Extension Cable *1 | |
| USB Data Cable *1 |
The myGripper H100 offers a standardized robot driver library that can be easily downloaded and installed via PyPI. It supports querying joint angles, encoder positions, speed data, and more. Compatible with both ROS1 and ROS2, it includes support for the RVIZ simulation environment, allowing users to display the robot arm's state and collect real-time data.

| Name | myGripper H100 | ||||
|---|---|---|---|---|---|
| Payload | 500g | ||||
| Self-Weight | 780g | ||||
| Stroke (Diameter) | 0 ¨C 130mm | ||||
| Motion Speed | 60 degrees per second per joint | ||||
| Number of Fingers | 3 fingers (corresponding to the human thumb, index finger, and ring finger) | ||||
| Movable Joints | 6 | ||||
| Motor Type | Servo motor supporting current, position, and speed control | ||||
| Lifespan | 1,000,000 cycles or more | ||||
| Electrical Interface | M8 Pin aviation connector | ||||
| Power Parameters | 24V, 2A | ||||
| Communication Interface | RS485 | ||||
| Communication Speed | Above 50Hz | ||||
| Data Format | Hexadecimal (Hex), 8N1 | ||||
| Protocol Type | MODBUS | ||||
| Programming Language | Python | ||||
| Main Control Chip | ESP32 | ||||
| Main Control Parameters | 240MHz dual-core, 600 DMIPS, 520KB SRAM, Wi-Fi, dual-mode Bluetooth | ||||
| Compatible Models |
|
||||
| Recommended Control Methods |
|
Storja tal-prezzijiet
Punt tad-dejta wieħed għal kull jum, ikkalkulat bħala medja skont id-data tal-osservazzjoni.
Ammonti f{currency}
Il-medji jiġu kkalkulati għal kull jum UTC mill-prezzijiet kollha tal-offerti rreġistrati.
Unitree
£1,106.26

Linkerbot
1,287.09 €

Elephant Robotics
minn $974

Elephant Robotics
minn $949
 Bejgħ
Elephant Robotics
$918.99minn $849Iffranka 8%

Unitree
$1,490

Unitree
$1,490

Linkerbot
minn $1,450

Sharpa
minn $30,000

Agibot
minn $4,420

Agibot
minn $5,360

Agibot
minn 19,900 zł
🍪 Preferenzi tal-cookies
Aħna nużaw cookies biex inkejlu l-prestazzjoni. Politika tal-privatezza