Nero 7-Axis Robotic Arm

Nero 7-Axis Robotic Arm

Nero 7-Axis Robotic Arm
AgileX | A-000000-07951
€2,400.00 VAT incl. €2,000.00 VAT excl.

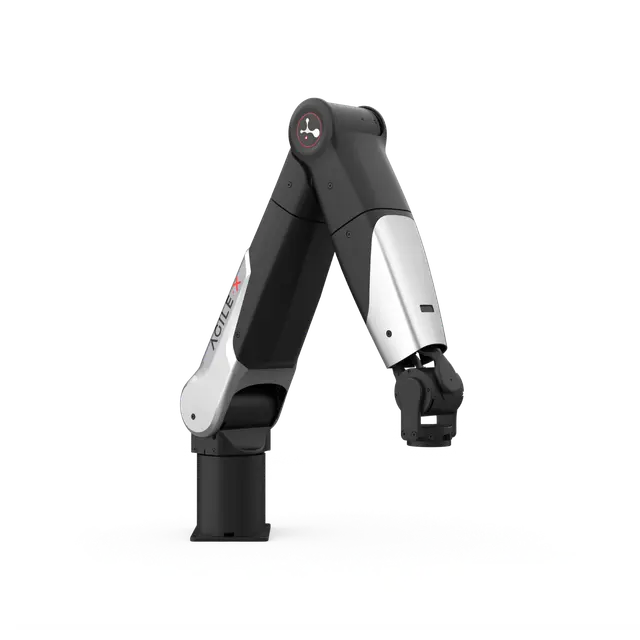
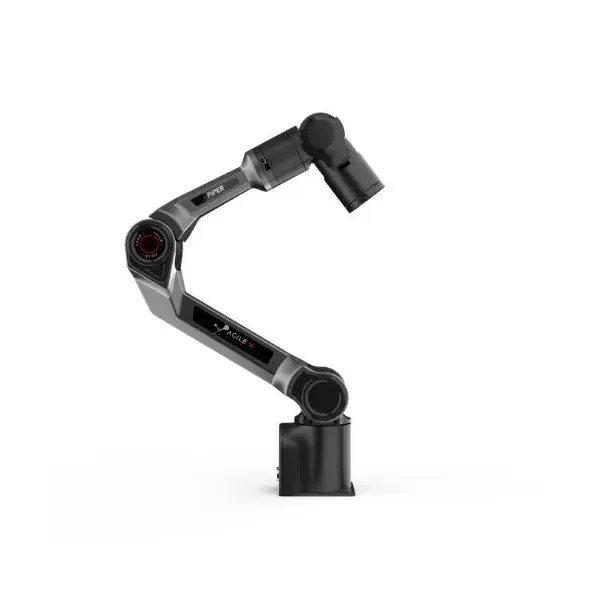
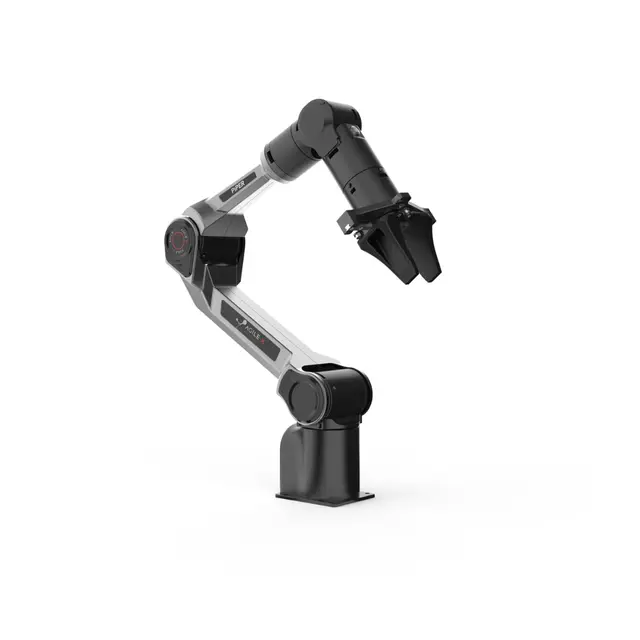
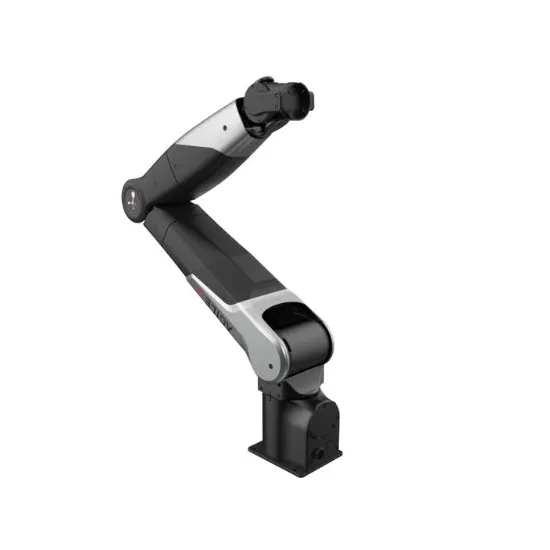
The Nero is a 7-axis (7-DoF) robotic arm designed for research work in humanoid robotics and Embodied AI. Its lightweight design and open architecture make laboratory integration, experimentation, and deployment across different setups (tabletop, side mounting, inverted) easier.

Quantity
Delivery within 6 to 8 weeks

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

A 7-axis arm built for dexterity, precision, and software integration

7-DoF dexterity, payload and repeatability

With its 7-DoF structure, the Nero aims to provide a wide spatial workspace and wrist-like dexterity close to human motion. It relies on in-house developed motors and a body weighing around 4.8 kg, capable of handling a 3 kg payload. The ±0.1 mm repeatability supports tasks requiring reproducible execution, notably within test protocols and data collection workflows.

R&D control and software integration (CAN/HTTP/TCP, Python, ROS)

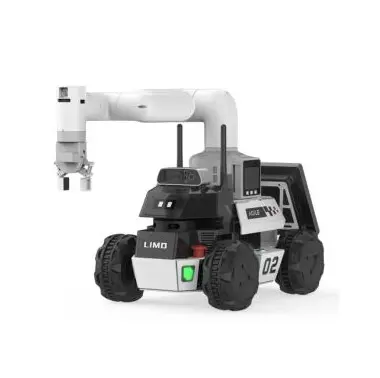
Control is designed for R&D use: CAN, HTTP and TCP interfaces, as well as multiple operation modes (for example drag teaching, offline trajectories, API, PC control). Integration with common robotics environments is streamlined via a Python SDK and ROS 1 / ROS 2 compatibility. The arm can also be combined with an AgileX mobile base to build a complete experimentation platform oriented toward an Embodied Platform.

Modular mechanical interfaces for grippers, dexterous hands and tools

On the mechanical side, the modular approach targets compatibility with various end-effectors: grippers, dexterous hands and other tools, so the system can be adapted to experimental protocol needs (physical interaction, manipulation, imitation learning, etc.).

Research use cases: humanoid robotics, learning, and capability validation

  • Embodied AI: end-to-end validation of perception → decision → action pipelines (control, execution, and evaluation).
  • Humanoid robotics: experiments on dexterity, 7-axis kinematics, and “human-like” manipulation.
  • Imitation learning: demonstrations via drag teaching, dataset creation, and policy comparison.
  • Reinforcement learning: repeatable trajectory execution, robustness testing, and interaction scenarios.
  • Physical interaction data collection: dataset generation for analysis and training (interaction quality and reproducibility).
  • ROS integration: application prototyping (ROS 1 / ROS 2) and development of experimental pipelines.
  • Mobile platform: integration with an AgileX mobile base to test mobile manipulation scenarios.

Technical specifications of the AgileX Nero arm

  • Degrees of freedom: 7
  • Reach: 580 mm
  • Weight: 4.8 kg
  • Payload: 3 kg
  • Repeatability: ±0.1 mm
  • Input voltage: DC 24 V
  • Noise: < 60 dB
  • Communication: CAN, HTTP, TCP
  • Control methods: drag teaching, offline trajectory, API, PC
  • Software compatibility: Python SDK, ROS 1, ROS 2
  • External interfaces: Power ×1, CAN ×1, Network ×1
  • Power consumption: max power < 120 W; average power < 40 W
  • Operating environment: 0–50°C; 25–85% RH, non-condensing
  • Mounting: table / side / inverted (upside down)
  • Base installation dimensions: 70 mm × 70 mm; M5 × 4
  • Max joint speed: J1 180°/s, J2 180°/s, J3 180°/s, J4 225°/s, J5 225°/s, J6 225°/s, J7 225°/s
  • Joint range of motion: J1 -157° to 157°, J2 -15° to 190°, J3 -160° to 160°, J4 -60° to 125°, J5 -160° to 160°, J6 -43° to 58°, J7 -90° to 90°

Nero robotic arm resources

Storja tal-prezzijiet

Storja tal-prezz medju

Punt tad-dejta wieħed għal kull jum, ikkalkulat bħala medja skont id-data tal-osservazzjoni.

Prezz medju ta’ kuljum

Ammonti f{currency}

$2,634.47
Grafika tal-istorja tal-prezz medju f{currency}Grafika tal-linji b’61 osservazzjoni minn 02 Ott 2026 sa 22 Nov 2026.$2,634.50$2,634.49$2,634.48$2,634.47$2,634.46Ott 2Ott 14Ott 27Nov 9Nov 2202 Ott 2026: medja ta’ $2,634.4703 Ott 2026: medja ta’ $2,634.4704 Ott 2026: medja ta’ $2,634.4705 Ott 2026: medja ta’ $2,634.4706 Ott 2026: medja ta’ $2,634.4707 Ott 2026: medja ta’ $2,634.4708 Ott 2026: medja ta’ $2,634.4709 Ott 2026: medja ta’ $2,634.4710 Ott 2026: medja ta’ $2,634.4711 Ott 2026: medja ta’ $2,634.4712 Ott 2026: medja ta’ $2,634.4713 Ott 2026: medja ta’ $2,634.4714 Ott 2026: medja ta’ $2,634.4715 Ott 2026: medja ta’ $2,634.4716 Ott 2026: medja ta’ $2,634.4717 Ott 2026: medja ta’ $2,634.4718 Ott 2026: medja ta’ $2,634.4719 Ott 2026: medja ta’ $2,634.4720 Ott 2026: medja ta’ $2,634.4721 Ott 2026: medja ta’ $2,634.4722 Ott 2026: medja ta’ $2,634.4723 Ott 2026: medja ta’ $2,634.4724 Ott 2026: medja ta’ $2,634.4725 Ott 2026: medja ta’ $2,634.4726 Ott 2026: medja ta’ $2,634.4727 Ott 2026: medja ta’ $2,634.4728 Ott 2026: medja ta’ $2,634.4729 Ott 2026: medja ta’ $2,634.4730 Ott 2026: medja ta’ $2,634.4731 Ott 2026: medja ta’ $2,634.4701 Nov 2026: medja ta’ $2,634.4702 Nov 2026: medja ta’ $2,634.4703 Nov 2026: medja ta’ $2,634.4704 Nov 2026: medja ta’ $2,634.4705 Nov 2026: medja ta’ $2,634.4706 Nov 2026: medja ta’ $2,634.4707 Nov 2026: medja ta’ $2,634.4708 Nov 2026: medja ta’ $2,634.4709 Nov 2026: medja ta’ $2,634.4710 Nov 2026: medja ta’ $2,634.4711 Nov 2026: medja ta’ $2,634.4712 Nov 2026: medja ta’ $2,634.4713 Nov 2026: medja ta’ $2,634.4714 Nov 2026: medja ta’ $2,634.4715 Nov 2026: medja ta’ $2,634.4716 Nov 2026: medja ta’ $2,634.4717 Nov 2026: medja ta’ $2,634.4718 Nov 2026: medja ta’ $2,634.4719 Nov 2026: medja ta’ $2,634.4720 Nov 2026: medja ta’ $2,634.4721 Nov 2026: medja ta’ $2,634.4722 Nov 2026: medja ta’ $2,634.47

Il-medji jiġu kkalkulati għal kull jum UTC mill-prezzijiet kollha tal-offerti rreġistrati.