Harga purata harian
Jumlah dalam USD
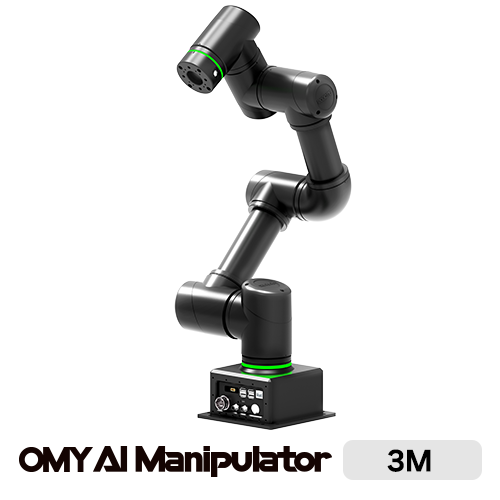
Penerangan
Features Custom Manipulator Easy integration of 3rd-party components (such as hands, sensors, vision systems) depending on the working environment. Providing customizable development environment (C, C#, Python, etc.) via the DYNAMIXEL SDK. Plug-and-Play Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-3M DOF 6 Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Features Custom Manipulator Easy integration of 3rd-party components (such as hands, sensors, vision systems) depending on the working environment. Providing customizable development environment (C, C#, Python, etc.) via the DYNAMIXEL SDK. Plug-and-Play Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-3M DOF 6 Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Sejarah harga
Satu titik data bagi setiap hari, dipuratakan mengikut tarikh pemerhatian.
Jumlah dalam USD
Purata dikira bagi setiap hari UTC berdasarkan setiap harga tawaran yang direkodkan.
Robotis
13,923.95 €

Robotis
$11,498.85
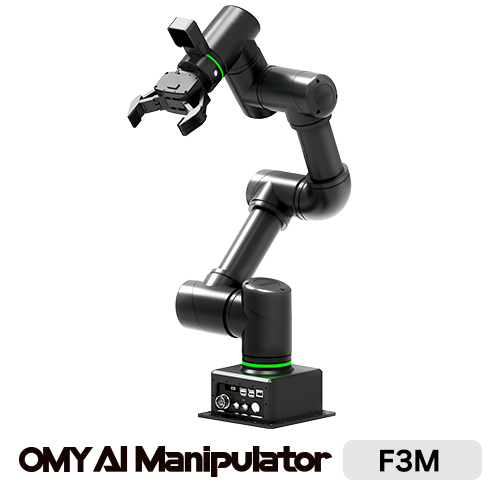
Robotis
£9,313.13

Robotis
$4,834.51
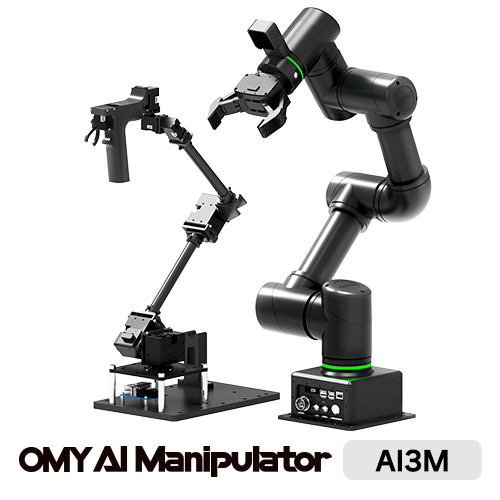
Robotis
£11,145.87

Robotis
$14,373.85
Robotis
894.92 €
Robotis
17,272.96 €
Robotis
3,291.60 €
Robotis
444 €
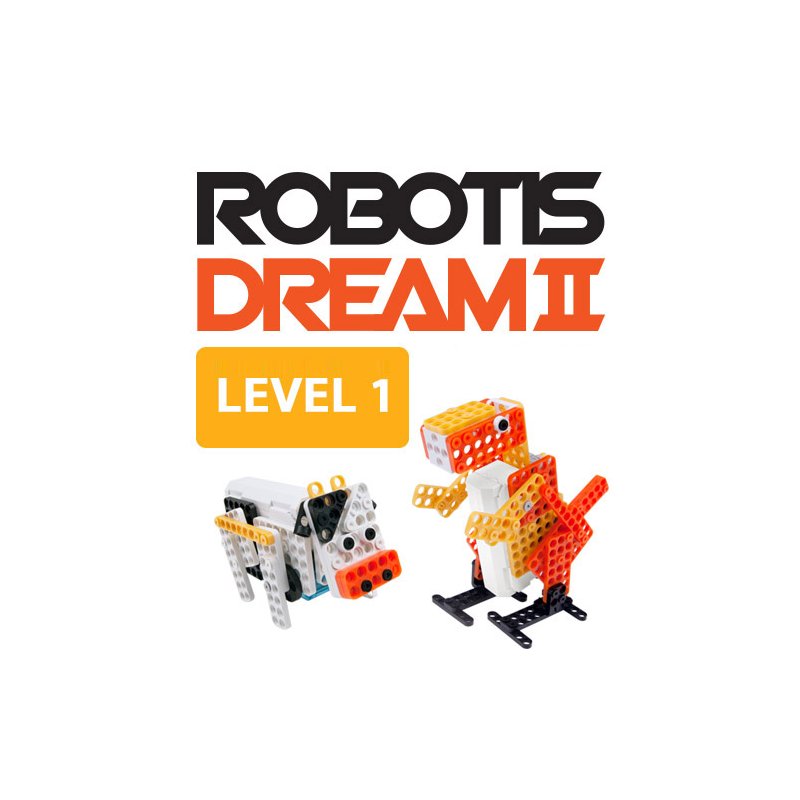
Robotis
157.95 €
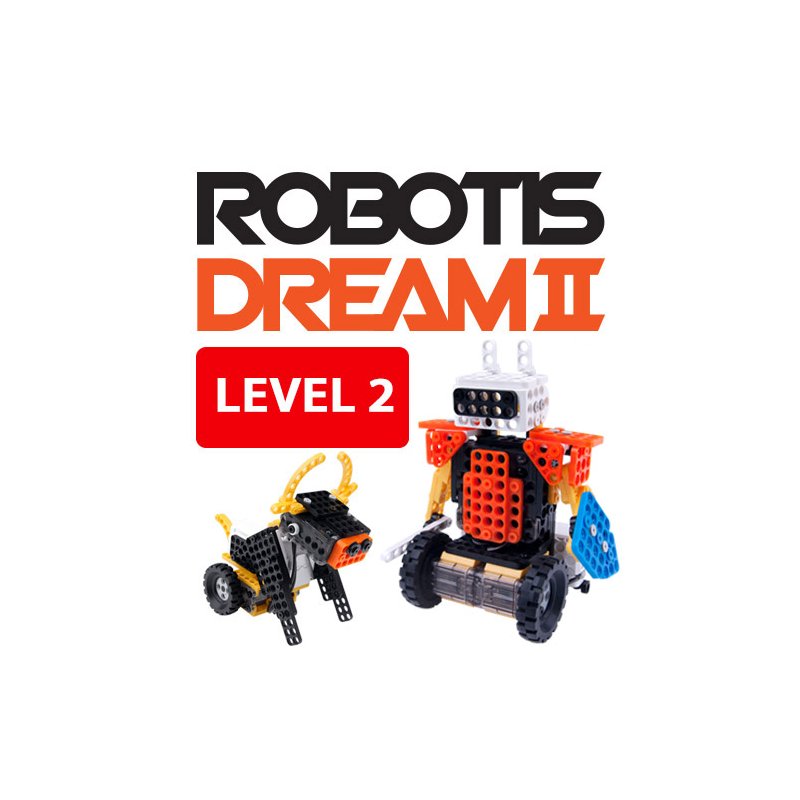
Robotis
157.95 €
🍪 Keutamaan kuki
Kami menggunakan kuki untuk mengukur prestasi. Dasar Privasi