Harga purata harian
Jumlah dalam USD
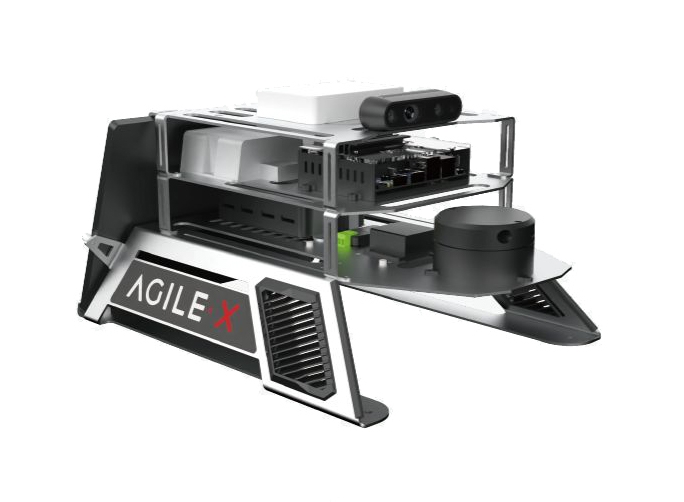
Penerangan
Equipped with a full suite of sensors to support indoor SLAM, Navigation and Vision based applications. A powerful NVIDIA Jetson Nano computer comes pre-installed with Linux and ROS Ubuntu 18.4. What's Included Research & Development Kit Research & Development Kit - Pro Nvidia Jetson Nano ARM A57 @ 1.43 GHz CPU 128 Maxwell GPU 4GB 64 LPDDR4 25.6GB/s HDMI/DP, USB 3.0, USB 2.0 Micro-B Nvidia Xavier ARM v8.2 64 CPU 512 Tensor Core Volta GPIJ 32 GB 256 LPDDR4x 32 GBeMMC5.1 HDMI 2.0sUSB 3.1s RJ45 EAl-G4 Lidar Rotate 360-degree scan ning distances measurement and 0.26-0.30 angular resolution 5-12Hz scanning frequency and 9000 times/S high-speed ranging 0.1-16m ranging radius magnetic wireless technology and low-loss industrial design VLP16 Lidar 3600 horizontal scanning and 0.1-0.40 angular resolution ±150 Vertical scanning and 20 angular resolution 5-20Hz scanning frequency, up to 300,000 point-data/S output and 01-100m ranging radius IP67 protection level and ultra-long service life Realsense D435 Stereo depth camera FOV = 86 x 57 degrees Depth Output resolution: 1280 x 720 Depth frame rate up to 90 fps Ideal range .3 to 3 meters Portable 11.6 inch monitor 480g/8mm ultra-thi 1920*1080P USB Type-C direct connection Full integration (Hardware / Software / Mounting) Pre-installed with Linux and ROS Ubuntu 18.4 Pre-installed hardware drivers allowing all sensors to be controlled by onboard PC. Fully integrated sensor mounting plates. Methodically designed for highest IP rating, and best placement of sensor. Allows for easy access and additional integration of new components. Compatible with Scout Mini, Tracer, SCOUT 2,0 and BUNKER. Onboard open source SLAM based mapping Development tools include viz, Gazebo and Nomachine. Communication (Ros) nodes are provided for mapping and navigation. .price-match { background-color: #b3ffb3; color: #000000; padding: 20px; text-align: center; border-radius: 10px; box-shadow: 0 2px 4px rgba(0, 0, 0, 0.1); font-family: Arial, sans-serif; } .price-match p { margin: 0; } .price-match strong { color: #000000; font-weight: bold; } Equipped with a full suite of sensors to support indoor SLAM, Navigation and Vision based applications. A powerful NVIDIA Jetson Nano computer comes pre-installed with Linux and ROS Ubuntu 18.4. Compatible with Scout Mini, Tracer, SCOUT 2,0 and BUNKER. PRICE MATCH GUARANTEE We guarantee the best price in the market. If you find a better offer, let us know and we will beat it! More information: Terms & Conditions
Equipped with a full suite of sensors to support indoor SLAM, Navigation and Vision based applications. A powerful NVIDIA Jetson Nano computer comes pre-installed with Linux and ROS Ubuntu 18.4. What's Included Research & Development Kit Research & Development Kit - Pro Nvidia Jetson Nano ARM A57 @ 1.43 GHz CPU 128 Maxwell GPU 4GB 64 LPDDR4 25.6GB/s HDMI/DP, USB 3.0, USB 2.0 Micro-B Nvidia Xavier ARM v8.2 64 CPU 512 Tensor Core Volta GPIJ 32 GB 256 LPDDR4x 32 GBeMMC5.1 HDMI 2.0sUSB 3.1s RJ45 EAl-G4 Lidar Rotate 360-degree scan ning distances measurement and 0.26-0.30 angular resolution 5-12Hz scanning frequency and 9000 times/S high-speed ranging 0.1-16m ranging radius magnetic wireless technology and low-loss industrial design VLP16 Lidar 3600 horizontal scanning and 0.1-0.40 angular resolution ±150 Vertical scanning and 20 angular resolution 5-20Hz scanning frequency, up to 300,000 point-data/S output and 01-100m ranging radius IP67 protection level and ultra-long service life Realsense D435 Stereo depth camera FOV = 86 x 57 degrees Depth Output resolution: 1280 x 720 Depth frame rate up to 90 fps Ideal range .3 to 3 meters Portable 11.6 inch monitor 480g/8mm ultra-thi 1920*1080P USB Type-C direct connection Full integration (Hardware / Software / Mounting) Pre-installed with Linux and ROS Ubuntu 18.4 Pre-installed hardware drivers allowing all sensors to be controlled by onboard PC. Fully integrated sensor mounting plates. Methodically designed for highest IP rating, and best placement of sensor. Allows for easy access and additional integration of new components. Compatible with Scout Mini, Tracer, SCOUT 2,0 and BUNKER. Onboard open source SLAM based mapping Development tools include viz, Gazebo and Nomachine. Communication (Ros) nodes are provided for mapping and navigation.
Sejarah harga
Satu titik data bagi setiap hari, dipuratakan mengikut tarikh pemerhatian.
Jumlah dalam USD
Purata dikira bagi setiap hari UTC berdasarkan setiap harga tawaran yang direkodkan.
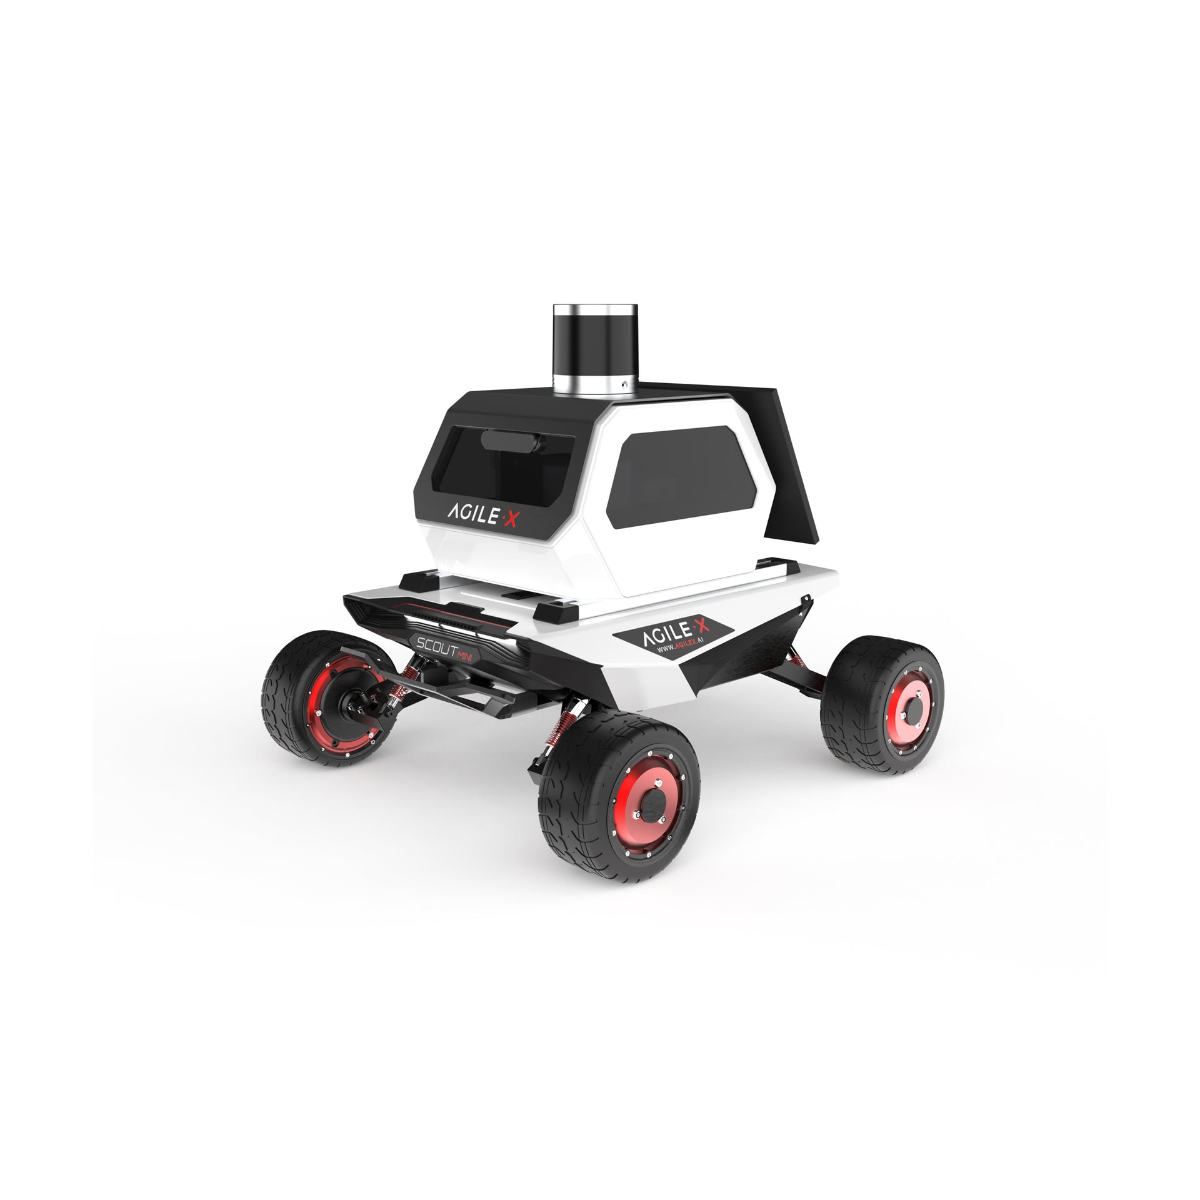
AgileX
£6,653
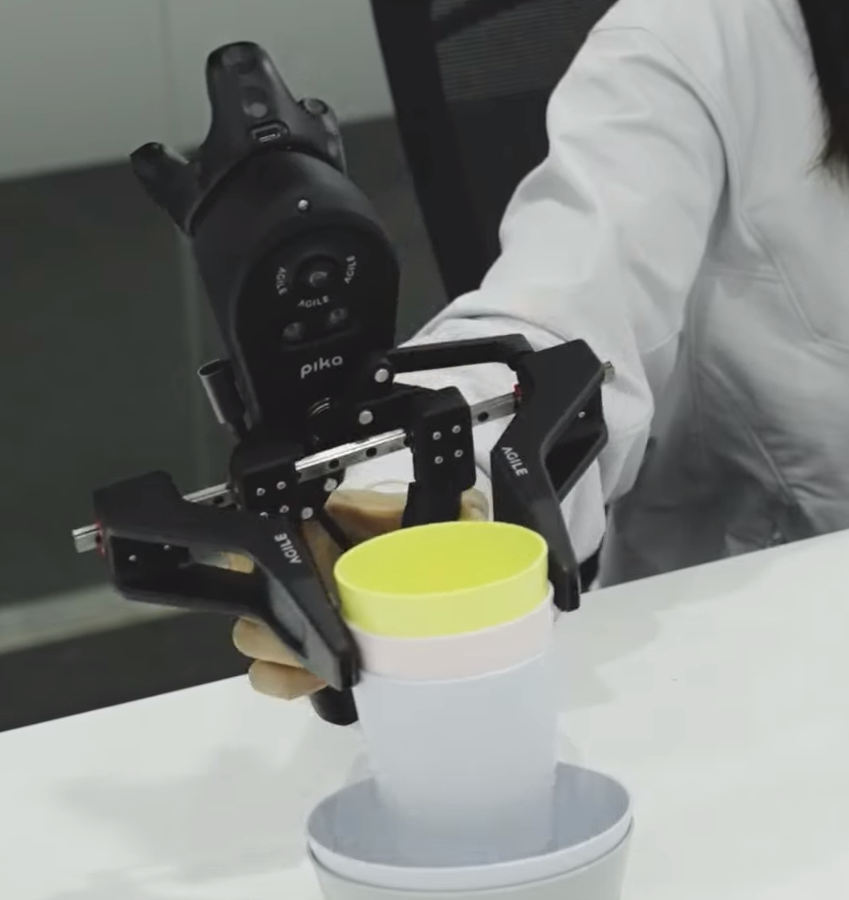
AgileX
£4,988.16
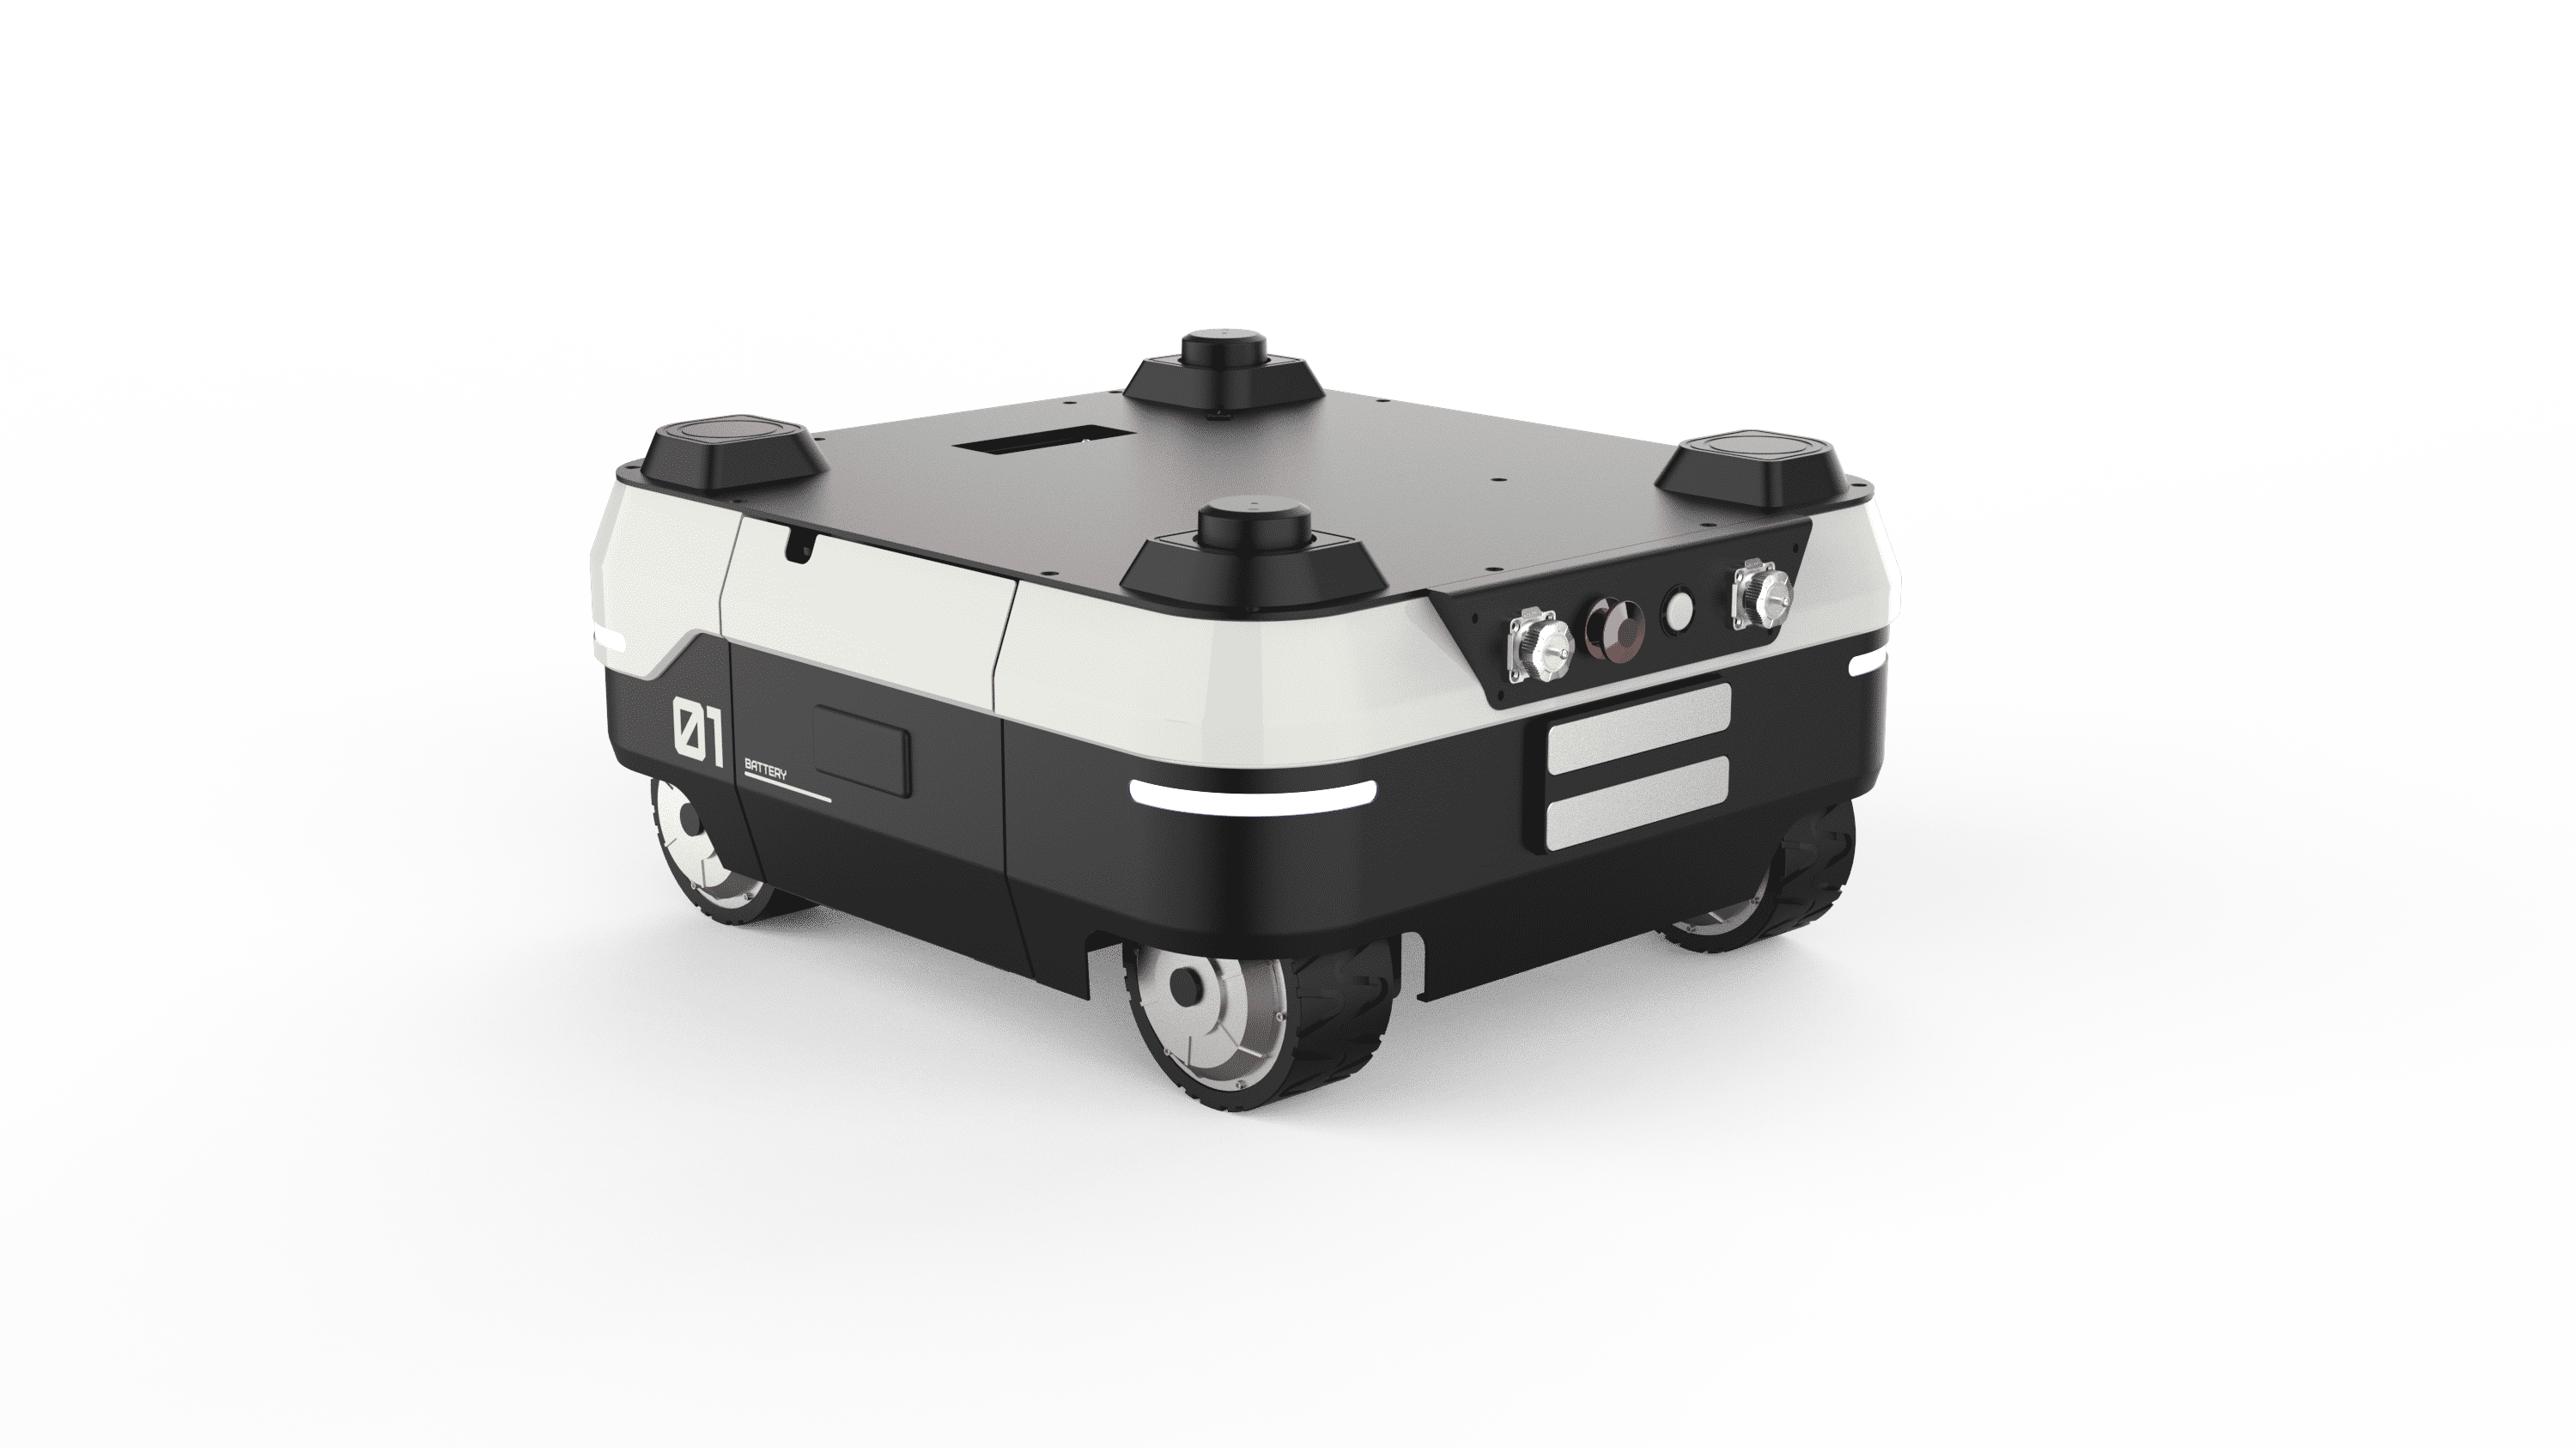
AgileX
£3,158.11

AgileX
$9,500
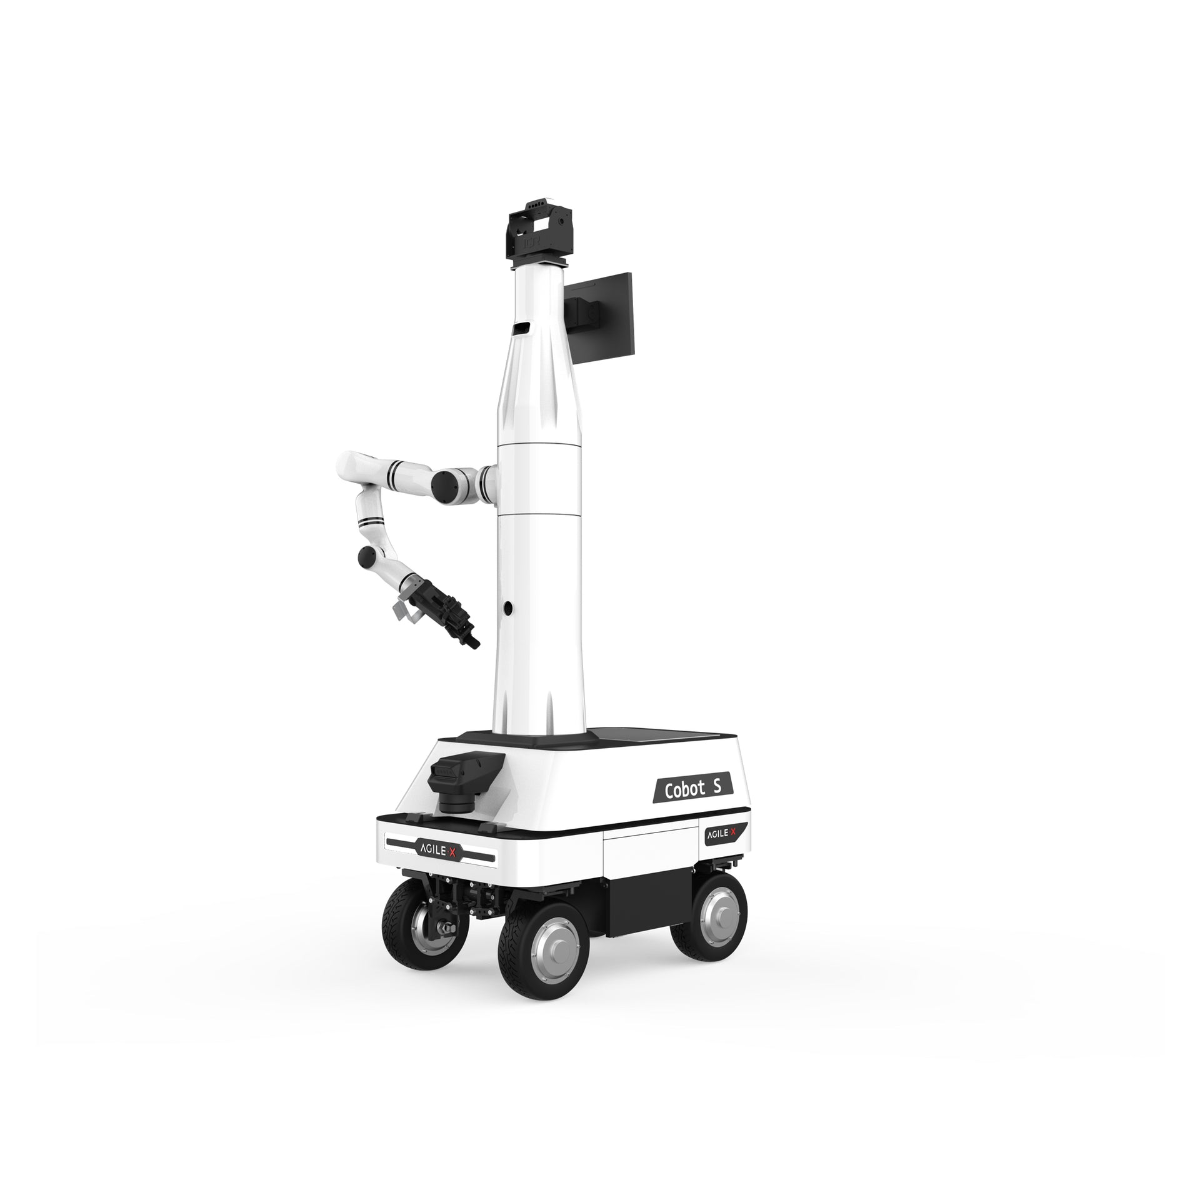
AgileX
£39,533.92
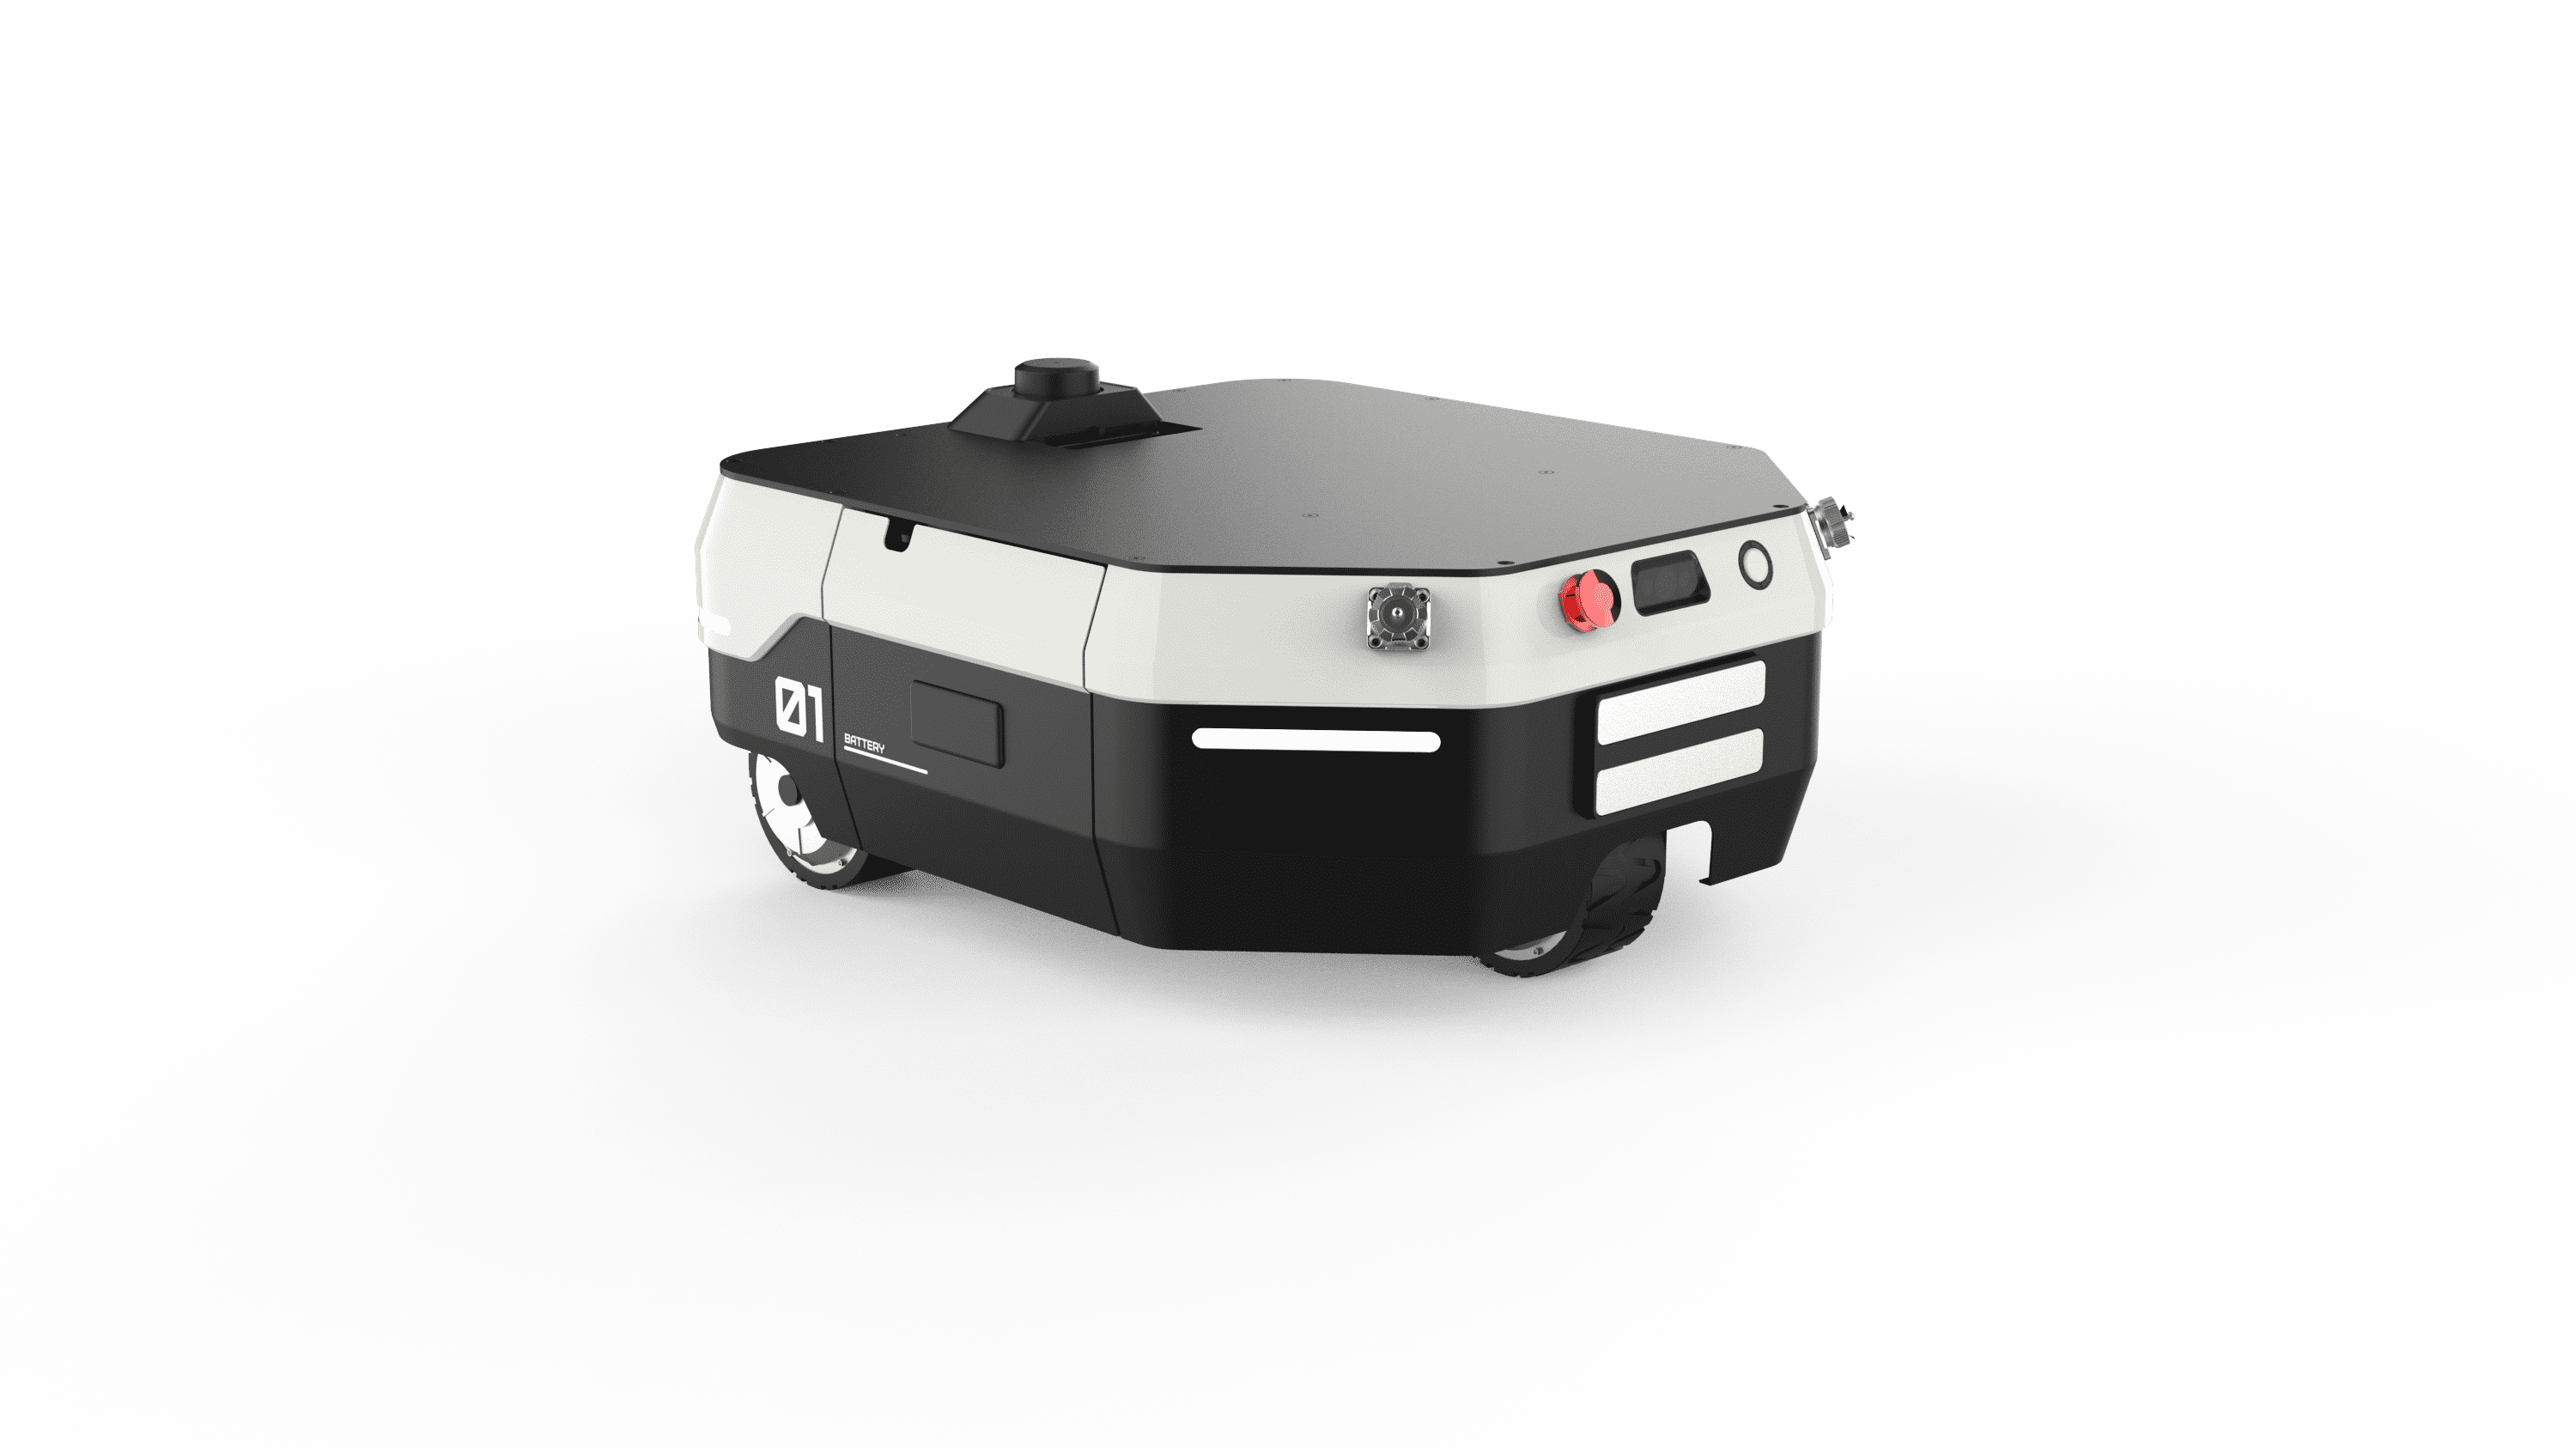
AgileX
£2,784.62

AgileX
$17,500

AgileX
$18,500

Agibot
5,900 zł

Agibot
5,900 zł

Unitree
$6,200

Unitree
$5,900
🍪 Keutamaan kuki
Kami menggunakan kuki untuk mengukur prestasi. Dasar Privasi