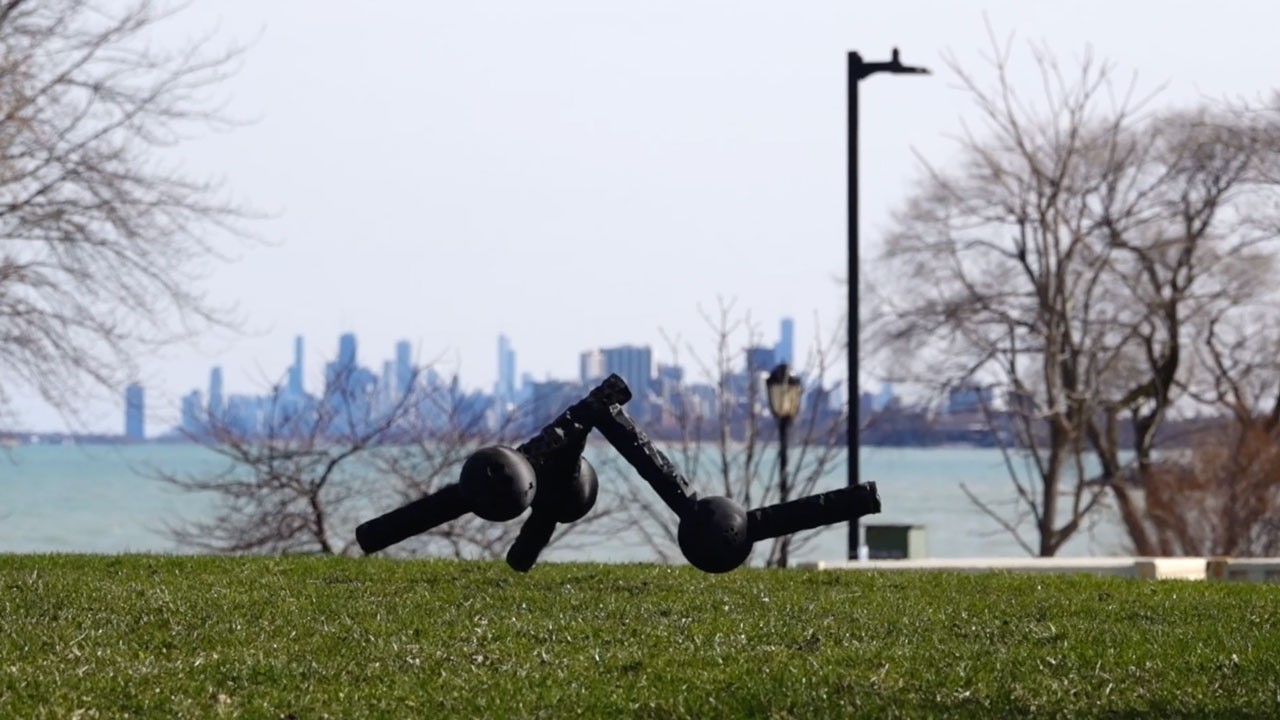
Northwestern University researchers have built a modular legged robot system that automatically generates its own body plan and locomotion policy, then operates immediately in unstructured outdoor terrain. Published in PNAS, the work breaks a fundamental constraint that has kept terrestrial robots locked into human-designed four-limbed configurations since the field began.
Table of Contents
- What is the Northwestern modular legged robot?
- Why automatic body-plan design is an embodied AI breakthrough
- How the modular system works
- Comparable modular and legged robots on the market today
- What This Means for Robotics
- Frequently Asked Questions
What is the Northwestern modular legged robot?
Every legged robot deployed in a real-world environment to date — from Boston Dynamics' Spot to ANYbotics' ANYmal — arrived with a body plan locked in by human engineers before manufacturing began. Northwestern's system, developed at the Center for Robotics and Biosystems and published in PNAS, replaces that manual process with an automated one. Athletic modular building blocks snap together into novel configurations, and the system generates a matching locomotion controller so the robot can operate immediately — no hand-tuning required.
The result: robot morphologies (body shapes and limb arrangements) that no human designer would have produced, capable of running across unstructured outdoor terrain on first deployment.
Why automatic body-plan design is an embodied AI breakthrough
The gap between software AI and physical AI has always been the body. Language models can be retrained overnight; a legged robot's mechanical structure is permanent from the moment it leaves the factory. That permanence has produced an oddly narrow zoo of commercial platforms — nearly all of them quadrupeds, with a handful of bipeds emerging in the last three years.
Northwestern's approach attacks the constraint directly. By treating morphology as a design variable rather than a fixed parameter, the system explores a vastly larger space of possible robots. This is co-design of body and brain — the same principle that makes biological evolution so generative — applied to physical hardware on an engineering timescale.
The implications extend well beyond academic curiosity. Consider three specific failure modes of fixed-morphology robots:
- A quadruped cannot squeeze a torso through a gap sized for a snake-like configuration
- A biped is mechanically suboptimal for carrying asymmetric loads across uneven ground
- A fixed-leg-count robot cannot redistribute load if one limb is damaged
A system that auto-generates body plans could, in principle, be reconfigured for a specific mission before deployment rather than after a costly redesign cycle. That closes a loop that has frustrated field robotics for decades.
How the modular system works
The Northwestern platform consists of what the researchers describe as "highly athletic modular building blocks" — actuated limb segments with standardised mechanical and electrical interfaces. The design pipeline has three stages:
Stage 1 — Morphology search
An automated process explores combinations of the available modules, evaluating candidate configurations against locomotion objectives. This is computationally intensive but runs offline before hardware assembly.
Stage 2 — Rapid physical assembly
Once a configuration is selected, a human (or eventually another robot) assembles the modules. The standardised interfaces mean this takes minutes rather than the months a custom mechanical design would require.
Stage 3 — Hitting the ground running
The locomotion policy — the control software that translates desired motion into individual joint commands — is generated automatically to match the assembled morphology. The robot does not require a manual tuning phase. It operates in unstructured outdoor environments on first activation.
This third stage is where the Physical AI claim is strongest. Generating a locomotion policy for a novel morphology has historically required significant expert effort. Automating it means the design iteration cycle compresses from months to hours.
| Stage | Traditional approach | Northwestern system |
|---|---|---|
| Body plan design | Human engineers, months | Automated search, hours |
| Physical build | Custom manufacturing | Modular assembly, minutes |
| Controller tuning | Manual, weeks | Auto-generated at assembly |
| First outdoor operation | After full validation cycle | Immediate |
Comparable modular and legged robots on the market today
The Northwestern system is a research platform, not a commercial product. But the underlying insight — that morphological flexibility increases deployment utility — is one that several commercial platforms approach from different angles.
Legged platforms with modular sensor/payload stacks — Spot (Boston Dynamics) and ANYmal (ANYbotics) both support modular payload systems, though the leg count and arrangement remain fixed. This is morphological flexibility at the periphery, not the core.
Reconfigurable inspection robots — The nuclear facility demonstration shown separately in IEEE Spectrum's Video Friday roundup illustrates a real-world use case: a reconfigurable robot performing gamma-ray source location in a darkened reactor facility, swapping a thermal camera for a standard optical unit mid-mission. That hot-swap capability hints at where Northwestern's deeper morphological flexibility could eventually land.
Snake and multi-limb research platforms — Academic systems like those from CMU and ETH Zurich have explored non-standard morphologies, but none combine automatic body-plan generation with immediate outdoor locomotion.
For buyers evaluating legged platforms today, the commercially available options remain fixed-morphology quadrupeds. You can browse legged and industrial robots on Robot Overflow to compare current-generation platforms while this research matures toward deployable hardware.
What This Means for Robotics
Northwestern's automatic body-plan design research is early-stage — a PNAS paper, not a product roadmap. But it signals a directional shift that buyers and engineers should track across a three-to-five year horizon.
For field robotics buyers: The current generation of fixed-morphology platforms will remain the practical choice for the next several years. Spot, ANYmal, and their successors are proven, supported, and improving rapidly through software updates. Modular auto-design platforms are not yet commercially available.
For hardware developers: The modular building-block approach creates an interesting component market. If Northwestern's interfaces or a derivative standard gains traction, there is a potential ecosystem of actuator modules, sensor packages, and structural components — analogous to how ROS created a software ecosystem around standardised interfaces.
For AI/ML engineers: The locomotion policy auto-generation problem is closely related to sim-to-real transfer and morphology-conditioned reinforcement learning. Progress here feeds directly into the broader challenge of making robots adaptable without human retraining loops.
For inspection and hazardous-environment operators: This is the highest near-term application signal. The nuclear facility reconfigurable robot demonstration, combined with Northwestern's body-plan flexibility, points toward robots that can be mission-configured on-site — assembling the right morphology for a specific pipe diameter, access hatch size, or terrain type before entering a hazardous zone.
The broader trend is unmistakable: the boundary between robot design and robot operation is collapsing. When a system can specify its own body and learn to move in it within hours, the distinction between "engineering a robot" and "deploying a robot" becomes semantic.