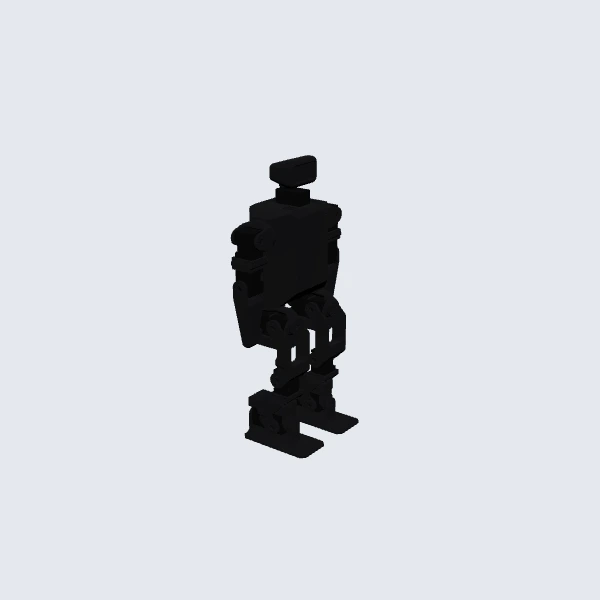
What is the Rhoban Microban?
A small, fully 3D-printed open-source humanoid, about 30 cm tall, by Marc Duclusaud of the Rhoban team (LaBRI, University of Bordeaux): 19 Dynamixel XL330 servos, a Raspberry Pi Zero 2 W and two 18650 cells, about $567 in parts. It walks with a policy trained in simulation.
Specifications
Facts about the Rhoban Microban from its project's published documentation, design files and its makers' own figures. A figure marked Estimate is worked out from those files or parts lists rather than stated by the maker.
| Spec | Detail |
|---|---|
| Height | About 30 cm (README); its 3D model measures 32.7 cm from the soles to the top of the head. |
| Mass | Not published as a weighed figure. The link masses in the 3D model (a modelled value, screws included) add up to 0.82 kg (818.9 g); with about 40 g of cables it leaves out, the authors estimate 0.86 kg. |
| Degrees of freedom | 19: 6 per leg (hip yaw, roll and pitch, knee, ankle pitch and roll), 3 per arm (shoulder pitch and roll, elbow) and 1 to turn the head. |
| Actuators | 19 × ROBOTIS Dynamixel XL330-M288-T servos, daisy-chained on one bus at 1 Mbps; fed straight from the 2-cell 18650 battery (8.4 V full, about 7.4 V nominal), above the XL330's rated 3.7–6.0 V, and the servos' input-voltage error is switched off (assembly guide). |
| Onboard computer | Raspberry Pi Zero 2 W with Pollen Robotics' open RPI Robot Hat (servo bus, IMU, audio). |
| Sensors | An IMU on Pollen's RPI Robot Hat (Microban's code reads a Bosch BMI088 over I2C) and the servos' own position, speed, current and voltage readings. Pollen's newest hat revision (D1, 6 Oct 2026) moves to an LSM6DSV16X IMU, so a hat made now may need a code change. No camera: the head is "just cosmetic" for now. |
| Battery | Two 18650 Li-ion cells in series (2S, 8.4 V full) with a BMS; Murata VTC6 recommended (3,120 mAh each). Charged over USB-C on the robot, whether it is on or off. |
| Printed parts | 21 part designs in PLA (42 pieces; the README says about 30 parts), at 0.12 mm layers and 15% infill; under one roll of filament. |
| Parts cost | $567.35 at the BOM's listed prices ("approximately $567"; the README says $550–600), $623.45 with the servo setup tools. Not sold assembled: you build it yourself. |
| Walking | A neural-network policy trained in simulation (MjLab) walks it; the training environments are open (MarcDcls/mjlab_microban). It can be driven from a keyboard or a Bluetooth Xbox controller. |
| Released | First release v0.0.1 on 21 June 2026 and version 1.0.0 on 6 July 2026 (with a Zenodo DOI); a walking demo went on YouTube on 29 June 2026. The repository was created on 6 May 2026. |
3D model
The interactive 3D model on this page is converted from the project's published design: Microban by Marc Duclusaud (Rhoban team, LaBRI, University of Bordeaux), github.com/Rhoban/microban. 3D model under CC BY-NC-SA 4.0: non-commercial use, with credit, shared alike.
Sources
- Project repository: github.com/Rhoban/microban