متوسط السعر اليومي
المبالغ بعملة USD
الوصف
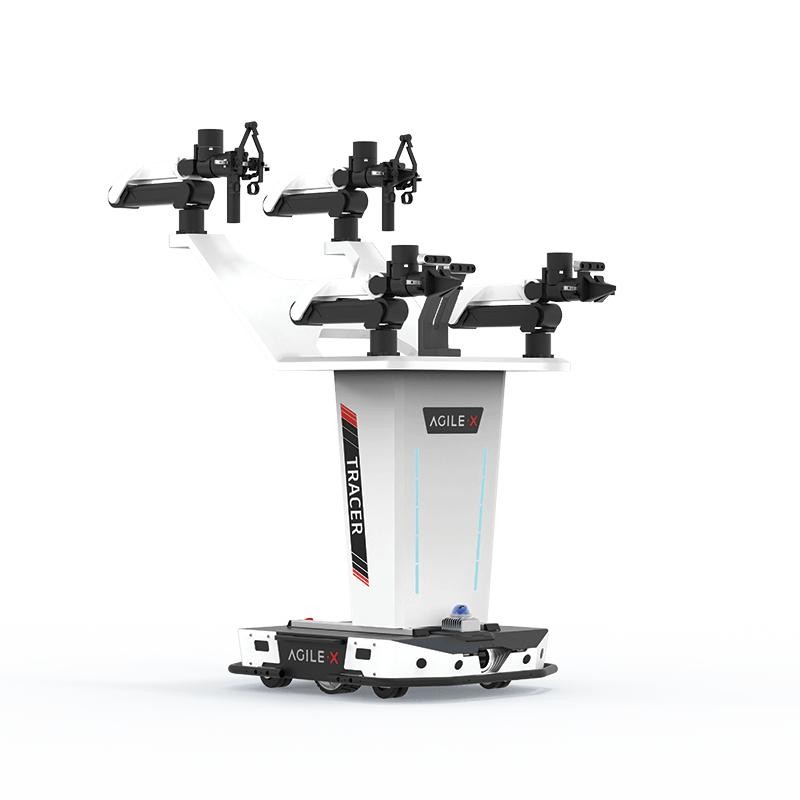
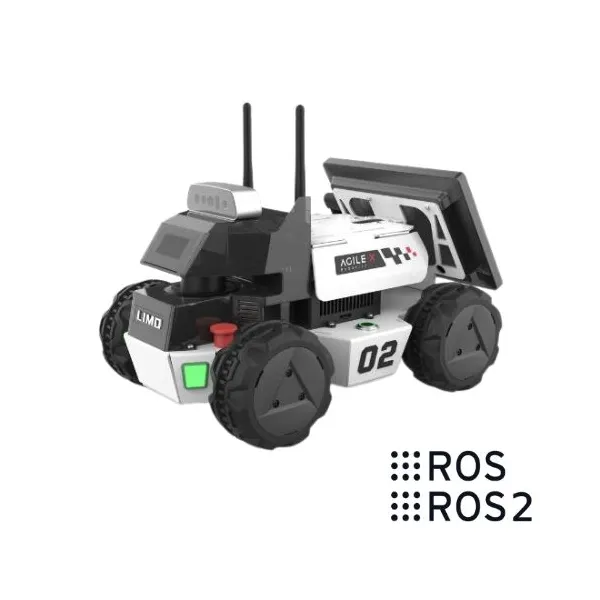
AgileX Cobot Magic is a system based on Mobile ALOHA that can simultaneously remotely control the TRACER mobile base and robotic arms. Mobile Aloha is a whole-body remote operation data collection system developed by Zipeng Fu, Tony Z. Zhao, and Chelsea Finn from Stanford University. Its hardware is based on 2 robotic arms (ViperX 300), equipped with 2 wrist cameras and 1 top camera, and a mobile base from AgileX Robotics Tracer differential motion robot, etc. Data collected using Mobile ALOHA, combined with supervised behavior cloning and joint training with existing static ALOHA datasets, can improve the performance of mobile manipulation tasks. With 50 demonstrations for each task, joint training can increase the success rate by 90%. Mobile ALOHA can autonomously perform complex mobile manipulation tasks such as cooking and opening doors. Special thanks to the Stanford research team Zipeng Fu, Tony Z. Zhao, and Chelsea Finn for their research on Mobile ALOHA, which enabled full open-source implementation. For more details about this project, please check out the link. Based on Mobile Aloha, AgileX developed Cobot Magic, which can achieve the complete code of Mobile Aloha, with higher configurations and lower costs, and is equipped with larger-load robotic arms and high-computing power industrial computers. AgileX Cobot Magic is a system based on Mobile ALOHA that can simultaneously remotely control the TRACER mobile base and robotic arms. It is equipped with an indoor differential drive AGV base, a high-performance robotic arm, an industrial-grade computer, and other components. AgileX Cobot Magic assists users in better utilizing open-source hardware and the Mobile ALOHA deep learning framework for robotics. It covers a wide range of tasks, from simple pick-and-place operations to more intricate and complex actions such as pouring, cooking, riding elevators, and organizing items. Mobile ALOHA is a whole-body remote operation data collection system developed by Zipeng Fu, Tony Z. Zhao, and Chelsea Finn from Stanford University. Mobile ALOHA: Learning Bimanual Mobile Manipulation with Low-Cost Whole-Body Teleoperation 100 KG Payload 240 MIN Runtime 1.6 M/S Speed Features Its hardware is based on 4 robotic arms , equipped with 2 wrist cameras and 1 top camera, and a mobile base from AgileX Robotics Tracer differential motion robot. Advanced and Cost-Effective Robotic Automation Cobot Magic integrates the Mobile ALOHA code and offers better configurations and cost savings. It features stronger robotic arms and powerful industrial computers, excelling in complex tasks like dual-arm operations. This makes Cobot Magic a versatile tool for both industry and research. Simulation Data Training Set up the Mobile Aloha software environment for data and model training across simulated and real-world environments. Data Collection Users can flexibly accomplish a wide range of everyday tasks by controlling the teaching robot arm, from basic pick and place operations to more sophisticated skills. Unleash the Bimanual MobileManipulation Navigate cluttered spaces, watering flowers, opening boxes, grasp and manipulate delicate objects, and even cook a simple meal. Standard Configuration Wheeled Mobile Robot Tracer Depth Camera Orbbec Dabai USB HUB 12V Power Supply 6DOF Lightweight Robot ARM *4 Customized Adjustable Velcro*2 Customized Grip Tape*2 Customized Power Strip 4 OUTLET ALOHA Stand Customized Speed and Performance IMU CH 110 Display 11.6'' 1080P AgileX will continue to collect data from various motion tasks based on Cobot Magic for model training and inference. Please stay tuned for updates on Github. .price-match { background-color: #b3ffb3; color: #000000; padding: 20px; text-align: center; border-radius: 10px; box-shadow: 0 2px 4px rgba(0, 0, 0, 0.1); font-family: Arial, sans-serif; } .price-match p { margin: 0; } .price-match strong { color: #000000; font-weight: bold; } Mobile Aloha is a whole-body remote operation data collection system developed by Zipeng Fu, Tony Z. Zhao, and Chelsea Finn from Stanford University. Its hardware is based on 2 robotic arms (ViperX 300), equipped with 2 wrist cameras and 1 top camera, and a mobile base from AgileX Robotics Tracer differential motion robot, etc. PRICE MATCH GUARANTEE We guarantee the best price in the market. If you find a better offer, let us know and we will beat it! More information: Terms & Conditions
AgileX Cobot Magic is a system based on Mobile ALOHA that can simultaneously remotely control the TRACER mobile base and robotic arms. Mobile Aloha is a whole-body remote operation data collection system developed by Zipeng Fu, Tony Z. Zhao, and Chelsea Finn from Stanford University. Its hardware is based on 2 robotic arms (ViperX 300), equipped with 2 wrist cameras and 1 top camera, and a mobile base from AgileX Robotics Tracer differential motion robot, etc. Data collected using Mobile ALOHA, combined with supervised behavior cloning and joint training with existing static ALOHA datasets, can improve the performance of mobile manipulation tasks. With 50 demonstrations for each task, joint training can increase the success rate by 90%. Mobile ALOHA can autonomously perform complex mobile manipulation tasks such as cooking and opening doors. Special thanks to the Stanford research team Zipeng Fu, Tony Z. Zhao, and Chelsea Finn for their research on Mobile ALOHA, which enabled full open-source implementation. For more details about this project, please check out the link. Based on Mobile Aloha, AgileX developed Cobot Magic, which can achieve the complete code of Mobile Aloha, with higher configurations and lower costs, and is equipped with larger-load robotic arms and high-computing power industrial computers. AgileX Cobot Magic is a system based on Mobile ALOHA that can simultaneously remotely control the TRACER mobile base and robotic arms. It is equipped with an indoor differential drive AGV base, a high-performance robotic arm, an industrial-grade computer, and other components. AgileX Cobot Magic assists users in better utilizing open-source hardware and the Mobile ALOHA deep learning framework for robotics. It covers a wide range of tasks, from simple pick-and-place operations to more intricate and complex actions such as pouring, cooking, riding elevators, and organizing items. Mobile ALOHA is a whole-body remote operation data collection system developed by Zipeng Fu, Tony Z. Zhao, and Chelsea Finn from Stanford University. Mobile ALOHA: Learning Bimanual Mobile Manipulation with Low-Cost Whole-Body Teleoperation 100 KG Payload 240 MIN Runtime 1.6 M/S Speed Features Its hardware is based on 4 robotic arms , equipped with 2 wrist cameras and 1 top camera, and a mobile base from AgileX Robotics Tracer differential motion robot. Advanced and Cost-Effective Robotic Automation Cobot Magic integrates the Mobile ALOHA code and offers better configurations and cost savings. It features stronger robotic arms and powerful industrial computers, excelling in complex tasks like dual-arm operations. This makes Cobot Magic a versatile tool for both industry and research. Simulation Data Training Set up the Mobile Aloha software environment for data and model training across simulated and real-world environments. Data Collection Users can flexibly accomplish a wide range of everyday tasks by controlling the teaching robot arm, from basic pick and place operations to more sophisticated skills. Unleash the Bimanual MobileManipulation Navigate cluttered spaces, watering flowers, opening boxes, grasp and manipulate delicate objects, and even cook a simple meal. Standard Configuration Wheeled Mobile Robot Tracer Depth Camera Orbbec Dabai USB HUB 12V Power Supply 6DOF Lightweight Robot ARM *4 Customized Adjustable Velcro*2 Customized Grip Tape*2 Customized Power Strip 4 OUTLET ALOHA Stand Customized Speed and Performance IMU CH 110 Display 11.6'' 1080P AgileX will continue to collect data from various motion tasks based on Cobot Magic for model training and inference. Please stay tuned for updates on Github.
سجل الأسعار
نقطة بيانات واحدة لكل يوم، محسوبة بمتوسط الأسعار المرصودة في ذلك اليوم.
المبالغ بعملة USD
تُحسب المتوسطات لكل يوم وفق التوقيت العالمي المنسق، استنادًا إلى أسعار جميع العروض المسجلة.
AgileX
£14,785
AgileX
£15,523
AgileX
9,360 €
AgileX
2,694.68 €
AgileX
2,040 €
AgileX
9,000 €
AgileX
2,400 €
AgileX
61,880.95 €
AgileX
5,950.95 €
AgileX
£5,914
AgileX
£3,552.75
AgileX
£5,526.50
🍪 تفضيلات ملفات تعريف الارتباط
نستخدم ملفات تعريف الارتباط لقياس الأداء. سياسة الخصوصية