New
Universal Master Arm – Teleoperation Leader Arm

Universal Master Arm – Teleoperation Leader Arm

Universal Master Arm – Teleoperation Leader Arm
AgileX | A-000000-08555
€540.00 VAT incl. €450.00 VAT excl.

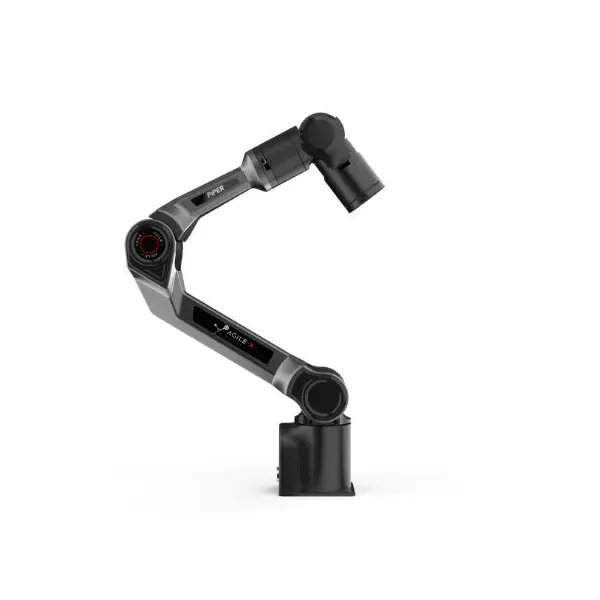
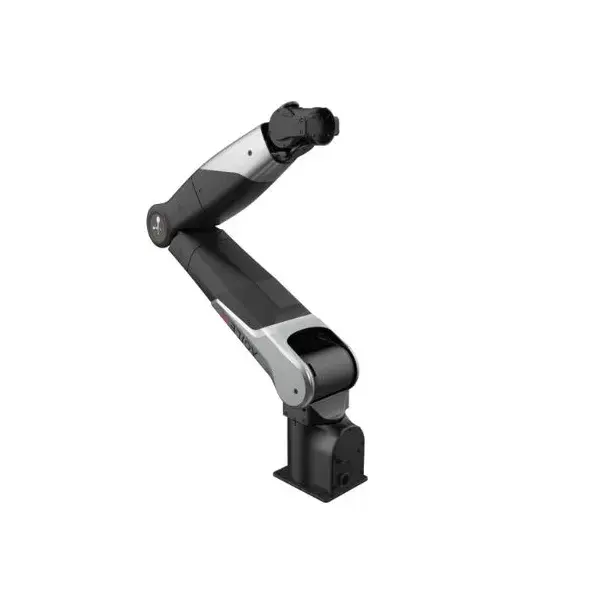
The Universal Master Arm by AgileX Robotics is a lightweight 6-degree-of-freedom leader arm designed for real-time teleoperation of robotic arms and for recording human demonstrations for Robot Learning.
Version
-- Please select an item --
  • Left
  • Right
Quantity
In backorder
This product is on backorder. You can place an order on our website or send us a purchase order in PDF format
to know the delivery times

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

Key features of the Universal Master Arm

  • 6 degrees of freedom for real-time teleoperation using 6D pose mapping
  • Compact design: 0.6 kg and 415 mm reach
  • Accuracy: ±1° orientation accuracy and ±5 mm position accuracy
  • Connectivity: integrated CAN and PC connection via USB Type-C
  • Compatible with Python, C++ and ROS 2, as well as AgileX PiPER and NERO robotic arms
  • Available in left-hand or right-hand versions

A leader arm for robot teleoperation

The Universal Master Arm operates as a leader arm: the user directly moves the master arm, and the system transmits the corresponding position and orientation to the controlled robotic arm.

Using 6D pose mapping and inverse kinematics, the operator's movements are converted into commands that enable the robot to reproduce the motion in real time.

This approach makes manipulation tasks easier to perform without having to manually program each robot trajectory.

Data collection for Robot Learning

Beyond teleoperation, the Universal Master Arm can be used to record human demonstrations of manipulation tasks. This data can then be used to train or evaluate robotic models and policies.

It is particularly suitable for the following applications:

  • Robot Learning
  • Imitation Learning
  • Demonstration data collection
  • Embodied AI
  • Manipulation policy development
  • ACT and Diffusion Policy
  • Human-robot interaction research

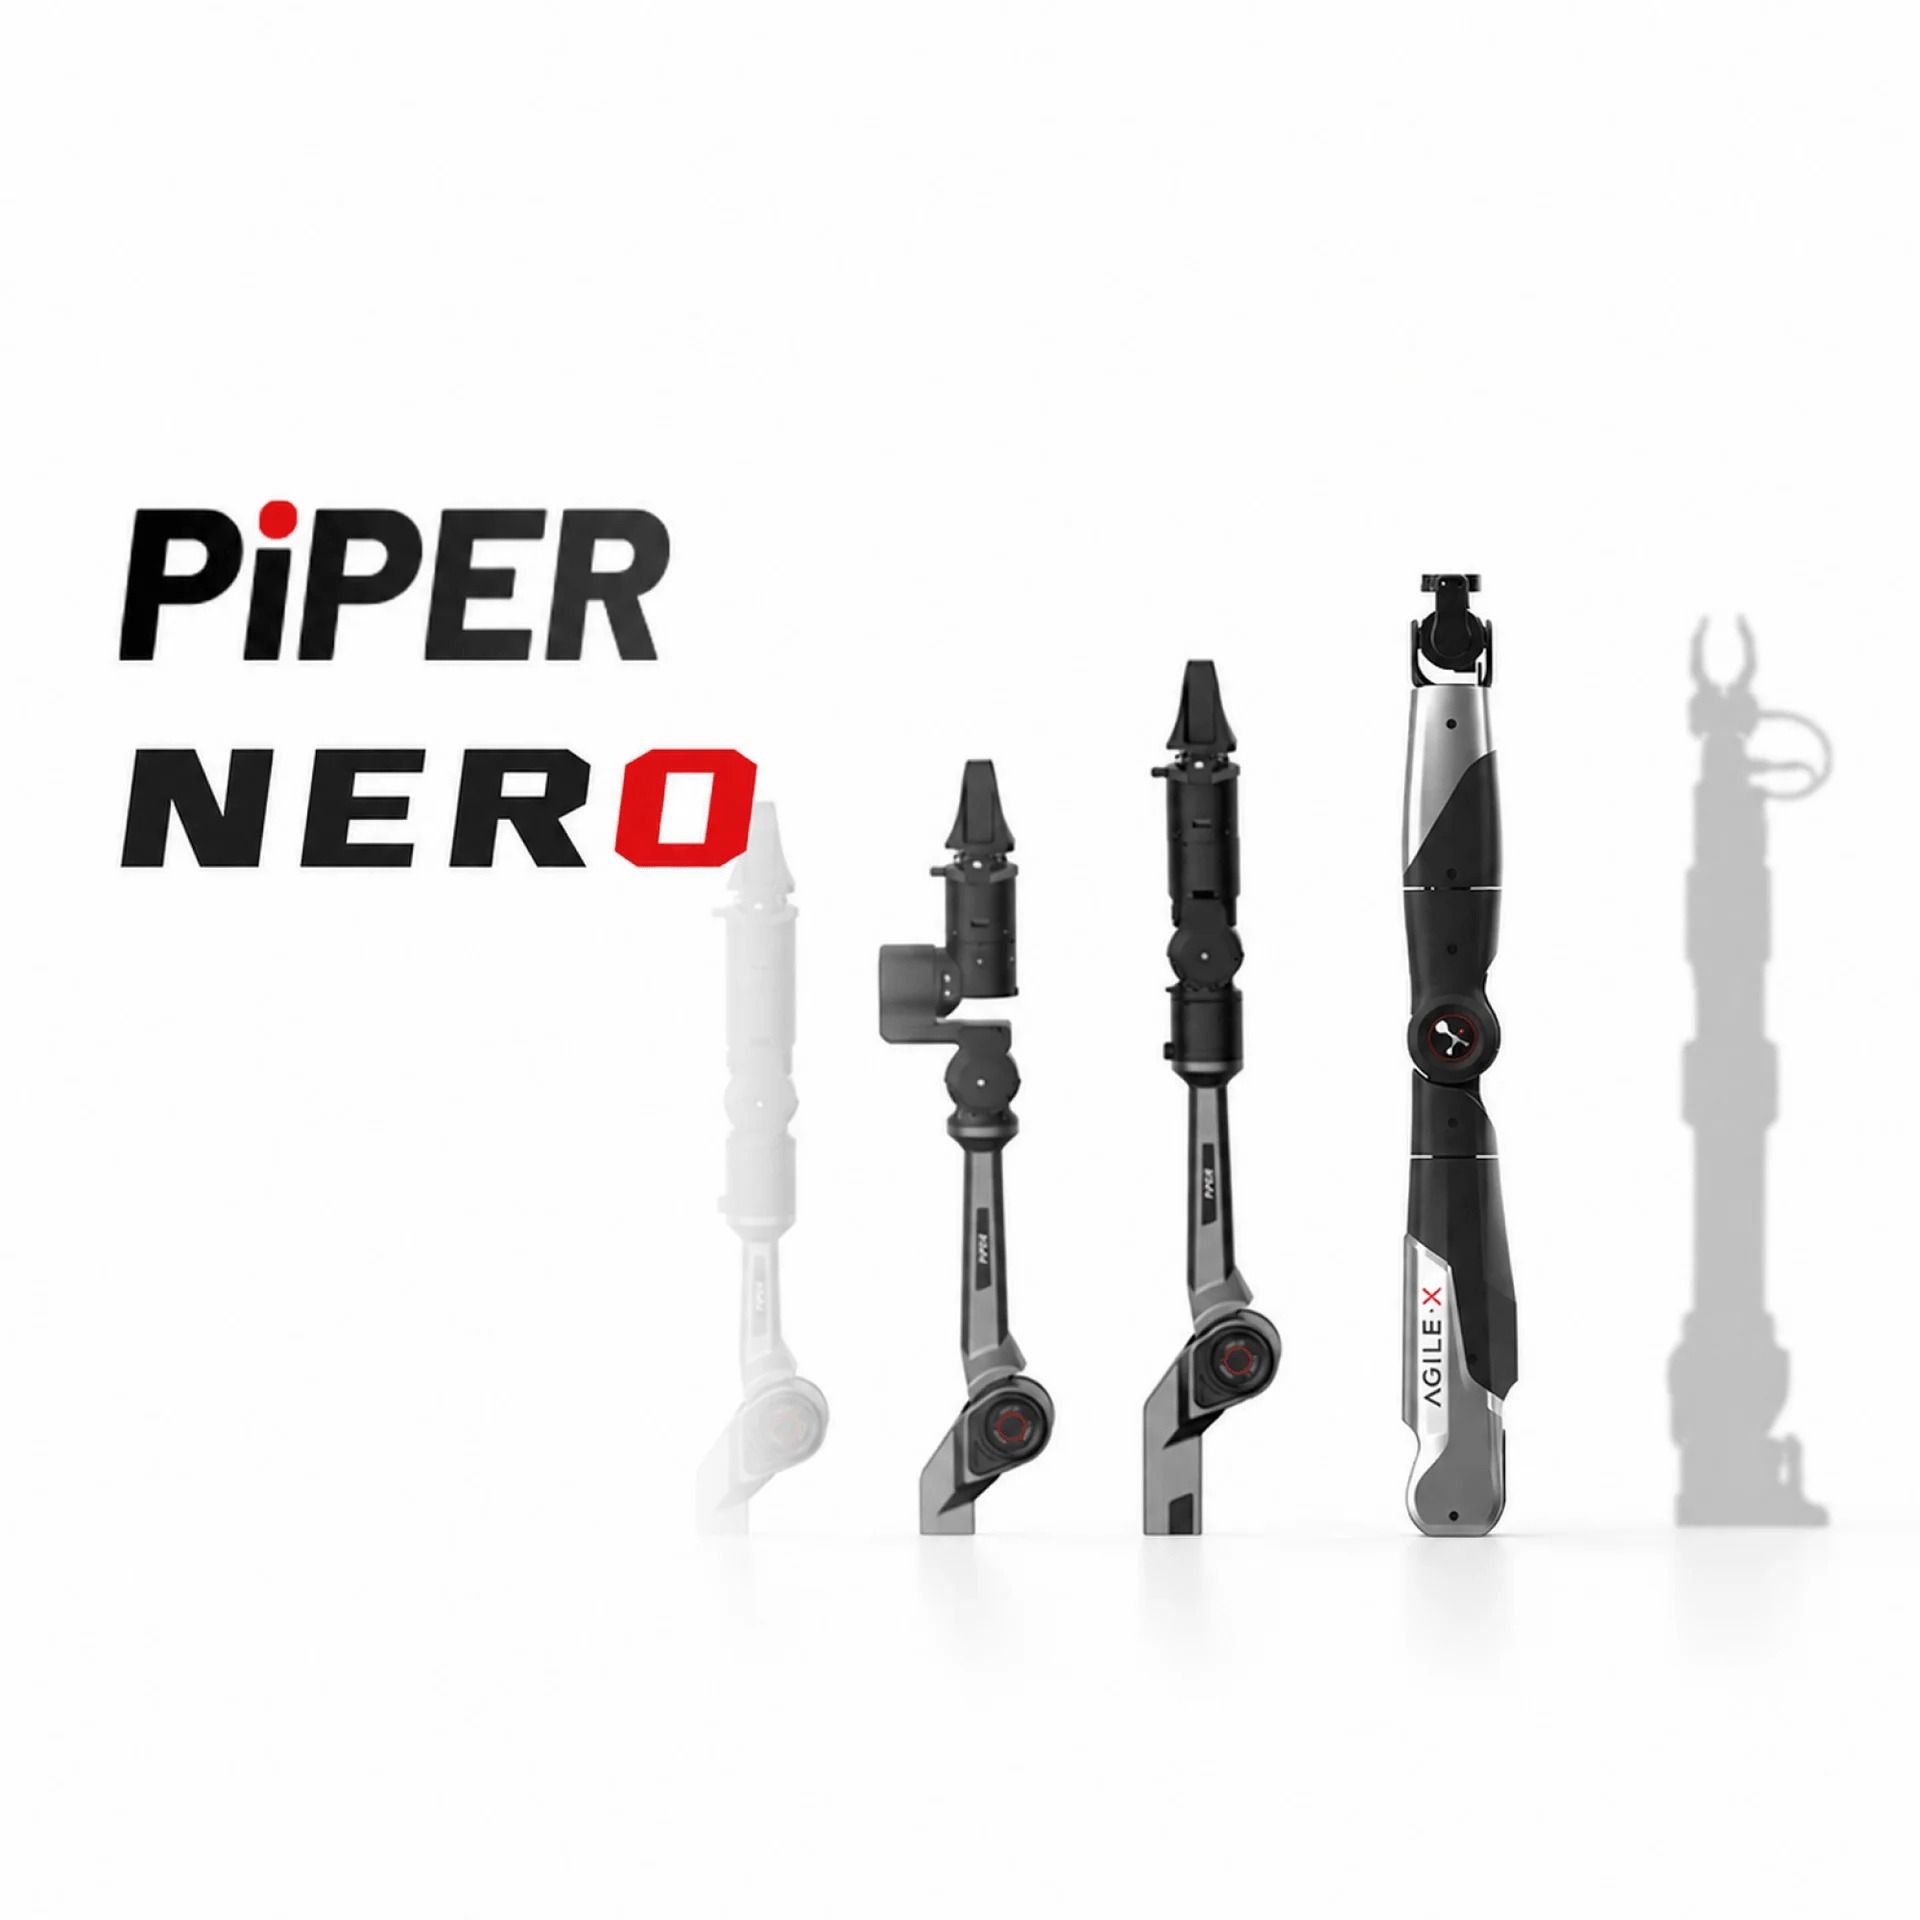
Compatible with NERO and PiPER robotic arms

The Universal Master Arm can notably control the following AgileX robotic arms:

  • NERO with 7 degrees of freedom
  • PiPER with 6 degrees of freedom

The same teleoperation platform can therefore be used with different robotic arm architectures. Integration with third-party arms is also possible by adapting the robot model, inverse kinematics solver and control interface.

AgileX PiPER / NERO

Left-hand or right-hand version

The Universal Master Arm is available in a left-hand or right-hand version. Each version is specific to its side and cannot be used interchangeably as a left or right arm.

For a bimanual teleoperation setup, it is therefore necessary to use one left Universal Master Arm and one right Universal Master Arm.

Easy integration into an R&D environment

Weighing only 0.6 kg and featuring an integrated CAN module, the Universal Master Arm is designed for easy installation on a workbench or integration into an experimental platform.

The PC connection is made directly via USB Type-C. The system supports Python, C++ and ROS 2, making it easy to integrate into existing robotics development environments.

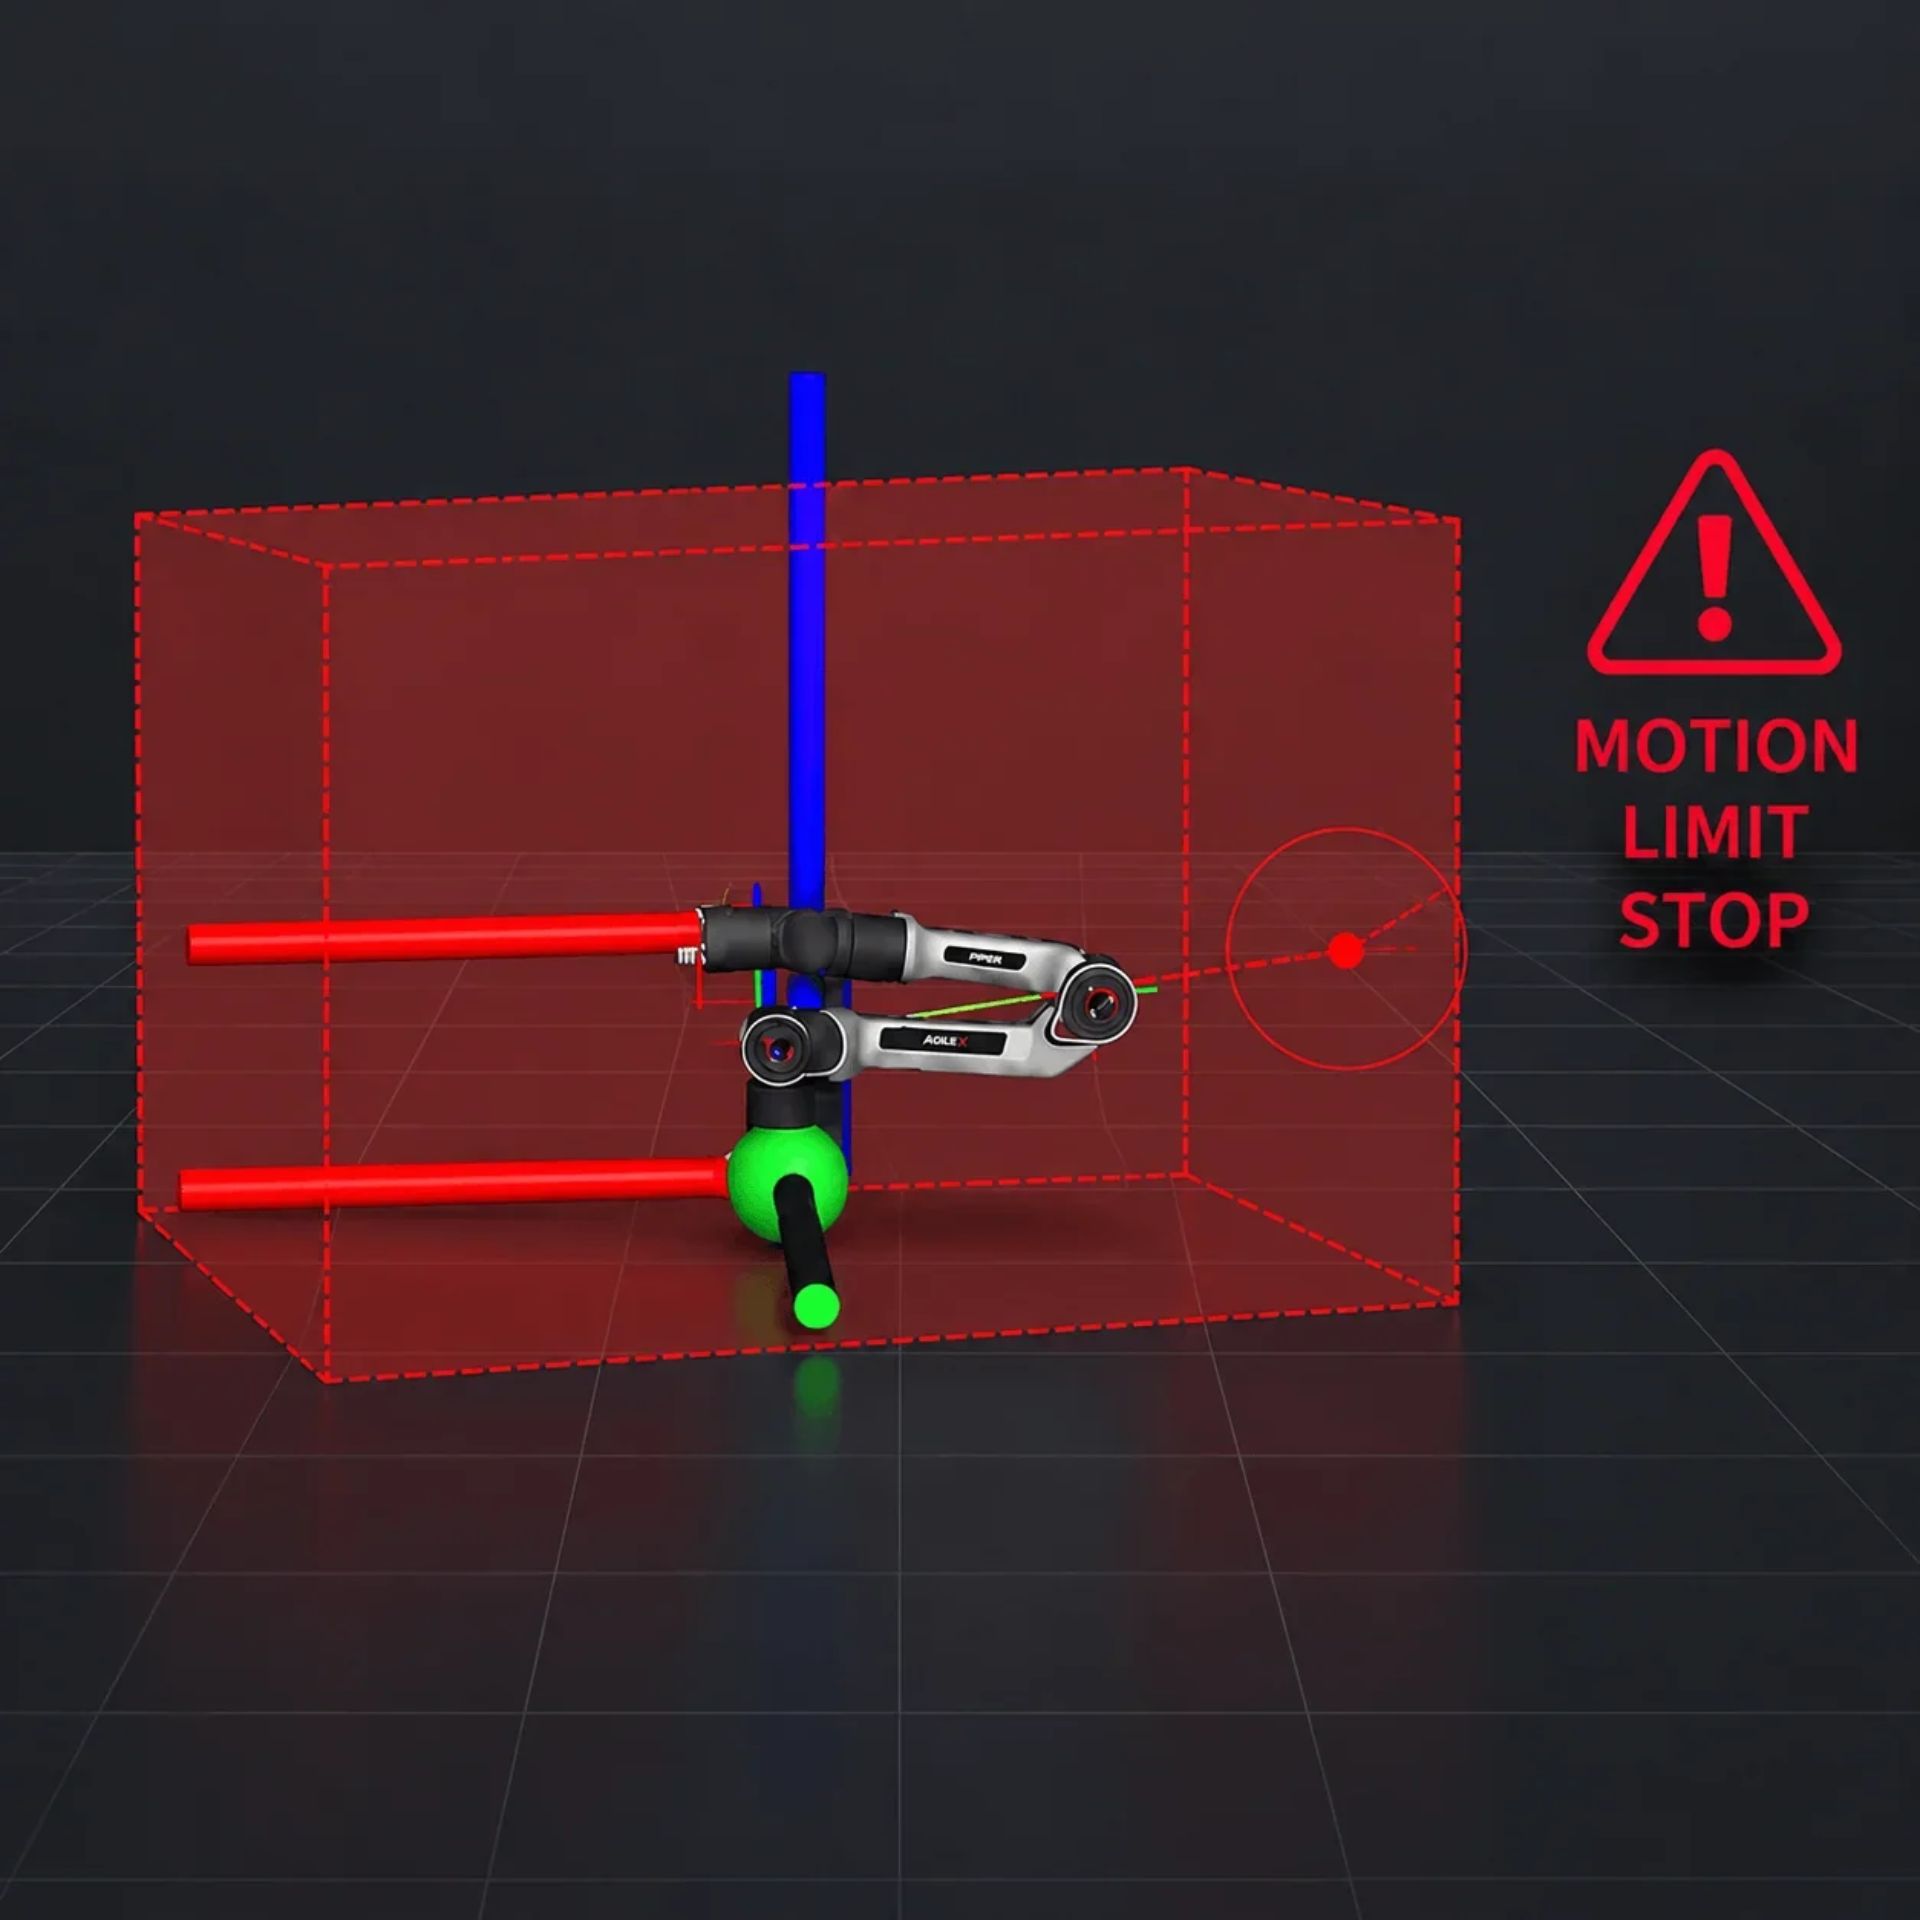
Configurable motion limits

Workspace limits can be configured to restrict robot movements to a defined area. When a target pose exceeds these limits, the system can stop the movement to prevent unwanted motion.

Universal Master Arm - Customizable Workspace Limites

Universal Master Arm technical specifications

TypeTeleoperation leader arm
Degrees of freedom6 DoF
Weight0.6 kg
Reach415 mm
Workspace505 mm, hemispherical
Handle rotation±180°
Encoder resolution16 bits
Angular accuracy±1°
Position accuracy±5 mm
Latency0.1 ms
InterfaceUSB Type-C
Power supply5 V DC
Dimensions260 × 110 × 145 mm
DevelopmentPython, C++, ROS 2
Compatible armsAgileX PiPER, NERO and third-party platforms with software adaptation
VersionsLeft-hand or right-hand arm, side-specific

Universal Master Arm Resources