Daily average price
Amounts in USD


This bundle does NOT include a camera for the OMX-F Follower Arm.
A compatible camera can be purchased separately: Camera Information →
Please review these requirements before setting up OMX with Physical AI Tools.
| Category | Requirement |
|---|---|
| Recommended OS | Ubuntu |
| Host Operating System | Any Linux distribution. The host OS version does not need to match the container. |
| Container Environment | Ubuntu 24.04 + ROS 2 Jazzy |
| GPU | NVIDIA GPU with CUDA support |
| Required Software | Docker Engine, Git, and NVIDIA Container Toolkit |
| Recommended Setup Knowledge | Basic Linux terminal, Docker, ROS 2, and USB device/serial port setup |
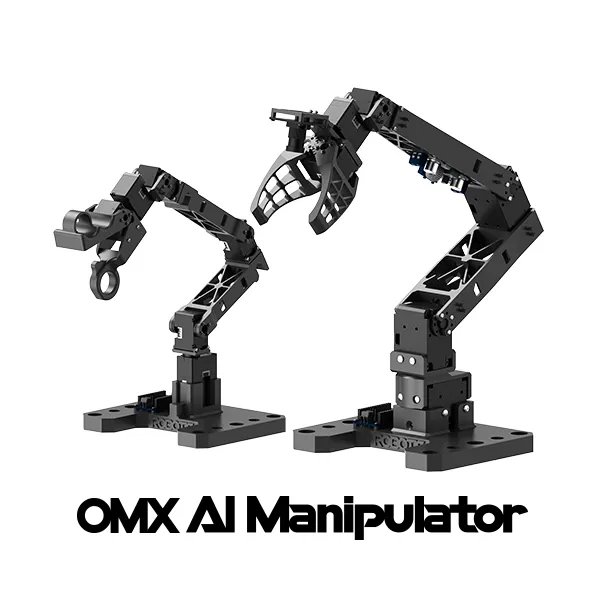
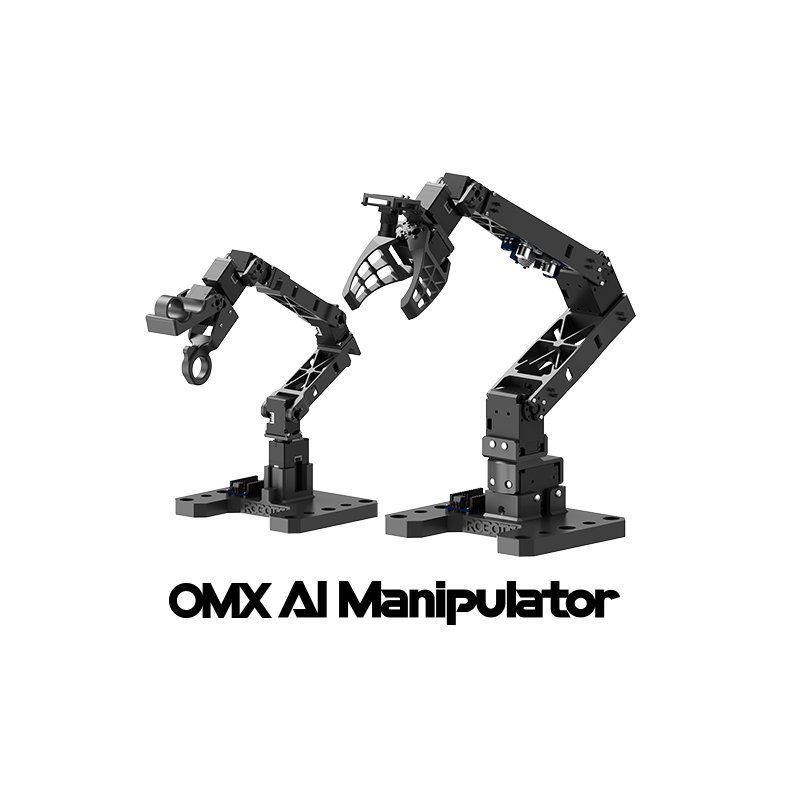
The OMX is an entry-level Physical AI manipulator designed for dataset collection, teleoperation, and imitation learning. It provides an accessible platform for users who want to collect robot motion data, operate a leader/follower arm system, and begin working with Physical AI workflows.

Effective May 2026, the Link-U and DC Converter utilized in the OMX-AI has been changed.
This update was implemented to ensure the stable supply of essential components and to maintain the product’s optimal performance and reliability.
Inventory of the previous version will be shipped first until depleted.


| Item | OMX-L Leader |
|---|---|
| Degrees of Freedom | 5 + Gripper |
| Full Reach | 335 mm |
| Weight | 360 g |
| Voltage | 5 VDC |
| Communication | USB-C / TTL |
| Baudrate | 1 Mbps |
| Software | ROS 2 |

| Item | OMX-F Follower |
|---|---|
| Degrees of Freedom | 5 + Gripper |
| Full Reach | 400 mm |
| Weight | 560 g |
| Voltage | 12 VDC |
| Payload | 100 g full reach / 250 g normal operating range |

Before operation, users should complete the OMX assembly and software setup guides. For Physical AI workflows, users should also complete the ROS 2 Physical AI Tools setup guide, including Docker, NVIDIA Container Toolkit, serial port configuration, and camera topic configuration.
```
Price history
One data point per day, averaged by observation date.
Amounts in USD
Averages are computed per UTC day from every recorded offer price.
Robotis
444 €
Robotis
416.95 €
Robotis
£265.61
Robotis
327.95 €

Robotis
$310.39
Robotis
304.95 €
Robotis
£308.50

Robotis
$399

Robotis
$436.89

Robotis
$275.89
Robotis
451.95 €

Robotis
£219.17
🍪 Cookie preferences
We use cookies to measure performance. Privacy Policy