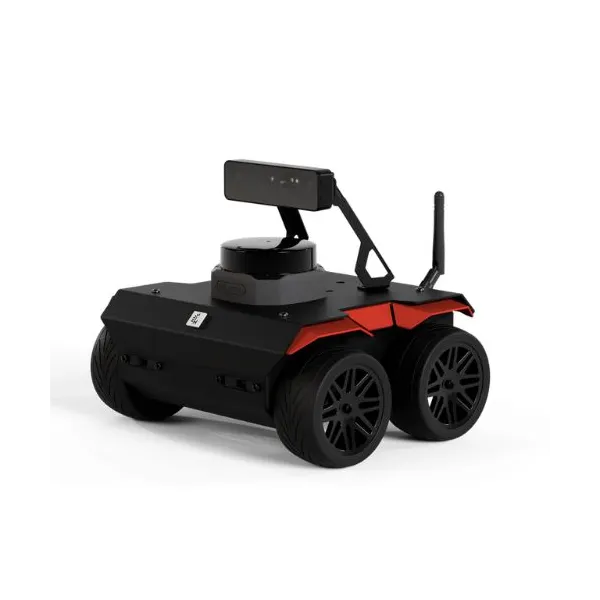
- Ready-to-Run ROS 2 Platform Ships with Ubuntu 24.04 and ROS 2 Jazzy preinstalled on Raspberry Pi 5 (8 GB), enabling immediate autonomy development without base-layer configuration.
- Two Perception Variants ROSbot 3 uses RPLIDAR C1 + OAK-D Lite; the PRO upgrades to RPLIDAR S2 + OAK-D Pro for higher-performance SLAM and depth perception in cluttered environments.
- Agile 4-Wheel Drive Four independent DC motors with quadrature encoders deliver 1.0 m/s max speed and 420°/s rotation on an indoor-friendly 200 × 233 mm aluminum chassis.
- Rich Onboard Sensing Bosch BNO055 IMU, four VL53L0X ToF sensors (up to 200 cm range), and STM32F407 low-level controller provide the data foundation for localization and navigation stacks.
- Modular Expansion Rear-panel interface and open payload area accept additional sensors, compute modules, or prototype hardware up to 5 kg.

Daily average price
Amounts in USD