Last updated: February 2025
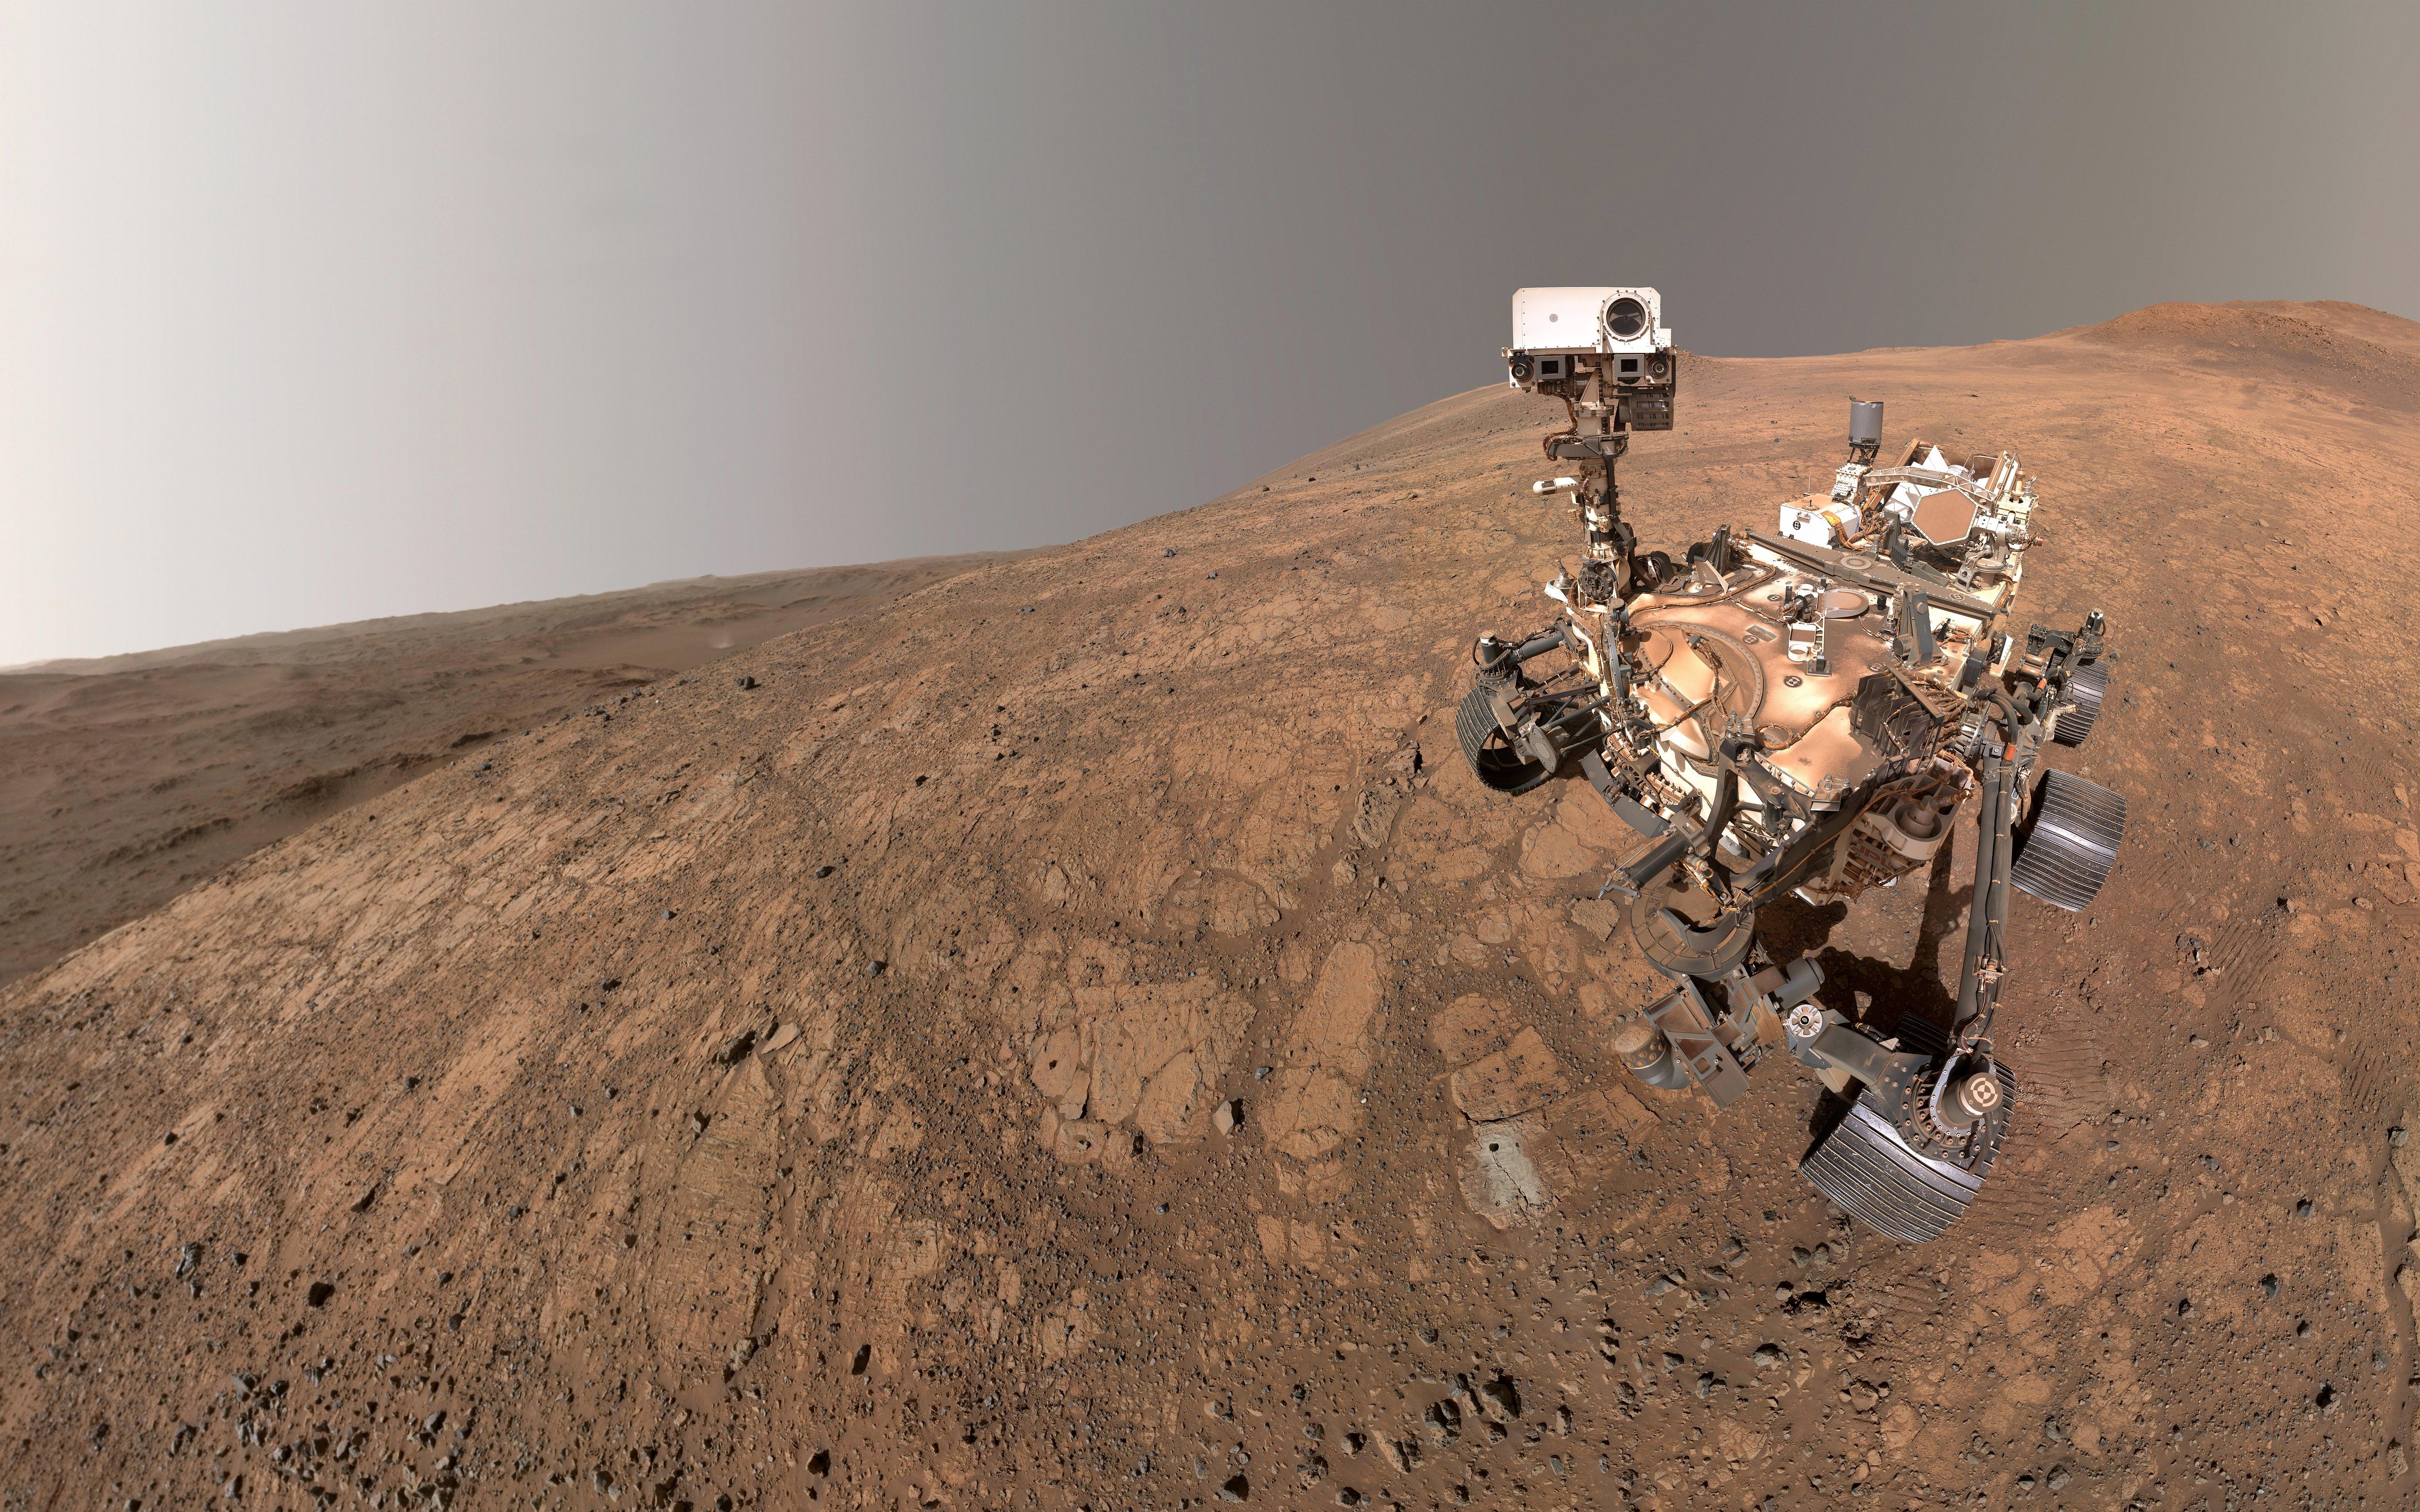
NASA's Perseverance rover has completed 90% of its Mars traversal autonomously — up from just 6.2% for its predecessor Curiosity — using an algorithm that runs on late-1990s-era computing hardware. The feat represents a landmark in Physical AI: high-autonomy navigation in unstructured, uncharted terrain with minimal compute, with implications that extend well beyond space exploration.
Table of Contents
- What is ENav and how does it work?
- How does Perseverance compare to previous Mars rovers?
- Why does compute-constrained autonomy matter?
- What role does AI play in future Mars navigation?
- What this means for robotics and autonomous systems
- Frequently Asked Questions
What is ENav and how does it work?
Enhanced Autonomous Navigation (ENav) is Perseverance's onboard pathfinding system, designed to assess approximately 1,700 candidate paths within a 6-meter radius and select the safest route — all while the rover continues moving. This concurrent think-and-drive capability is what separates Perseverance from every Mars rover before it, and it achieves this on a radiation-hardened CPU with the processing power of an iMac G3 from 1998.
The algorithm works in three stages. First, Perseverance captures stereo images of the terrain ahead and maps thousands of possible forward paths. Second, it ranks those paths by scoring factors including terrain roughness and estimated travel time. Third — and this is where ENav is architecturally clever — it applies ACE (approximate clearance estimation), a computationally expensive collision-checking routine, to only the top-ranked handful of candidates. The heavy lifting is reserved for genuinely difficult terrain; on clear ground, the rover keeps rolling.
According to IEEE Spectrum, the full technical analysis of ENav was published in IEEE Transactions on Field Robotics in November 2025, co-authored by Masahiro "Hiro" Ono, supervisor of the Robotic Surface Mobility Group at NASA's Jet Propulsion Laboratory.
How does Perseverance compare to previous Mars rovers?
Perseverance has driven more than 30 kilometres across Mars with 90% of that distance covered autonomously — shattering the benchmark set by Curiosity, which achieved just 6.2% autonomous travel over its entire mission.
The performance gap is stark across every metric:
| Metric | Opportunity | Curiosity | Perseverance |
|---|---|---|---|
| Autonomous driving share | Low | ~6.2% | ~90% |
| Best single-sol distance (autonomous) | 109 m | — | 331.74 m |
| Navigate while moving? | No | No | Yes |
| Peak average daily distance | — | — | 201 m/sol |
| Total distance (as of Oct 2024) | — | — | 30+ km |
Opportunity held the single-sol autonomous distance record at 109 metres until 3 April 2023, when Perseverance covered 331.74 metres autonomously in a single Martian day — more than tripling the previous record. During its sprint to the ancient river delta at Jezero Crater, the rover sustained 95% autonomous driving over 24 consecutive Martian days, covering roughly 5 kilometres of delta foothills.
The fundamental difference is architectural. Curiosity had to stop completely to compute a safe path before each movement segment — what Ono calls "the main speed bump." Perseverance computes the next path while executing the current one, making its autonomous driving "an order of magnitude faster," in Ono's words.
Why does compute-constrained autonomy matter?
Running sophisticated terrain-navigation autonomy on a processor equivalent to a 1998 desktop computer is not a limitation to work around — it is the result of a deliberate, risk-managed engineering philosophy, and it carries important lessons for terrestrial robotics.
Radiation hardening (the process of manufacturing chips to withstand the ionising radiation environment of deep space, which would otherwise cause bit-flips and processor failures) severely constrains available compute. The CPU inside Perseverance is the same model used in Curiosity — a proven design chosen precisely because its reliability in harsh conditions is well-documented. Introducing a faster, newer processor would mean accepting uncharted failure modes millions of kilometres from the nearest repair technician.
The constraint forced a precise algorithmic solution: do expensive computation only where it matters. This principle — sometimes called compute-aware planning — is increasingly relevant on Earth, where autonomous systems must balance inference speed against power budgets on edge hardware. Warehouse robots, agricultural drones, and outdoor inspection platforms all face variants of the same tradeoff.
Masahiro Ono summarises the core challenge succinctly: the Martian terrain is static (rocks don't move), but vast and largely uncharted. "This enormous uncertainty is the major challenge," he notes. Perseverance's solution is probabilistic path ranking combined with selective deep-checking — a template that translates directly to any robot navigating novel, GPS-unreliable, or infrastructure-free environments.
What role does AI play in future Mars navigation?
In December 2024, NASA ran its first test of a navigation pipeline that uses a model based on Anthropic's Claude to analyse orbital imagery from the Mars Reconnaissance Orbiter (MRO) and generate waypoints — a preview of foundation models entering operational space robotics.
Current ENav operation relies entirely on images the rover captures itself, because MRO orbital images lack sufficient ground resolution for close-range navigation decisions. The Anthropic-based test targeted a different layer of the autonomy stack: high-level route planning from above, feeding structured waypoint coordinates down to the rover's local navigation system.
This two-layer architecture — a large language model (LLM) handling strategic path generation from coarse satellite data, with a lean onboard algorithm handling real-time local navigation — closely mirrors how hybrid AI systems are being designed for autonomous vehicles and industrial robots on Earth. The LLM doesn't drive; it plans. The embedded system executes.
If validated, this approach would reduce dependence on human operators for mission-level route decisions, which become increasingly impractical as rovers push deeper into the solar system. Mars already has a communication delay of 3 to 22 minutes one-way depending on orbital positions — making real-time human teleoperation impossible and raising the stakes for every autonomous decision the rover makes independently.
What This Means for Robotics and Autonomous Systems
Perseverance's ENav breakthrough is more than a space milestone — it is a proof-of-concept for autonomous navigation in the extreme end of the unstructured environment spectrum, validated over thousands of real-world kilometres without a safety net.
Four practical implications stand out for the robotics industry:
- Compute-efficient autonomy is achievable at high performance levels. Developers of industrial robots and mobile platforms operating on edge hardware should study ENav's selective compute architecture — applying expensive collision-checking only on pre-filtered candidate paths rather than exhaustively.
- Think-and-move concurrency is a fundamental speed multiplier. The shift from stop-plan-move to plan-while-moving delivered an order-of-magnitude improvement in effective speed on Mars. The same architectural change in warehouse AMRs (autonomous mobile robots) and outdoor inspection platforms could dramatically increase throughput without hardware upgrades.
- Foundation models are entering the physical autonomy stack. The Anthropic waypoint-generation test signals a near-term future where LLMs handle strategic planning while embedded algorithms handle reactive execution. Companies building cobots and mobile manipulation systems should monitor this hybrid architecture closely.
- Proven reliability beats raw performance in harsh environments. NASA's deliberate choice to reuse a validated CPU over more powerful alternatives is a reminder that in high-consequence deployments — construction, mining, offshore, emergency response — system reliability and predictable failure modes often matter more than benchmark scores.
Ono frames the long-term direction clearly: "The automation of space systems is an unstoppable direction if we want to explore deeper in space." The same logic applies to any domain where humans cannot be present in real time.