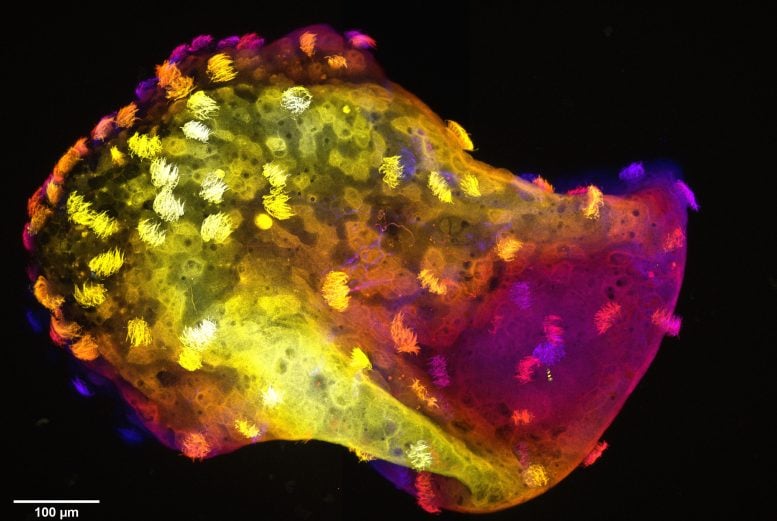
Researchers at Tufts University and Harvard's Wyss Institute have built self-moving robots from living frog cells that wire their own nervous systems — no silicon, no code, no actuators. Published in Advanced Science, these "neurobots" represent a fundamental departure from conventional robotics: instead of engineering machines to mimic biology, scientists are now building machines from biology itself.
Table of Contents
- What Is a Neurobot and How Does It Work?
- How Neurobots Differ From Conventional Robots
- What Neurobots Can Actually Do Right Now
- The Path From Lab to Real-World Deployment
- What This Means for Robotics
- Frequently Asked Questions
What Is a Neurobot and How Does It Work?
A neurobot is a self-organizing robot built entirely from living biological cells — including neurons that spontaneously wire themselves into functional circuits without any genetic engineering or external scaffolding. Unlike brain organoids or lab-on-a-chip systems, neurobots move through their environment, linking electrical neural signals directly to observable physical behaviour.
The neurobot lineage begins with xenobots, first described in a 2020 PNAS paper by Tufts University biologist Michael Levin and colleagues. Those earliest constructs were built from frog-derived structural cells that used hair-like projections called cilia (microscopic surface appendages that beat rhythmically to generate propulsion) to swim through water. They self-repaired minor damage. Some even replicated by sweeping up loose stem cells.
The fundamental limitation of xenobots, however, was that their behaviour was essentially mechanical — driven by anatomy and physics rather than any internal information-processing. They could detect chemical cues and retain traces of past experiences, but so can bacteria, fungi, and protists. What they lacked was a nervous system capable of integrating signals across the organism and dynamically directing action.
Neurobots close that gap. Neurons mature from partially differentiated stem cells alongside structural tissue, forming branching electrochemical relay networks throughout the organism. That neural architecture changes behaviour in measurable ways: neurobots spend less time stationary, trace looping and spiralling paths rather than simple repeating trajectories, and respond distinctly to neuroactive drugs.
"We're still very early in terms of understanding the system and its capabilities," says Haleh Fotowat, a neuroengineer at Harvard's Wyss Institute who collaborated on the study. "But once we understand how the neurobots self-organize, then we can begin to engineer on top of that."
How Neurobots Differ From Conventional Robots
The contrast with standard robotics architectures is stark — and philosophically provocative.
| Dimension | Conventional Robot (e.g., humanoid) | Neurobot |
|---|---|---|
| Substrate | Silicon, metal, polymers | Living biological cells |
| Actuation | Electric motors, hydraulics | Cilia (biological hair-like structures) |
| Control system | Programmed software / trained AI model | Self-wired neural circuits |
| Sensing | External sensors (cameras, LiDAR, IMU) | Distributed biological signal integration |
| Repair | Requires external maintenance | Self-repair of minor damage |
| Power source | External battery / charging infrastructure | Metabolises nutrients from surrounding medium |
| Programming | Explicit code or learned weights | Conditioning / guided learning |
| Current size | Centimetres to metres | Sub-millimetre to ~1mm |
Every assumption that underpins current industrial robot and humanoid robot design — rigid actuators, programmable controllers, discrete sensors — is absent here. The neurobot doesn't run on a compute stack. It is the compute stack.
Carlos Gershenson, a complex systems researcher at Binghamton University, puts it plainly: "These things don't occur naturally. They're made with natural cells, but we're the ones arranging them."
That distinction matters enormously. Conventional Physical AI pairs learned software intelligence with engineered hardware bodies. Neurobots collapse that distinction entirely: the intelligence and the body are one continuous biological system.
What Neurobots Can Actually Do Right Now
Measured against the ambitions of robotics, current neurobot capability is embryonic — but the trajectory matters as much as the baseline.
The neural upgrade produces behaviours qualitatively different from non-neural biological machines. Neurobots explore more actively, demonstrate more complex locomotion patterns, and exhibit drug-dependent behavioural changes that confirm neural signalling is genuinely driving movement — not merely coinciding with it. This links electrical activity to physical action in a way that earlier xenobots couldn't achieve.
The research team, including Levin and Fotowat, now plans to introduce human neural cells into "anthrobots" — a variant built from human lung cells rather than frog tissue — extending the neurobot framework into a fully human biological context. The longer-term ambition is conditioning these organisms to perform specific tasks through guided learning, analogous, as University of Vermont roboticist Josh Bongard puts it, to "dogs trained to sniff for bombs."
But there is an important caveat that serious readers should register: the gap between current demonstration and deployed capability is vast. The organisms are microscopic, short-lived, and operate in constrained aqueous environments. Their neural circuits self-organise, but cannot yet be reliably directed toward specific behaviours on demand. The science of understanding neurobot self-organisation must precede any science of engineering it.
The Path From Lab to Real-World Deployment
The first commercial bets on this technology are modest and appropriately scoped. Fauna Systems — the startup co-founded by Levin and Bongard, and led by CEO Naimish Patel — is targeting environmental sensing as its initial market, specifically aquaculture monitoring, wastewater analysis, and pollutant detection.
The core value proposition is signal integration: where a single chemical sensor detects one analyte, a living organism integrates dozens of simultaneous environmental stressors — heavy metal concentrations, pH shifts, agricultural runoff traces — into a single, measurable behavioural response. Precedent exists in Poland, where multiple cities already deploy freshwater mussels wired with sensors as living water-quality sentinels. Xenobots could extend that concept with greater sensitivity and specificity.
Crucially, Fauna's near-term product pipeline centres on first-generation xenobots, not neurobots. "Right now, we're looking for the intersection between unmet commercial need and emerging capability," Patel says. The neural complexity of neurobots remains a research problem. Simpler biological machines are closer to commercially deployable.
The roadmap implied by the research, however, points somewhere significantly more ambitious: cyborg systems that integrate biological neural tissue with engineered control infrastructure, potentially combining the adaptability of living nervous systems with the precision of electronic components.
What This Means for Robotics
Neurobots are not going to displace humanoid robots or cobots in factories this decade. But they reframe the long-term question about what "robotics hardware" ultimately means.
The entire current investment thesis in physical robotics — from Boston Dynamics to Figure AI to Unitree — rests on an assumption: that the right architecture is silicon intelligence embodied in engineered mechanical systems. The neurobot research suggests a parallel path exists where the body, the actuators, and the intelligence are all grown rather than built.
For robotics engineers, the immediate practical relevance is limited but the research value is high. Neurobots offer a model system for studying how simple neural networks produce complex coordinated behaviour — a question that directly informs how we design control architectures for conventional robots. Understanding emergent biological organisation could yield design principles that improve artificial systems.
For researchers in embodied AI and soft robotics — the field building robots from flexible, compliant materials that interact more safely with biological environments — neurobots represent an existence proof that sub-millimetre biological machines can achieve directed locomotion without any engineered structure whatsoever.
The deeper provocation, as Levin frames it: "Where does form and function come from in the first place? When it's not evolved and it's not engineered, where do these patterns come from?" That question sits at the intersection of developmental biology, neuroscience, and robotics — and the answer, when it comes, will matter far beyond the lab.