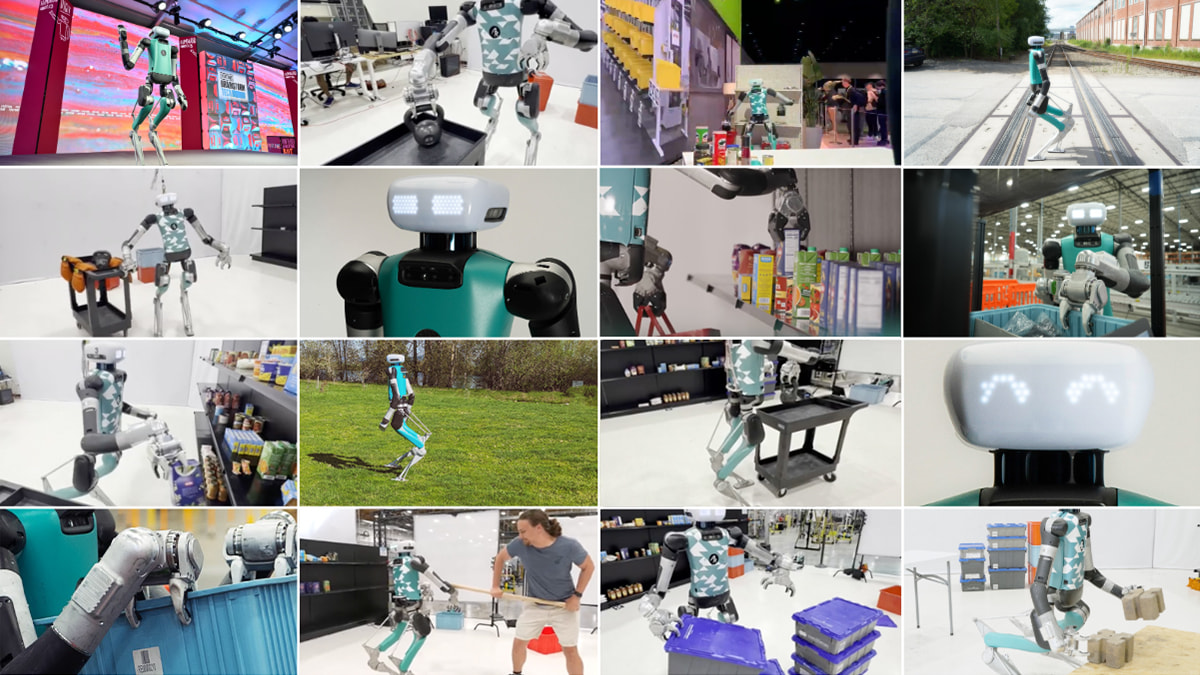
Anchor 1 from Archon Robotics achieved a 30% to 80% decrease in tracking error versus all existing controllers under the strictest real-world global scoring setting, first reported by Arxiv. The benchmark measures precision, sustained execution stability and reachability across diverse whole-body coordination demands, where even small errors can cause failure.
Humanoid controllers have acquired increasingly diverse motor skills, but translating those capabilities into precise, stable whole-body manipulation remains challenging. Anchor 1 is introduced alongside a benchmark to evaluate those capabilities systematically.
Anchor 1 uses calibrated sparse motion references to preserve task-relevant human-motion structure without online joint-space retargeting. That leaves kinematic freedom for precise control. Offline curation pairs robot motions with those references to shape the training distribution toward stable, physically plausible whole-body coordination.
Explicit error feedback is decoupled from motion encoding, improving control precision while supporting flexible command interfaces. The benchmark assesses precision, sustained execution stability and reachability across diverse whole-body coordination demands.
Evaluations in simulation and on hardware showed stronger precision and stability across all evaluation tracks. In the strictest setting, the tracking-error decrease came with fewer look-ahead inputs and without retargeting.
The controller and benchmark cover complementary sides of the problem: a control method and a systematic way to evaluate it. Downstream experiments also demonstrated more efficient teleoperated data collection and higher task success using the same deployment pipeline.