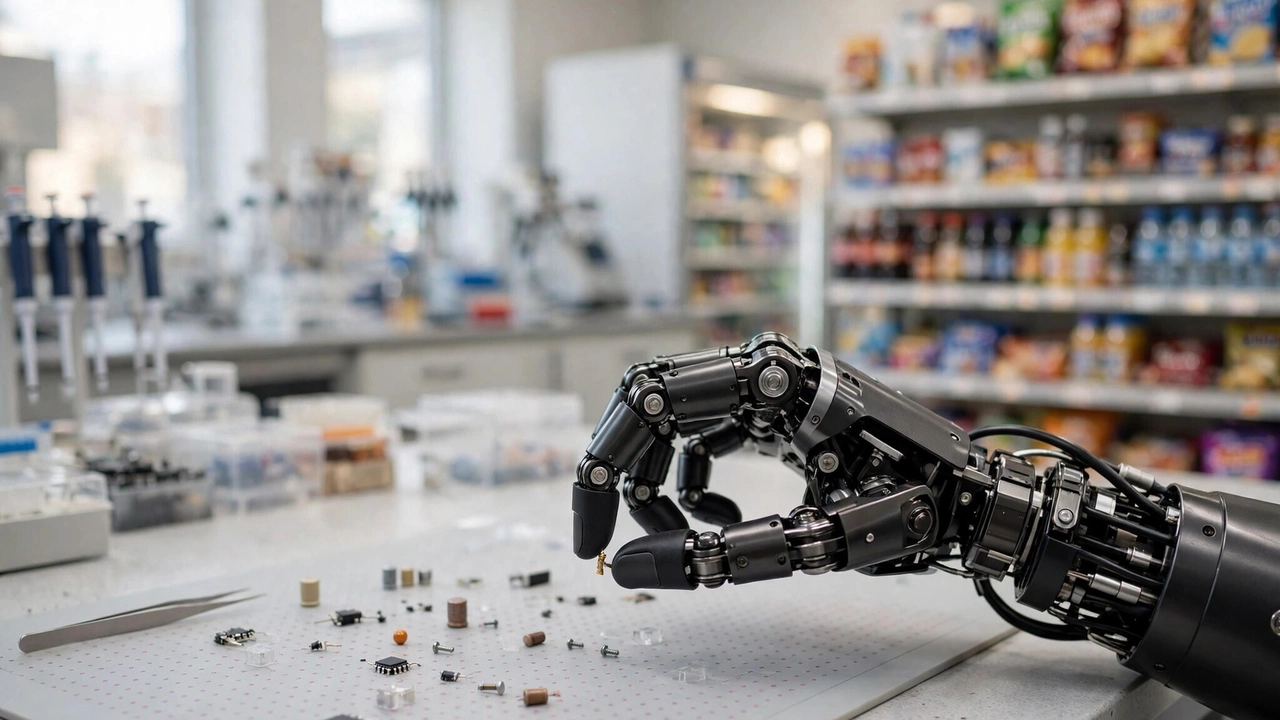
AGIBOT has introduced GO-3 Preview, an embodied foundation model built to connect pre-training, post-training and learning after deployment, first reported by Roboticsandautomationnews. The approach aims to let robots keep improving after deployment, using physical and virtual practice and lessons from real-world tasks instead of treating pre-training as the finish line.
GO-3 Preview ranks first on RoboDojo, RoboTwin and RoboColiseum. AGIBOT says the model will be fully open-sourced by the end of 2026.
The model’s World Reasoning Action Model (WRAM) architecture combines task understanding, predictions of future states and action generation. AGIBOT presents that combination as a way to help robots transfer skills across tasks, rather than rely on fixed movements for familiar situations.
GO-3 Preview is paired with Genie Evolver for post-training and Genie Master for deployment. Genie Evolver combines a fleet of 100 physical robots with physics simulation and world models, using execution and virtual exploration to refine action strategies through feedback.
Genie Master connects planning, execution, feedback and experience retention. Its framework can use lessons from successful and unsuccessful attempts in long-term memory, while recorded trajectories and feedback can also support further training of action policies.
AGIBOT demonstrated Genie Master with its Genie G2 robot in a real convenience store. The company says the robot identified causes of task failures, adjusted strategies and improved across complex manipulation tasks without human demonstrations or manual tuning.
The design makes deployment another learning stage, not the end of model development. AGIBOT says GO-3 Preview will be fully open-sourced by the end of 2026.