Prețul mediu zilnic
Sume în USD
Descriere
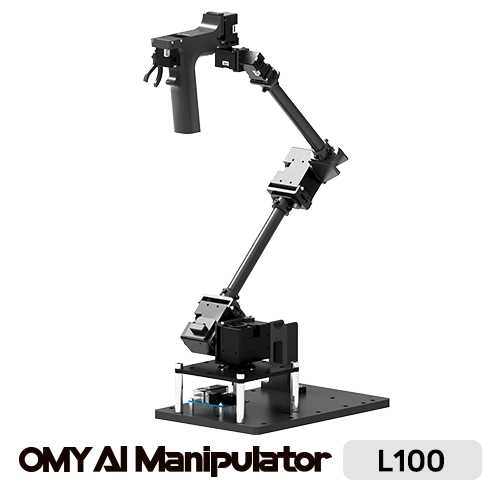
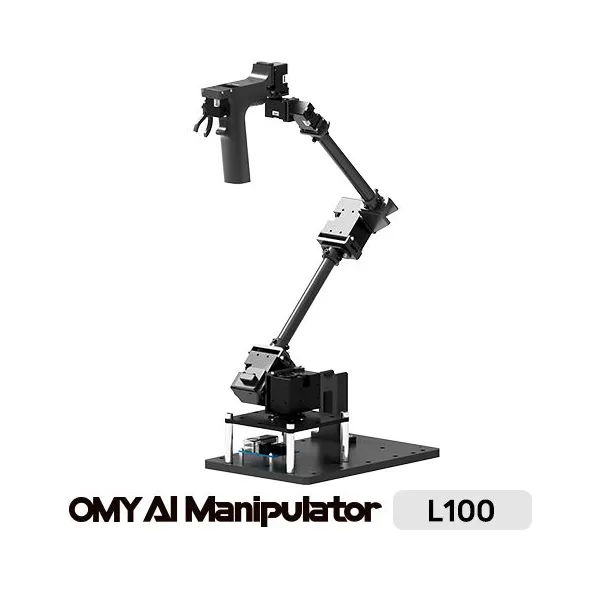
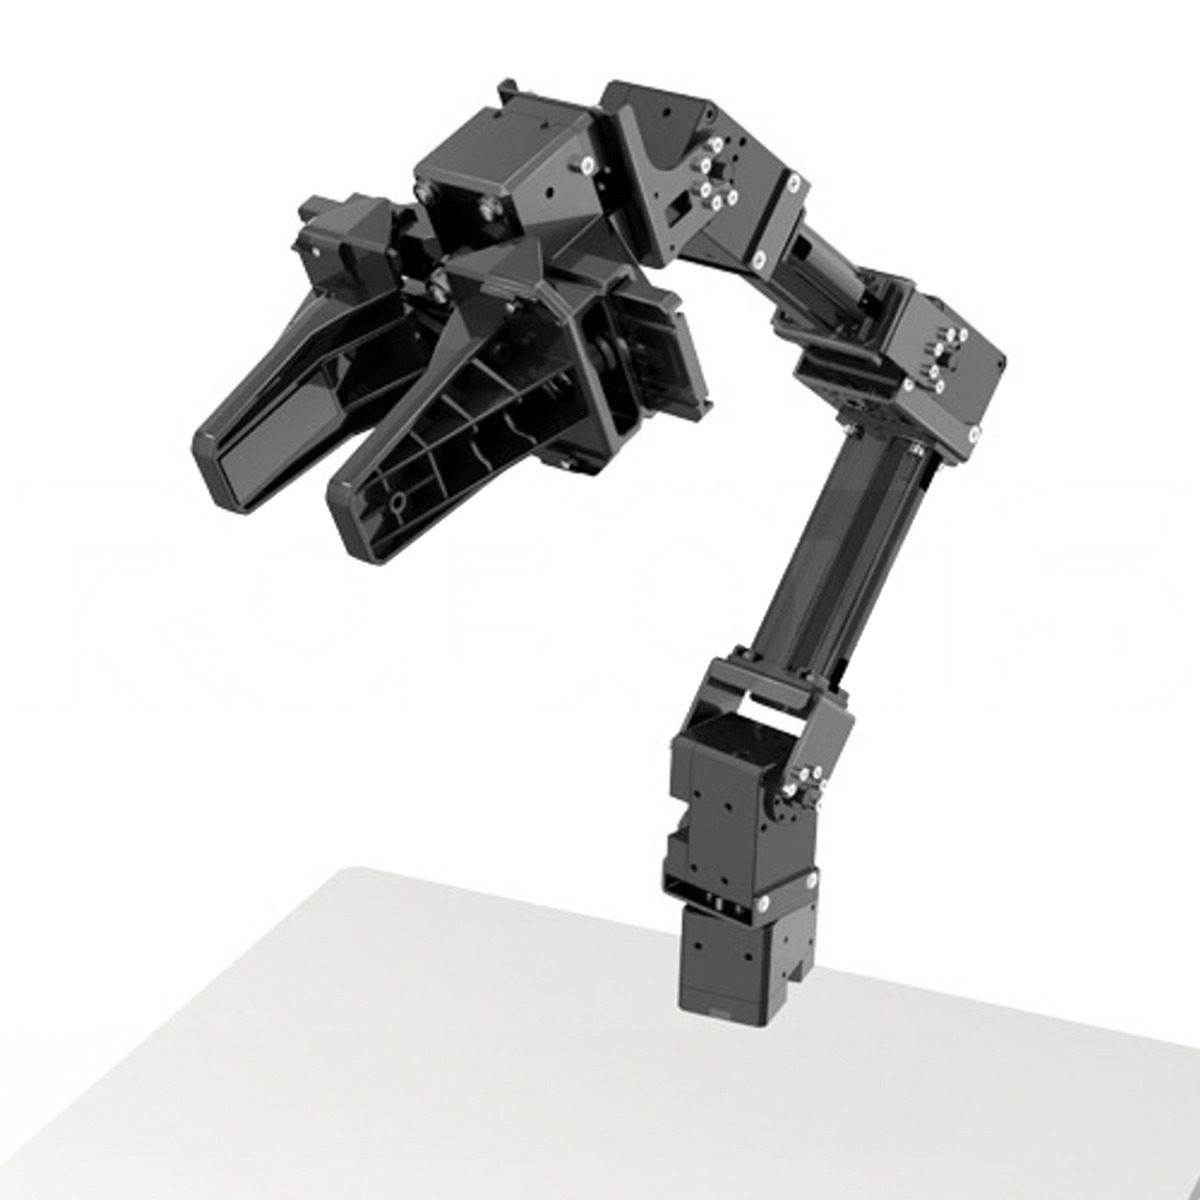
Features Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Offering operational and customization flexibility via a lightweight (under 1.5kg) and modular structure. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo, MuJoCo). Enabling compatibility between heterogeneous/multiple robots based on the ROS2 environment. Specification Items OMY-L100 (Leader) DOF 7 Payload - Reach 560 [mm] Weight 1.46 [kg] Operating Voltage 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Repeatability - Brake Force - TCP Speed - Host Interface U2D2 (USB 2.0) Internal Communications TTL Multidrop Bus Communication Baudrate 4 [Mbps] Robot Hand - Camera - Links e-Manual
Features Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Offering operational and customization flexibility via a lightweight (under 1.5kg) and modular structure. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo, MuJoCo). Enabling compatibility between heterogeneous/multiple robots based on the ROS2 environment. Specification Items OMY-L100 (Leader) DOF 7 Payload - Reach 560 [mm] Weight 1.46 [kg] Operating Voltage 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Repeatability - Brake Force - TCP Speed - Host Interface U2D2 (USB 2.0) Internal Communications TTL Multidrop Bus Communication Baudrate 4 [Mbps] Robot Hand - Camera - Links e-Manual
Istoricul prețurilor
Un punct de date pentru fiecare zi, calculat ca medie după data observației.
Sume în USD
Mediile sunt calculate pentru fiecare zi UTC, pe baza tuturor prețurilor ofertelor înregistrate.
Robotis
£2.215,05
Robotis
£2.215,05
Robotis
1.838,95 €
Robotis
£1.999,50
Robotis
£1.999,50

Robotis
$1.629,09

Robotis
$1.933,61

Robotis
$1.908,31
Robotis
3.291,60 €
Robotis
1.540,95 €
Robotis
£1.118,42
Robotis
£1.250,61
🍪 Preferințe pentru cookie-uri
Folosim cookie-uri pentru a măsura performanța. Politica de confidențialitate