Durchschnittspreis pro Tag
Beträge in USD
Beschreibung
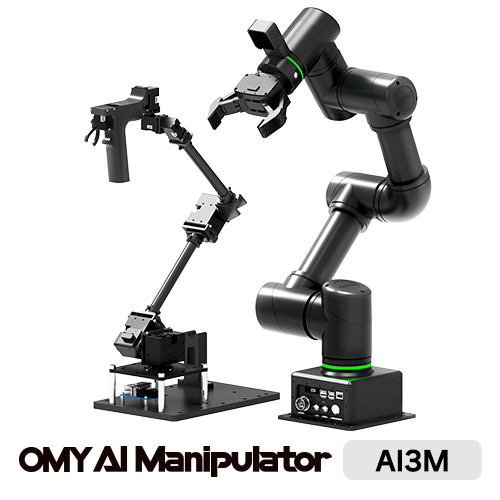
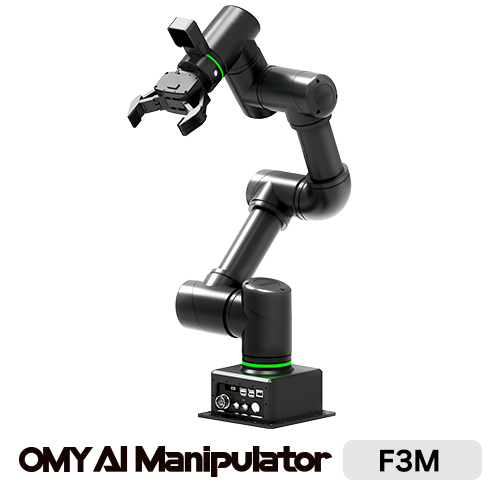
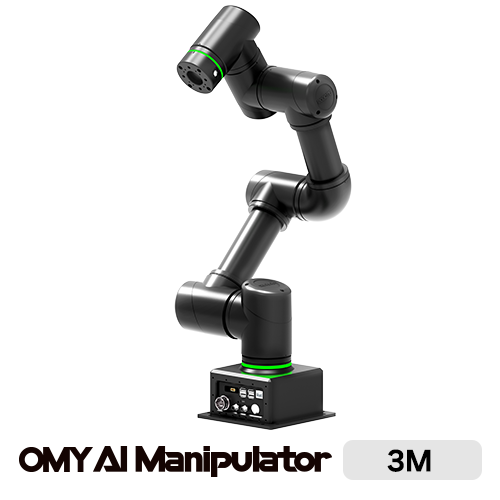
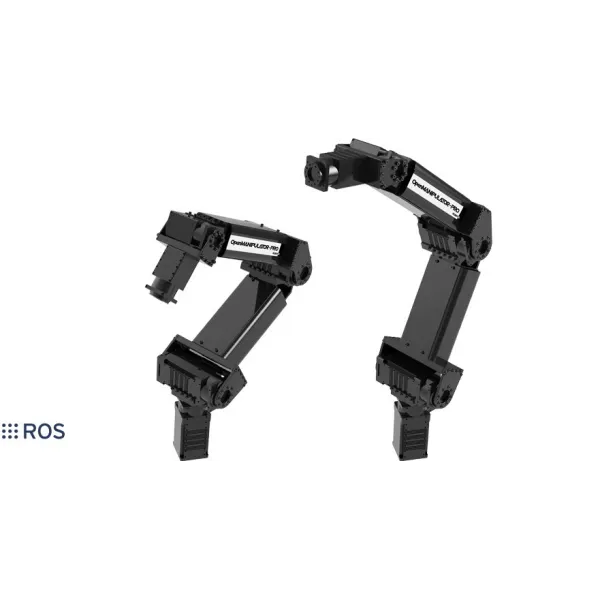
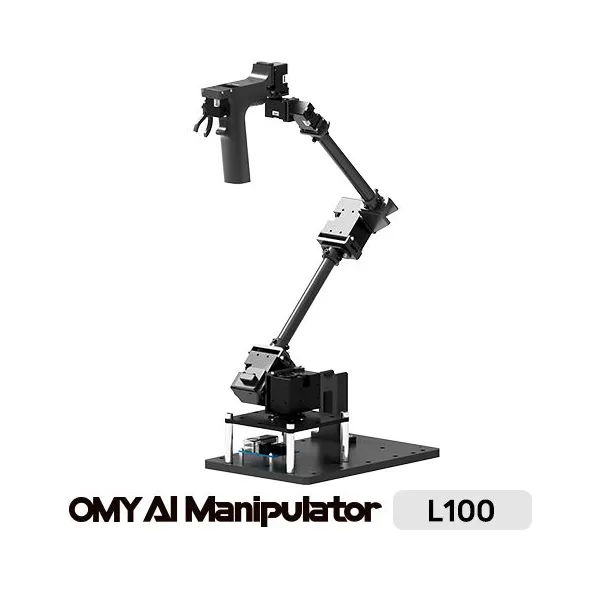
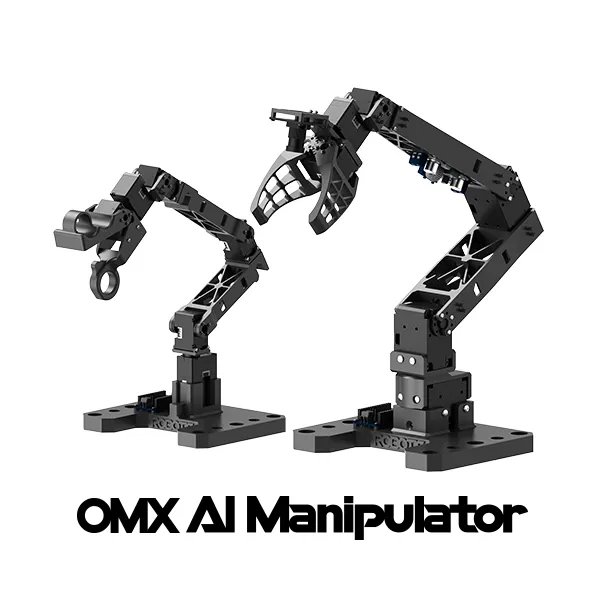
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Adopting built-in collision avoidance feature to Prevent operator injury and robot damage through. Delivering smooth acceleration and deceleration during operation with the time-based trajectory profile function. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-L100 (Leader) OMY-F3M (Follower) DOF 7 6 Payload - 3 [kg] Reach 560 [mm] 580 [mm] Weight 1.46 [kg] 13.5 [kg] Operating Voltage 12 [VDC] 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability - ±0.05 [mm] Brake Force - 200% of the continuous torque for each joint TCP Speed -
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Adopting built-in collision avoidance feature to Prevent operator injury and robot damage through. Delivering smooth acceleration and deceleration during operation with the time-based trajectory profile function. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-L100 (Leader) OMY-F3M (Follower) DOF 7 6 Payload - 3 [kg] Reach 560 [mm] 580 [mm] Weight 1.46 [kg] 13.5 [kg] Operating Voltage 12 [VDC] 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability - ±0.05 [mm] Brake Force - 200% of the continuous torque for each joint TCP Speed -
Preisverlauf
Ein Datenpunkt pro Tag, gemittelt nach Beobachtungsdatum.
Beträge in USD
Die Durchschnittswerte werden pro UTC-Tag anhand aller erfassten Angebotspreise berechnet.

Robotis
$17.248,85

Robotis
$11.498,85
Robotis
13.923,95 €
Robotis
£9.313,13

Robotis
$14.373,85
Robotis
15.549,95 €
Robotis
£7.420,21

Robotis
$16.176,02
Robotis
17.272,96 €
Robotis
894,92 €
Robotis
3.291,60 €
Robotis
444 €
🍪 Cookie-Einstellungen
Wir verwenden Cookies zur Leistungsmessung. Datenschutzerklärung