


Image
AGIBOT OmniGlove
High-precision hand-motion capture and dexterous-hand teleoperation in one data glove. OmniGlove combines 6 EMF sensors and 7 IMUs with bundled Windows software for visualization, calibration, recording, playback and teleoperation. OmniGlove Pro adds full-palm tactile sensing with 746 tactile points across 17 zones per hand, with tactile and hand-pose data aligned in time. Both versions are sold as a pair of gloves.
Sold as a pair of gloves. Quantity 1 = one pair.
Quantity:
Data collection & teleoperation
Human leads.
Robot follows.
A data glove combining high-precision hand-motion capture with teleoperation. OmniGlove Pro adds full-palm tactile sensing for multimodal data collection and human–robot interaction research.
OmniGlove / OmniGlove Pro

Key specs · OmniGlove / Pro
Put it on. Every move, captured.
- Position accuracy (typical)
- ≤1 mm
- Orientation accuracy (typical)
- ≤1.5°
- Motion-to-data latency*
- 10 ms
- Full-palm tactile · Pro
- 746 points
- Standard weight (including cable)
- 105 g
- Calibration time
- 10–15 s
01 / Precise tracking
Every flex,
precisely tracked.
Fusing 6 EMF sensors with 7 IMUs, wrist and fingers are solved as one chain, outputting 21 joint angles, 21 keypoints and 5 fingertip poses in real time.
6 EMF + 7 IMUsSensor fusion21 + 21 + 5Joint angles · keypoints · fingertip poses

02 / Anti-interference
Fields shift.
Pose holds.
A built-in anti-magnetic algorithm lets EMF and IMU data complement each other. Optimized for electromagnetic fields, metal objects and two-hand use, tracking stays stable in complex environments.

03 / OmniGlove Pro
Every grip.
Force made visible.
The Pro version covers each hand with 746 tactile points across 17 zones, sensing contact force from fingertips to palm. Tactile data is time-aligned with hand pose, capturing both motion and force.
- Tactile points / zones
- 746 / 17
- Force range
- 0–20 N
- Force resolution
- 0.1 N
- Spatial resolution
- <3 mm


04 / Teleoperation
Human leads.
Robot follows.
Once calibrated to the user’s hand, the glove drives a dexterous hand directly, with single- or dual-handed operation. OmniGlove Pro supports synchronized motion and force replay, reproducing human operation on real robots.

Teleop-ready dexterous hands

OmniHand 3

OmniHand 3 Ultra
05 / Ready out of the box
Fully in-house.
Easy to integrate.
Developed in-house, the bundled Windows host software handles visualization, calibration, recording, playback and teleoperation in one toolchain, for a smoother data-collection workflow.
10–15 sCalibration time1000 HzIMU output · EMF 125 Hz · tactile 125 Hz (Pro)
- Visualize
- Calibrate
- Record
- Replay
- Teleoperate

Product video
See the whole system.
Choose your version
Two versions. Your choice.
Compare motion capture and full-palm tactile sensing. Both versions are sold as a pair of gloves; select your Version in the product options above.
Motion data
OmniGlove
Motion capture + teleoperation
- 6 EMF + 7 IMU fusion tracking with a built-in anti-magnetic algorithm
- 21 joint angles · 21 keypoints · 5 fingertip poses
- Calibration, recording, playback and teleoperation built in
For dexterous-hand teleoperation and hand-motion data.
Motion + tactile data
OmniGlove Pro
Motion capture + full-palm tactile sensing + teleoperation
- Everything in the standard version
- Full-palm sensing: 746 tactile points / 17 zones per hand, 0–20 N
- Tactile and hand-pose data aligned in time
For contact-rich data, tactile and HRI research.
Specifications
Technical specs.
Shared motion-tracking performance. Additional tactile sensing in OmniGlove Pro.
SpecificationOmniGloveOmniGlove Pro
Sensing6 EMF + 7 IMU fusion tracking
Position accuracy≤1 mm (typical)
Orientation accuracy≤1.5° (typical)
Anti-interferenceBuilt-in anti-magnetic algorithm, optimized for electromagnetic fields, metal objects and two-hand use
Hand solver output21 joint angles · 21 keypoints · 5 fingertip poses
Motion sensor output rateEMF: 125 Hz · IMU: 1000 Hz
Motion-to-data latency*10 ms
Full-palm tactile—746 points / 17 zones per hand
Tactile output rate—125 Hz
Force range—0–20 N
Force resolution—0.1 N
Spatial resolution—<3 mm
Weight (including cable)105 ± 5 g130 ± 5 g
Calibration time10–15 s
Teleoperation compatibilityOmniHand 3 · OmniHand 3 Lite · OmniHand 3 Ultra
SizeM (L coming soon)
Shared values apply to both versions. “—” indicates a Pro-only capability.
*Device output <10 ms; not end-to-end teleoperation latency.
OmniGlove
Wear & capture.
Move & follow.
Turning every human move into data for dexterous hands. Discuss your research or teleoperation setup with our team.
Contact salesPrice history
Average price history
One data point per day, averaged by observation date.
Daily average price
Amounts in USD
Averages are computed per UTC day from every recorded offer price.
Related Listings

AGIBOT G2 Battery Lewa
Agibot · Eindhoven, NL
5,900 zł

AGIBOT G2 Battery Prawa
Agibot · Eindhoven, NL
5,900 zł

AgiBot OmniPicker
Agibot · Eindhoven, NL
2,900 zł

AgiBot G2 Acc Teleoperation kit
Agibot · Eindhoven, NL
29,900 zł

AGIBOT D1 Battery
Agibot · Eindhoven, NL
from 1,590 zł

AGIBOT OmniPicker Adaptive Gripper
Agibot · Paris, FR
$601.25

AGIBOT A2 Ultra and A2 Lite VR Teleoperation Kit
Agibot · Paris, FR
$2,750
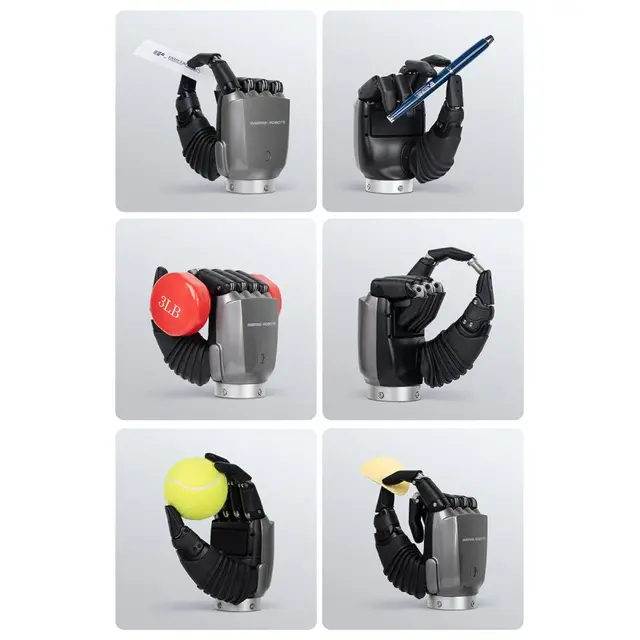
Inspire Robots Dexterous Hand RH56F1 (CAN)
Inspire Robots · Dormagen, DE
5,799.95 €

Hesai XT16 16-Channel 3D LiDAR Sensor for Robotics (with GO2 Mounting Bracket)
Hesai · New York, US
$6,600

Unitree B2-Contact Charger Kit - DEMO CONDITION
Unitree · Austin, US
$6,200

Unitree XT16 LiDAR for Go2-W
Unitree · Austin, US
$5,900

Unitree Remote control with screen (Dual camera + 3 in 1)
Unitree · Austin, US
$5,900