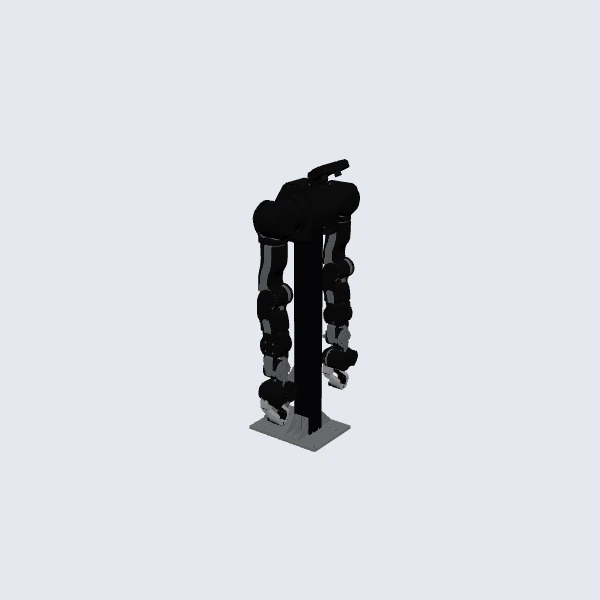
What is the Enactic OpenArm 2.0?
An open-source pair of human-sized robot arms on an aluminium pillar, made for physical AI research: you drive them to record demonstrations, with force felt both ways, and train robot models on the data. Enactic designed it in Tokyo; its published parts list for the 1.0 arms adds up to ¥960,438 (about $6,069), and WowRobo sells the 2.0 set assembled for $6,500 online ($6,000 by email order).
Specifications
Facts about the Enactic OpenArm 2.0 from its project's published documentation, design files and its makers' own figures. A figure marked Estimate is worked out from those files or parts lists rather than stated by the maker.
| Spec | Detail |
|---|---|
| Type | Two human-scale robot arms, each with 7 joints and a two-finger gripper, on an aluminium pillar bolted to a table. Made for physical AI research: an operator drives them (teleoperation, with force felt both ways) to record demonstrations, and trained models then run them. |
| Size | Arm reach 606 mm. Measured on the robot description: the shoulders are 0.697 m above the base plate and 305 mm apart, the chest is 0.77 m tall and the head camera sits on top. The base plate is 250 × 190 mm, 8 mm thick, with 48 M6 holes. Enactic scaled the arms for a person 160–165 cm tall. |
| Mass | 5.5 kg per arm (WowRobo’s specifications; whether this includes the gripper is not stated). The link masses in the robot description (modelled values) add up to 5.36 kg per arm, 6.13 kg with the gripper, and 16.1 kg for the whole set with the pillar and the camera mount. |
| Actuated joints | 16 motors: 7 joints in each arm (J1 to J7) and one gripper motor in each hand (J8). The two fingers of a gripper move together: in the description the second finger copies the first. |
| Actuators | Damiao joint motors with their own drivers: DM-J8009P-2EC at the shoulder (J1, J2; 40 N·m peak, 9:1), DM-J4340P-2EC and DM-J4340-2EC in the upper arm and elbow (J3, J4; 27 N·m peak, 40:1), DM-J4310-2EC V1.1 in the wrist and gripper (J5 to J8; 7 N·m peak, 10:1). Each has two 14-bit magnetic encoders and talks CAN. |
| Payload | 4.1 kg per arm held for one minute with the arm stretched out (nominal), 6.0 kg moved and held for a second (peak), in both cases including whatever is mounted on the arm. |
| Control and power | 1 kHz control over CAN-FD. A computer drives the motors through USB-to-CAN FD adapters (two in Enactic's 1.0 parts list); Enactic's software runs the motors in MIT mode (position and speed gains plus a torque command). The 1.0 list adds two 24 V, 15 A power supplies and an emergency stop. There is no computer in the robot. |
| Sensors | Two magnetic angle sensors in every motor; a camera in each gripper (Arducam B0495: 1920 × 1200, global shutter, 95° diagonal view); and in the standard 2.0 set a Stereolabs ZED Mini stereo camera above the chest. All three cameras share one USB hub. |
| Gripper | A compact two-finger pinching gripper with a 30 N grip force (WowRobo’s figure; the conditions are not stated), its own motor, a camera inside the case and fingers that are easy to swap (2.0; the 1.0 gripper was linkage-driven, without a camera). |
| Structure | Machined 6061 aluminium and SUS304 stainless-steel parts, made to order by MiSUMi's meviy service from Enactic's part numbers; 3D-printed covers and fingers; a 60 × 60 mm aluminium extrusion as the pillar. |
| Parts cost (Enactic’s list) | ¥960,438 (about $6,069 at the 9 Oct 2026 rate) for two arms and the pedestal in Enactic's OpenArm 1.0 parts list: motors ¥397,356 (41%), mechanical parts ¥478,518 (50%), electronics ¥84,564 (9%). The README gives $6,500 for a complete bimanual system. 2.0 keeps the arms, motors and electronics and swaps the gripper; its cameras and printed parts are not priced in the public lists. |
| Price (11 Nov 2026) | WowRobo, the manufacturer Enactic certifies, sells OpenArm 2.0 assembled and tested: without the top stereo camera $6,500 online or $6,000 by email order, with it $7,300 or $6,800. Enactic's purchase page gives WowRobo 20–40 days and worldwide shipping. RT Corporation in Tokyo, Enactic's official supplier in Japan, sells it by quotation. |
| Designed by | Enactic, Inc., Tokyo (founded July 2025), which also builds the Ena care robot. OpenArm 01 launched in July 2025 and OpenArm 2.0 in May 2026, adding the in-hand camera gripper, the OpenArm Cell test bench and the KER teaching arm (KER not released yet). |
3D model
The interactive 3D model on this page is converted from the project's published design: OpenArm by Enactic, Inc. (github.com/enactic/openarm_description) and contributors; ZED Mini mesh by Stereolabs (github.com/stereolabs/zed-ros2-description). Used under Apache-2.0.
Sources
- Project repository: github.com/enactic/openarm_description