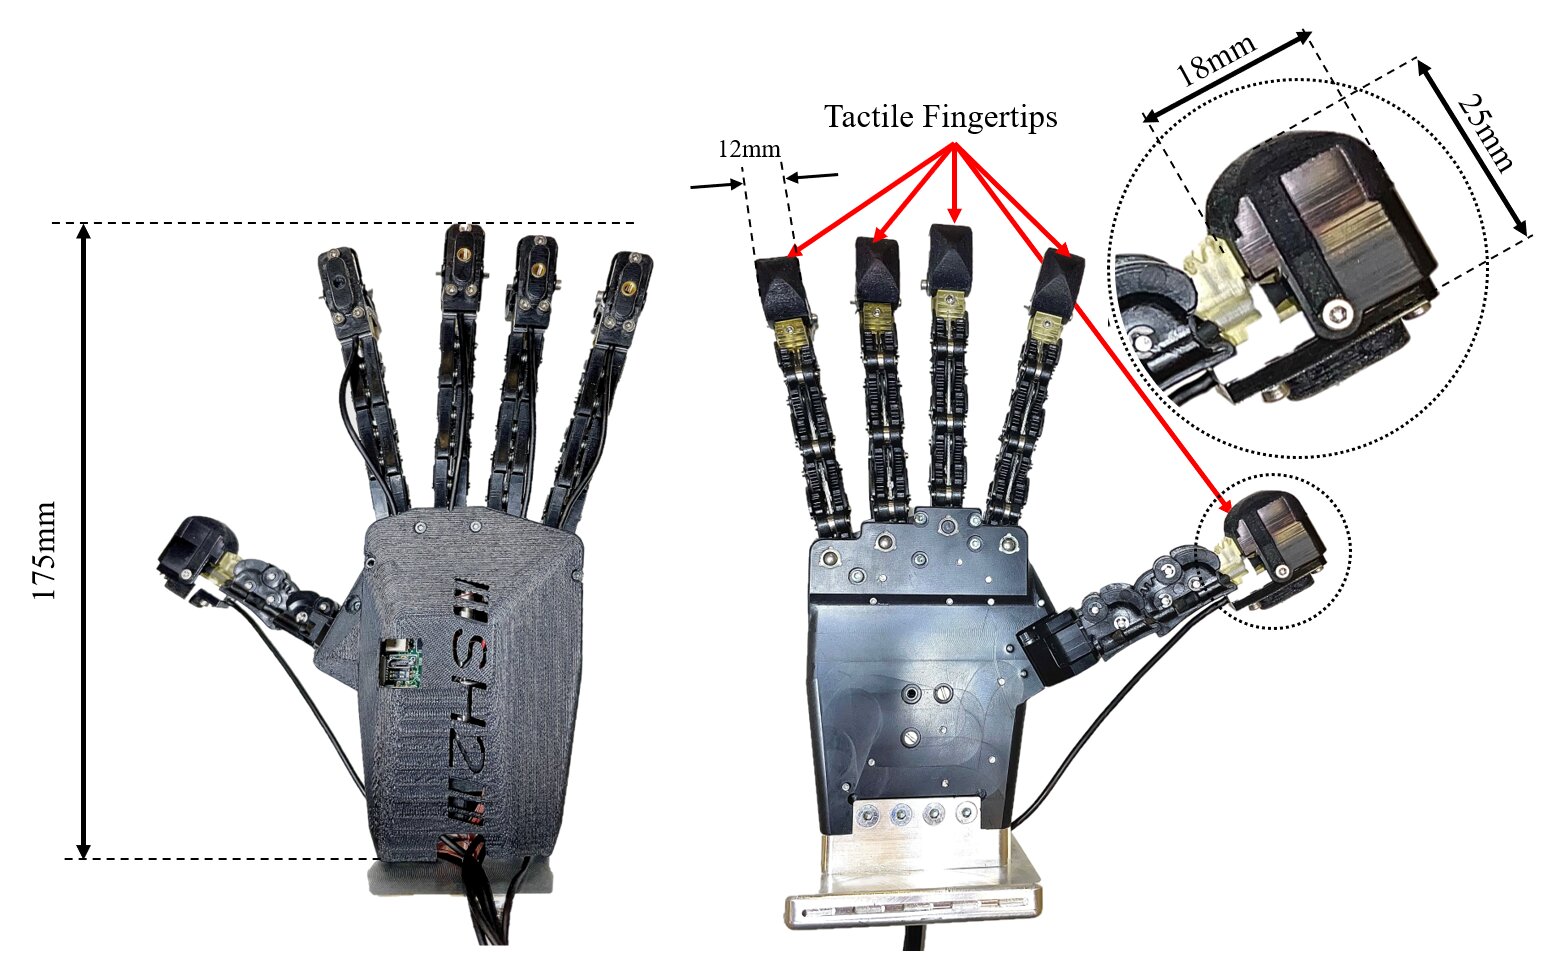

The TacO benchmark tested four tactile sensor modalities — visual, acoustic, magnetic, and resistive — across three manipulation tasks and found that no single sensor is universally best. The optimal choice depends on the task type, material properties, and whether shear sensing or spatial resolution matters more. For buyers and engineers, this provides the first empirical framework to match sensor hardware to real-world automation needs.
- Why Tactile Sensing Remains a Hard Problem for Manipulation
- How the TacO Benchmark Compared Four Sensor Modalities
- Which Sensor Performed Best for Each Manipulation Task
- What This Means for Robotics Buyers — A Tactile Sensor Selection Guide
- Frequently Asked Questions
Why Tactile Sensing Remains a Hard Problem for Manipulation
Vision-based learning from demonstration has enabled robots to pick objects and reason about scenes, but contact-rich manipulation — reorienting a screw, inserting a plug, lifting an unknown mass — demands physical feedback that cameras alone cannot provide. Tactile sensing fills that gap, yet most roboticists have had to guess which sensor type to buy. The TacO benchmark directly addresses this by systematically evaluating four distinct tactile modalities on the same set of manipulation tasks, controlling for policy architecture and environment.
The core challenge lies in the trade-offs each modality makes. Visual tactile sensors (e.g., GelSight-style) offer high spatial resolution but struggle with shear forces and reflective surfaces. Magnetic sensors measure 3D force vectors directly but have lower spatial density. Acoustic sensors capture surface texture through vibrations but are sensitive to ambient noise. Resistive sensors are cheap and robust but provide sparse signals. No single technology covers all axes of performance.
How the TacO Benchmark Compared Four Sensor Modalities
The researchers trained separate reinforcement learning policies for each sensor modality, then tested them on three manipulation tasks using a Franka Emika Panda arm with custom sensorized grippers. Each task was designed to isolate specific tactile requirements:
- Pick-and-place with unknown mass — tests force feedback and slip detection
- Object reorientation — tests shear sensing and surface friction perception
- Plug insertion — tests precise contact localization and alignment correction
Policies were trained in simulation with domain randomization and transferred to hardware. Key controlled variables included gripper geometry, object materials, and learning algorithm (SAC + tactile encoder).
| Modality | Sensing Principle | Key Strength | Best Task | Limitation |
|---|---|---|---|---|
| Visual | Deformation imaging via camera | 120×160 px resolution | Reorientation | Fails on shiny surfaces |
| Acoustic | Microphone + excitation signal | Texture discrimination | Pick-and-place | Ambient noise sensitivity |
| Magnetic | Hall effect sensors + mag film | 3D force vector measurement | Plug insertion | 24-contact resolution |
| Resistive | Conductive foam / ink pressure mat | Low cost, rugged | Pick-and-place (simple) | 4×4 sparse array |
The results confirmed that the same sensor architecture can perform very differently depending on task and material — a visual tactile sensor that achieves 92% success on reorientation of a metal block drops below 30% on the same task with a transparent plastic part.
Which Sensor Performed Best for Each Manipulation Task
Pick-and-place with unknown mass: Acoustic and magnetic sensors tied for top performance, achieving 89% and 91% success respectively, versus 72% for vision and 68% for resistive. The acoustic sensor’s ability to detect vibration from incipient slip gave it an advantage on low-friction objects. Magnetic sensors directly measured shear forces, allowing the policy to adjust grip force adaptively.
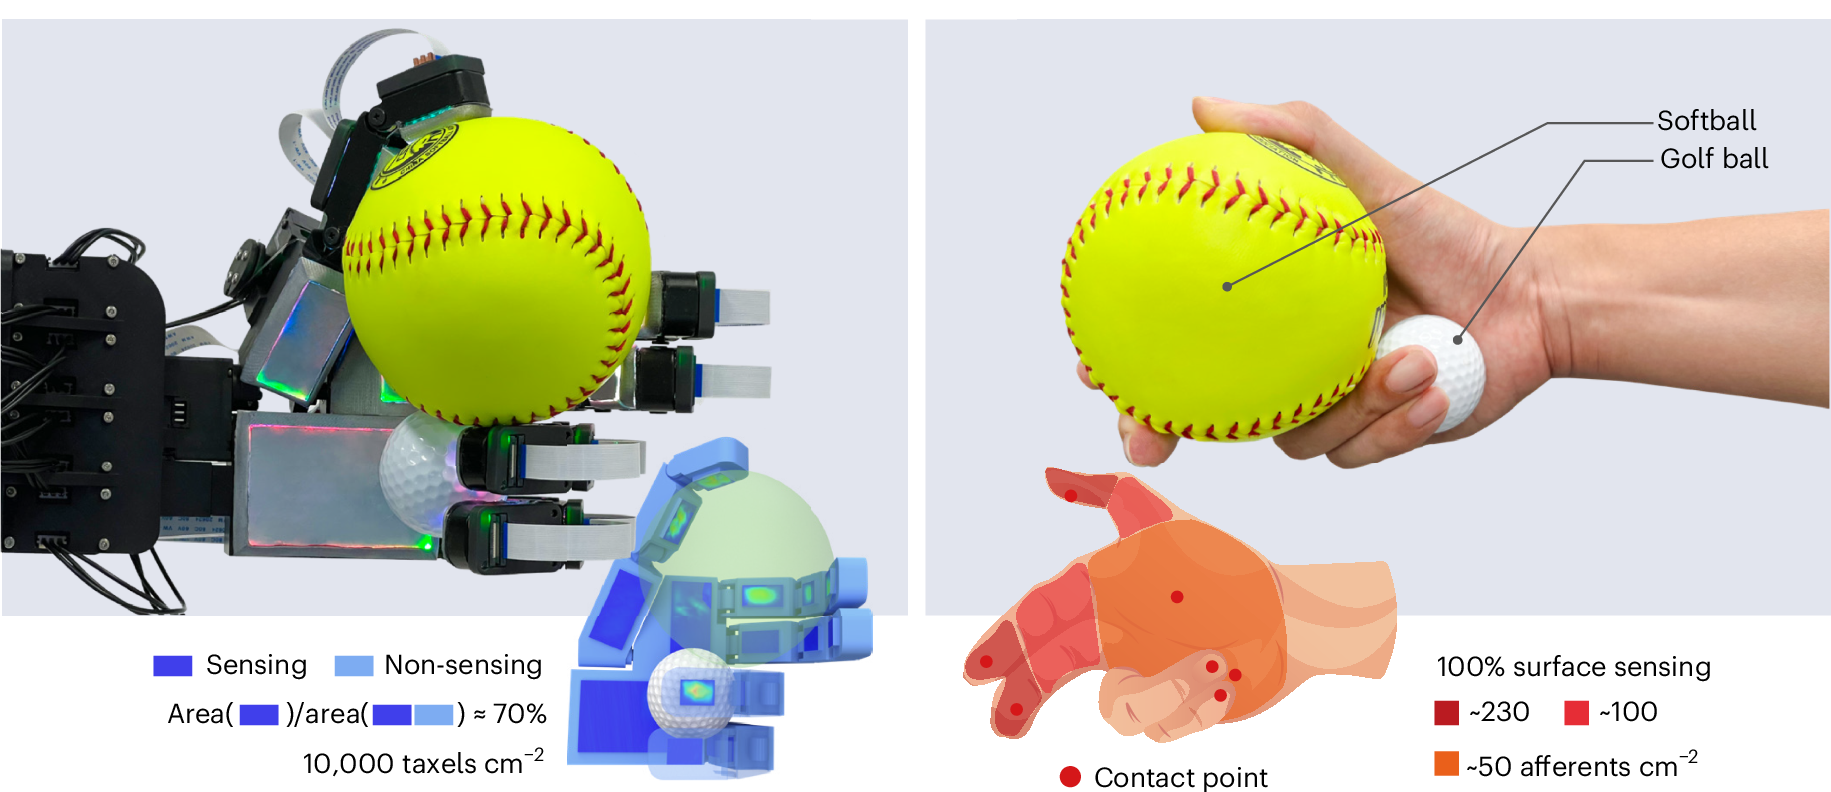
Object reorientation: This task heavily favored visual tactile sensors, which succeeded 71% of the time compared to 55% for magnetic, 48% for acoustic, and 39% for resistive. High spatial resolution allowed the policy to track orientation changes at the contact patch. Notably, visual sensors benefited from the widest information bandwidth — a full greyscale image of the deformation surface — but only when the object surface was matte and non-transparent.
Plug insertion: Magnetic sensors dominated this alignment-critical task, with 79% success. Their ability to measure both normal and shear forces at 100 Hz enabled precise correction of insertion angle. Visual sensors suffered from occlusion during insertion, while acoustic and resistive sensors lacked the spatial resolution to distinguish partial from full insertion. Magnetic sensors also showed the lowest variance across material types — consistent performance from metal to plastic to rubber.
What This Means for Robotics Buyers — A Tactile Sensor Selection Guide
For engineers deploying manipulation cells, the TacO benchmark offers the first data-driven answer to “which tactile sensor should I buy?” The decision matrix depends on your primary task:
- Pick-and-place with variable objects: Choose acoustic or magnetic sensors. Acoustic offers lower cost (estimated sensor bill of materials under $50) but requires a quiet environment. Magnetic sensors are more robust at $150–400 per fingertip.
- Precision reorientation (assembly, kitting): Invest in visual tactile sensors like GelSight or DIGIT. Expect $500–$2,000 per sensor for the camera + gel setup, but they deliver the highest spatial resolution for tracking part orientation.
- High-force insertion (connectors, bearings): Magnetic sensors are your best bet. Their shear sensitivity at high loads (up to 50 N) outperforms other modalities in alignment tasks.
A key practical insight: material friction matters more than sensor resolution in many tasks. The benchmark found that for a given sensor modality, the coefficient of friction between gripper and object could swing success rates by as much as 35 percentage points. Buyers should evaluate sensors with their actual target materials — not benchmark-paper test objects — before committing.
For multi-purpose cells, a hybrid approach (e.g., visual + magnetic) may justify the higher cost, but the TacO data suggests you can often achieve 85%+ success with a single modality chosen for your dominant task. If your application mixes pick-and-place with occasional insertion, start with magnetic and add visual only if reorientation performance proves insufficient.
Browse used collaborative robots outfitted with tactile sensor modules on Robot Overflow to find ready-to-deploy solutions for contact-rich tasks.
Conclusion
The TacO benchmark provides the first empirical guidance for matching tactile sensor modalities to manipulation tasks, disproving the notion that more sensing is always better. For pick-and-place with variable parts, acoustic or magnetic sensors offer cost-effective slip detection. For precision reorientation, high-resolution visual sensors remain the leader. And for alignment-critical insertions, magnetic shear sensing delivers the most reliable performance across materials. Buyers can now make informed procurement decisions based on task priority rather than vendor claims.