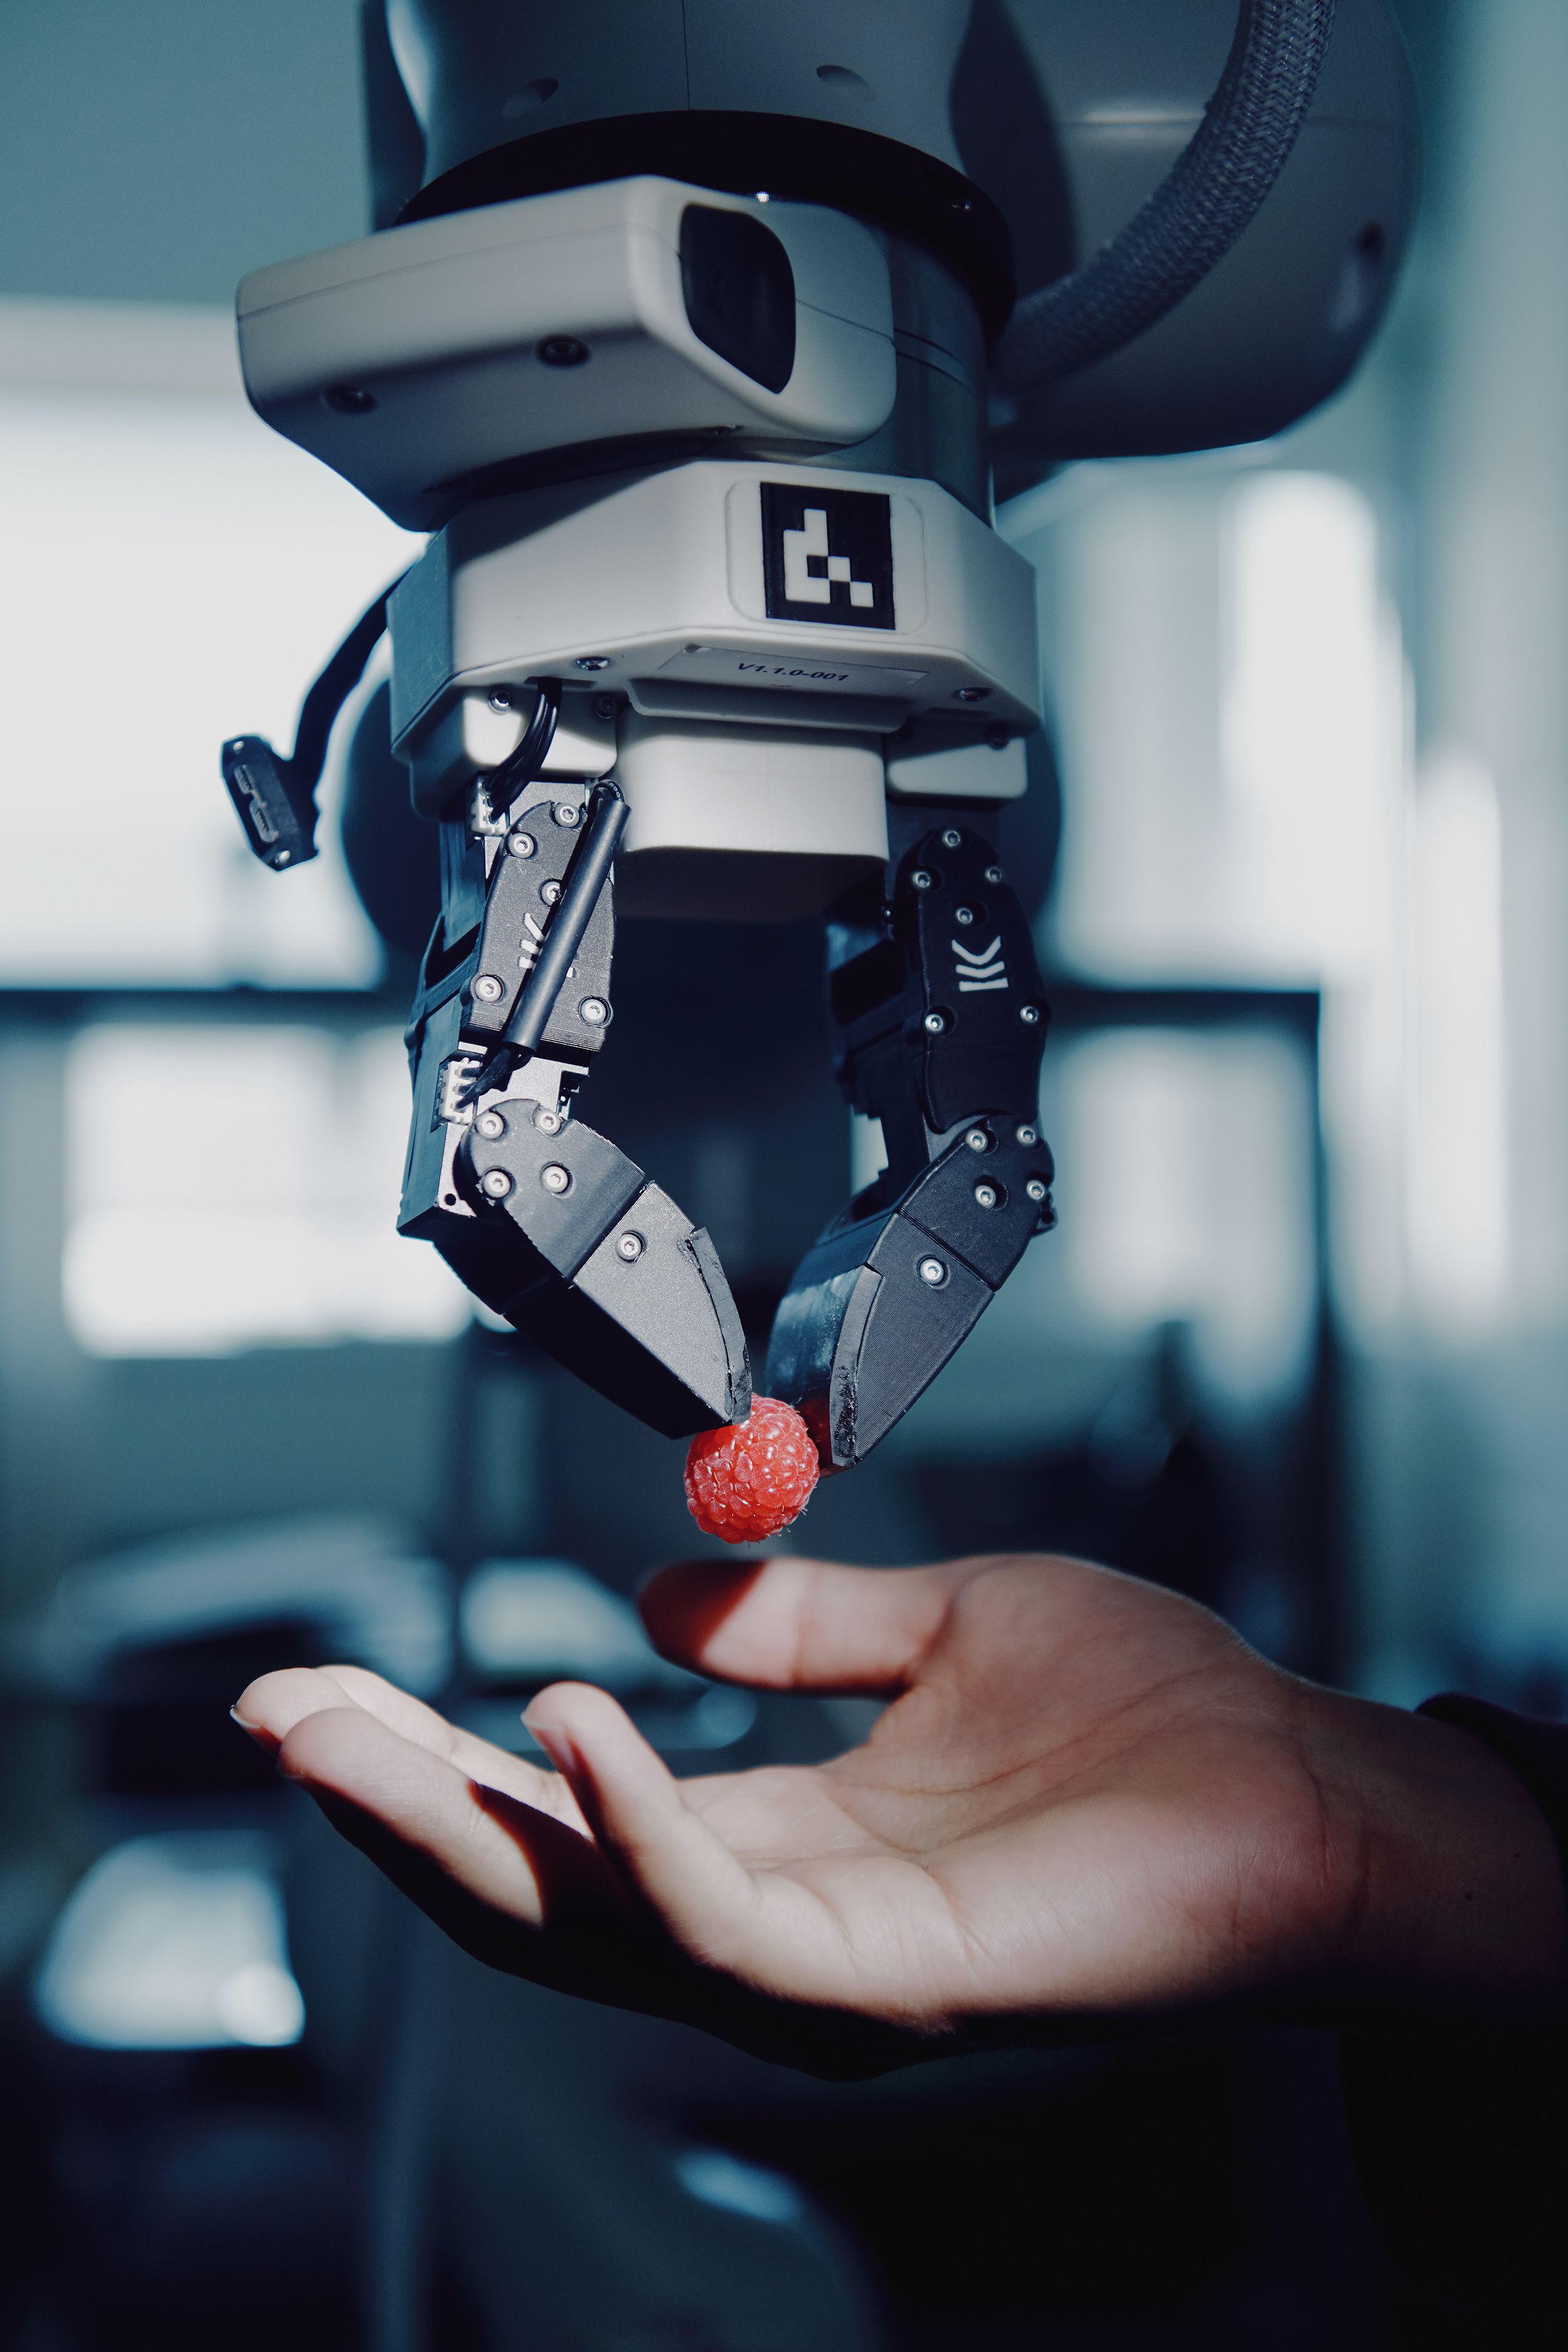
The robotics industry keeps declaring its "ChatGPT moment" — the breakthrough where machines finally crack human-level dexterity. Eka Robotics' demonstrations, from sorting chicken nuggets to screwing in light bulbs, are visually compelling. But impressive demos and genuine physical intelligence are very different things, and buyers writing six-figure purchase orders need to know the difference.
- The 'ChatGPT Moment' Problem in Robotics
- What Eka's Robots Actually Do
- Demo Dexterity vs. Industrial Dexterity
- What Manipulation Robots Actually Cost — And What You Get
- What This Means for Automation Buyers
- Frequently Asked Questions
The 'ChatGPT Moment' Problem in Robotics
Every few months, a new robotics company releases footage that goes viral. A robot hand catches a thrown object. A humanoid folds a t-shirt. A gripper unscrews a bottle cap without breaking it. The narrative is always the same: this is the inflection point, the moment physical AI finally arrived.
The problem is that ChatGPT's actual breakthrough was measurable and immediate. You could use it. Millions of people did, the same week it launched, for real productive tasks. The robots in these viral demos operate under conditions that rarely survive contact with production environments — controlled lighting, known object positions, pre-selected object geometries, and dozens of takes to get one clean recording.
This is not cynicism. It is calibration. The gap between "eerily lifelike in a lab" and "reliable in a food-processing facility" is where robotics companies have been dying for thirty years. Eka Robotics may genuinely be pushing the state of the art forward. But the ChatGPT analogy does the industry a disservice, because it sets an expectation of immediate, universal deployment readiness that manipulation hardware simply cannot yet deliver.
What Eka's Robots Actually Do
Eka Robotics has demonstrated manipulation capabilities that are, by any fair measure, technically impressive. Their systems handle tasks that sit at the difficult end of the robotics dexterity spectrum — sorting irregular food items like chicken nuggets (variable shape, variable surface friction, compressible), and performing constrained assembly tasks like screwing in light bulbs (requiring compliant force control and precise rotational alignment).
According to Wired, Eka's robots appear eerily lifelike in their motion — a description that points to something real. Biological motion naturalness is actually a proxy metric researchers use to evaluate whether a robot has learned generalised manipulation skills or is executing a rigid motion primitive. Lifelike movement suggests the system is responding dynamically to sensory feedback rather than replaying a recorded trajectory.
That distinction matters enormously. A robot replaying a fixed trajectory fails the moment an object shifts two centimetres. A robot with genuine sensorimotor feedback can recover. Which category Eka's system falls into — and under what conditions it can recover — is the question that no demo video fully answers.
Demo Dexterity vs. Industrial Dexterity
The robotics field has a long-standing credibility problem rooted in the gap between demonstration performance and deployment performance. Here is what that gap looks like in practice:
| Capability | Controlled Demo | Production Floor Reality |
|---|---|---|
| Object variety | Hand-selected, consistent | Random, variable, damaged |
| Lighting | Optimised | Inconsistent, harsh, shadows |
| Failure recovery | Edit out failures | Must recover autonomously |
| Throughput | Qualitative ("it works") | Quantified (units/hour, OEE%) |
| Uptime requirement | Single take | 85-99% sustained |
| Object presentation | Staged | Random orientation, clutter |
The chicken nugget demo is actually a useful test case. Food items are among the hardest manipulation targets — deformable, variable, with uncertain friction coefficients and unpredictable behaviour when grasped. If Eka's system genuinely handles this at production throughput rates with the failure modes documented, it represents real progress. But "handles it in a demo" and "handles it at 600 units per hour across a 16-hour shift" are separated by an enormous engineering gulf.
The light bulb task is similarly instructive. Screwing in a bulb requires the robot to detect thread engagement, modulate torque to avoid overtightening, and recognise successful seating — all through force-torque feedback rather than vision alone. This is legitimately hard. Companies like Sanctuary AI and Apptronik have been working on comparable precision assembly capabilities for years without declaring a ChatGPT moment, precisely because they understand how many edge cases exist between "demo ready" and "factory ready."
What Manipulation Robots Actually Cost — And What You Get
Grounding the hype in purchase economics is useful here. The manipulation robot market spans a wide range of capability tiers, and buyers need a realistic framework for what each tier actually delivers.
| Platform Type | Typical Price Range | Dexterity Level | Production Readiness |
|---|---|---|---|
| Fixed industrial arm (e.g. FANUC, KUKA) | $25,000–$80,000 | Low — structured tasks only | High — proven at scale |
| Collaborative robot (cobot) with standard gripper | $35,000–$75,000 | Medium — semi-structured | High — ISO certified |
| Cobot with advanced dexterous gripper | $60,000–$120,000 | Medium-high — varied objects | Medium — application-specific |
| Purpose-built dexterous manipulation system | $150,000–$400,000+ | High — unstructured environments | Low-to-medium — early deployment |
| Humanoid (current gen) | $50,000–$250,000 | Variable — rapidly evolving | Low — pilot programs only |
Buyers exploring the used cobots for sale on Robot Overflow will find proven platforms in the $35,000–$75,000 range that deliver reliable, predictable performance for structured tasks. The honest trade-off: these systems will not sort chicken nuggets or screw in light bulbs without substantial engineering investment in fixturing and end-effector design. But they will run three shifts a day, five years from now, with documented uptime.
The emerging dexterous manipulation systems — the category Eka occupies — promise to eliminate that fixturing investment. The question buyers must ask is: at what price point, with what uptime guarantees, and with what failure mode documentation?
What This Means for Automation Buyers
The dexterous manipulation category is real, it is advancing rapidly, and it will eventually deliver on the ChatGPT-moment narrative. But "eventually" and "now" are not the same procurement decision.
For buyers evaluating Eka or similar dexterous manipulation platforms, the due diligence checklist should include: throughput figures under production conditions (not demo conditions), mean time between failures in uncontrolled environments, the breadth of object geometries tested, software update cadence and backward compatibility guarantees, and total cost of ownership including integration engineering.
For buyers with structured, repeatable tasks, the calculus is different. A used industrial robot configured for a known pick-and-place workflow will outperform any current dexterous system on unit economics and uptime. The dexterity premium only pays off when task variability is high enough that traditional fixturing becomes more expensive than the robot itself.
The broader signal is worth taking seriously regardless of deployment timing. The fact that companies like Eka are achieving biologically plausible manipulation motion in laboratory conditions means the production-ready version is probably three to seven years away, not thirty. That changes capital planning horizons. Facilities that are designing automation infrastructure today should architect for dexterous manipulation integration even if they are not deploying it yet.