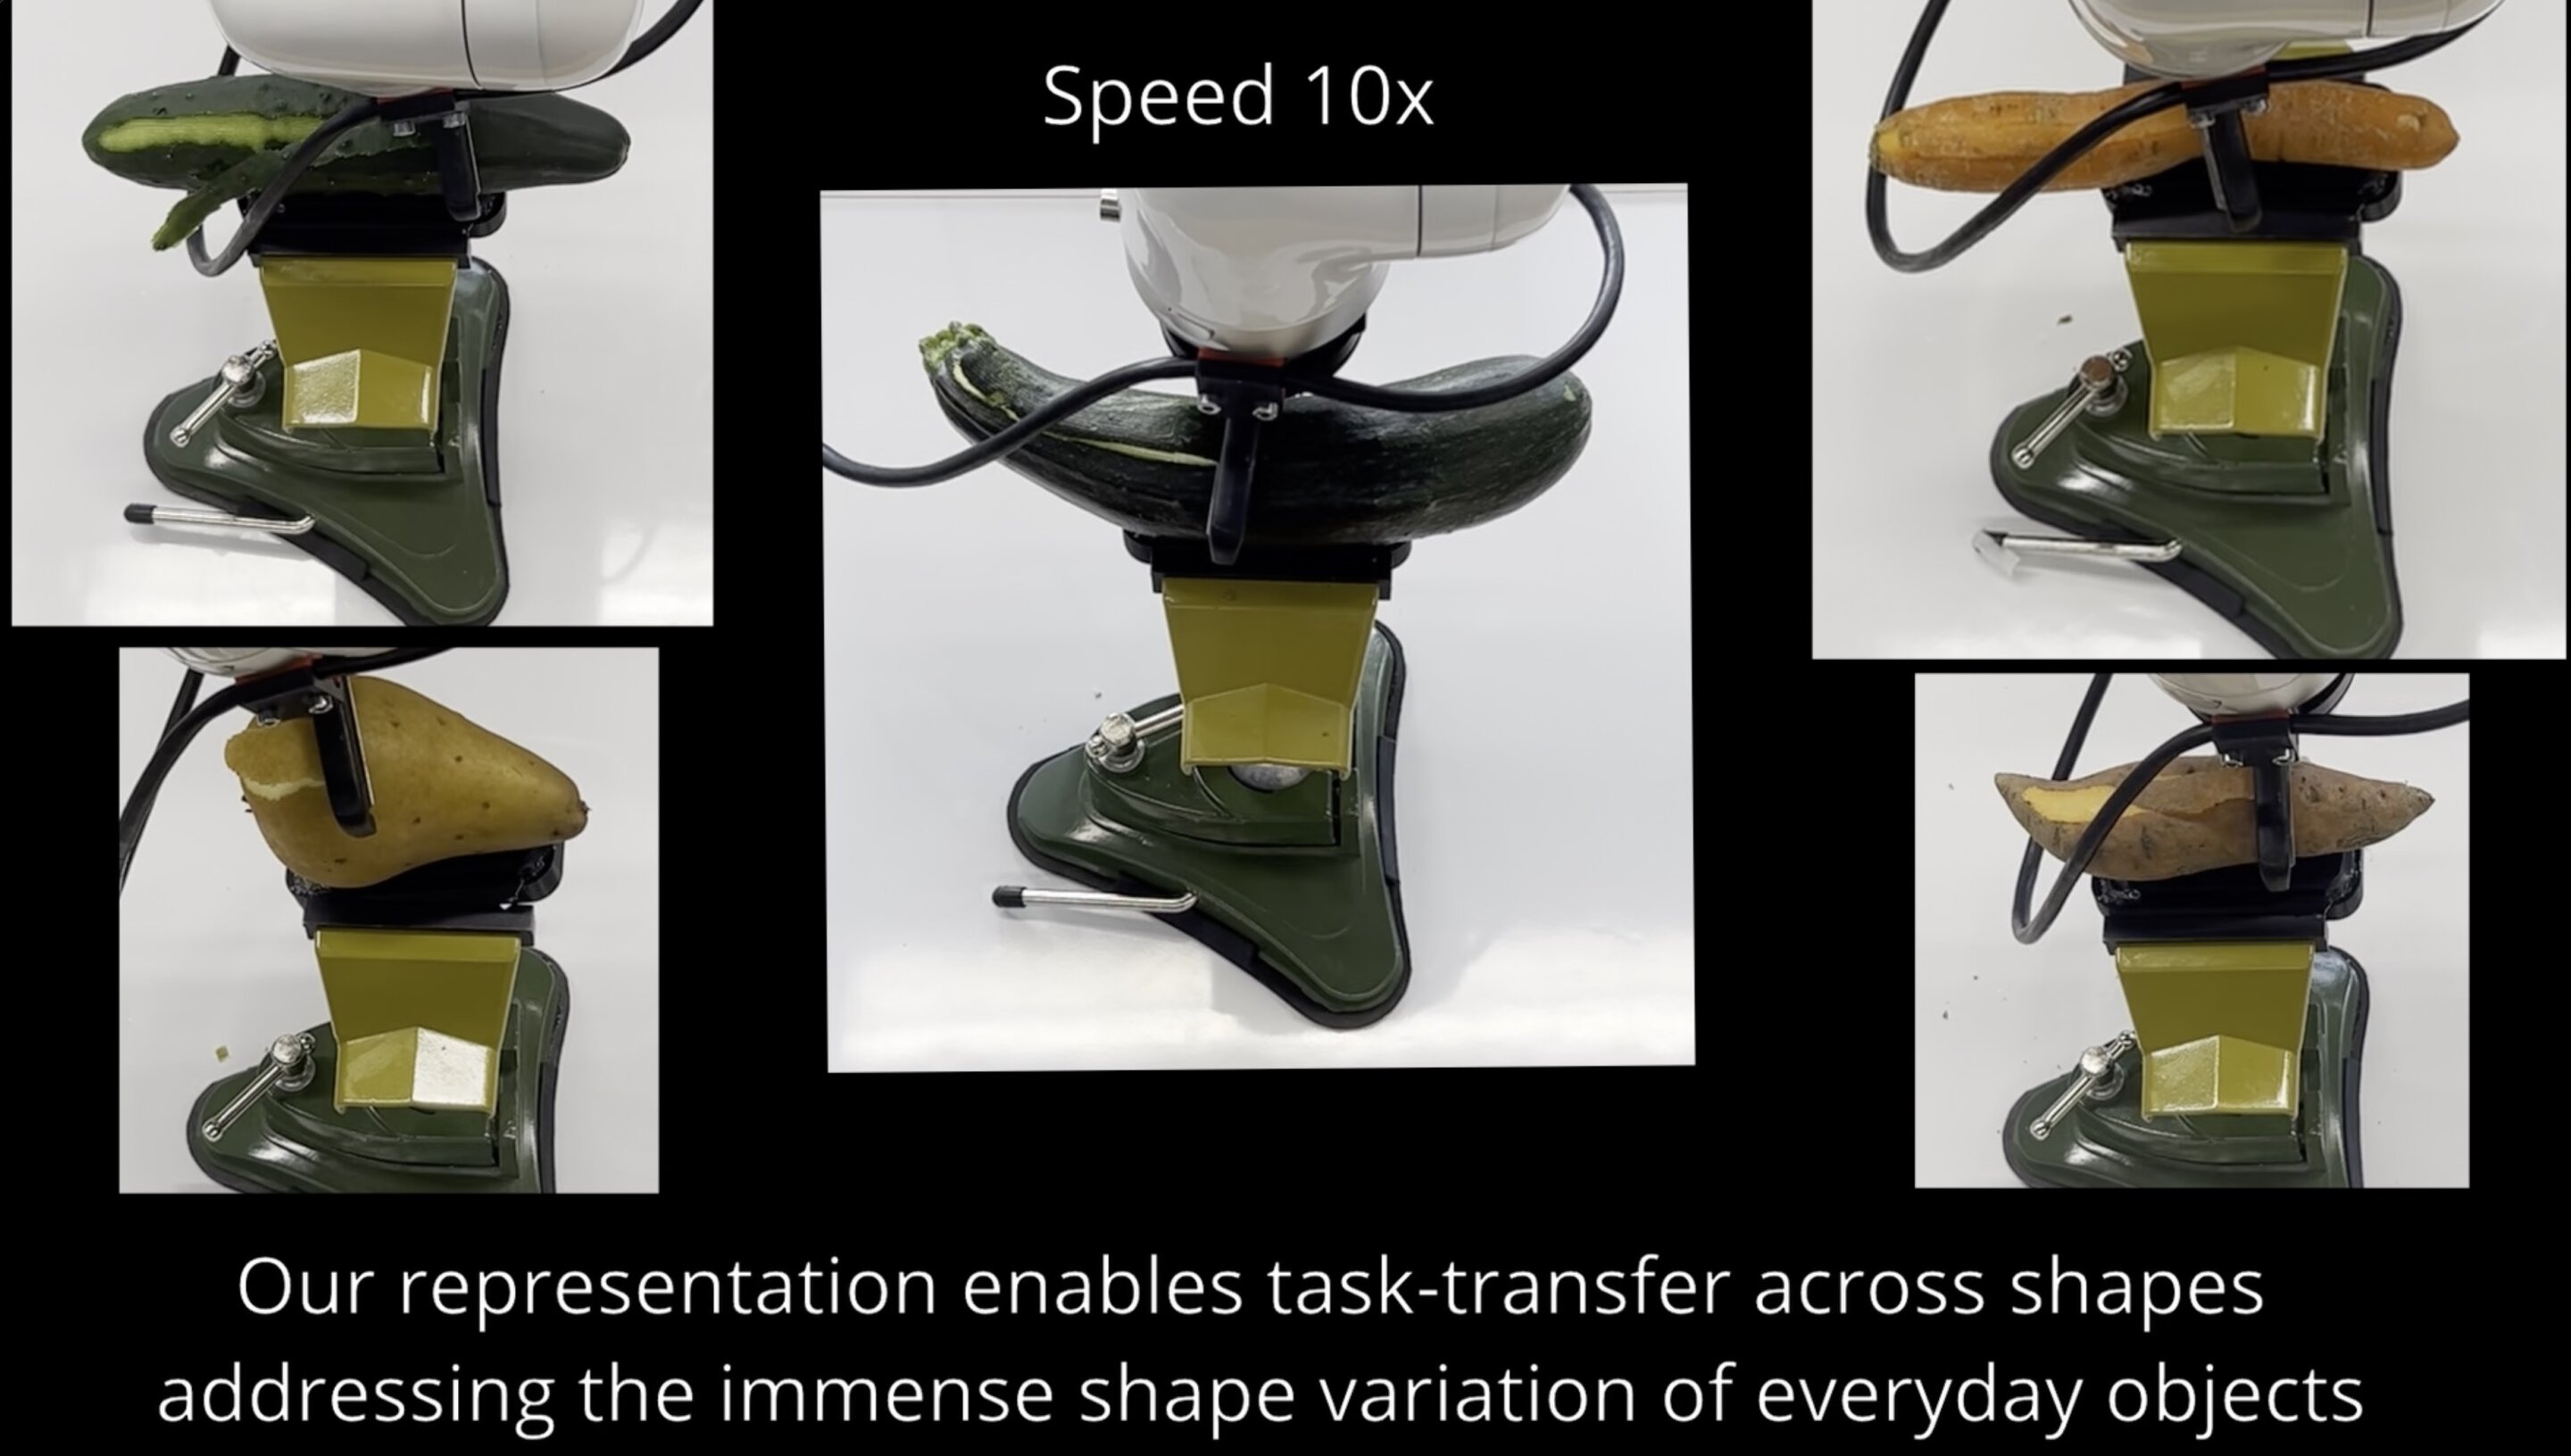
Robots that flawlessly stack boxes routinely fumble a banana. New research targets that exact gap, introducing a framework that teaches robots to reason about curved, irregular objects — the kind that dominate real kitchens, clinics, and factory floors. The implications stretch well beyond fruit: this is foundational work for any gripper system that needs to operate outside tightly controlled environments.
Table of Contents
- Why Curved Objects Break Robot Grippers
- How the New Framework Works
- Benchmarking Against Current Gripper Capabilities
- What This Means for Robotics and Automation
- Frequently Asked Questions
Why Curved Objects Break Robot Grippers
Most commercial robot grippers are engineered around a silent assumption: objects have flat faces, predictable edges, and consistent contact geometry. A banana violates every one of those assumptions simultaneously.
The core problem is contact planning — determining precisely where a gripper should touch an object to achieve a stable, controllable hold. For a rectangular box, contact points are obvious and the physics are forgiving. For a curved surface, small errors in placement cascade: the gripper slips, the object rotates unpredictably, and the grasp fails. According to TechXplore, this challenge extends across an entire class of everyday objects — cups, peelers, fruit, tools — all sharing non-planar geometry that standard manipulation pipelines struggle to model accurately.
The practical cost is significant. Warehouse and food-processing automation has historically avoided soft, irregular produce precisely because grasp reliability drops sharply. A gripper that works at 99% success on cardboard boxes might fall to 60-70% on curved produce, making it economically unviable for high-throughput lines where one dropped item can disrupt an entire conveyor sequence.
How the New Framework Works
The research introduces a geometry-aware manipulation framework that represents curved object surfaces using differential geometry — the same mathematical toolkit used to describe curved spacetime in physics — applied here to model how a gripper's contact patch deforms and shifts as it interacts with non-planar surfaces.
Rather than treating an object's surface as a flat approximation (the default in many grasp-planning systems), the framework maintains a continuous curvature model. Think of it like the difference between navigating with a flat map versus a globe: the flat map introduces distortions that grow worse the further you move from the centre. The analogy breaks down at the extremes — real object surfaces are far more varied than a sphere — but the principle holds: curvature-aware models make more accurate contact predictions.
The system operates in three stages:
- Surface reconstruction — a depth sensor builds a curvature map of the target object in real time
- Contact optimisation — the planner identifies gripper placement that maximises stable contact area across the curved surface
- Grasp execution with feedback — force and torque sensors at the fingertips adjust grip pressure dynamically as the object is lifted and manipulated
This closed-loop architecture is the critical differentiator. Earlier approaches computed a grasp plan and executed it open-loop, meaning any deviation from the predicted contact geometry caused failure. The new system continuously corrects, which matters enormously when handling objects whose surfaces are not perfectly consistent — a slightly overripe banana deforms differently than a firm one.
Benchmarking Against Current Gripper Capabilities
How does this research stack up against the gripper hardware available today? The gap between research capability and commercial deployment is worth examining honestly.
| Gripper Type | Curved Object Performance | Typical Use Case | Limitation |
|---|---|---|---|
| Two-finger parallel jaw | Low — point contact only | Boxes, cylinders | Slips on irregular curves |
| Three-finger adaptive (e.g. Robotiq 2F-85) | Moderate — conforms partially | Mixed industrial pick | Limited curvature adaptation |
| Soft/compliant gripper | High conformance, low precision | Delicate produce | Poor for tools requiring precise placement |
| Dexterous multi-finger hand | High — but slow, expensive | Research platforms | Cycle time and cost prohibitive at scale |
| This research framework (sensor-feedback + curvature planning) | High conformance + precision | Lab-demonstrated | Not yet commercially packaged |
Current commercial leaders in adaptive gripping — such as Robotiq's 2F-85 and 3-Finger Adaptive Gripper — achieve reasonable performance on mildly curved objects through mechanical compliance: the fingers physically wrap around the object rather than solving the geometry computationally. This works, but it trades precision for conformance. You can pick up a banana, but placing it in an exact orientation for downstream processing — peeling, slicing, packaging — remains unreliable.
The research framework targets precisely this gap: not just grasping curved objects, but manipulating them with positional intent. That distinction matters for food processing, surgical robotics, and any application where the robot must do something specific with the object after picking it up.
For buyers exploring used industrial robots for food or consumer goods applications, the honest assessment is that current hardware paired with standard software cannot reliably solve this problem. This research points toward what the next generation of gripper-plus-perception systems will need to deliver.
What This Means for Robotics and Automation
This research matters most for four application domains where curved-object handling is currently the bottleneck.
Food processing and agriculture represent the most immediate opportunity. Fruit picking, sorting, and processing lines are either heavily manual or use highly specialised single-purpose machinery. A generalised curved-object manipulation capability could unlock flexible automation for produce lines that currently can't justify the engineering cost of custom solutions.
Surgical and medical robotics handle curved instruments — scalpels, retractors, catheters — constantly. Precise, adaptive grasping of these tools is already a research priority; this framework provides a computational foundation applicable to that domain.
Service and household robotics face the curved-object problem in essentially every kitchen task. A robot that can reliably handle a cup, a banana, a vegetable peeler, and a sponge — all in the same workflow — is categorically more useful than one limited to flat or prismatic objects. This is a prerequisite capability for the humanoid home-assistant category that multiple companies are currently developing.
Cobots in unstructured manufacturing are increasingly being asked to handle components that aren't perfectly machined — castings, moulded parts, organic-shaped consumer products. Pairing cobot arms with curvature-aware grasp planning would meaningfully expand their deployable range. Buyers evaluating used cobots for sale for flexible manufacturing cells should watch this research space closely, as software updates to existing hardware could deliver capability upgrades without capital expenditure on new arms.
The broader signal here is directional: the field is moving from gripper hardware innovation toward perception-and-planning innovation. The next step-change in manipulation capability will likely come from better computational models of contact geometry, not from more exotic finger materials.