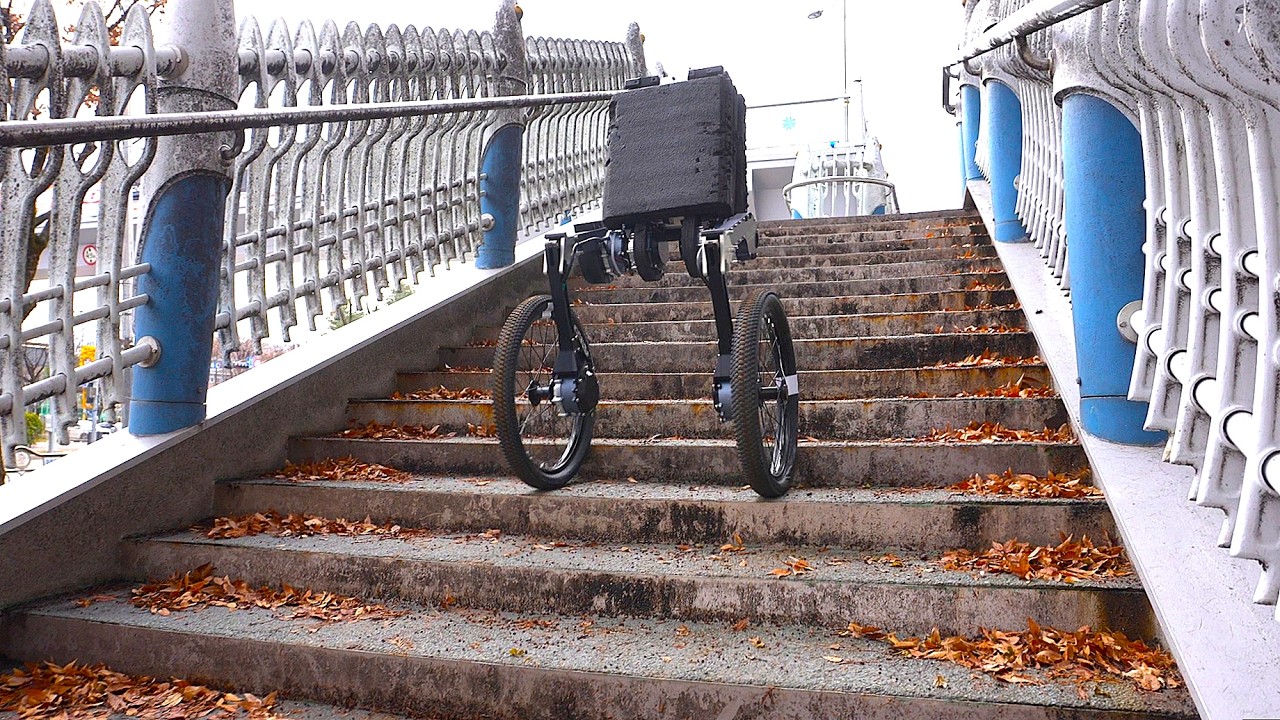
A paper presents RAIWAY, an in-house wheeled biped with 20-inch wheels, alongside a contact-informed controller for rolling over irregular and discontinuous terrain, first reported by Arxiv. The task is contact-dominated: local wheel–terrain interactions are impractical to instrument directly and depend on more than terrain geometry alone during this form of locomotion.
The framework uses contact information available in simulation to distill multi-contact events into a latent representation. At deployment, the controller infers that representation online from proprioception without contact sensing.
Real-world experiments covered steep slopes, gravel beds, studded surfaces and rocky terrain. RAIWAY also demonstrated continuous ascent on tested outdoor staircases, with riser heights up to 15 cm.
On the RAIWAY platform, the proposed controller outperformed baselines without the contact-informed mechanism across challenging indoor and outdoor settings. Together, the findings link simulation-informed control to real-world surface and stair tests, with performance compared on the platform.
Kyungmin Nam, Jiseong Lee, Donghyuk Choi, Jeongsoo Park, Woojin Kim and Jemin Hwangbo are listed as authors. The paper was submitted on 23 Oct 2026, runs eight pages and has seven figures; it was accepted to IEEE Robotics and Automation Letters (RA-L).